Motion planning with complete knowledge using a colored SOM
Related Experiment Video
Updated: Oct 24, 2026
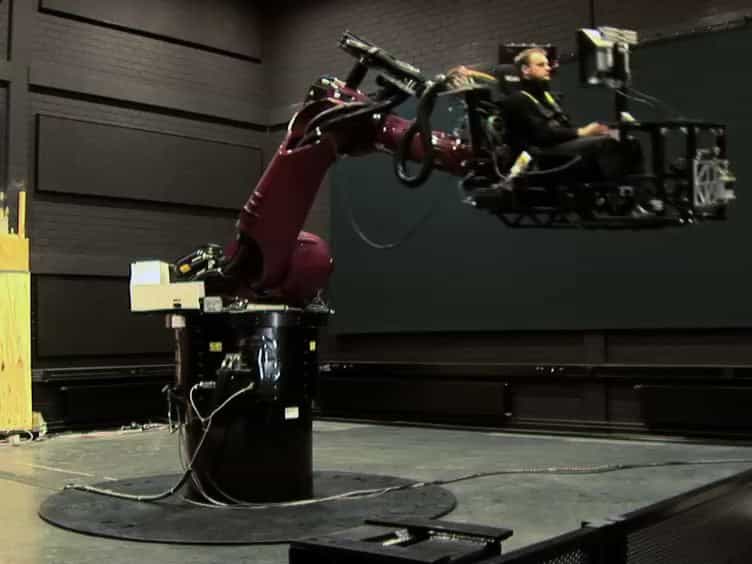
MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
J Vleugels1, J N Kok, M Overmars
1Department of Computer Science, Utrecht University, The Netherlands.

Abstract:
The motion planning problem requires that a collision-free path be determined for a robot moving amidst a fixed set of obstacles. Most neural network approaches to this problem are for the situation in which only local knowledge about the configuration space is available. The main goal of the paper is to show that neural networks are also suitable tools in situations with complete knowledge of the configuration space. In this paper we present an approach that combines a neural network and deterministic techniques. We define a colored version of Kohonen's self-organizing map that consists of two different classes of nodes. The network is presented with random configurations of the robot and, from this information, it constructs a road map of possible motions in the work space. The map is a growing network, and different nodes are used to approximate boundaries of obstacles and the Voronoi diagram of the obstacles, respectively. In a second phase, the positions of the two kinds of nodes are combined to obtain the road map. In this way a number of typical problems with small obstacles and passages are avoided, and the required number of nodes for a given accuracy is within reasonable limits. This road map is searched to find a motion connecting the given source and goal configurations of the robot. The algorithm is simple and general; the only specific computation that is required is a check for intersection of two polygons. We implemented the algorithm for planar robots allowing both translation and rotation and experiments show that compared to conventional techniques it performs well, even for difficult motion planning scenes.
Related Concept Videos
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:30
Vector Functions and Motion: Problem Solving
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:06
Body Planes
The sagittal plane is the plane that divides the body or an organ vertically into right and left sides. If this vertical plane runs directly down the middle of the body resulting in equal division, it is called the midsagittal or median...