Speed/accuracy trade-offs in target-directed movements
Related Experiment Video
Updated: Oct 24, 2026
Investigating the Deployment of Visual Attention Before Accurate and Averaging Saccades via Eye Tracking and Assessment of Visual Sensitivity
Published on: March 18, 2019
1Département de génie électrique et de génie informatique, Ecole Polytechnique, Montréal, Québec, Canada. rejean@scribens.polymtl.ca

Abstract:
This target article presents a critical survey of the scientific literature dealing with the speed/accuracy trade-offs in rapid-aimed movements. It highlights the numerous mathematical and theoretical interpretations that have been proposed in recent decades. Although the variety of points of view reflects the richness of the field and the high degree of interest that such basic phenomena attract in the understanding of human movements, it calls into question the ability of 'many models to explain the basic observations consistently reported in the field. This target article summarizes the kinematic theory of rapid human movements, proposed recently by R. Plamondon (1993b; 1993c; 1995a; 1995b), and analyzes its predictions in the context of speed/accuracy trade-offs. Data from human movement literature are reanalyzed and reinterpreted in the context of the new theory. It is shown that the various aspects of speed/accuracy trade-offs can be taken into account by considering the asymptotic behavior of a large number of coupled linear systems, from which a delta-lognormal law can be derived to describe the velocity profile of an end-effector driven by a neuromuscular synergy. This law not only describes velocity profiles almost perfectly, it also predicts the kinematic properties of simple rapid movements and provides a consistent framework for the analysis of different types of speed/accuracy trade-offs using a quadratic (or power) law that emerges from the model.
Related Concept Videos
 01:30
Vector Functions and Motion: Problem Solving
 01:10
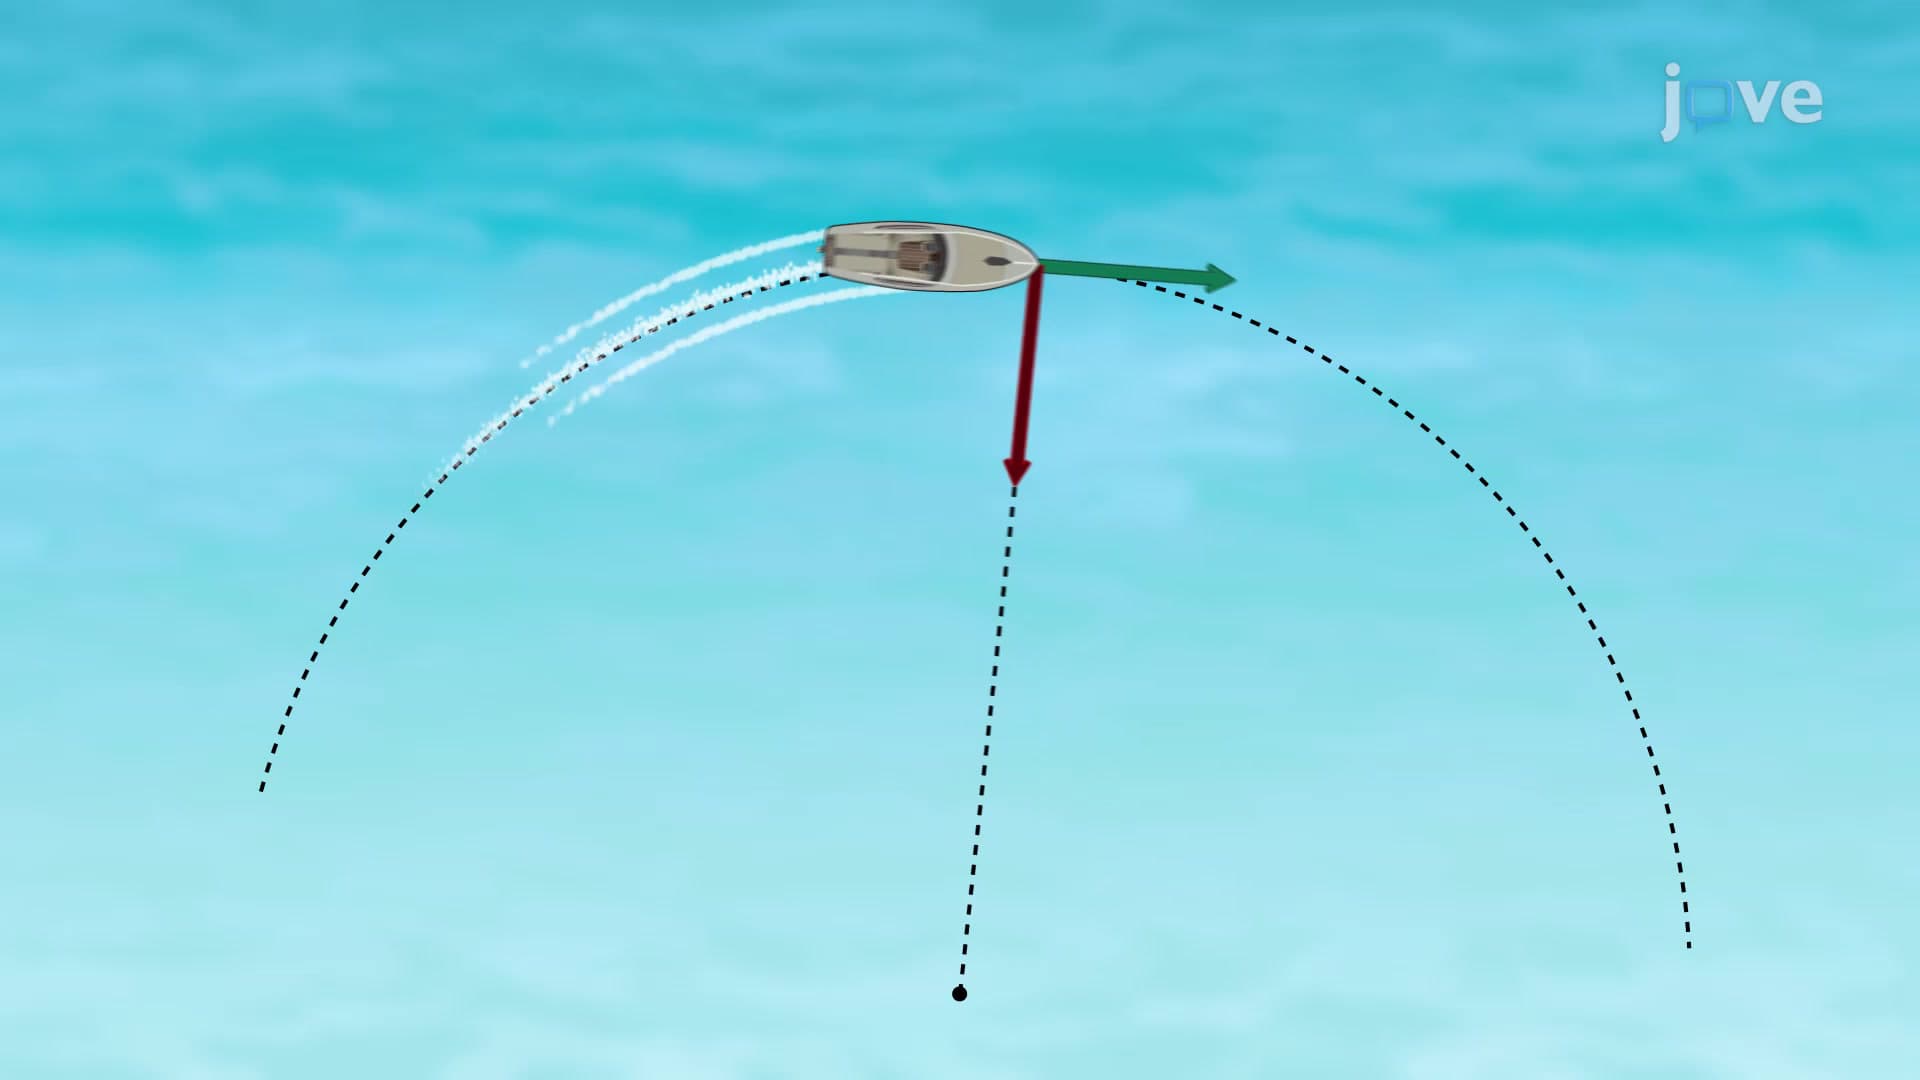
Direction of Acceleration Vectors
 01:11
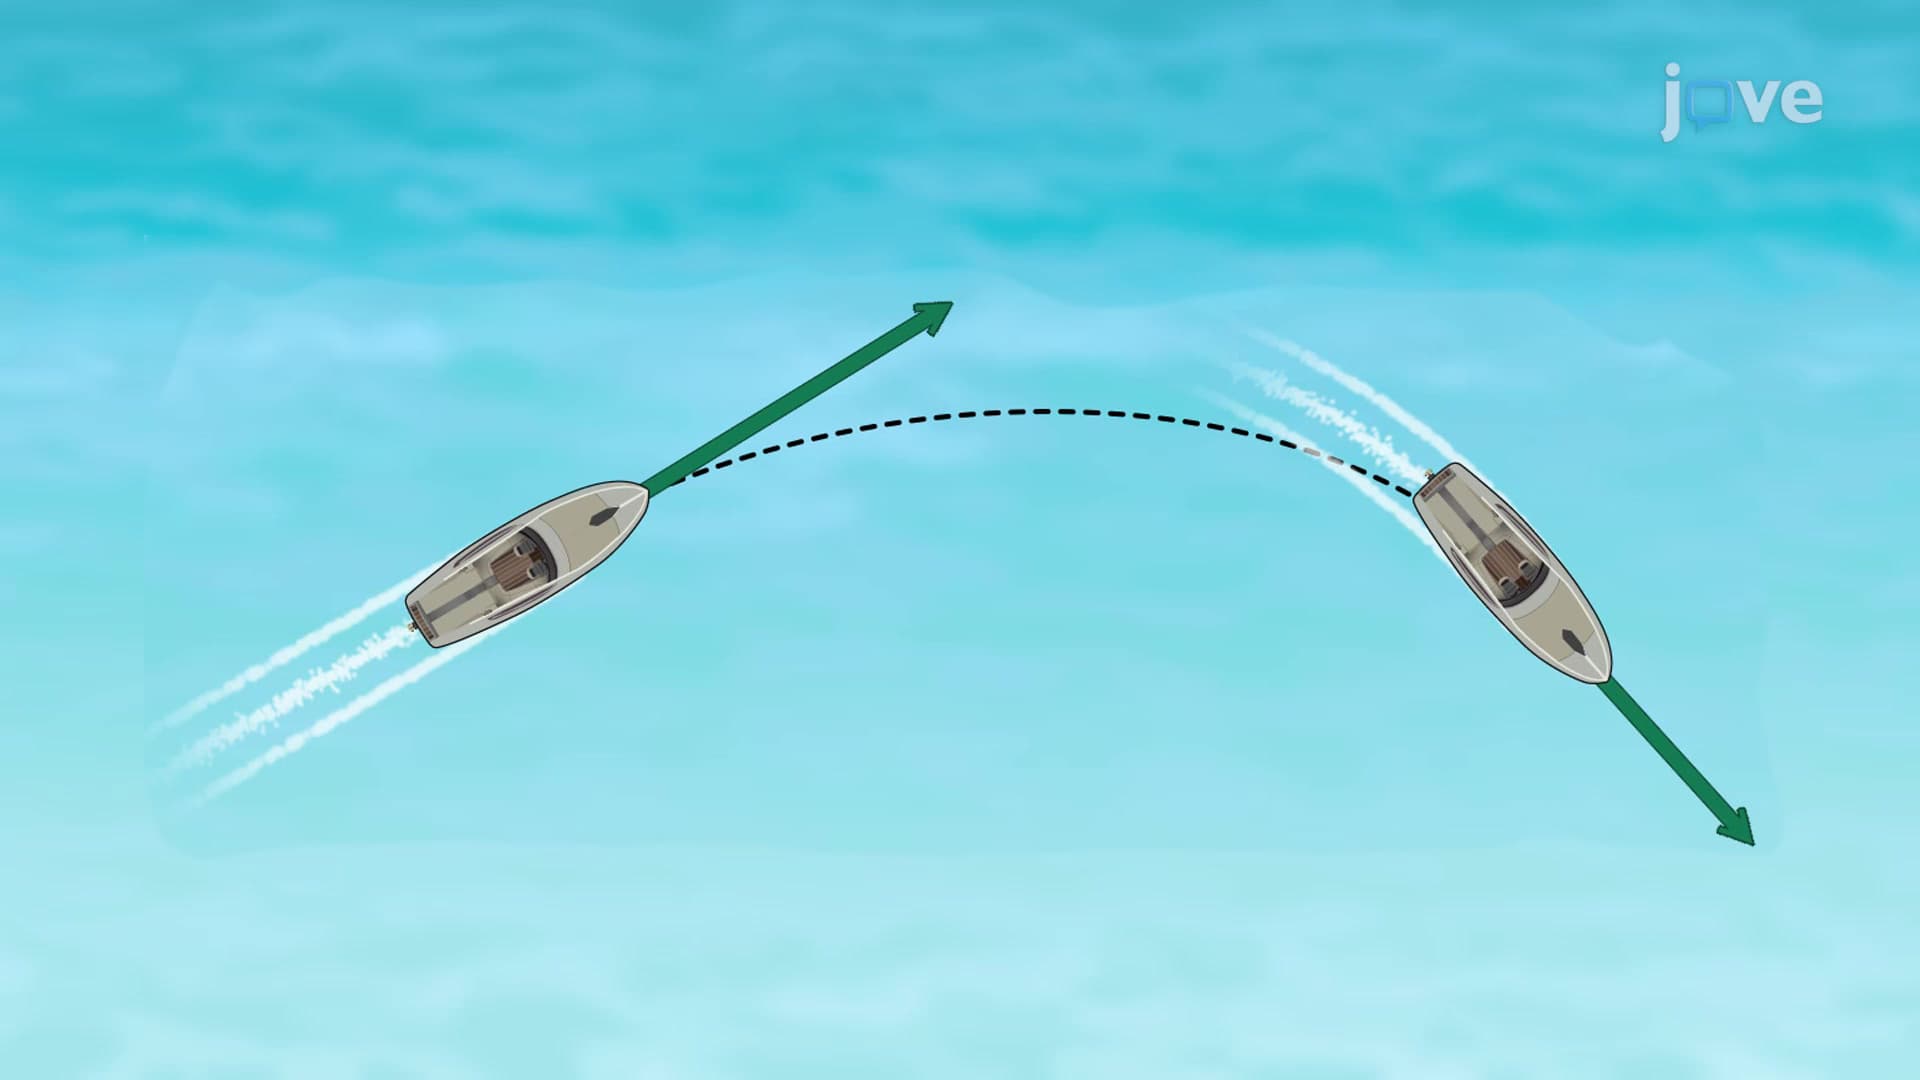
Relative Velocity in Two Dimensions
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:30
Acceleration Vectors
 01:10
Relative Velocity in One Dimension