Related Experiment Video
Updated: Oct 23, 2026
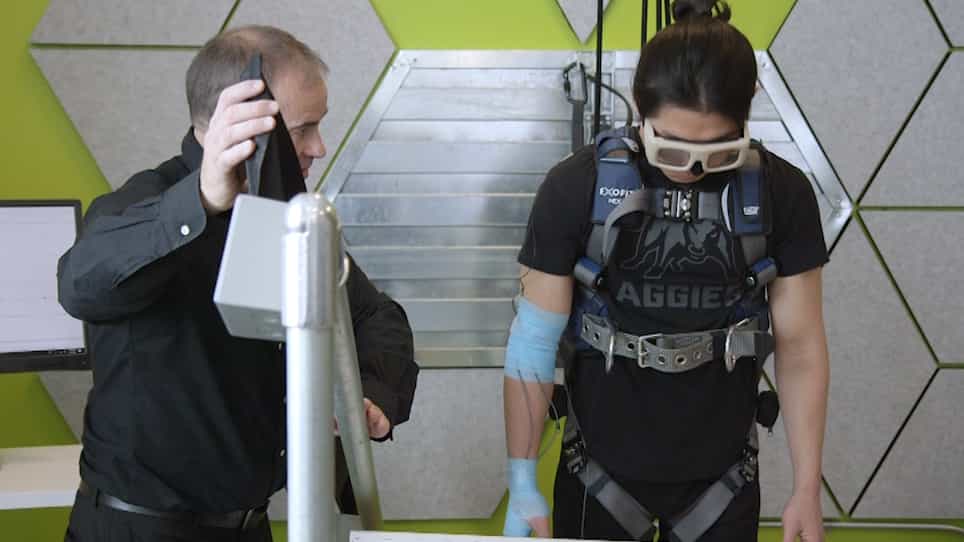
A Modified Lean and Release Technique to Emphasize Response Inhibition and Action Selection in Reactive Balance
Published on: March 19, 2020
Evolving neurocontrollers for balancing an inverted pendulum
1Max-Planck-Institute for Mathematics in the Sciences, Leipzig, Germany. f.pasemann@mis.mpg.de

Abstract:
This paper introduces an evolutionary algorithm that is tailored to generate recurrent neural networks functioning as nonlinear controllers. Network size and architecture, as well as network parameters like weights and bias terms, are developed simultaneously. There is no quantization of inputs, outputs or internal parameters. Different kinds of evolved networks are presented that solve the pole-balancing problem, i.e. balancing an inverted pendulum. In particular, controllers solving the problem for reduced phase space information (only angle and cart position) use a recurrent connectivity structure. Evolved controllers of 'minimal' size still have a very good benchmark performance.
Related Concept Videos
 01:09
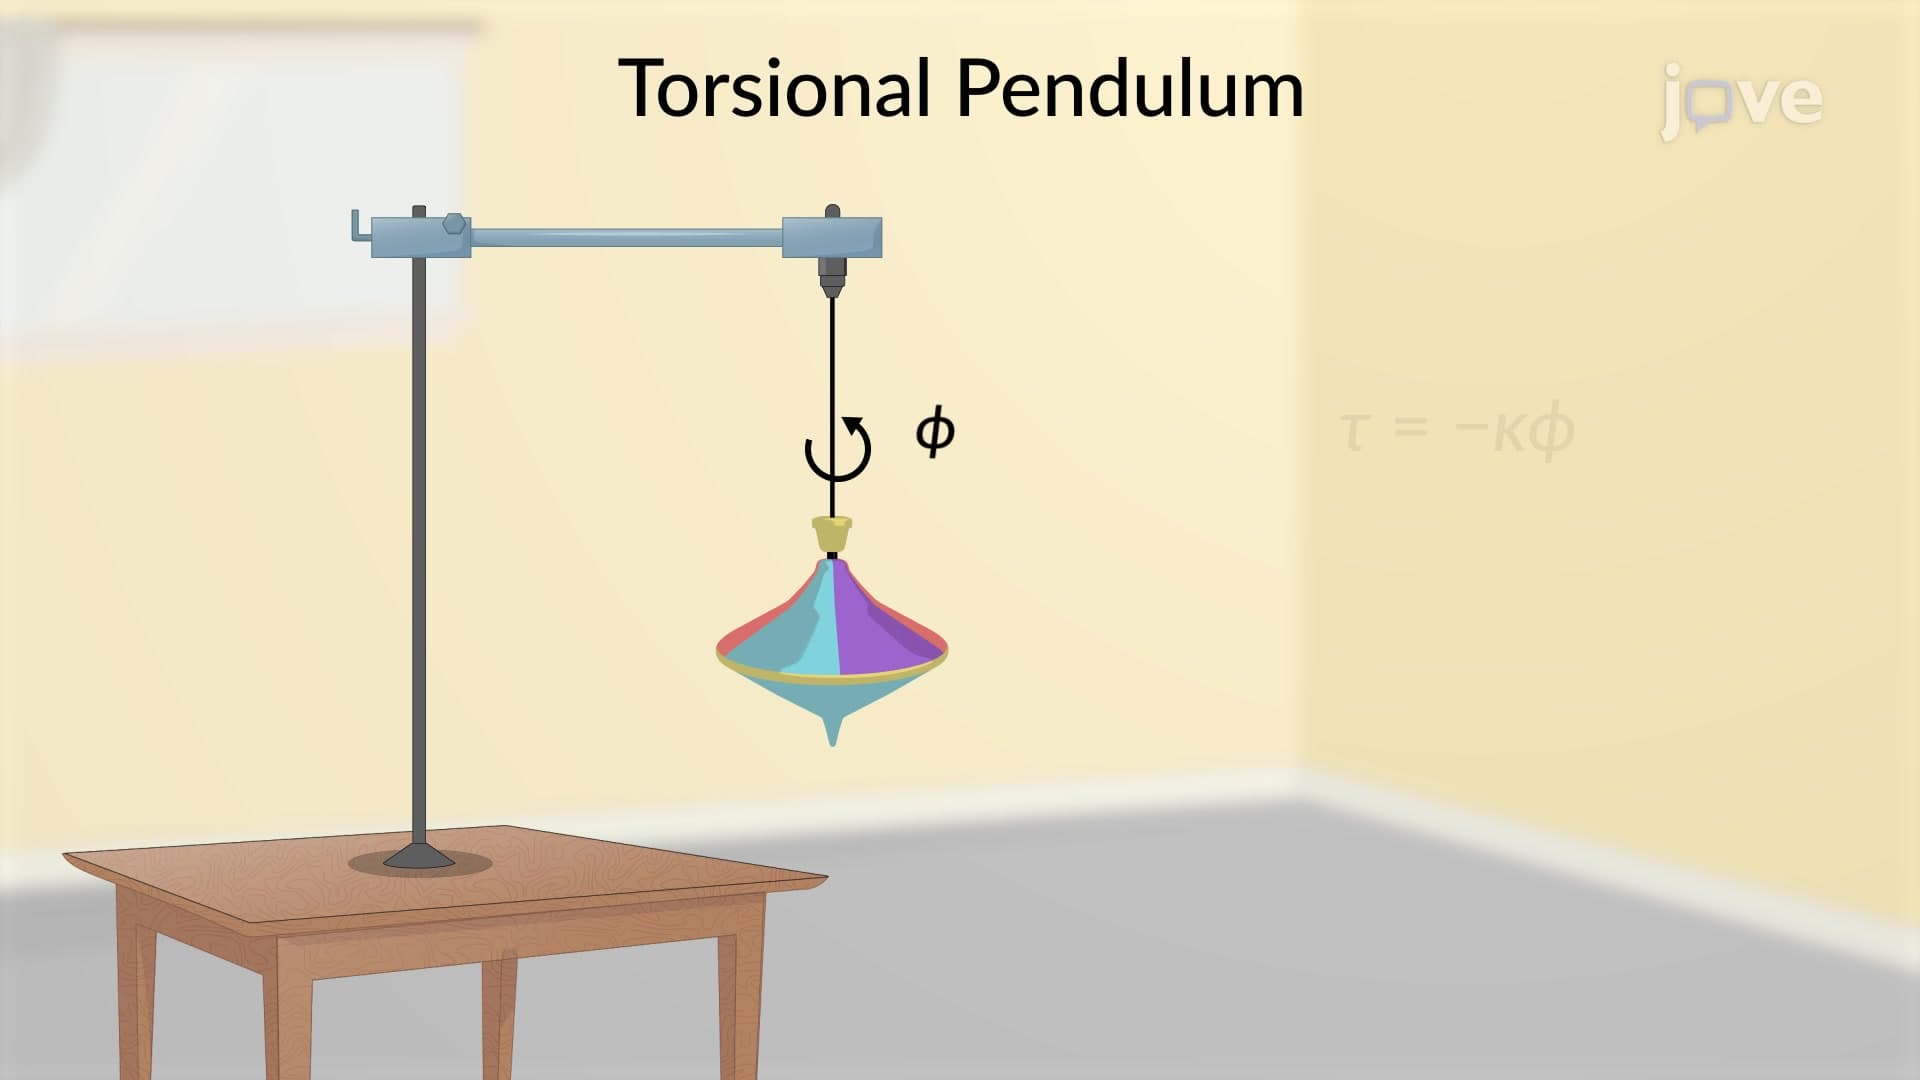
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played by the...
 01:06
Physical Pendulum
When dealing with complicated systems, the mass moment of inertia is an important parameter, as it describes the mass...
 01:15
Equilibrium and Balance
 01:10
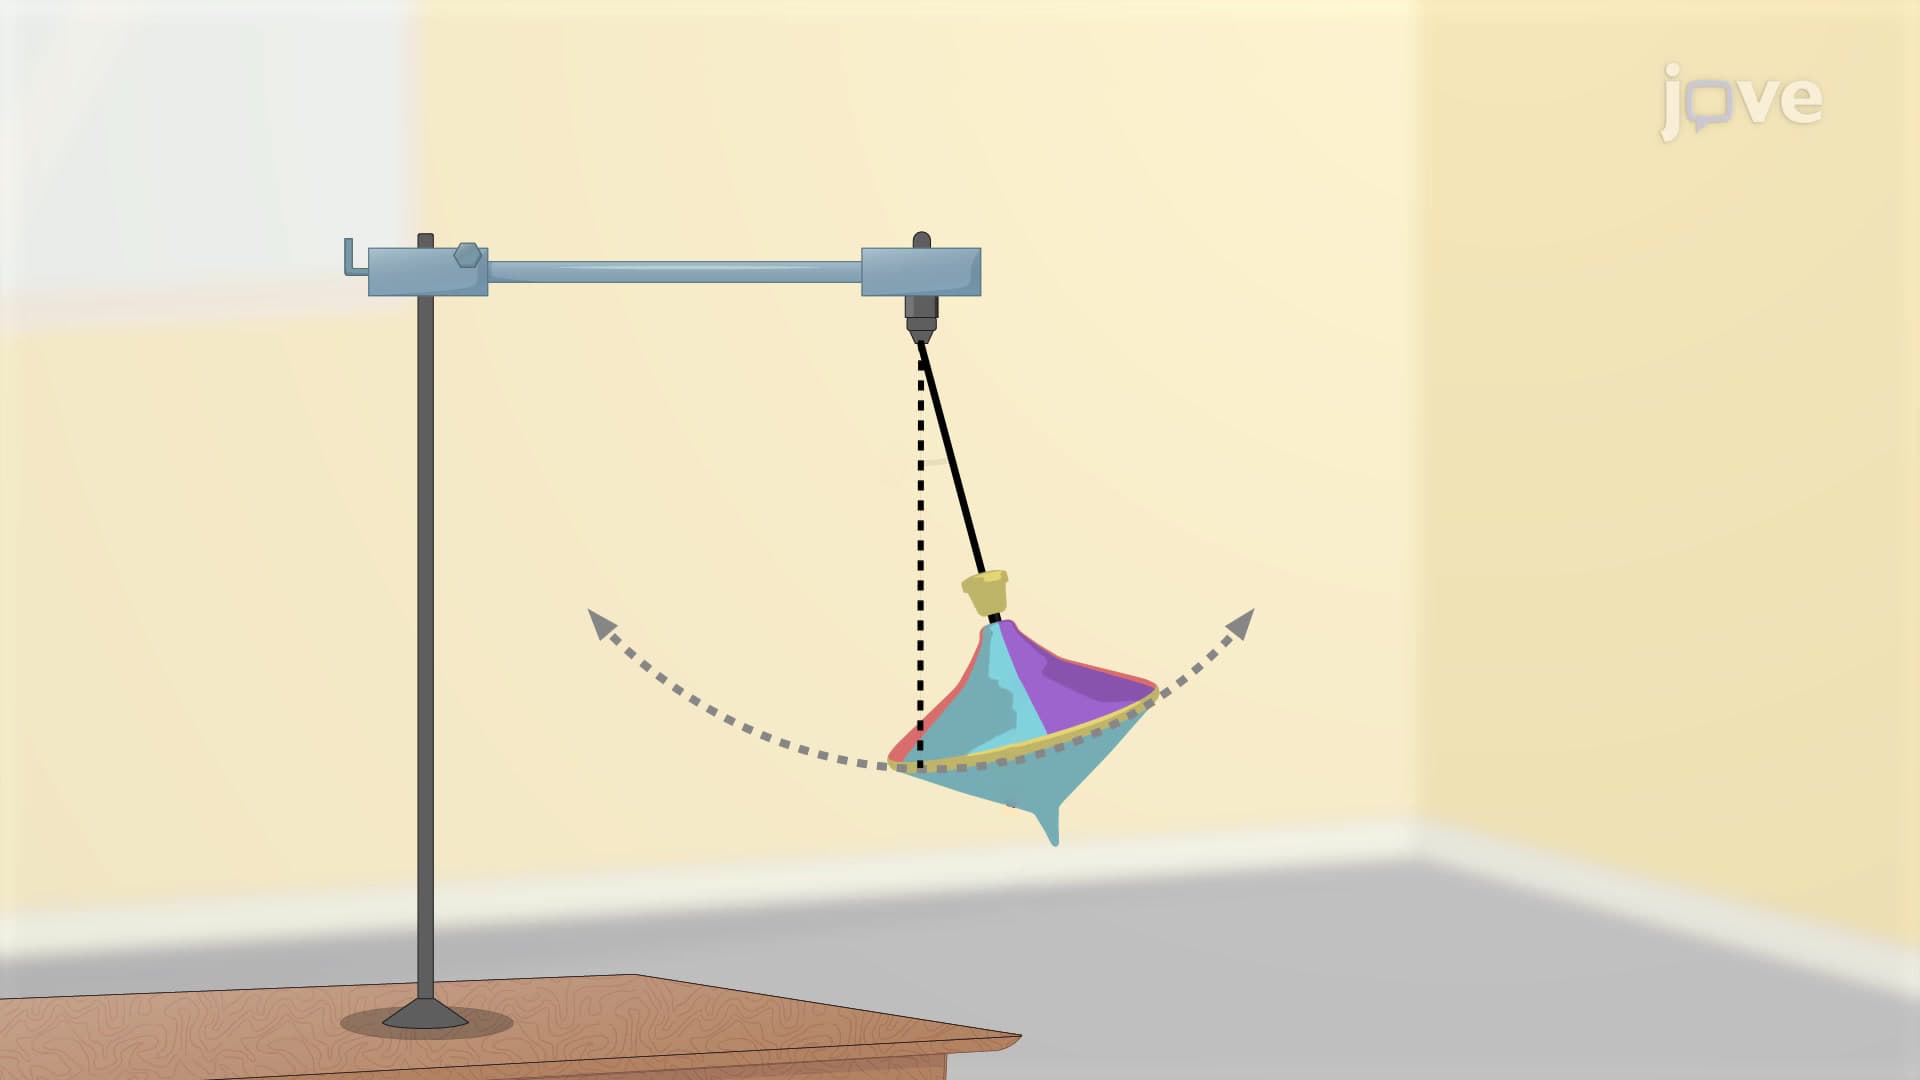
Simple Pendulum
The period of a simple pendulum depends on two factors: its length and the acceleration due to gravity. The period is completely independent of any other factors, such as mass or maximum displacement. For small displacements, a pendulum is...
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 00:49
Rigid Body Equilibrium Problems - I