Related Experiment Video
Updated: Oct 23, 2026
Measuring 3D In-vivo Shoulder Kinematics using Biplanar Videoradiography
Published on: March 12, 2021
The limitations of the instantaneous centre of rotation in joint research
1Biomechanics and Biomaterial Research Center, Department of Mechanical Engineering, Indiana University-Purdue University at Indianapolis, 46202, USA. jchen@engr.iupui.edu

Abstract:
The limitations on the use of the instantaneous centre of rotation (ICR), as calculated from discrete displacement data, are often not fully appreciated. As a consequence, the concept of the ICR has been improperly applied in some instances. In this paper, the procedures used to compute the ICR are developed in detail, and the factors that affect the computed results are identified. With an example, it is shown that in addition to being path dependent, ICR location is also sampling increment size dependent. Therefore, it is not appropriate to consider the ICR as a rotation centre if the body is undergoing general planar (combined translation and rotation) motion because it does not uniquely characterize the movement.
Related Concept Videos
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:20
Instantaneous Center of Zero Velocity
To analyze this, consider two points on the wheel: point A and point B. The absolute velocity of point B can be expressed as the vector sum of the absolute velocity of point A and the relative velocity of point B with respect to point A. To simplify this analysis,...
 01:26
Rotational Motion about a Fixed Axis
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:19
Euler Equations of Motion
 01:14
Moment of Inertia
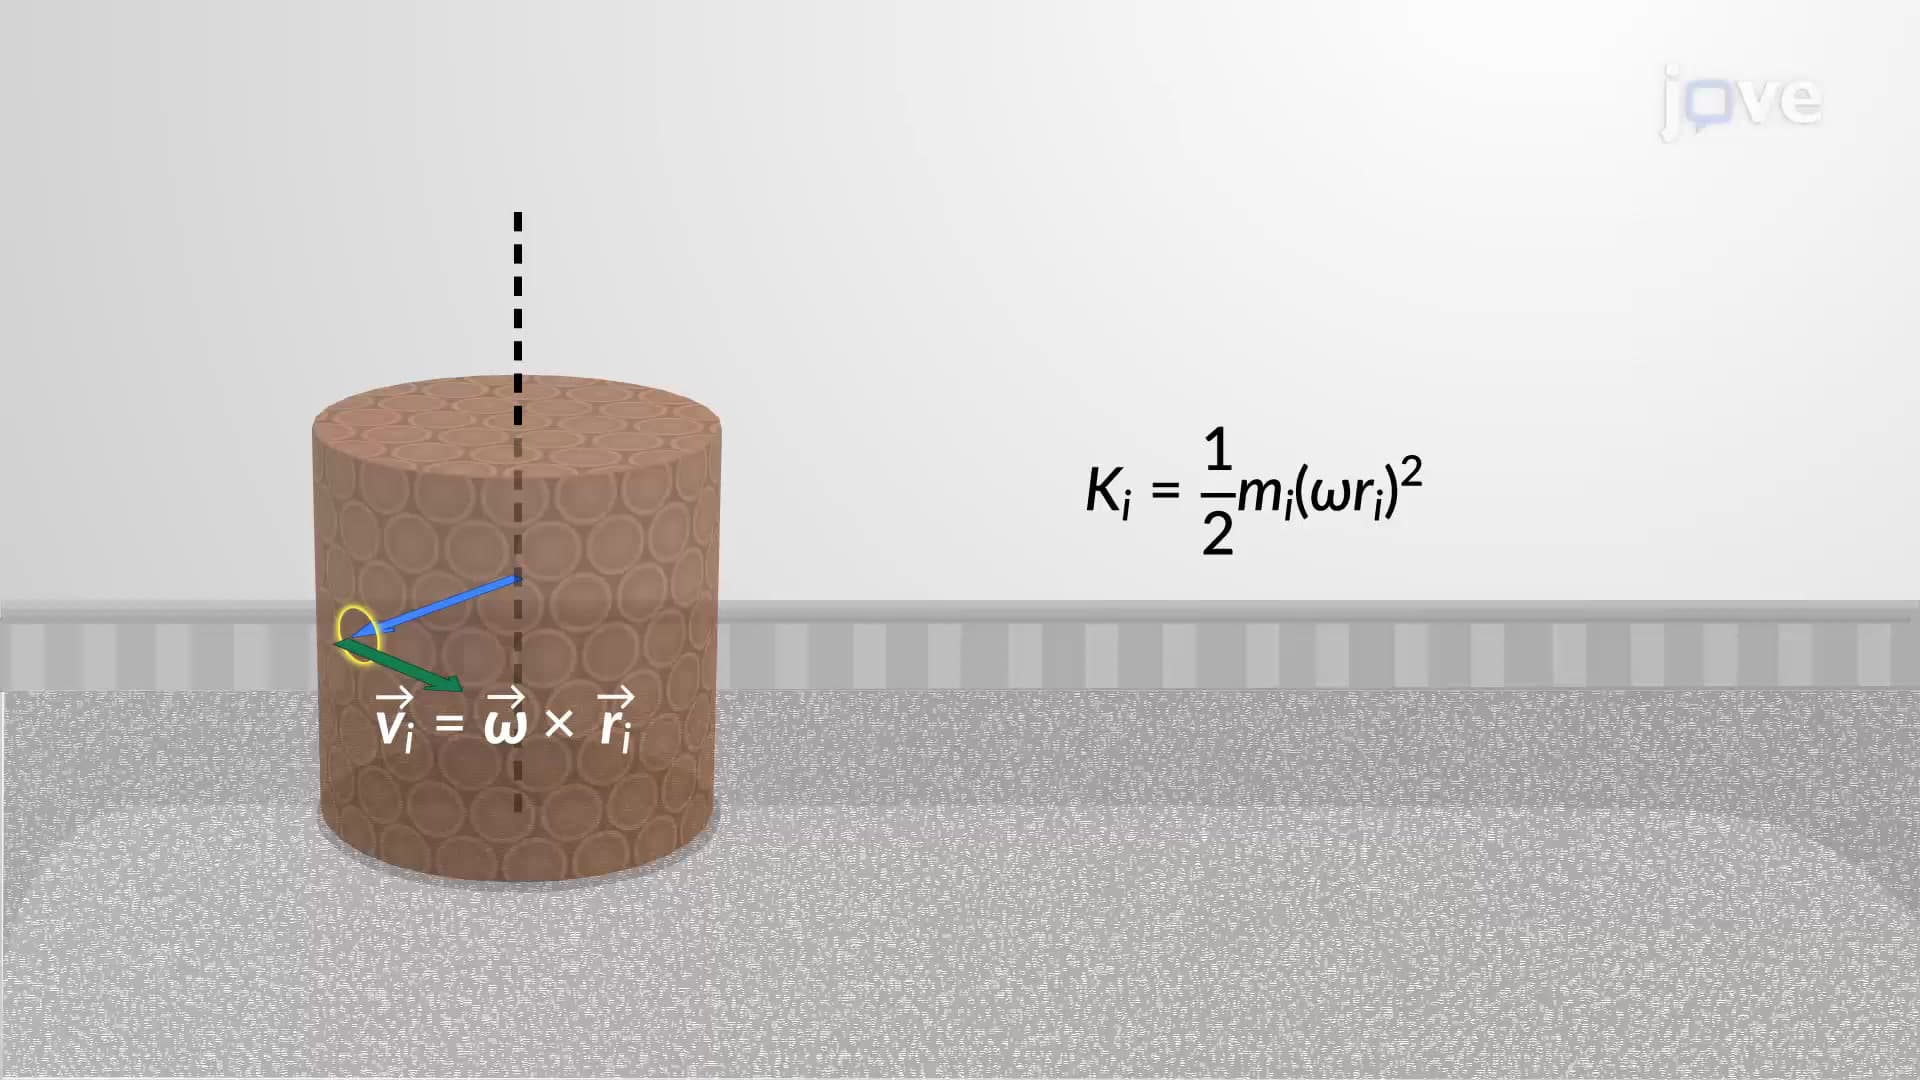
If a rigid body is rotating about an axis but is not in translational motion, its translational kinetic energy is zero. However, since each particle undergoes rotational motion, it possesses non-zero velocity and kinetic energy. Thus, the kinetic energy of the rigid body, which is the sum of the...