Instantaneous postural stability characterization using time-frequency analysis
Related Experiment Video
Updated: Oct 19, 2026
Postural Organization of Gait Initiation for Biomechanical Analysis Using Force Platform Recordings
Published on: July 26, 2022
M Ferdjallah1, G F Harris, J J Wertsch
1Orthopaedic and Rehabilitation Engineering Center (OREC), Marquette University, 1515 W. Wisconsin Ave., Box 25, Milwaukee 53203, USA.

Abstract:
Postural stability assessment is critical to a more accurate understanding of sway and balance control. The center of pressure (COP) metric has been shown to be a suitable output measure for time and frequency analysis. However, the center of pressure is a non-stationary signal. Standard time and frequency analysis methods may not be adequate for monitoring the dynamic changes in the center of pressure signal. In this study a time-frequency method, based on data-adaptive evolutionary spectral estimation, is applied to monitor the dynamic changes of the center of pressure in a non-stationary environment. Metrics including the instantaneous mean frequency (IMF), instantaneous spectral bandwidth (ISB), and instantaneous average power (IAP) are analyzed to characterize the center of pressure signal in both the anterior-posterior (AP) and the medial-lateral (ML) planes. Within the confines of this study, the IMF was found to be inversely proportional to IAP. The inverse proportionality factors were calculated in both eyes-open and eyes-closed trials during upright quiet standing. These findings suggest that the time-frequency analysis provides instantaneous metrics which describe the amplitude changes and frequency shift of the center of pressure under a variety of environmental conditions, thus providing a more reliable quantification of postural control.
Related Concept Videos
 01:28
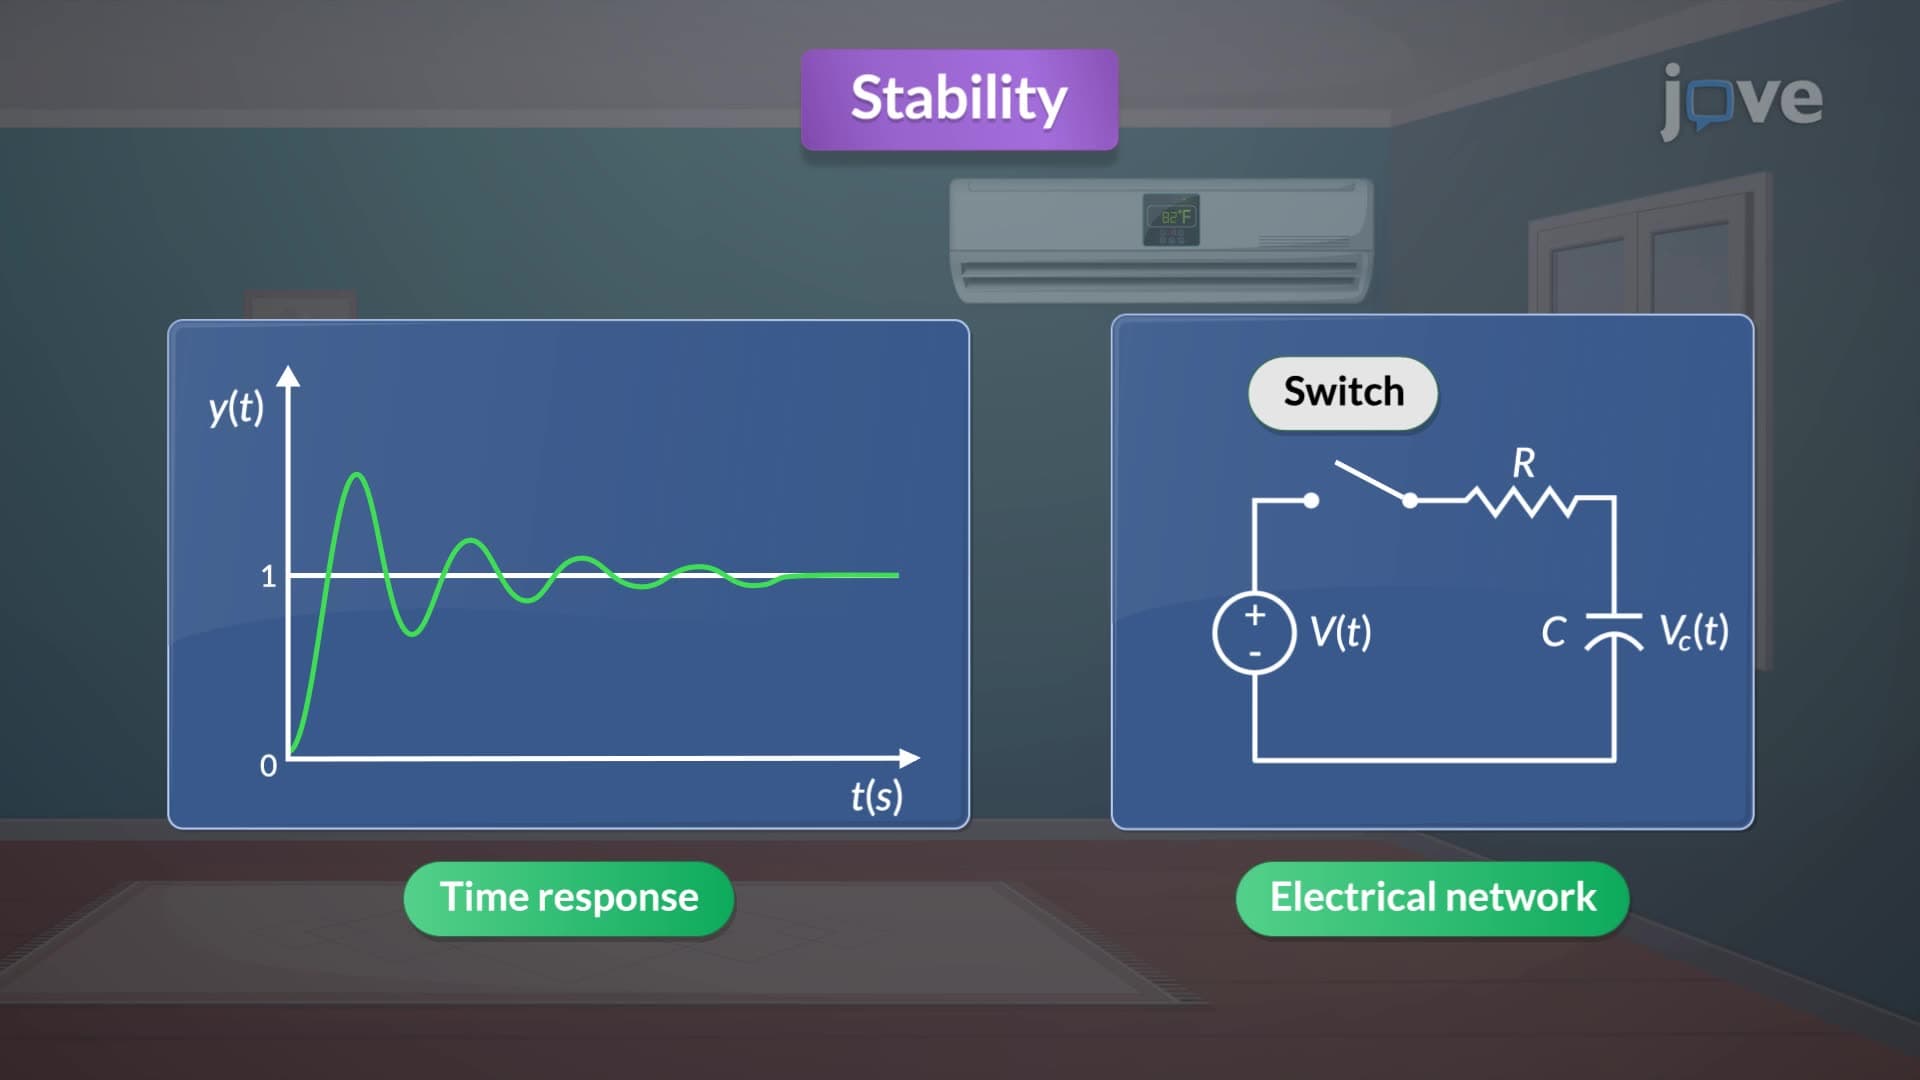
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:24
Time and frequency -Domain Interpretation of Phase-lead Control
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any finite,...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:15
Discrete Fourier Transform
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's response.