The visual representation of three-dimensional, rotating objects
Related Experiment Video
Updated: Oct 19, 2026

Three-Dimensional Mapping of the Rotation of Interactive Virtual Objects with Eye-Tracking Data
Published on: October 18, 2024
1Department of Psychology, Rutgers University, Newark, USA. zoe@psyche.mit.edu

Abstract:
Depth rotations can reveal new object parts and result in poor recognition of "static" objects (Biederman & Gerhardstein, 1993). Recent studies have suggested that multiple object views can be associated through temporal contiguity and similarity (Edelman & Weinshall, 1991; Lawson, Humphreys & Watson, 1994; Wallis, 1996). Motion may also play an important role in object recognition since observers recognize novel views of objects rotating in the picture plane more readily than novel views of statically re-oriented objects (Kourtzi & Shiffrar, 1997). The series of experiments presented here investigated how different views of a depth-rotated object might be linked together even when these views do not share the same parts. The results suggest that depth rotated object views can be linked more readily with motion than with temporal sequence alone to yield priming of novel views of 3D objects that fall in between "known" views. Motion can also enhance path specific view linkage when visible object parts differ across views. Such results suggest that object representations depend on motion processes.
Related Concept Videos
 01:28
Cylinders in Three-Dimensional Space
 01:26
Rotational Motion about a Fixed Axis
 01:30
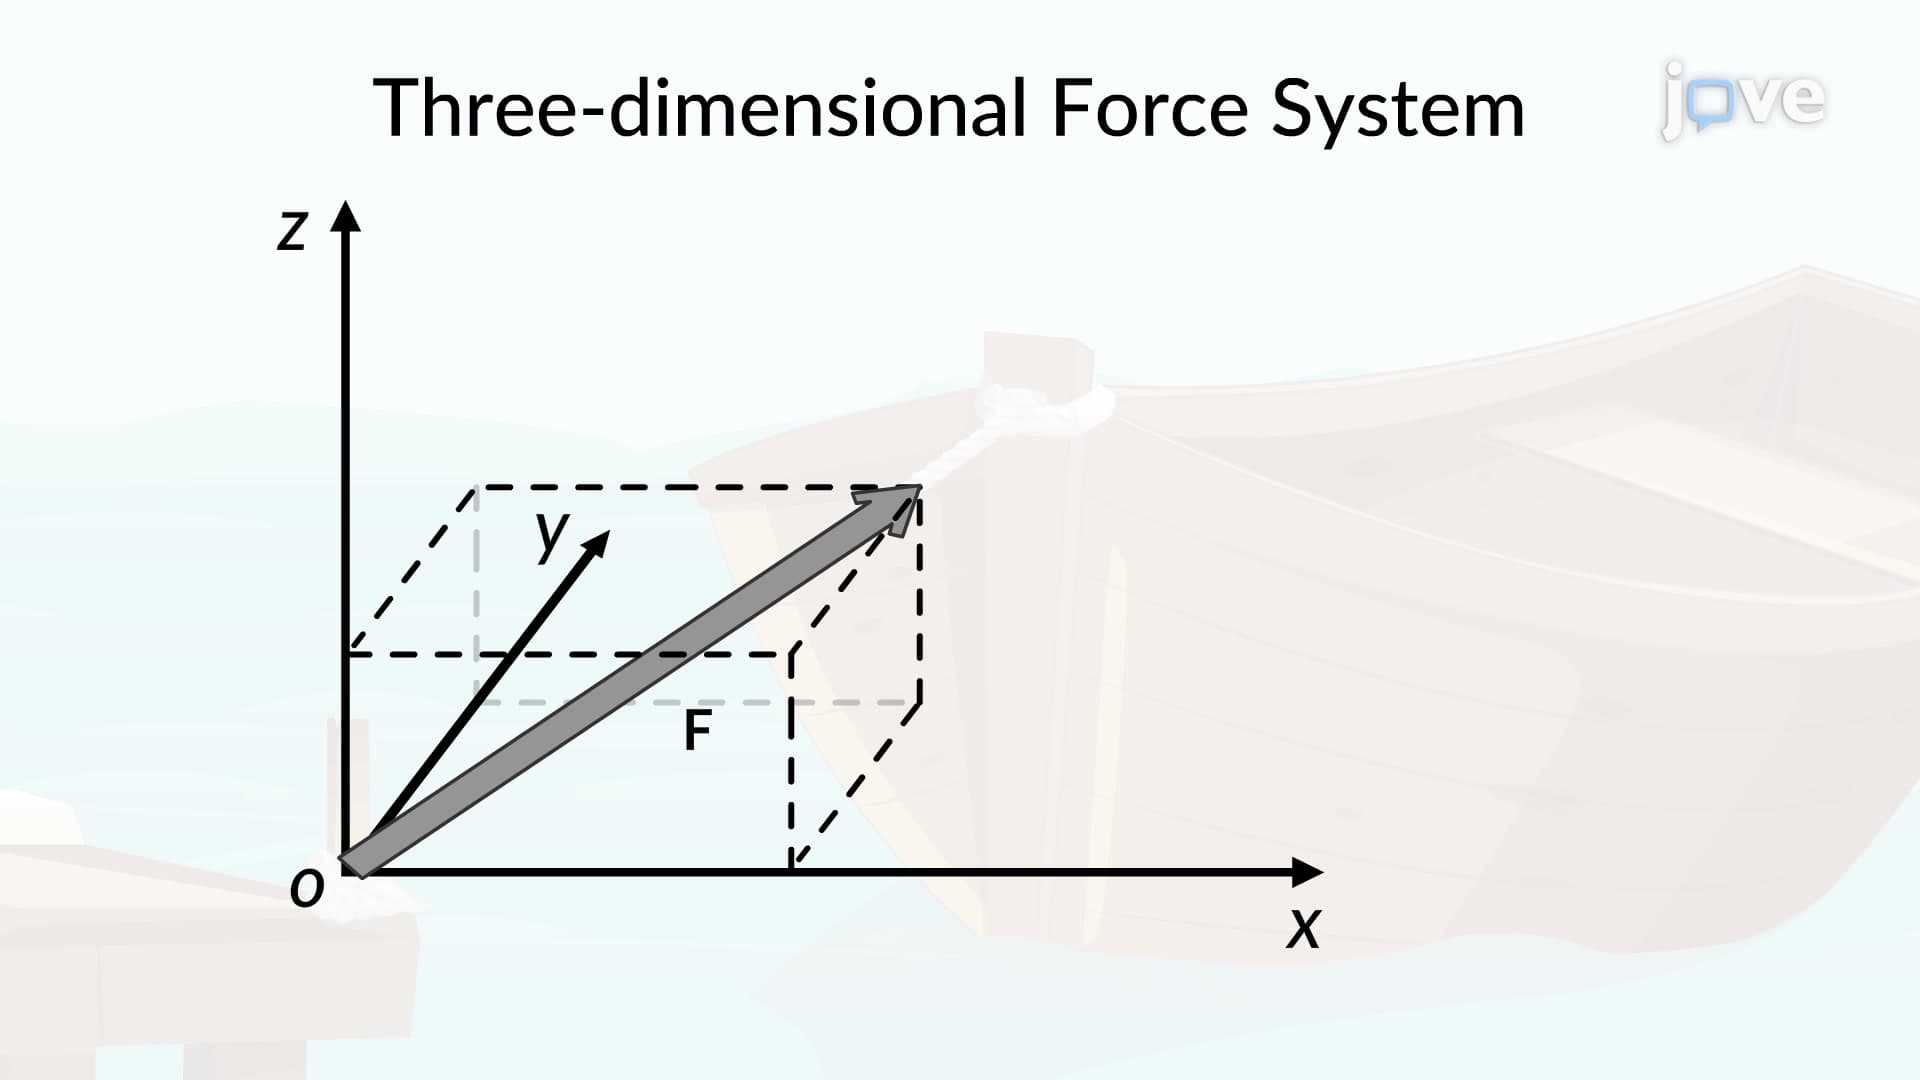
Three-Dimensional Force System
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
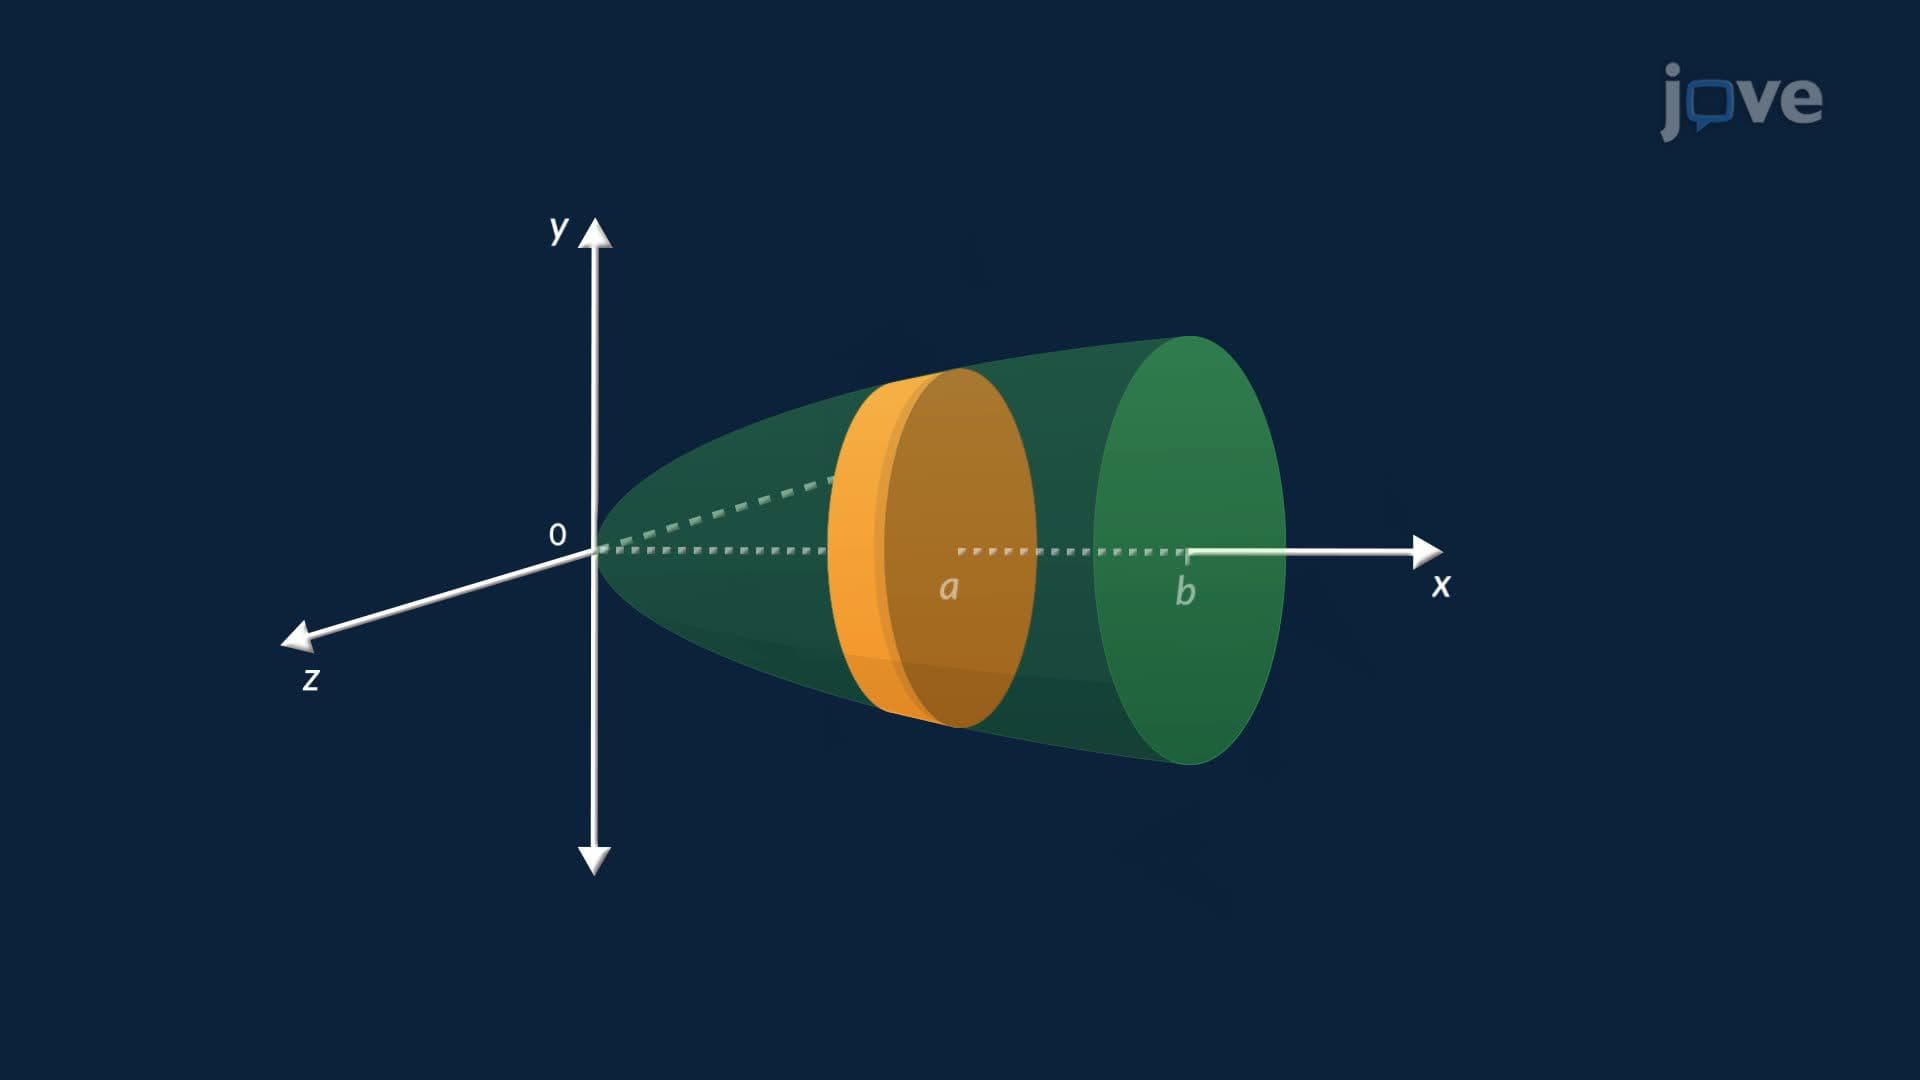
Volumes of Solids of Revolution
 01:11
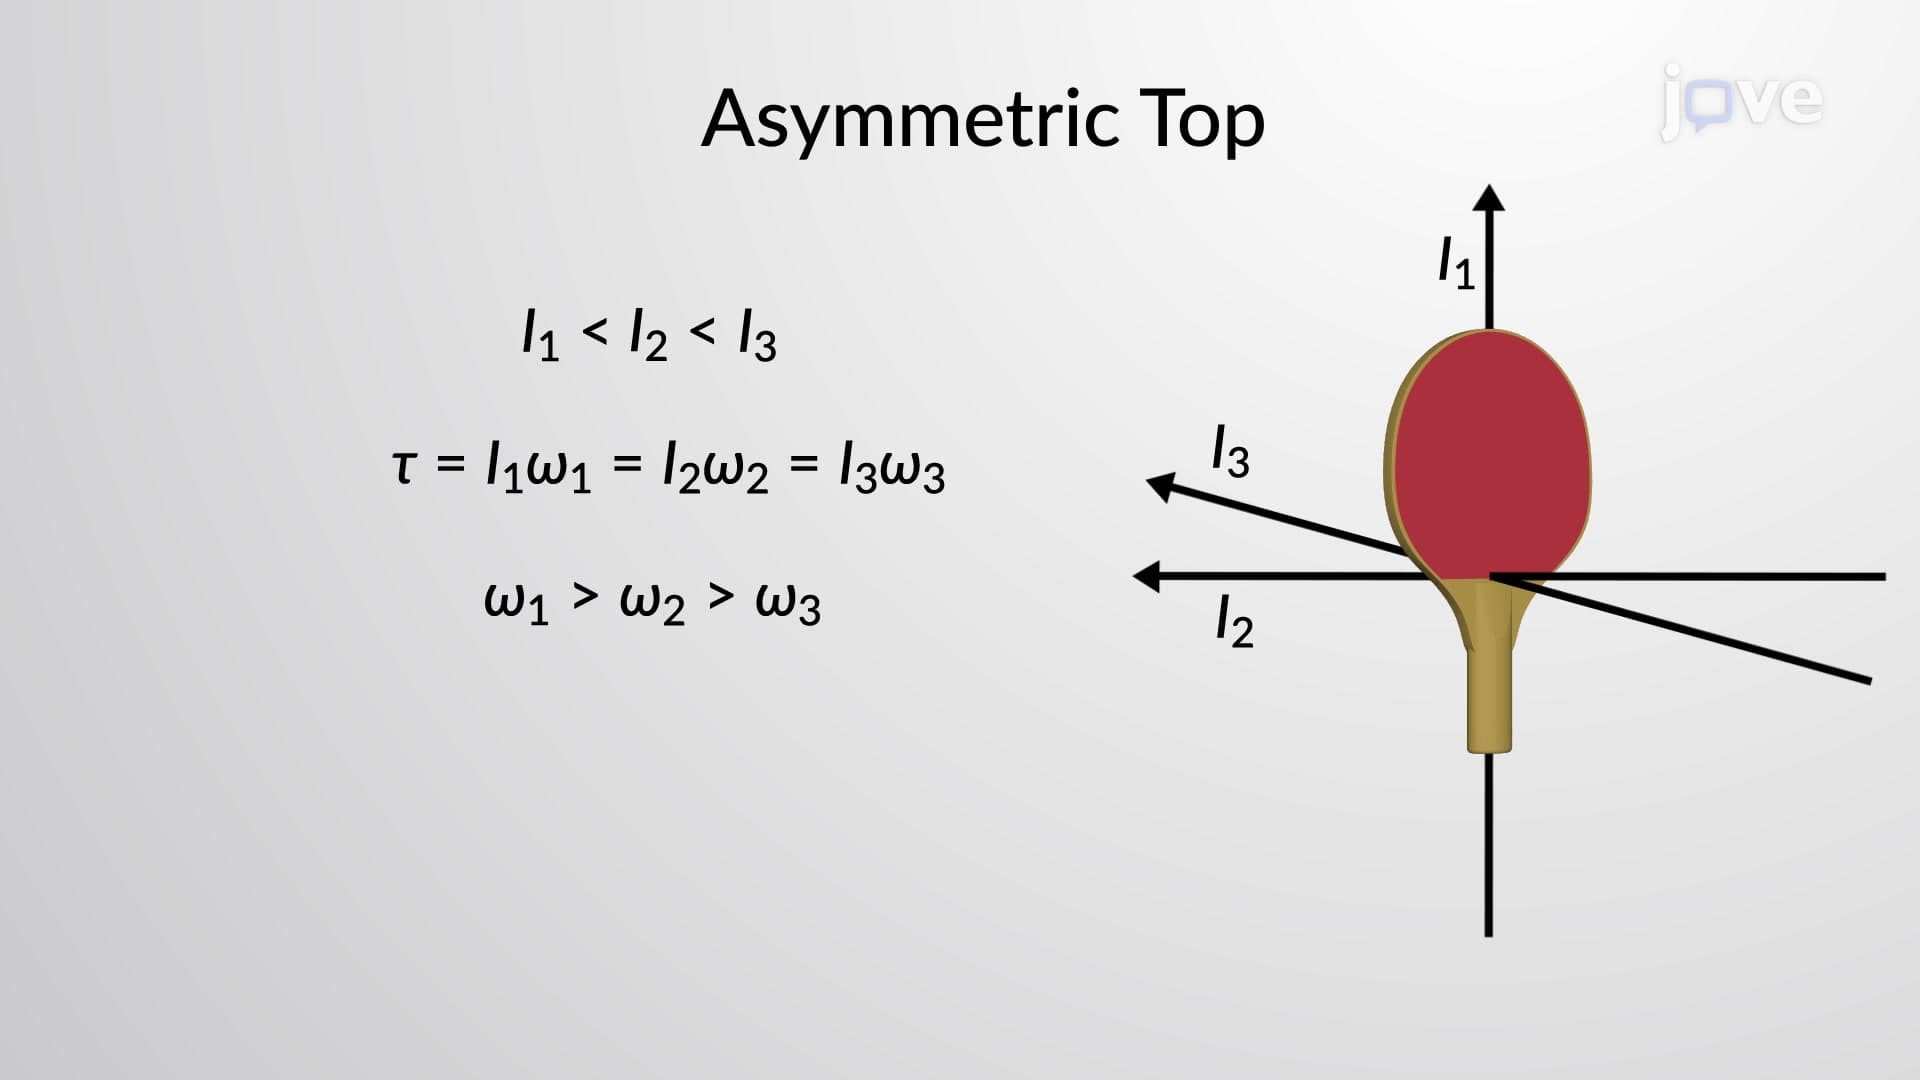
Rotation of Asymmetric Top
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...