Estimation of self-turning in the dark: comparison between active and passive rotation
Related Experiment Video
Updated: Oct 18, 2026
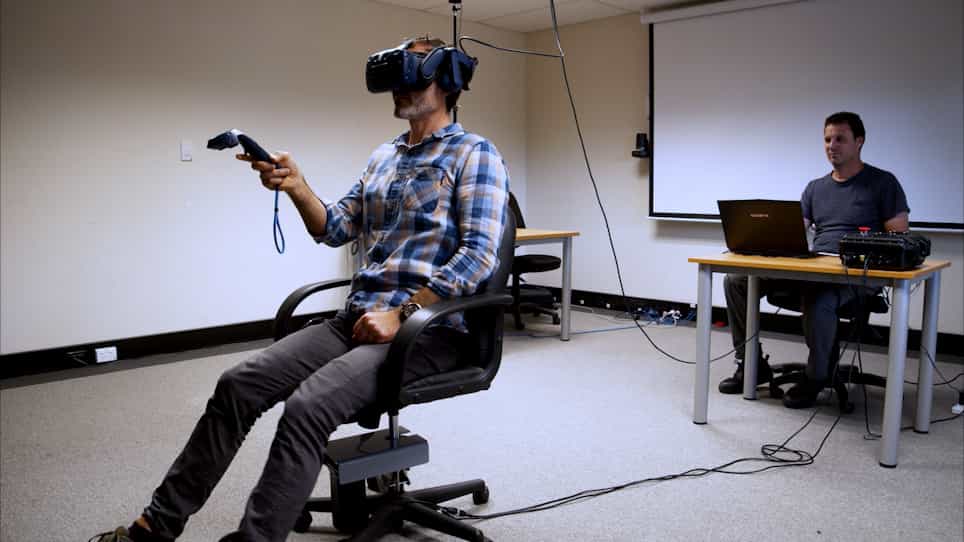
Controlled Rotation of Human Observers in a Virtual Reality Environment
Published on: April 21, 2022
1Sektion Neurophysiologie, Universität Ulm, Albert-Einstein-Allee 47, D-89081 Ulm, Germany.

Abstract:
The present work compares passive and active rotations in darkness with the aim of characterizing the contribution of efferent and proprioceptive information to the perception of angular displacement. The perception of angular displacements was measured in 12 naive subjects (Ss), who either stood on a rotating platform (passive mode, P) or actively turned about their vertical axis by stepping around "on the spot" on a stationary platform (active mode, A). Rotations consisted of short acceleration epochs followed by constant velocity periods of 18.5, 37, and 55 degrees /s, with angular displacements ranging from 30 degrees to 810 degrees (presented in a randomized order); in the case of active turning, Ss had learned to approximately produce any of these three velocity levels on command. Ss indicated perceived displacement either verbally (verbal estimation mode, E), or by stopping their rotation when self-displacement appeared to match the magnitude specified by the experimenter (targeting, T). The resulting four conditions (PE, PT, AE, AT) were administered blockwise. In none of the four conditions was there a systematic dependence of perception on turning velocity. Therefore, the results were pooled across velocities, and the Ss' performance was summarized in the form of estimation curves showing median estimates as a function of physical displacement. There were several differences between the passive and active modes: AE- and AT-estimation curves were linear, close to veracity, and fairly similar to each other. In contrast, the PE-curve was curved rightwardly ("saturation"), with small displacements being overestimated and large ones underestimated, whereas the PT-curve was linear and indicated a pronounced overestimation of large displacements. Moreover, both the random and the systematic errors (measures of individual consistency and correctness of individual calibration, respectively) were significantly smaller in the active than in the passive modes. The observed independence of Ss' perception from turning velocity also during passive rotation suggests that the perceptual time constant was significantly longer than 16 s (a value cited as typical for vestibular perception), being possibly "enhanced" by contextual implications and by expectations of the Ss. The clear improvement of perceptual performance in the active mode testifies to the importance of the efferent and proprioceptive signals arising during active motion. On the assumption that these signals are about as "noisy" as the vestibular ones, the smaller errors during active turning could result from their combination with the vestibular signal. Alternatively, they could also be intrinsically less noisy than the vestibular signal and simply replace the latter during active motion. In the context of these alternatives (which are not exhaustive), the general problem of sensory fusion is discussed, that is, by which mechanisms are signals from different sensory sources combined to obtain a unified representation of the self's orientation.
Related Concept Videos
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:26
Rotational Motion about a Fixed Axis
 01:18
Equation of Motion: Rotation About a Fixed Axis
The tangential component is dependent on the direction of the angular acceleration of the flywheel. The tangential component of the acceleration propels the flywheel along its path. On the other hand,...
 01:16
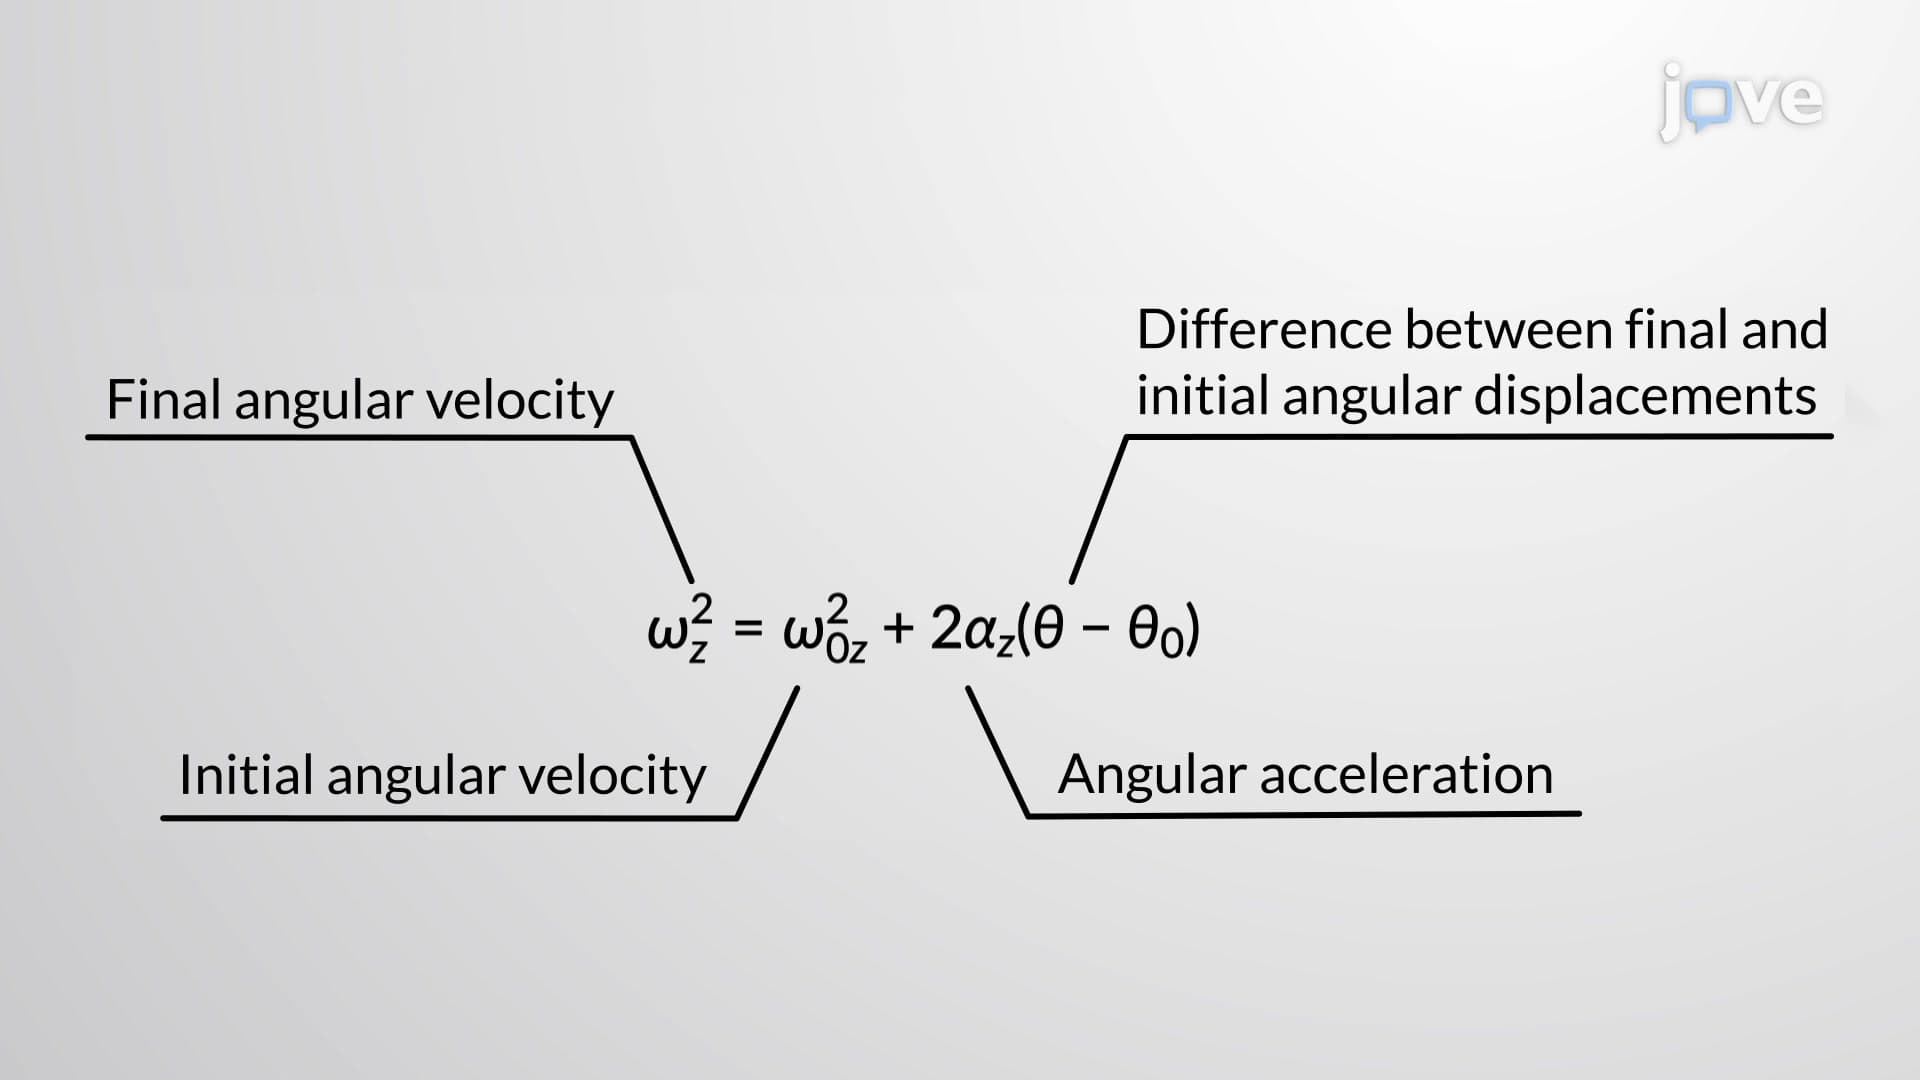
Rotation with Constant Angular Acceleration - II
The first...
 01:37
Rotation with Constant Angular Acceleration - I
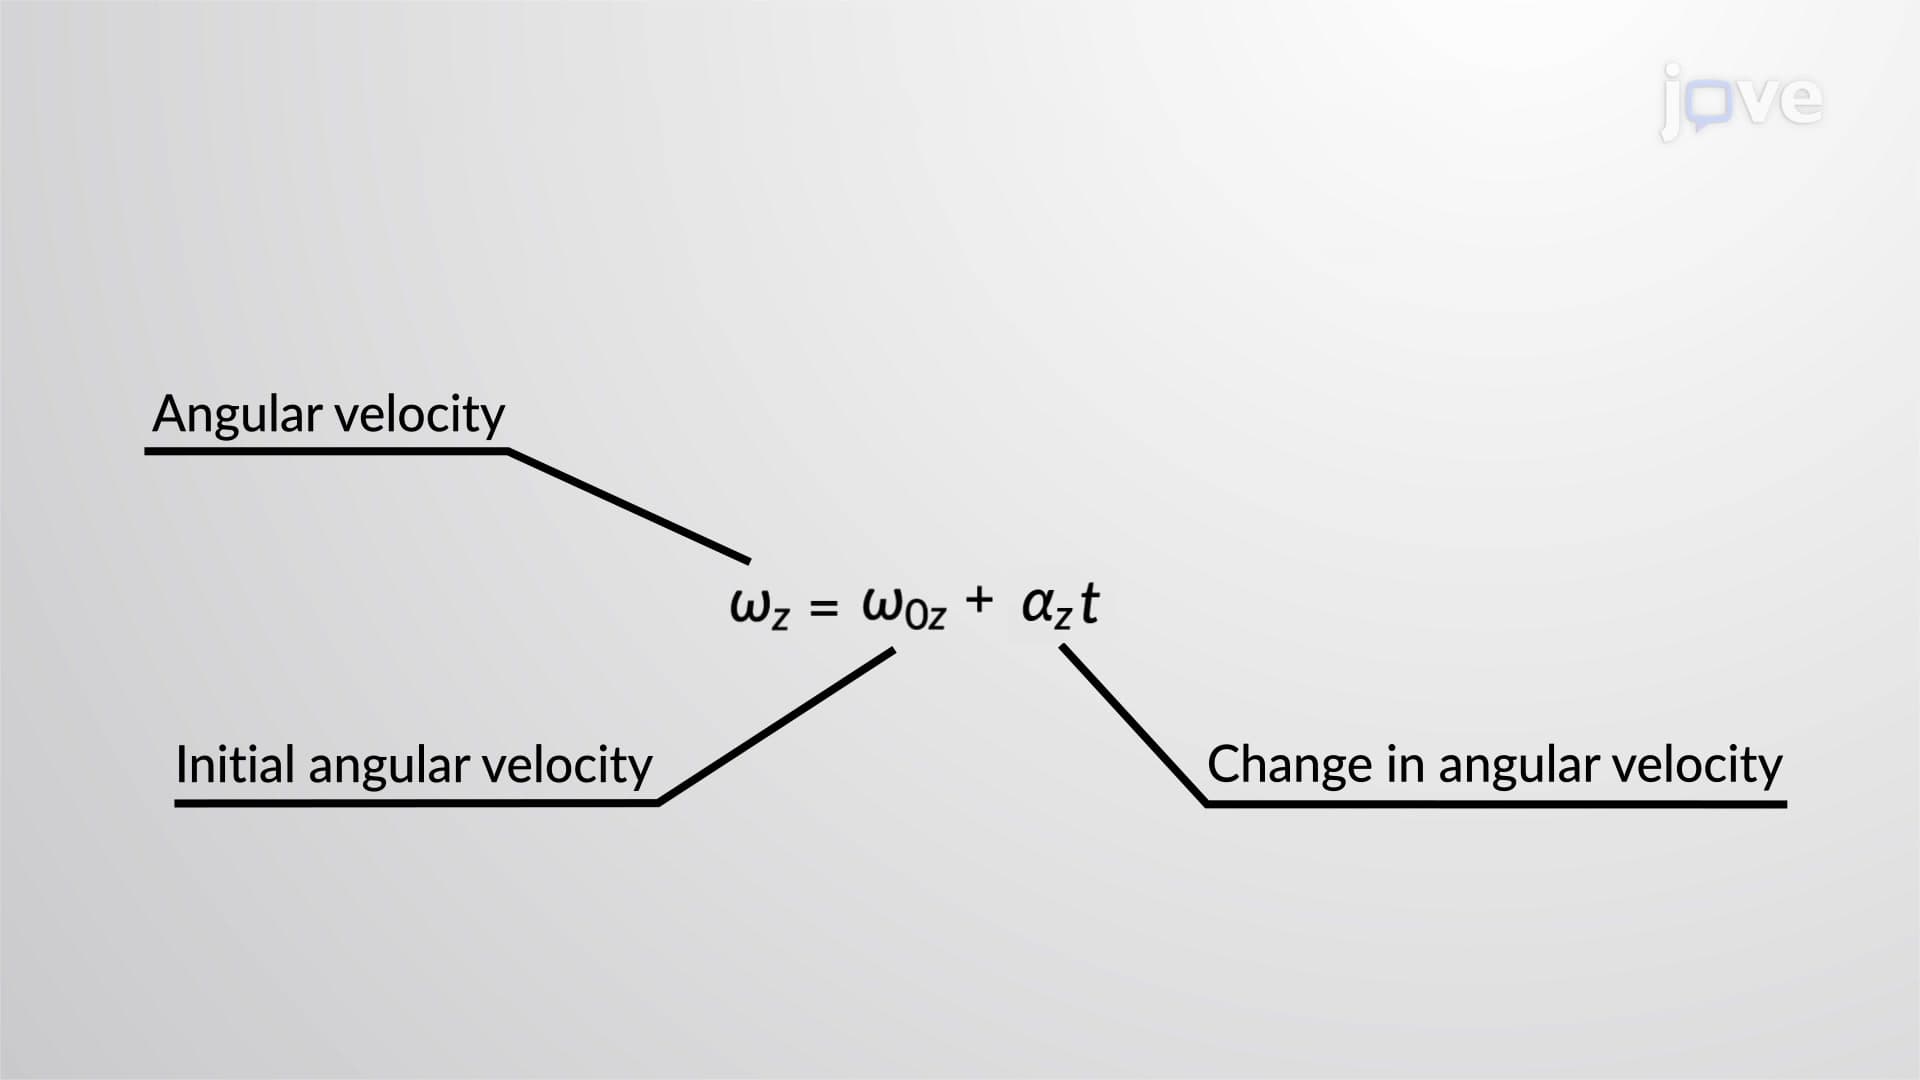
Using our intuition, we can begin to see how rotational quantities such as angular displacement, angular velocity, angular acceleration, and time are related to one another. For example, if a flywheel...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...