Neural networks learning with sliding mode control: the sliding mode backpropagation algorithm
Related Experiment Videos
G G Parma1, B R de Menezes, A P Braga
1PARMA@CPDEE.UFMG.BR

Abstract:
Based on the classical backpropagation weight update equations, sliding mode control theory is introduced as a technique to adapt weights of a multi-layer perceptron. As will be demonstrated, the introduction of sliding mode has resulted in a much faster version of the standard backpropagation. The results show also that the proposed algorithm presents some important features of sliding mode control, which are robustness and high speed of learning. In addition to that, this paper shows also how control theory can be applied to train neural networks.
Related Concept Videos
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:23
Propagation of Action Potentials
Neurons (nerve cells) have a resting membrane potential, with a slightly negative charge inside compared to outside. This is maintained by ion channels, such as sodium (Na+) and potassium (K+) channels, which control the flow of ions. When a stimulus, like a touch or a signal from another neuron, triggers the neuron, sodium channels open, allowing sodium ions to...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:21
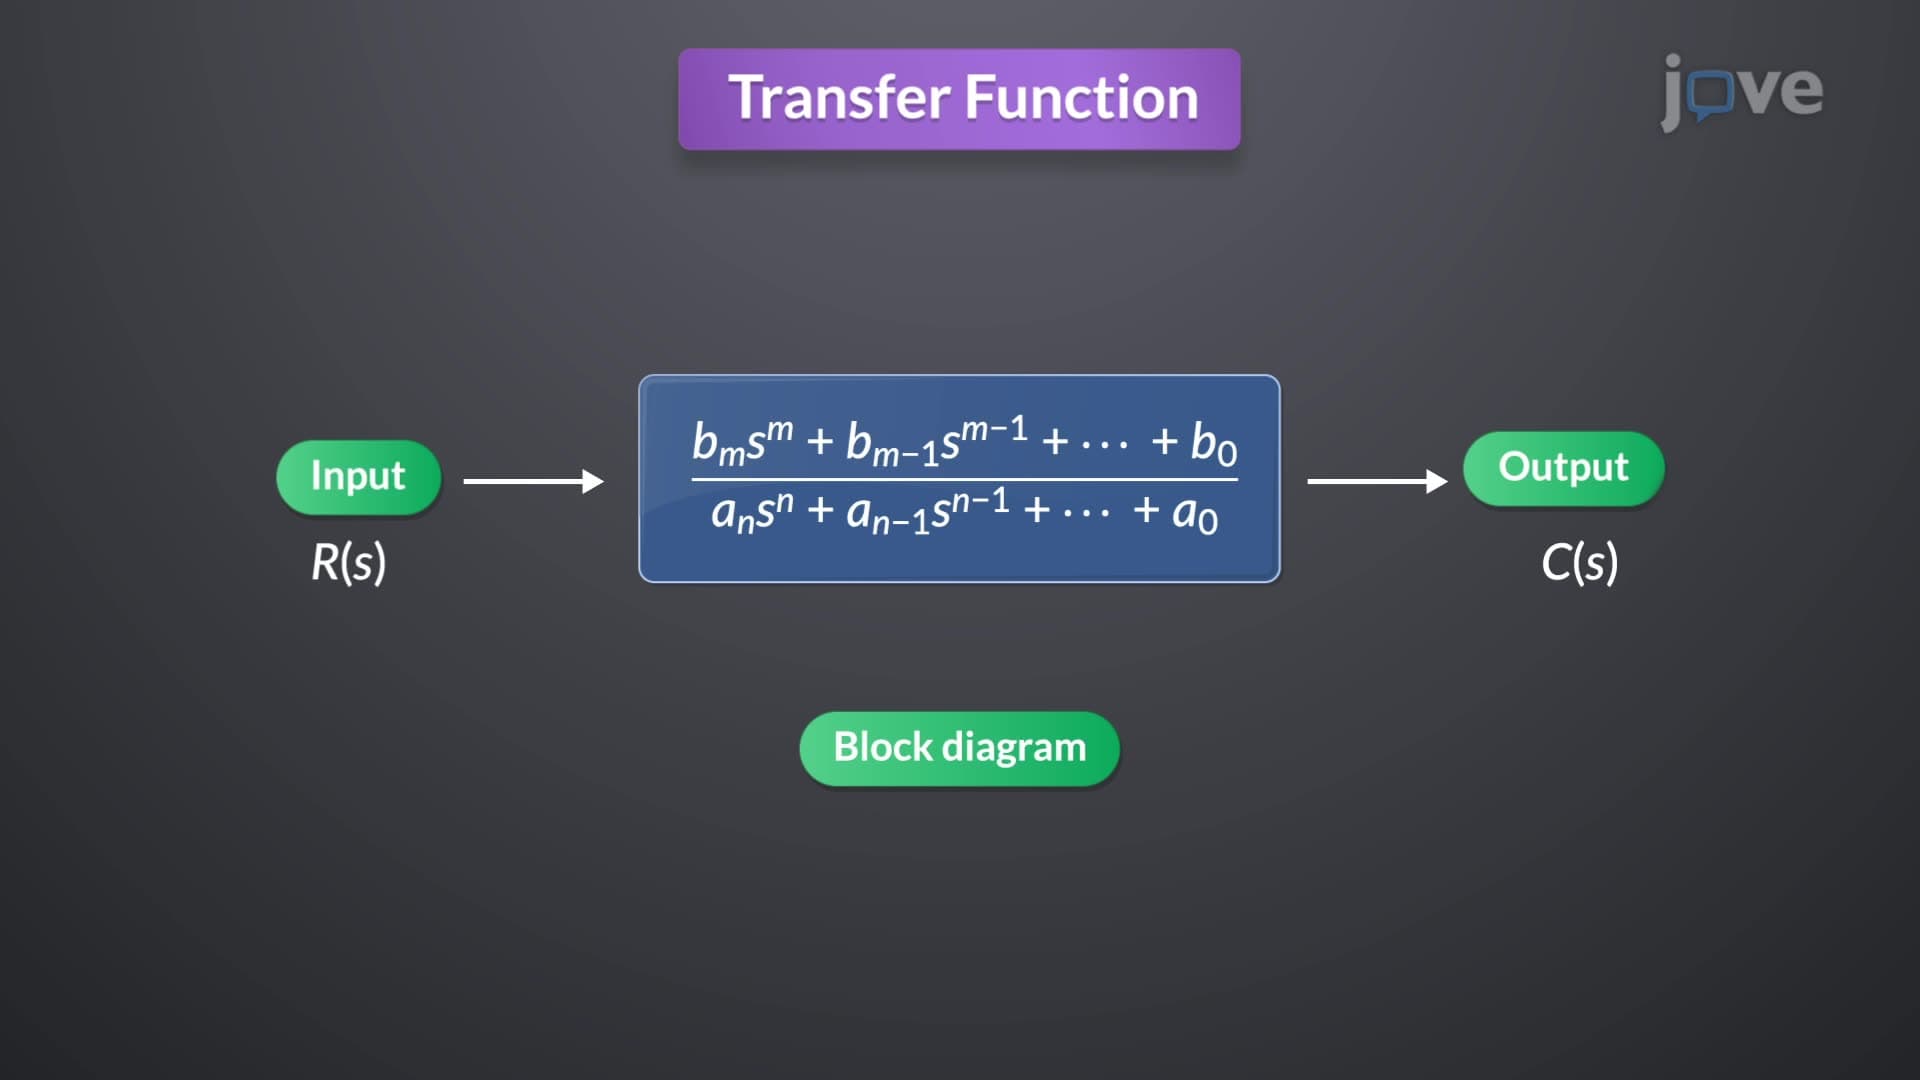
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:14
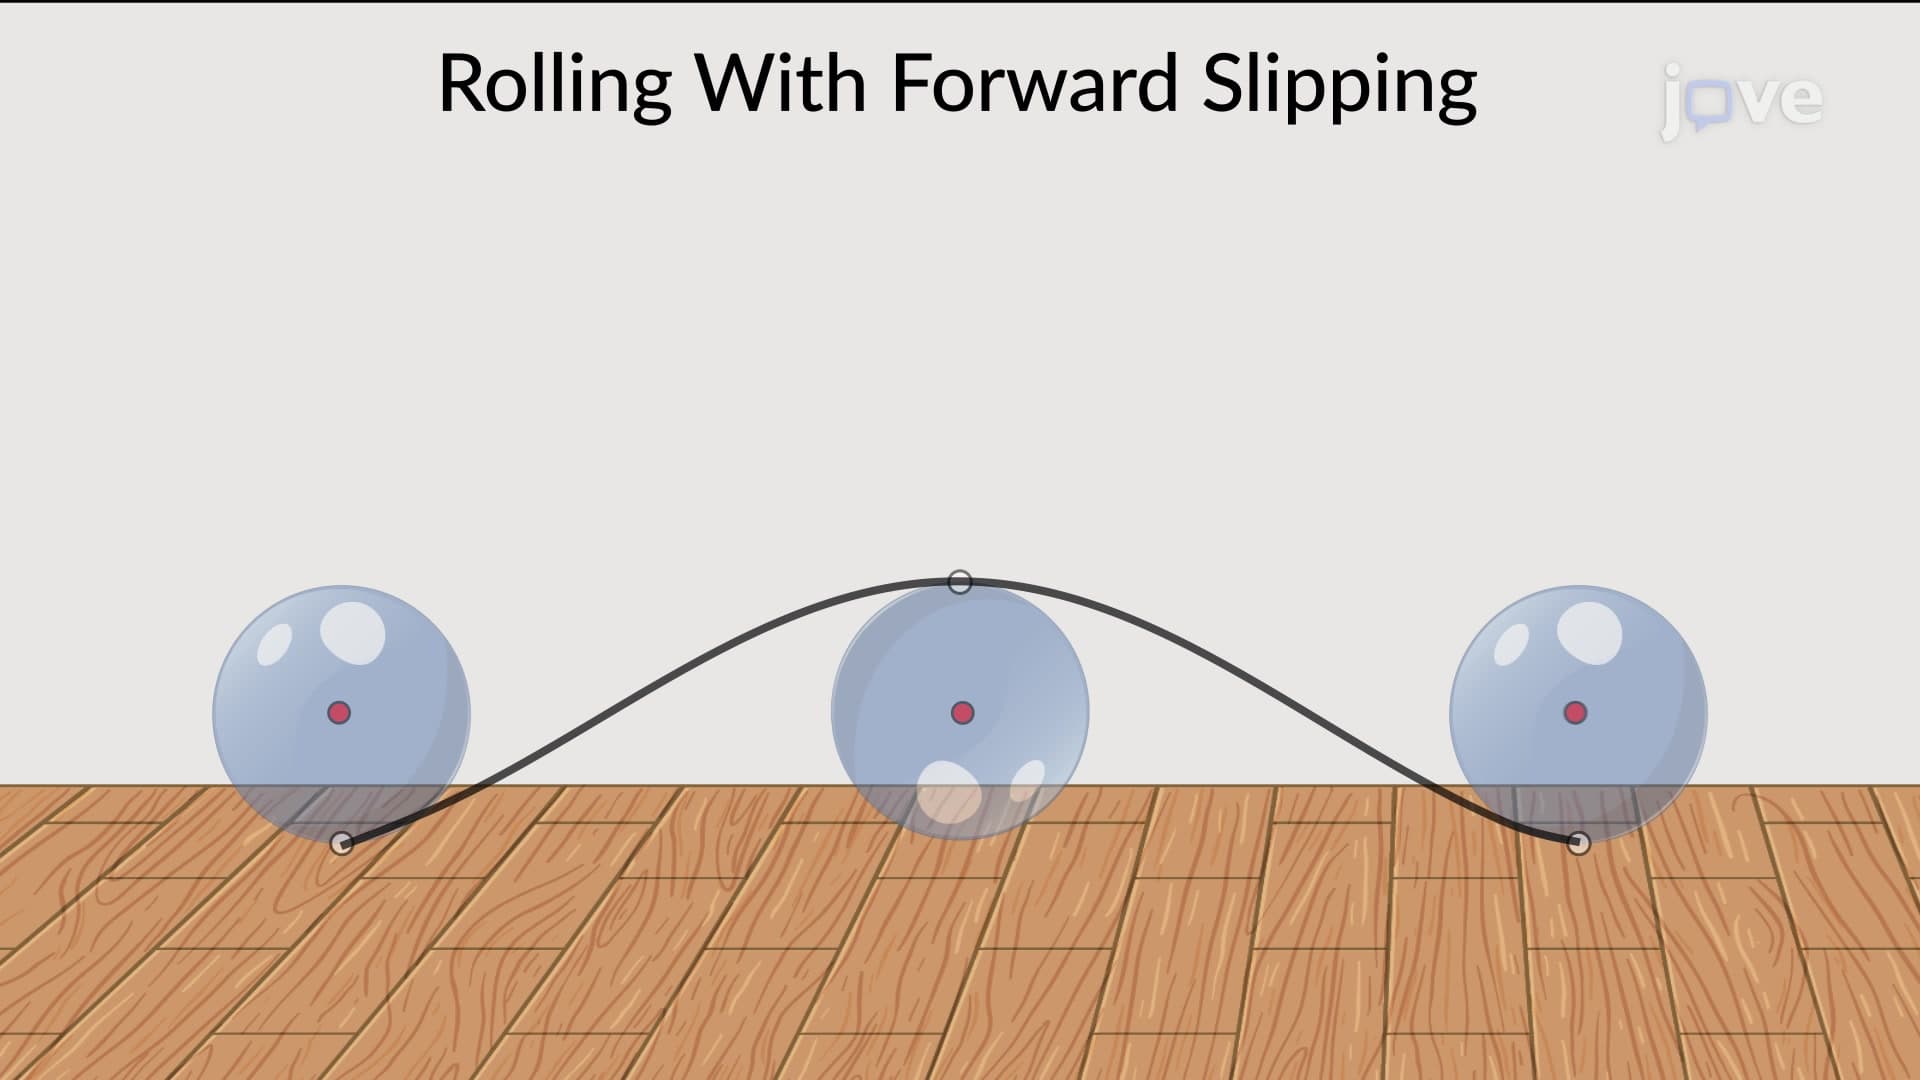
Rolling With Slipping
An object's rolling motion is characterized by its rotation around its axis, while linear motion refers to the object's translational motion along a surface. Frictional forces can affect...