Related Experiment Video
Updated: Oct 18, 2026
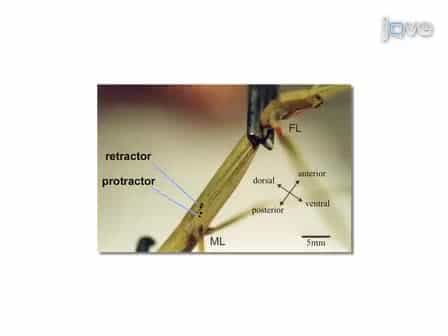
Studying the Neural Basis of Adaptive Locomotor Behavior in Insects
Published on: April 13, 2011
Templates and anchors: neuromechanical hypotheses of legged locomotion on land
1Department of Integrative Biology, University of California Berkeley, Berkeley, CA 94720-3140, USA. rjfull@socrates.berkeley.edu

Abstract:
Locomotion results from complex, high-dimensional, non-linear, dynamically coupled interactions between an organism and its environment. Fortunately, simple models we call templates have been and can be made to resolve the redundancy of multiple legs, joints and muscles by seeking synergies and symmetries. A template is the simplest model (least number of variables and parameters) that exhibits a targeted behavior. For example, diverse species that differ in skeletal type, leg number and posture run in a stable manner like sagittal- and horizontal-plane spring-mass systems. Templates suggest control strategies that can be tested against empirical data. Templates must be grounded in more detailed morphological and physiological models to ask specific questions about multiple legs, the joint torques that actuate them, the recruitment of muscles that produce those torques and the neural networks that activate the ensemble. We term these more elaborate models anchors. They introduce representations of specific biological details whose mechanism of coordination is of interest. Since mechanisms require controls, anchors incorporate specific hypotheses concerning the manner in which unnecessary motion or energy from legs, joints and muscles is removed, leaving behind the behavior of the body in the low-degree-of-freedom template. Locating the origin of control is a challenge because neural and mechanical systems are dynamically coupled and both play a role. The control of slow, variable-frequency locomotion appears to be dominated by the nervous system, whereas during rapid, rhythmic locomotion, the control may reside more within the mechanical system. Anchored templates of many-legged, sprawled-postured animals suggest that passive, dynamic self-stabilization from a feedforward, tuned mechanical system can reject rapid perturbations and simplify control. Future progress would benefit from the creation of a field embracing comparative neuromechanics.
Related Concept Videos
 01:28
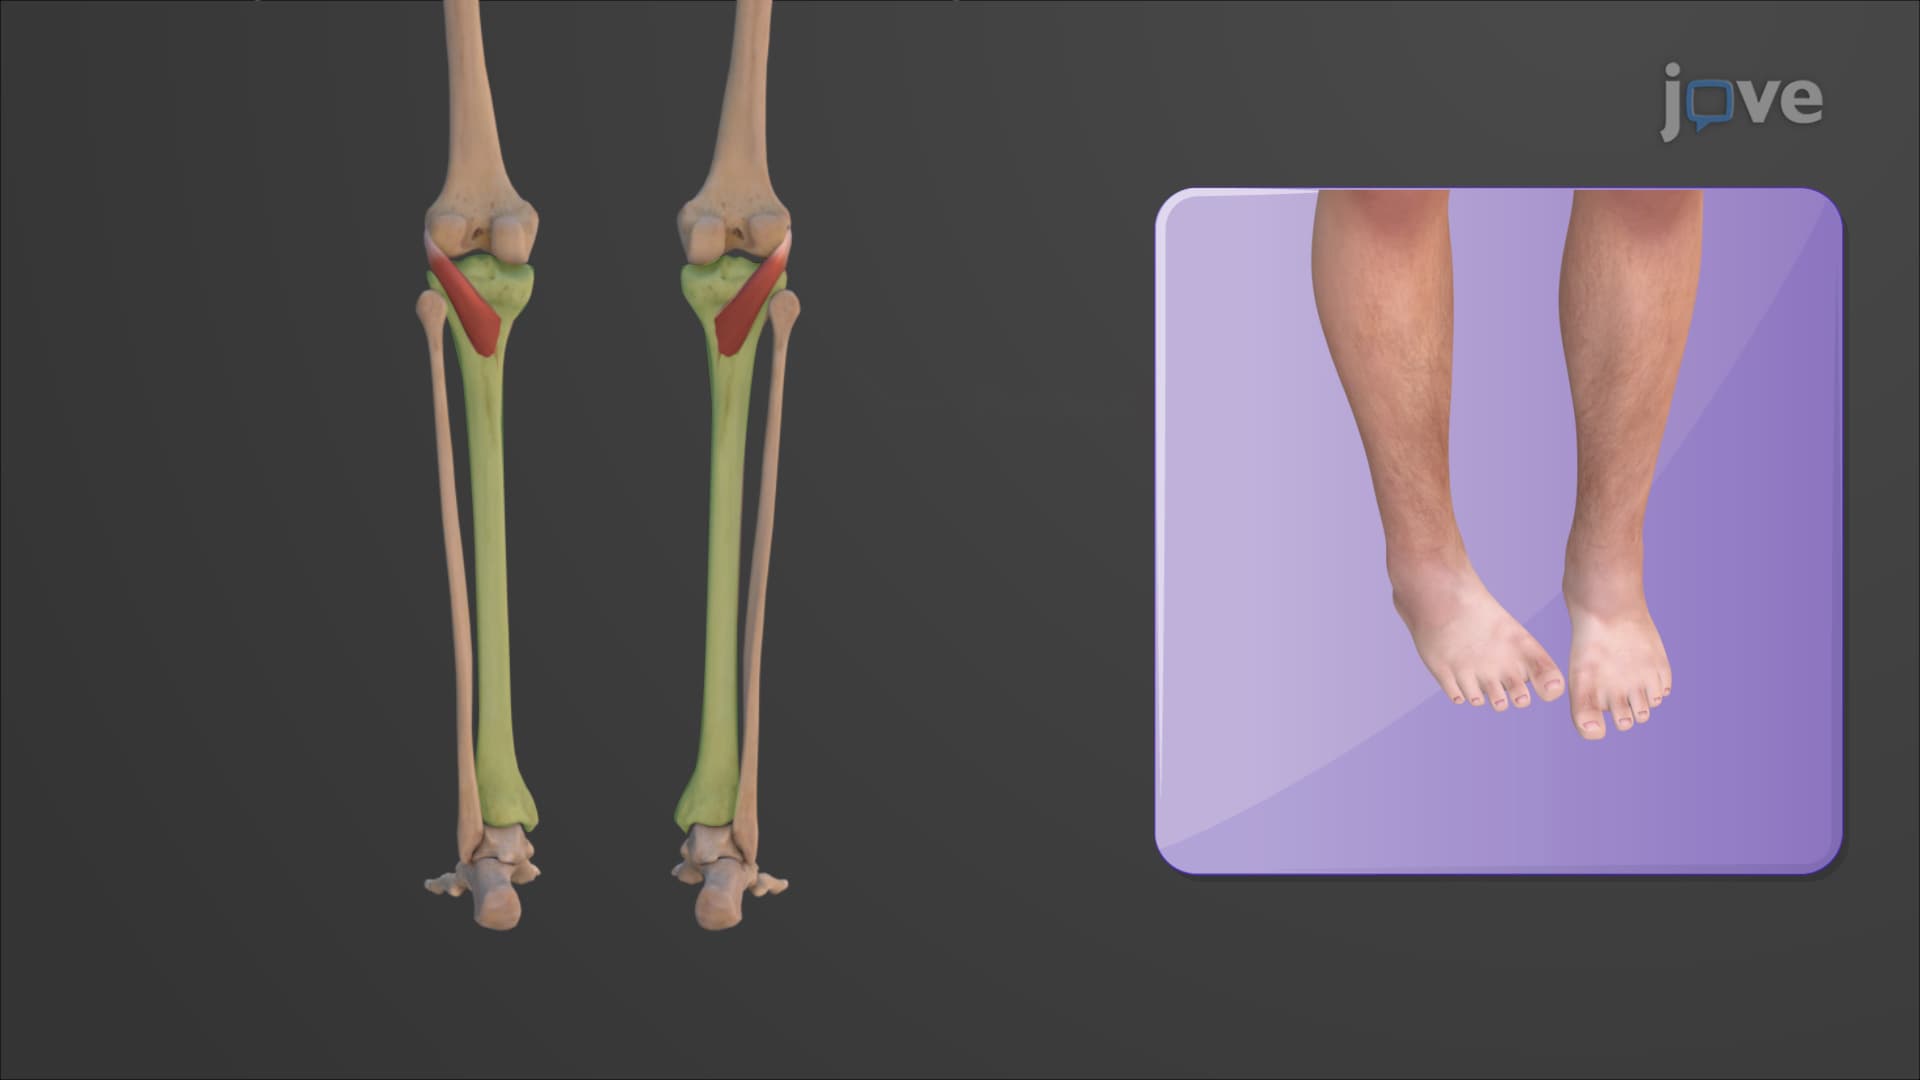
Muscles of the Leg that Move the Foot and Toes
Anterior Compartment
The anterior compartment includes muscles that contribute to the dorsiflexion of the foot. This compartment houses the tibialis anterior, extensor hallucis longus, and extensor digitorum longus muscles.
 01:18
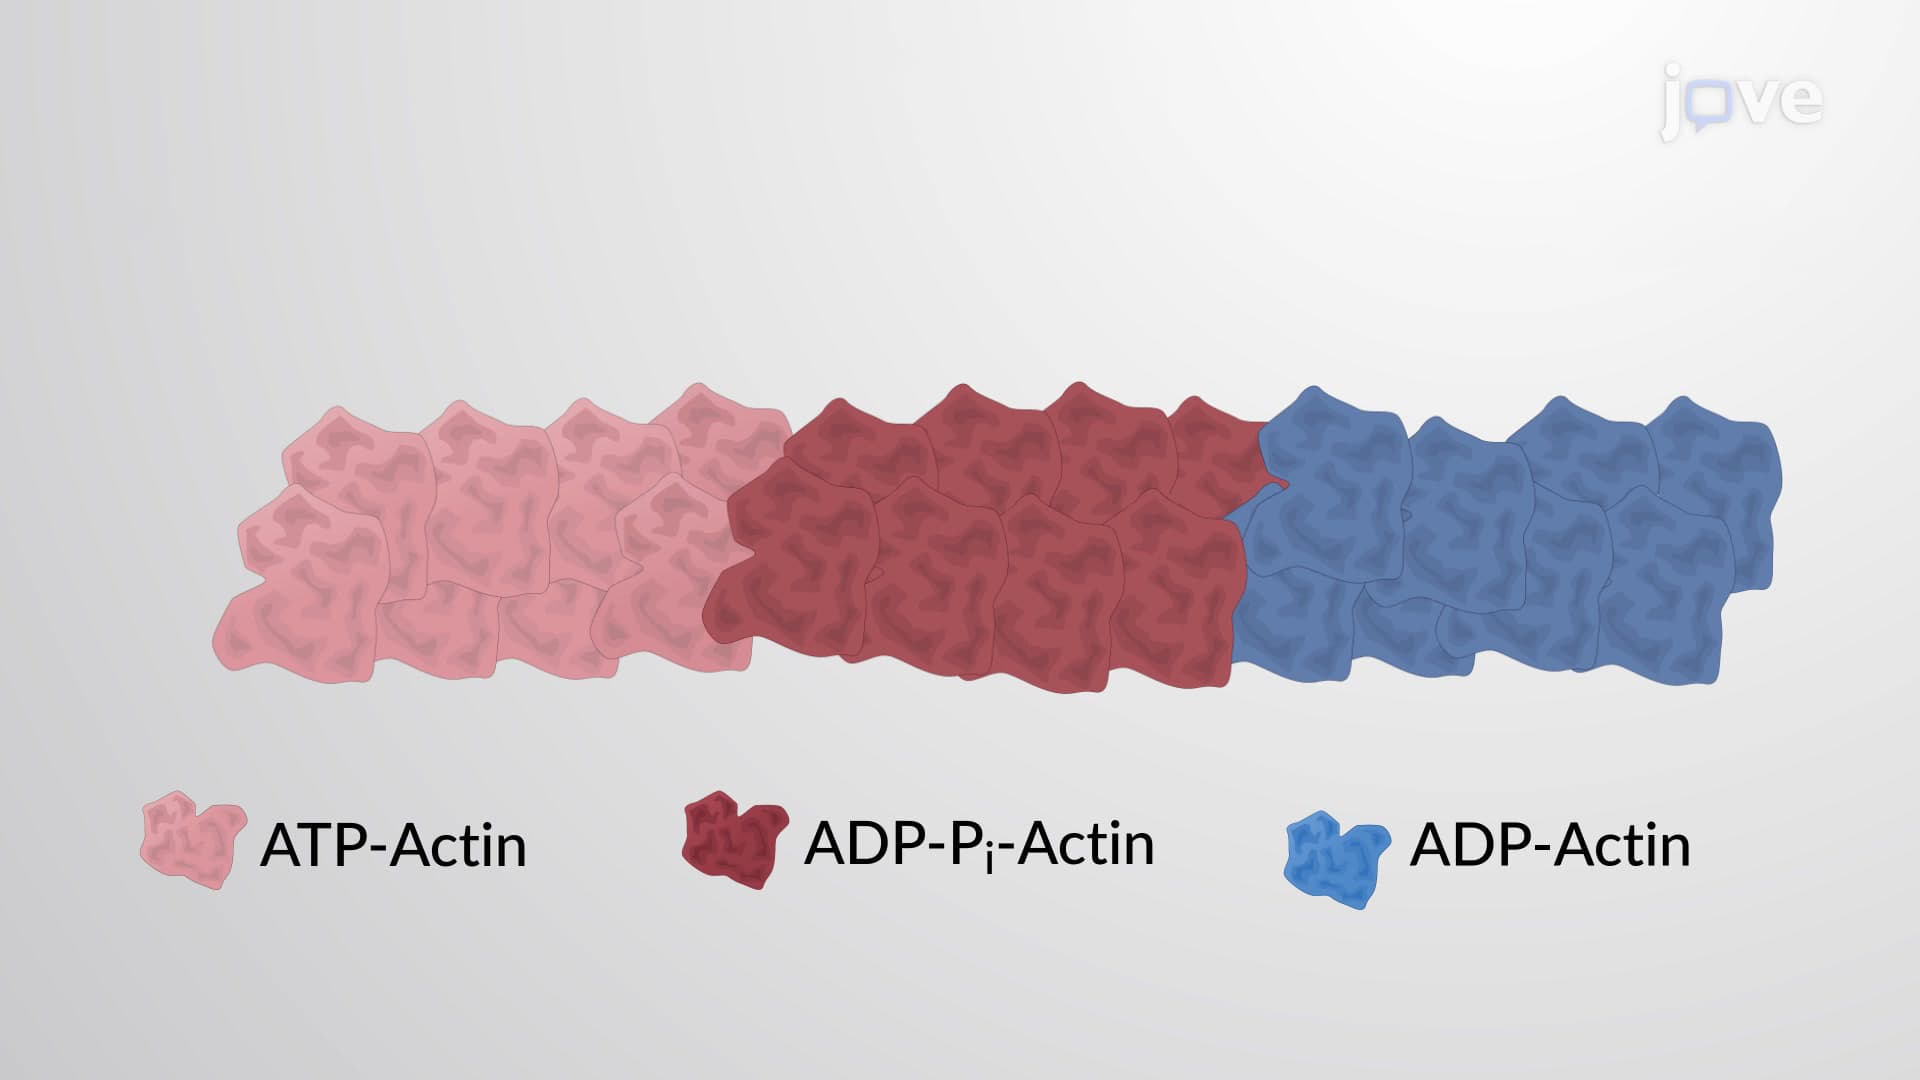
Actin Treadmilling
 01:23
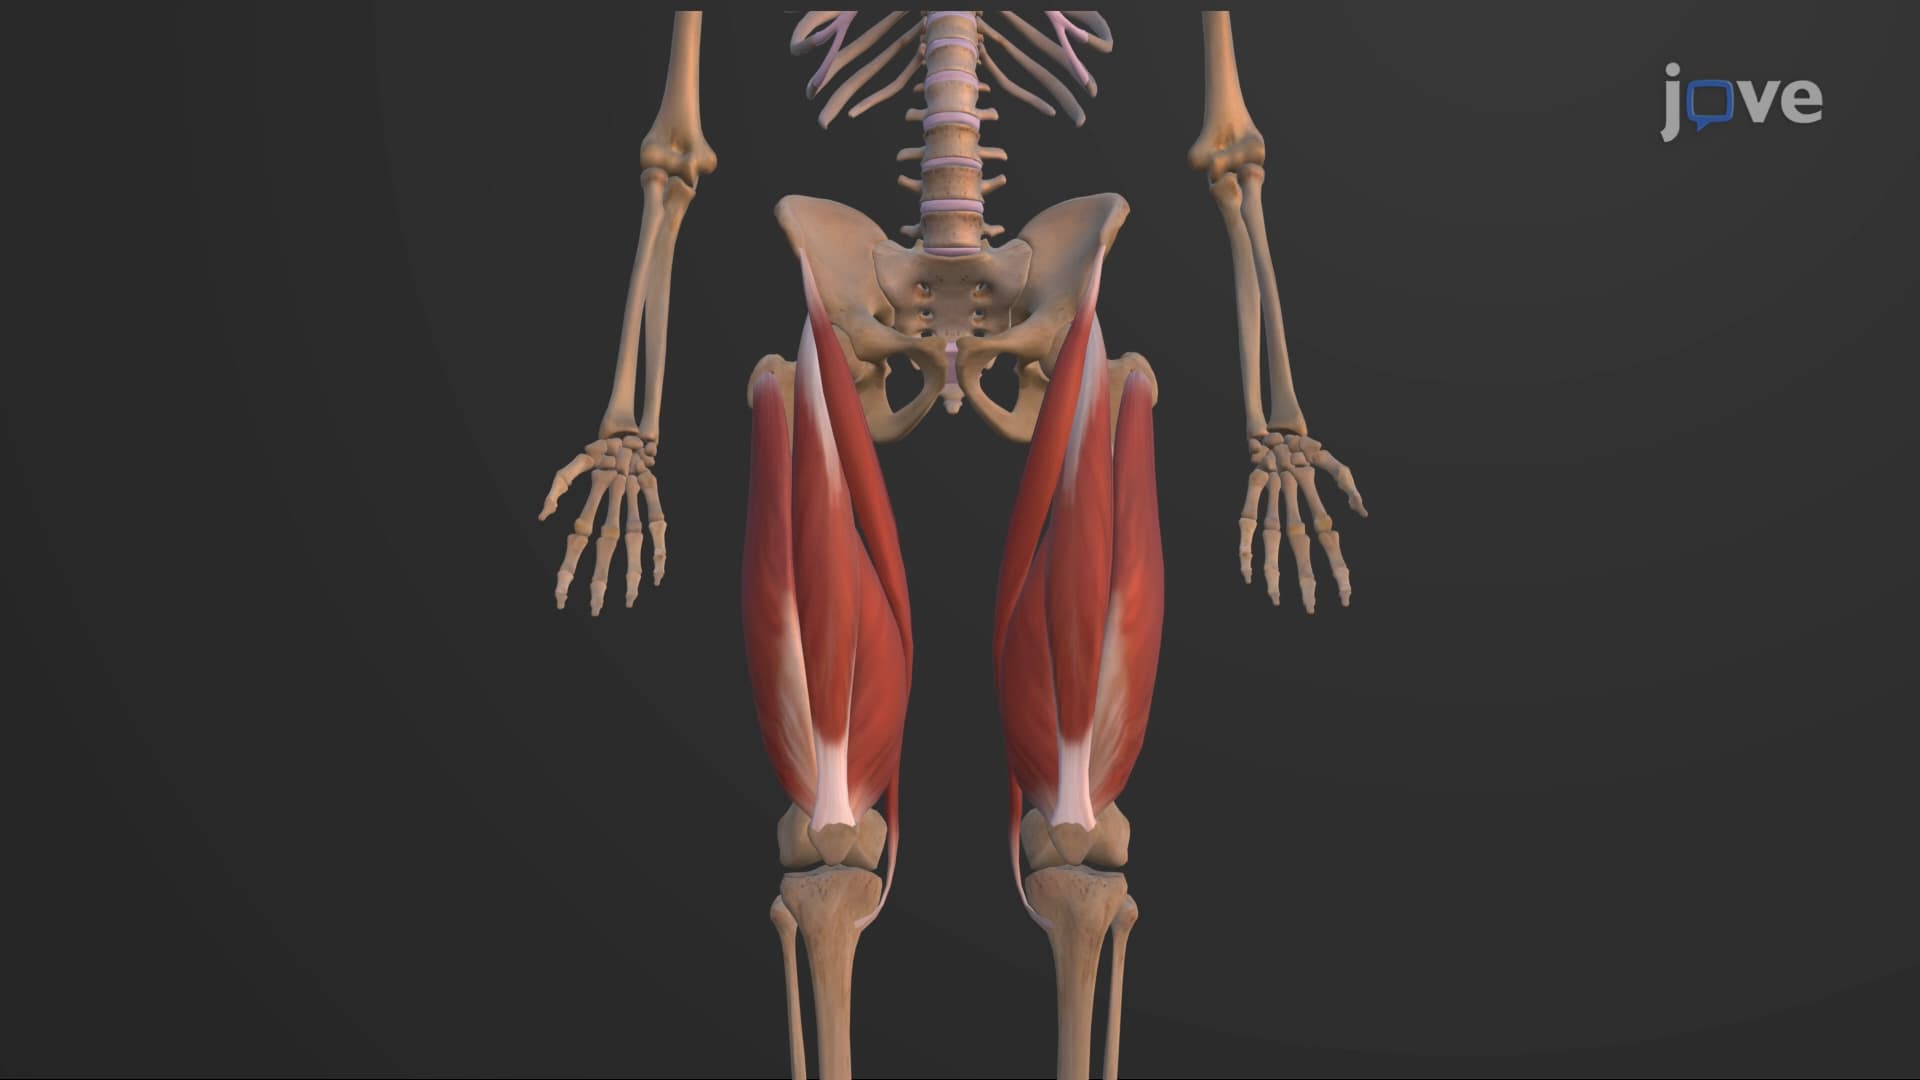
Muscles that Move the Leg
Anterior Compartment
The quadriceps femoris, the most visible muscle of the anterior compartment, is integral for leg extension and thigh flexion. It is formed by merging four distinct muscles — the vastus lateralis, vastus medialis, vastus intermedius, and rectus femoris. The quadriceps tendon, a shared tendon of the four quadriceps muscles, is affixed to...