Related Experiment Video
Updated: Aug 28, 2026
Four-Dimensional CT Analysis Using Sequential 3D-3D Registration
Published on: November 23, 2019
Efficient nonlinear registration of 3D images using high order co-ordinate transfer functions
1Department of Medical Physics and Clinical Engineering, Royal Hallamshire Hospital, Sheffield, UK.

Abstract:
There is an increasing interest in image registration for a variety of medical imaging applications. Image registration is achieved through the use of a co-ordinate transfer function (CTF) which maps voxels in one image to voxels in the other image, including in the general case changes in mapped voxel intensity. If images of the same subject are to be registered the co-ordinate transfer function needs to implement a spatial transformation consisting of a displacement and a rigid rotation. In order to achieve registration a common approach is to choose a suitable quality-of-registration measure and devise a method for the efficient generation of the parameters of the CTF which minimize this measure. For registration of images from different subjects more complex transforms are required. In general function minimization is too slow to allow the use of CTFs with more than a small number of parameters. However, provided the images are from the same modality and the CTF can be expanded in terms of an appropriate set of basis functions this paper will show how relatively complex CTFs can be used for registration. The use of increasingly complex CTFs to minimize the within group standard deviation of a set of normal single photon emission tomography brain images is used to demonstrate the improved registration of images from different subjects using CTFs of increasing complexity.
Related Concept Videos
 01:20
Calibration Curves: Linear Least Squares
For data that follow a straight line, the standard method for fitting is the linear...
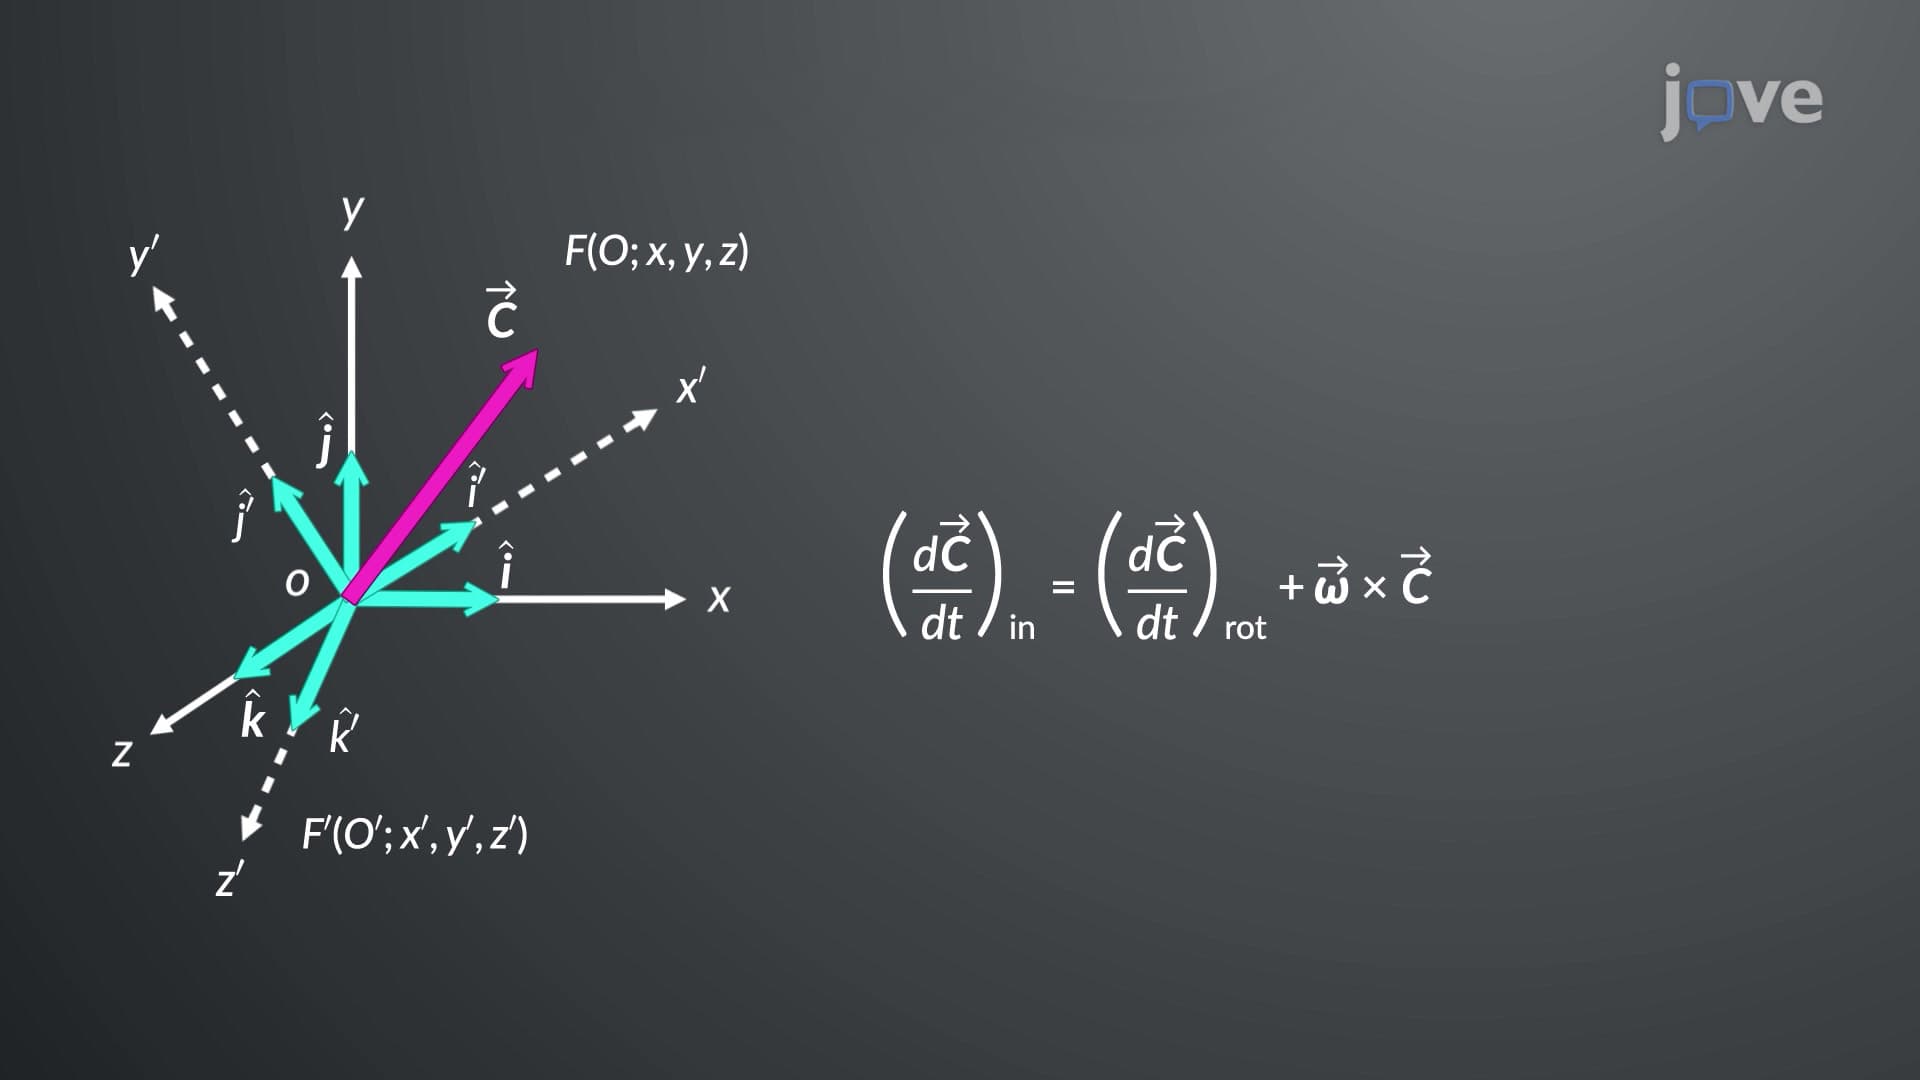 01:16
Vector Transformation in Rotating Coordinate Systems
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:27
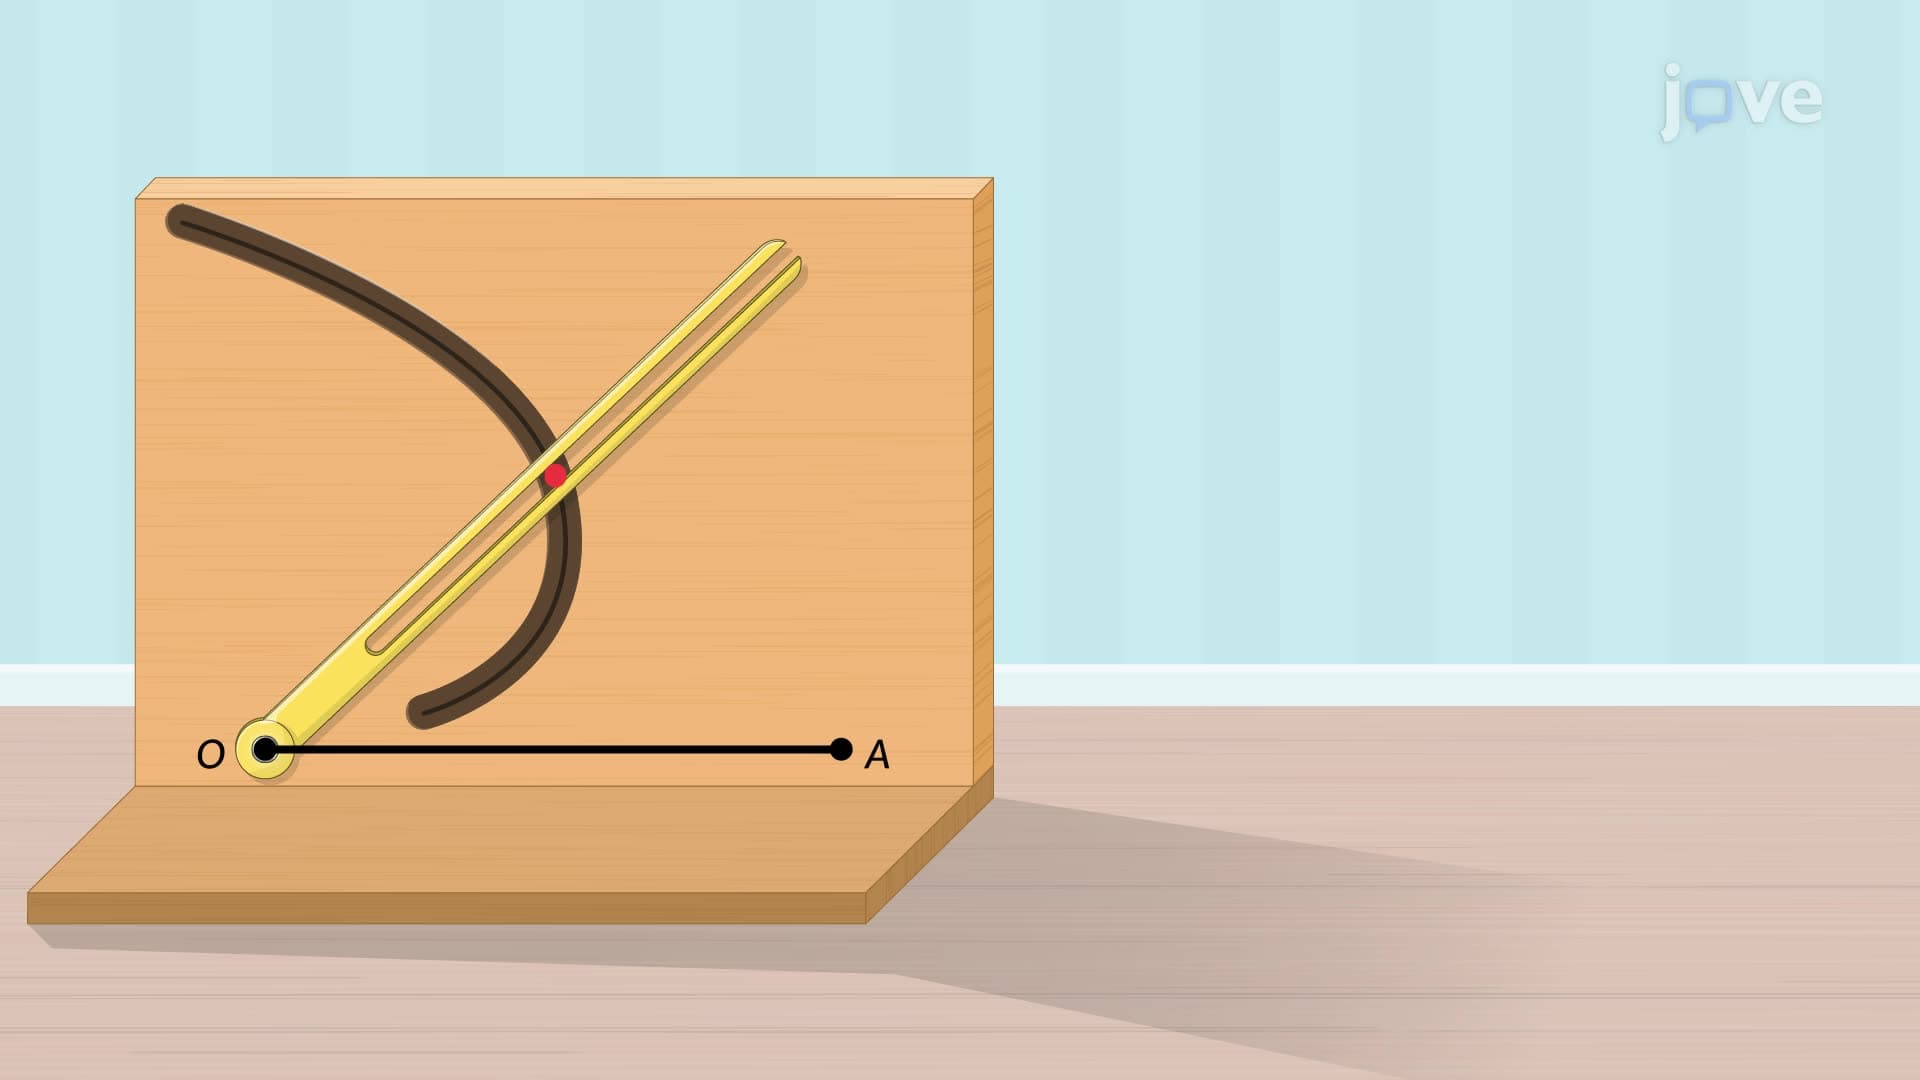
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position with respect to time...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:20
Transformations of Functions III