Related Experiment Video
Updated: Oct 17, 2026
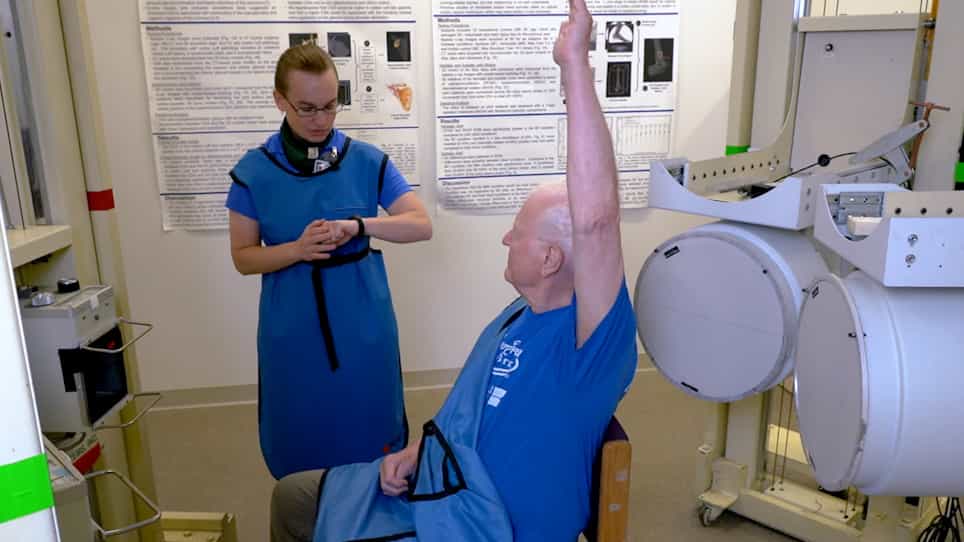
Measuring 3D In-vivo Shoulder Kinematics using Biplanar Videoradiography
Published on: March 12, 2021
Stiffness, viscosity, and upper-limb inertia about the glenohumeral abduction axis
L Q Zhang1, G H Portland, G Wang
1Department of Orthopaedic Surgery, Northwestern University, Rehabilitation Institute of Chicago, Illinois 60611, USA. l-zhang@nwu.edu

Abstract:
To evaluate the dynamic properties of the shoulder and understand how they are controlled by the central nervous system, glenohumeral-joint stiffness and viscosity and upper-limb inertia were quantified under various levels of muscle contraction in seven healthy human subjects. Through a cast attachment, the upper limb was perturbed in a precise pattern by a computer-controlled servomotor to manifest the dynamic properties of the joint. The recorded joint position and torque were used to estimate joint stiffness and viscosity and upper-limb inertia. With moderate muscle contraction, the stiffness and viscosity increased several fold. A stiffer shoulder joint associated with stronger muscle contraction made the shoulder more stable and protected it from potential injuries during strenuous tasks. Joint viscosity, especially the stronger viscous damping associated with more strenuous contraction, smoothed shoulder movement and stabilized the joint. From the control viewpoint, the glenohumeral joint responded to the central nervous system more quickly with increasing muscle contraction, which was useful during strenuous tasks. On the other hand, the central nervous system controlled stiffness and viscosity synchronously so that it dealt with only a nearly constant damping ratio of the joint over various levels of contraction, which simplified its task substantially. This approach quantified the dynamic and static properties of the shoulder under various levels of contraction more accurately and completely than a manual test, and it can potentially be used to evaluate changes in these properties caused by musculoskeletal injuries and their surgical treatments.
Related Concept Videos
 01:19
Bones of the Upper Limb: Humerus
 01:09
Angular Momentum and Principle Axes of Inertia
To put this equation into simpler terms, it can be reconfigured using rectangular coordinates. This involves choosing an alternative set of XYZ axes that are arbitrarily inclined with respect to the reference frame. The process of deriving the rectangular...
 01:18
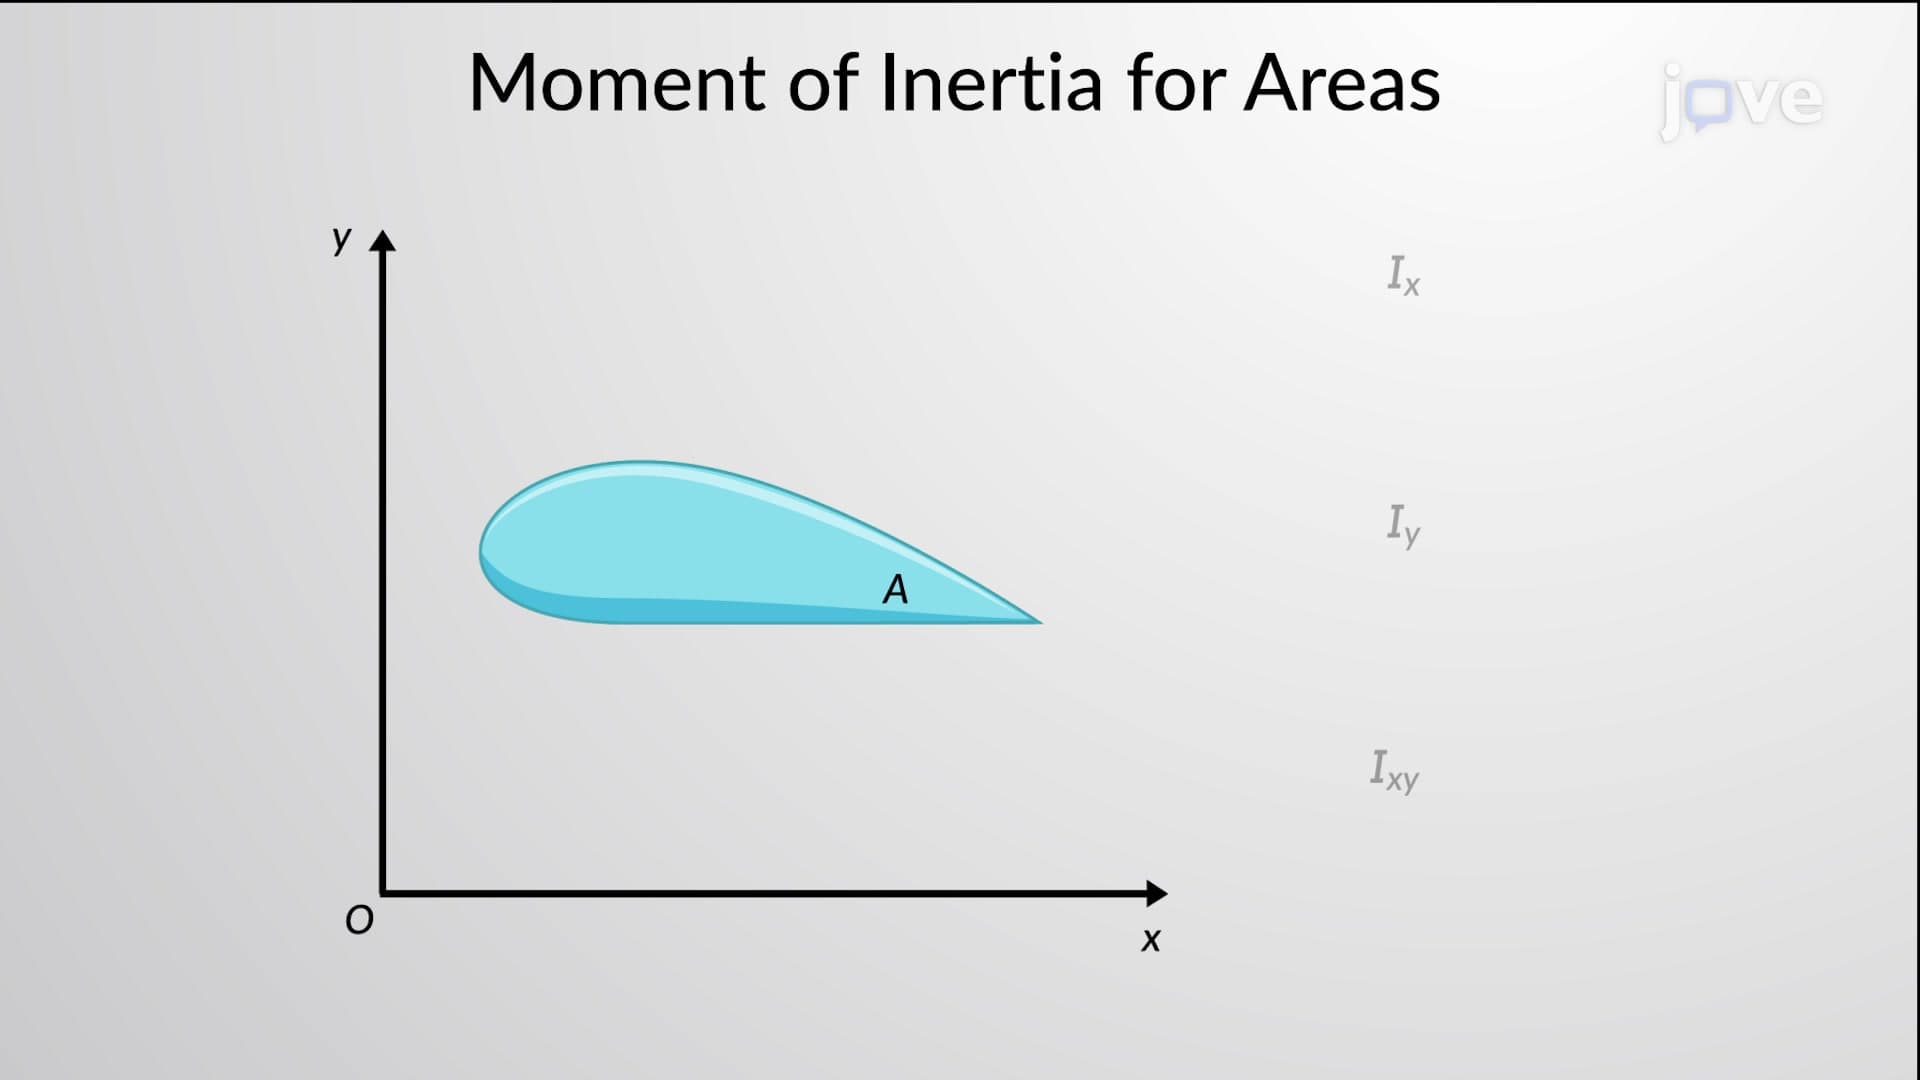
Moments of Inertia for an Area about Inclined Axes
 01:24
Inertia Tensor
The diagonal components of the inertia tensor matrix represent the moments of inertia concerning the principal axes of the object. These primary axes are defined as the axes where the object experiences the least...
 01:14
Moment of Inertia
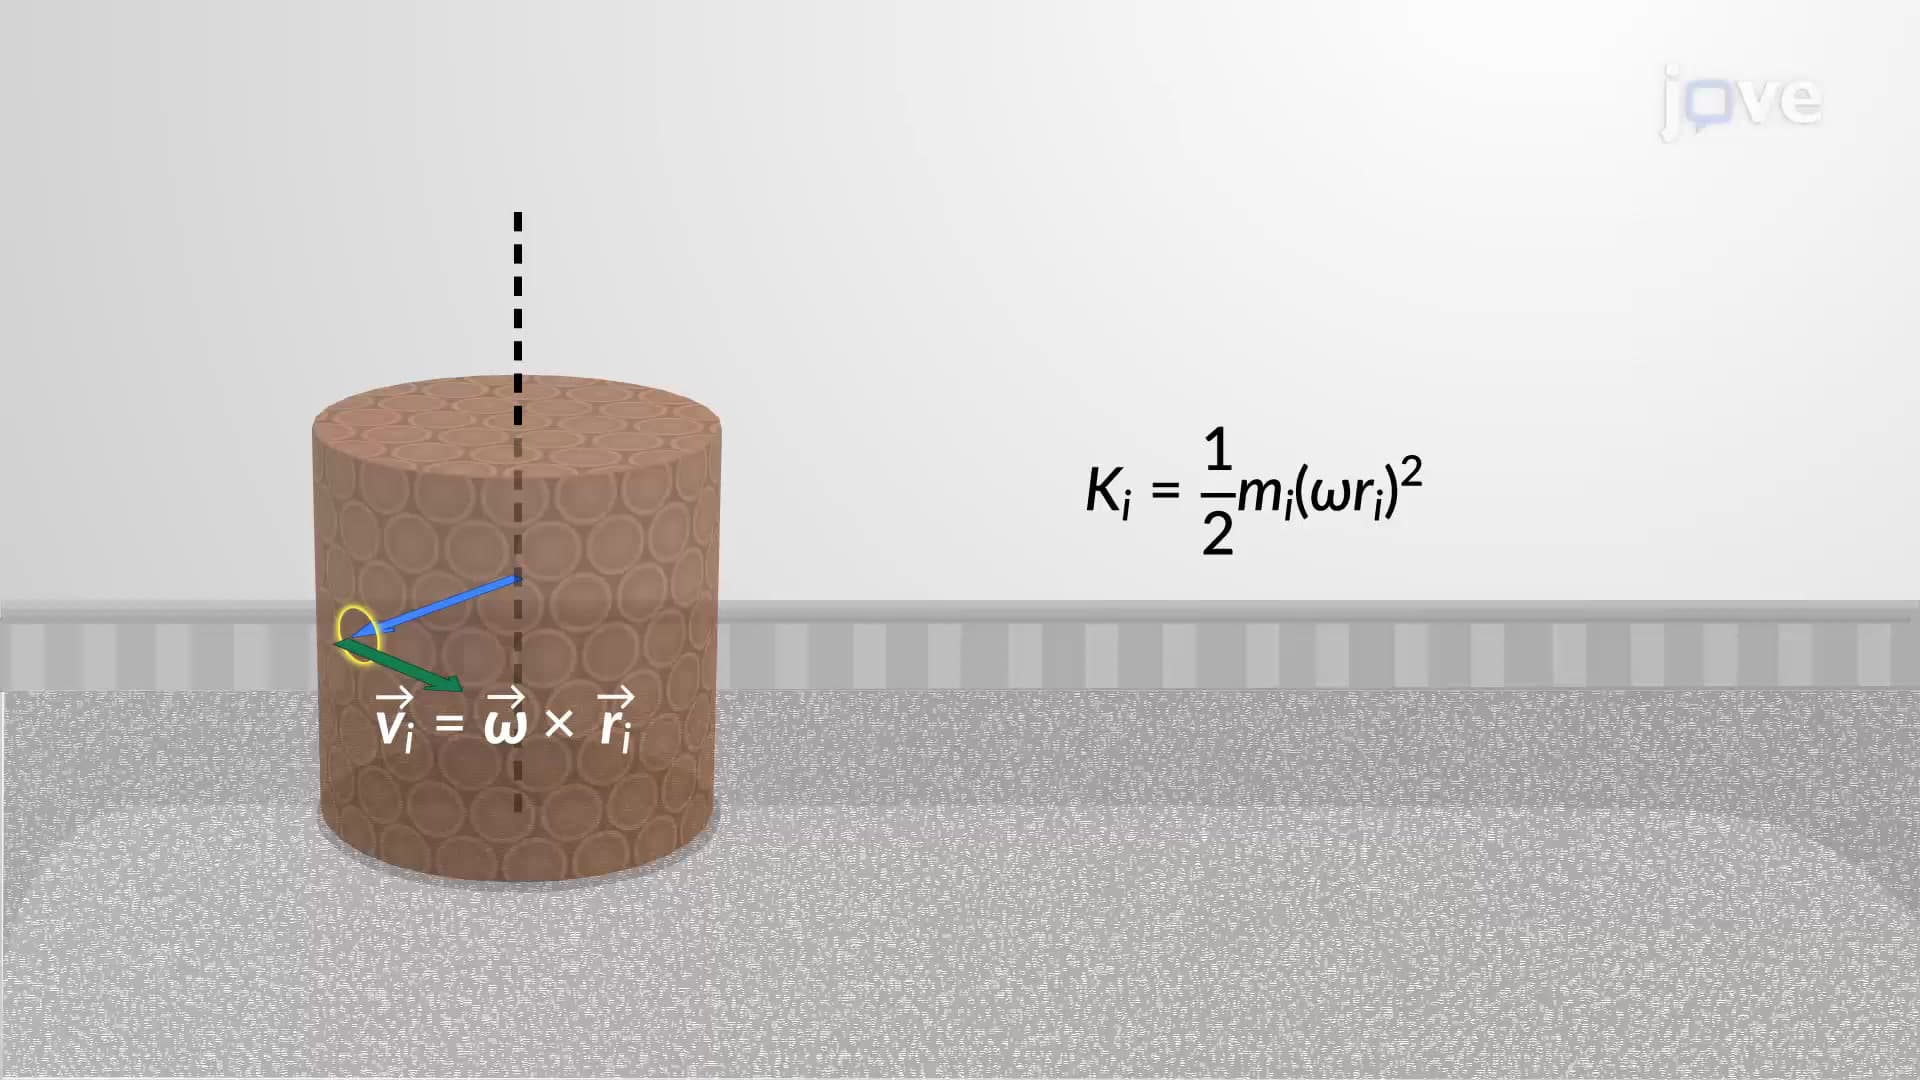
If a rigid body is rotating about an axis but is not in translational motion, its translational kinetic energy is zero. However, since each particle undergoes rotational motion, it possesses non-zero velocity and kinetic energy. Thus, the kinetic energy of the rigid body, which is the sum of the...
 01:09
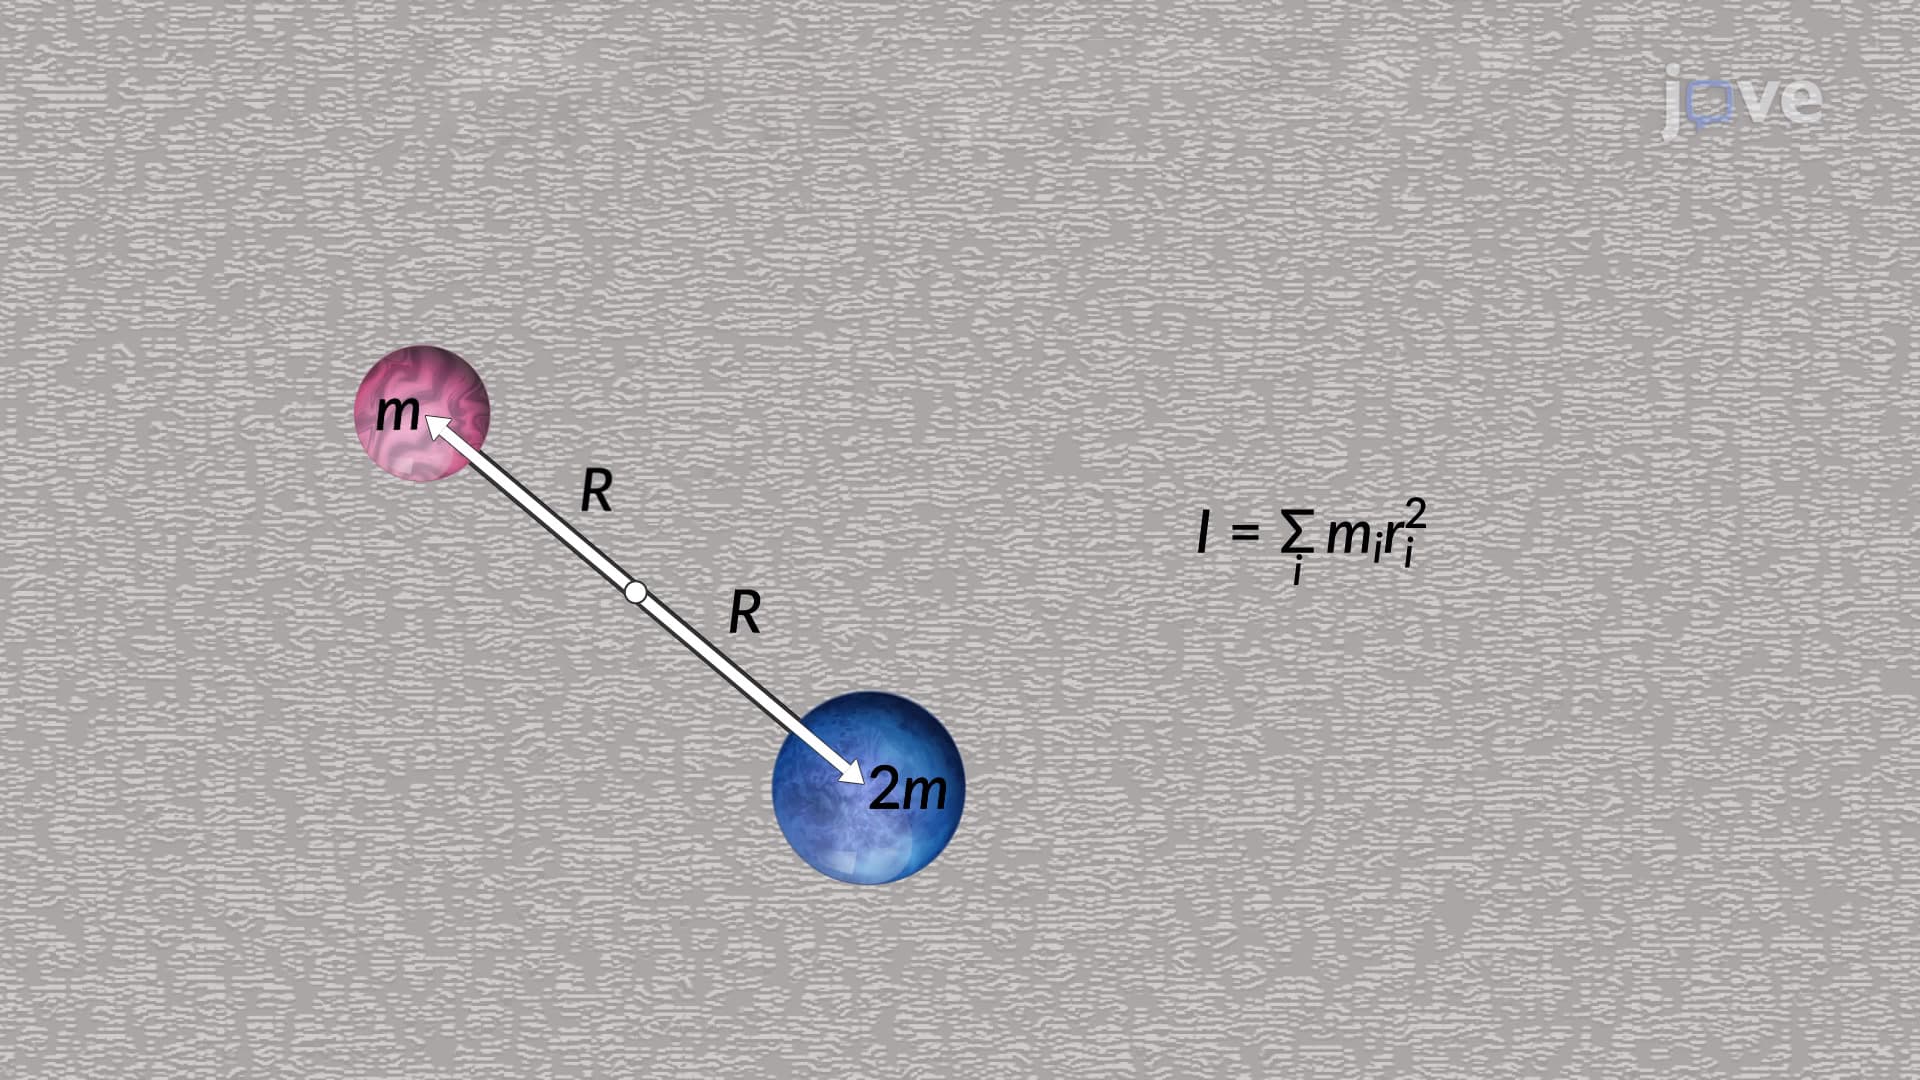
Moment of Inertia: Calculations