Training feed-forward neural networks with gain constraints
Related Experiment Video
Updated: Aug 10, 2026

An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
Published on: March 10, 2011
1Pavilion Technologies, 1110 Metric Blvd. Number 700, Austin, TX 78758-4018, USA.

Abstract:
Inaccurate input-output gains (partial derivatives of outputs with respect to inputs) are common in neural network models when input variables are correlated or when data are incomplete or inaccurate. Accurate gains are essential for optimization, control, and other purposes. We develop and explore a method for training feedforward neural networks subject to inequality or equality-bound constraints on the gains of the learned mapping. Gain constraints are implemented as penalty terms added to the objective function, and training is done using gradient descent. Adaptive and robust procedures are devised for balancing the relative strengths of the various terms in the objective function, which is essential when the constraints are inconsistent with the data. The approach has the virtue that the model domain of validity can be extended via extrapolation training, which can dramatically improve generalization. The algorithm is demonstrated here on artificial and real-world problems with very good results and has been advantageously applied to dozens of models currently in commercial use.
Related Concept Videos
 01:37
Neural Regulation
 01:15
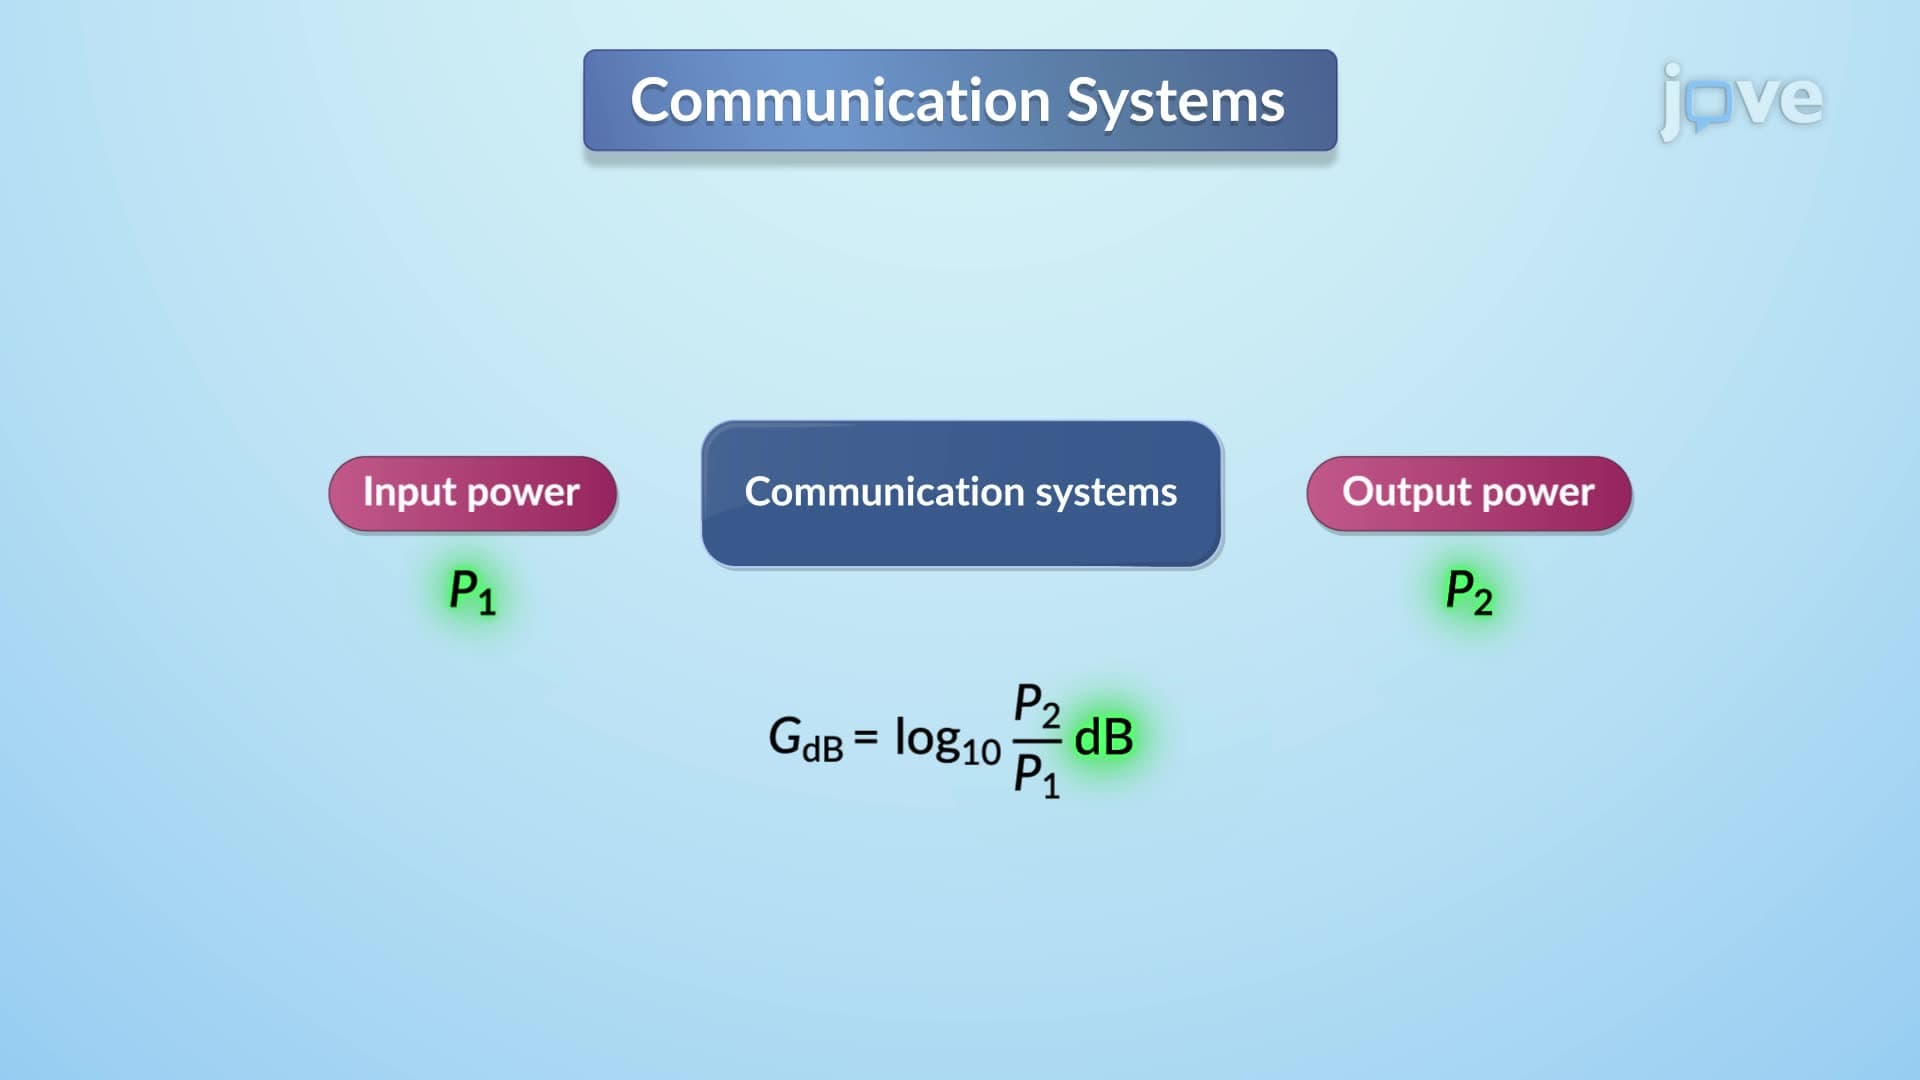
Gain
Gain:
Suppose Vin is the input and Vout is the output signal to a circuit.
 01:24
Effects of feedback
Feedback significantly modifies the gain of a control system. The gain of a system without feedback is altered by a factor of one plus GH, where G represents...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:12
Observational Learning