Unconstrained stereoscopic matching of lines
Related Experiment Video
Updated: Oct 16, 2026

Robotized Testing of Camera Positions to Determine Ideal Configuration for Stereo 3D Visualization of Open-Heart Surgery
Published on: August 12, 2021
1School of Optometry, University of California, Berkeley, USA. raymond@psyche.mit.edu

Abstract:
The computation of horizontal binocular disparities used in stereoscopic depth perception depends upon the identification of corresponding features in the two retinal images. In principle, binocular matching is a two-dimensional problem that considers matches in all possible meridians. Normally, constraints such as end points or crossing points limit the direction and magnitude of matches. If matching is unconstrained, such as is the case with long lines, it is completely ambiguous. Under these conditions the default match will be determined by the operating range, or upper disparity limit, of matchable vertical and horizontal disparities. We computed the operating range of vertical matches for stereoscopic depth as a function of line orientation. Our results suggest that the two-dimensional operating range is anisotropic for vertical and horizontal disparity and that unconstrained matches are not based upon either epipolar geometry or nearest neighbor constraints, but rather the mean of disparity estimates within the operating range for binocular matches. This operating range can be extended vertically when matches are constrained by image primitives.
Related Concept Videos
 01:21
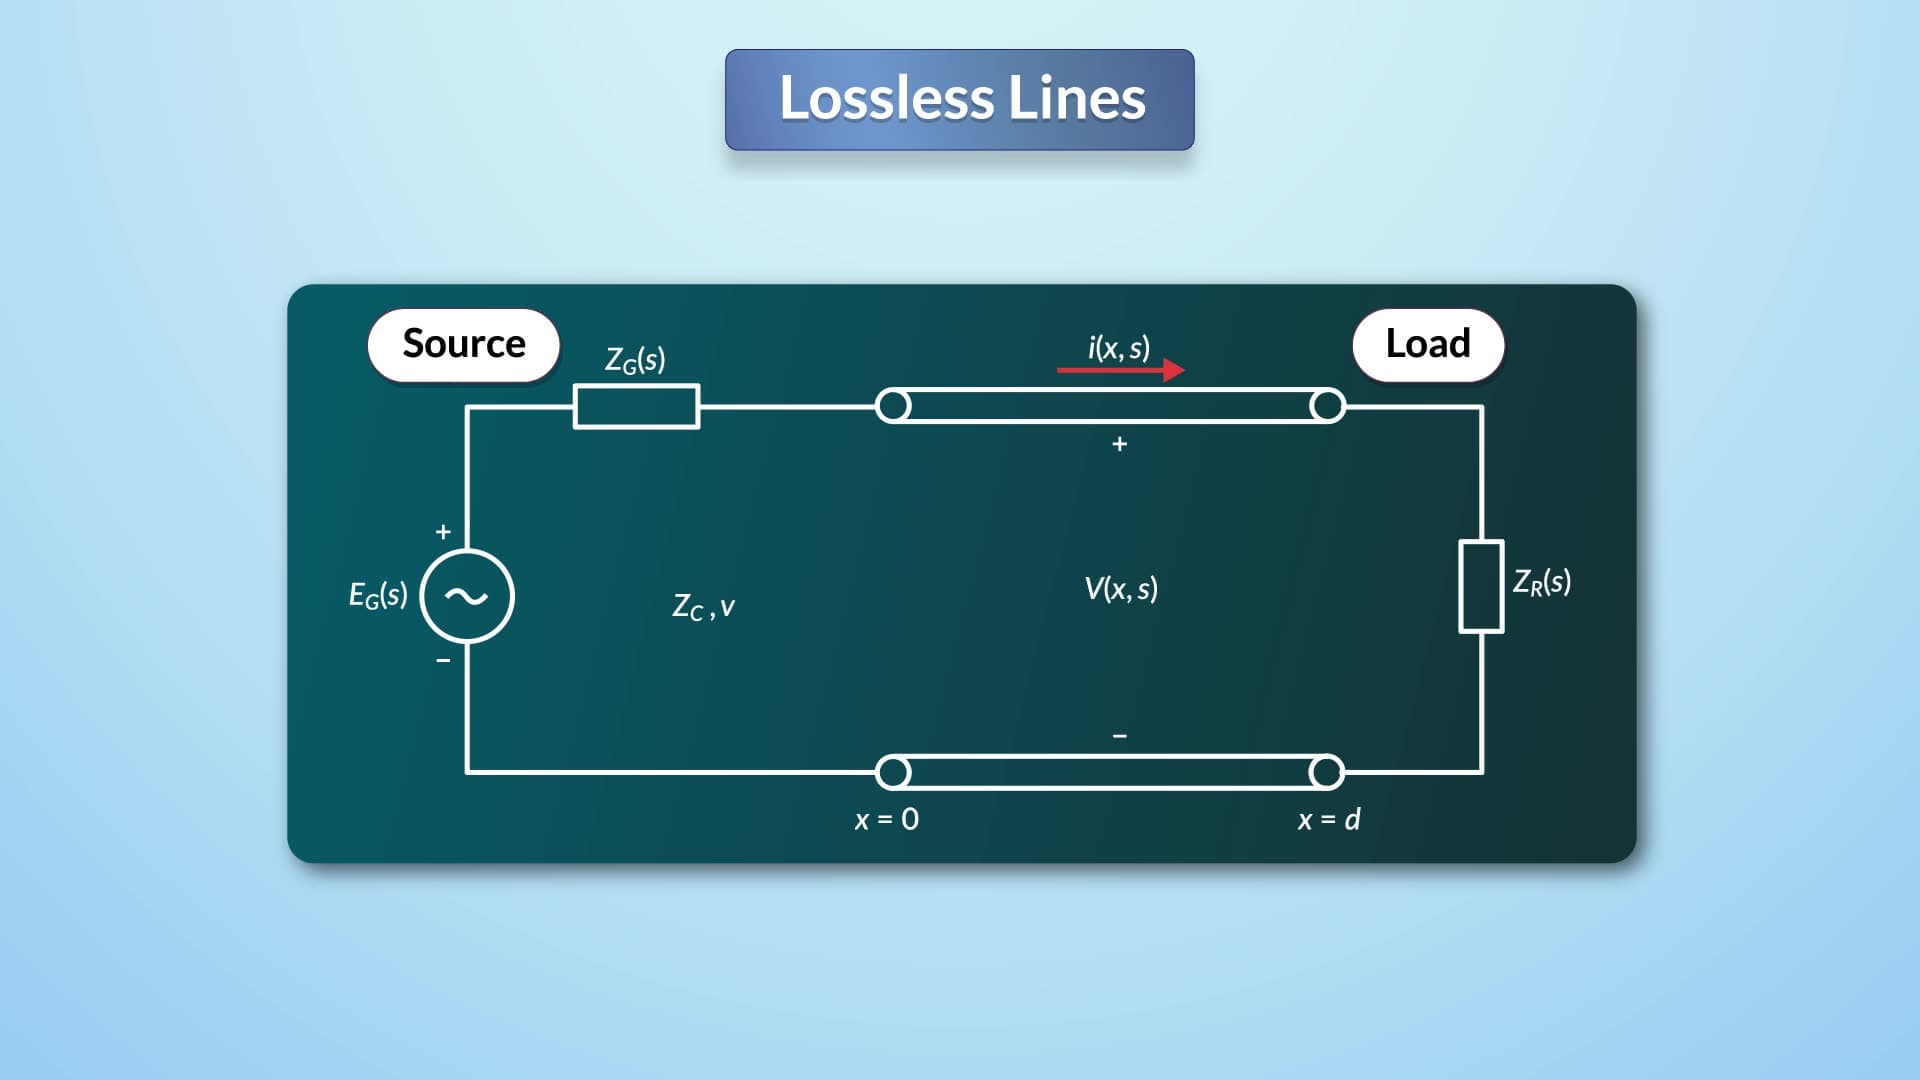
Boundary Conditions: Lossless Lines
At the receiving end, the boundary condition states that the voltage equals the product of the receiving-end impedance and current. This relationship is expressed as a function of the incident and...
 01:29
Lines in Space
 01:15
Depth Perception and Spatial Vision
 02:32
Stereoisomers
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...