Related Experiment Video
Updated: Aug 8, 2026

Measuring Sensitivity to Viewpoint Change with and without Stereoscopic Cues
Published on: December 5, 2013
Mathematical theory of stereotactic coordinate transformation: elimination of rotational targeting error by addition
1Department of Neurosurgery, Inselspital, Berne, Switzerland. ethan.taub@insel.ch

Abstract:
All frame-based stereotactic procedures require localization of an anatomical target within the coordinate system of the stereotactic frame. If the target is defined by its coordinates given in a stereotactic atlas (indirect localization), the neurosurgeon faces the mathematical task of transforming atlas coordinates into frame coordinates. In the method usually used, the frame coordinates of two reference points (the anterior and posterior commissures) are obtained from computerized tomography or magnetic resonance images, and serve as the basis for the coordinate transformation. This two-point algorithm relies on the additional assumption that the frame sits on the patient's head without exhibiting roll, that is, rotation about the anteroposterior axis (y axis). Usually this assumption is nearly, but not exactly, correct. An amount of roll as small as 3 degrees can cause a targeting error on the order of 1 mm when a two-point algorithm is used. This potential source of error can be eliminated by using a new method of coordinate transformation, the derivation of which is mathematically reported in this article. The new method requires a third reference point located in the midsagittal plane, in addition to the two commissural reference points.

Related Concept Videos
 01:16
Vector Transformation in Rotating Coordinate Systems
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:30
Polar Coordinate System
 01:29
Lines in Space
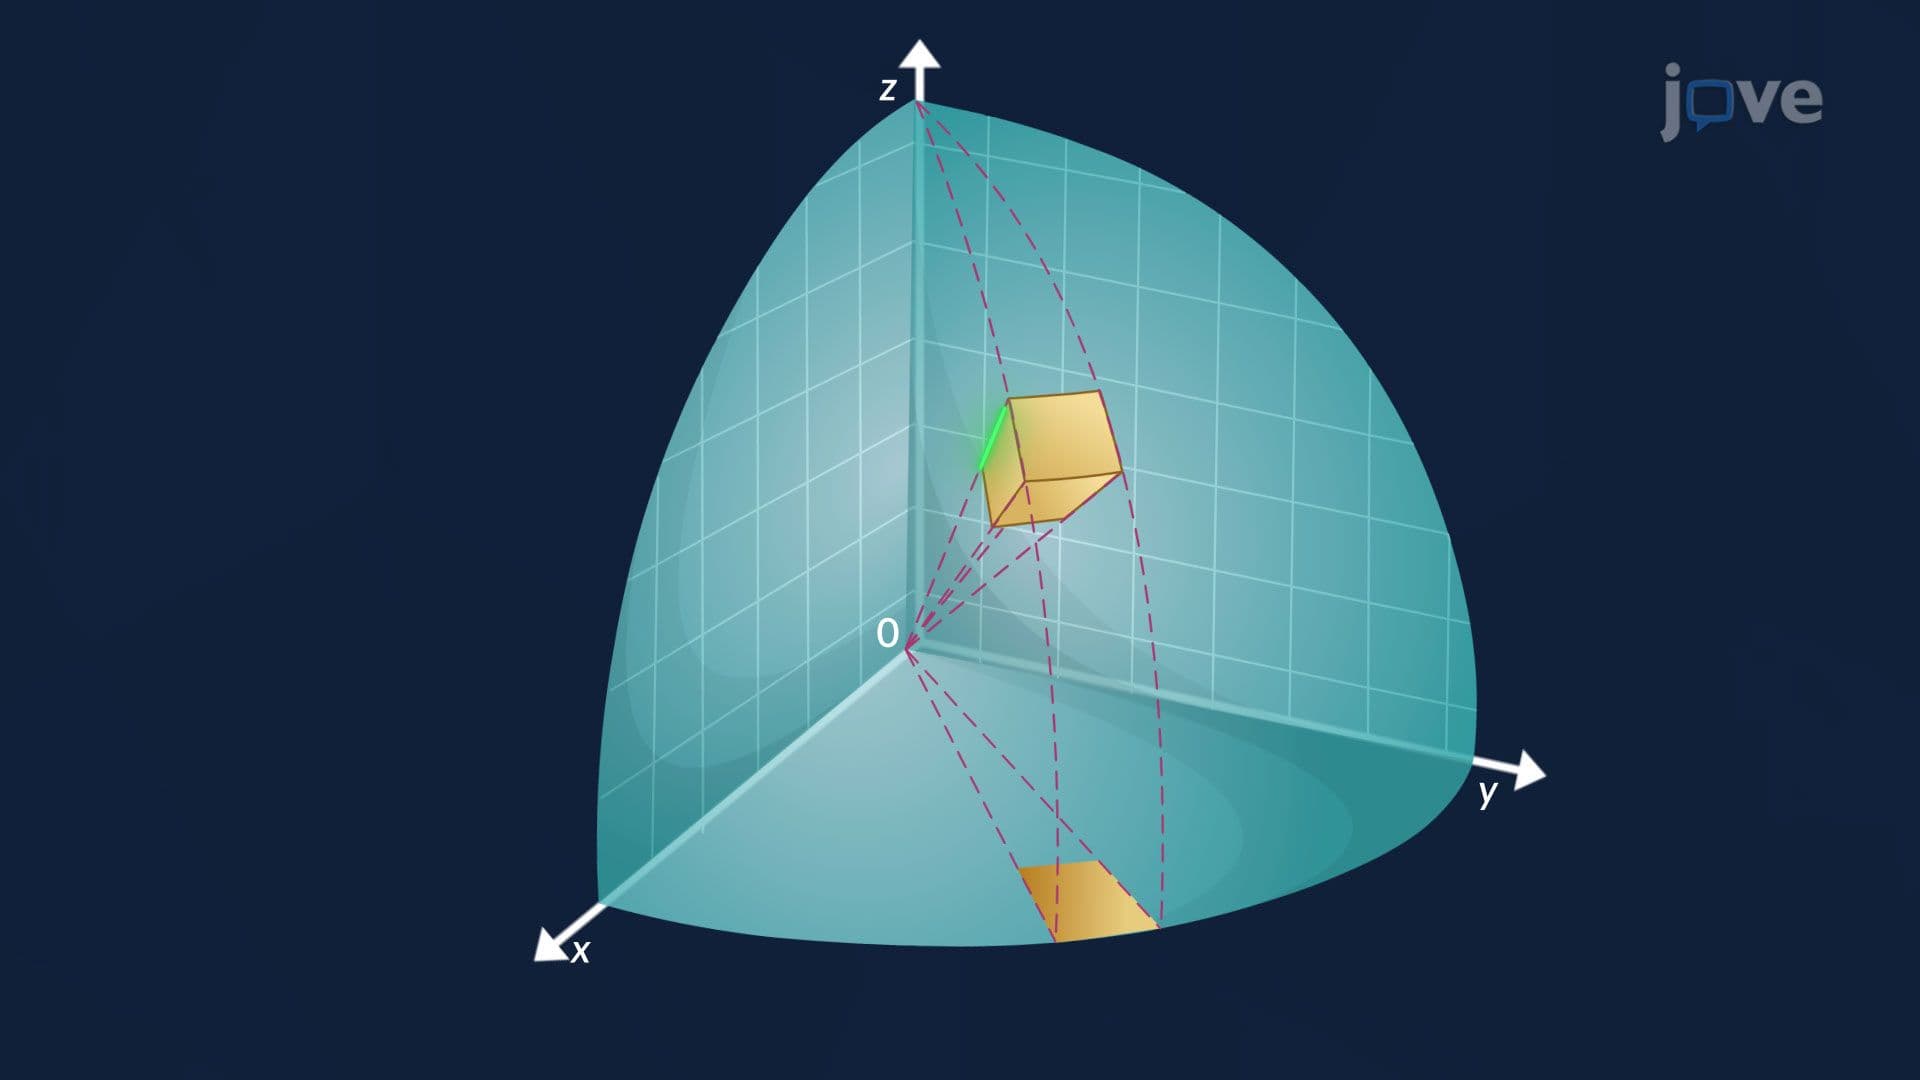 01:27
Triple Integrals in Spherical Coordinates
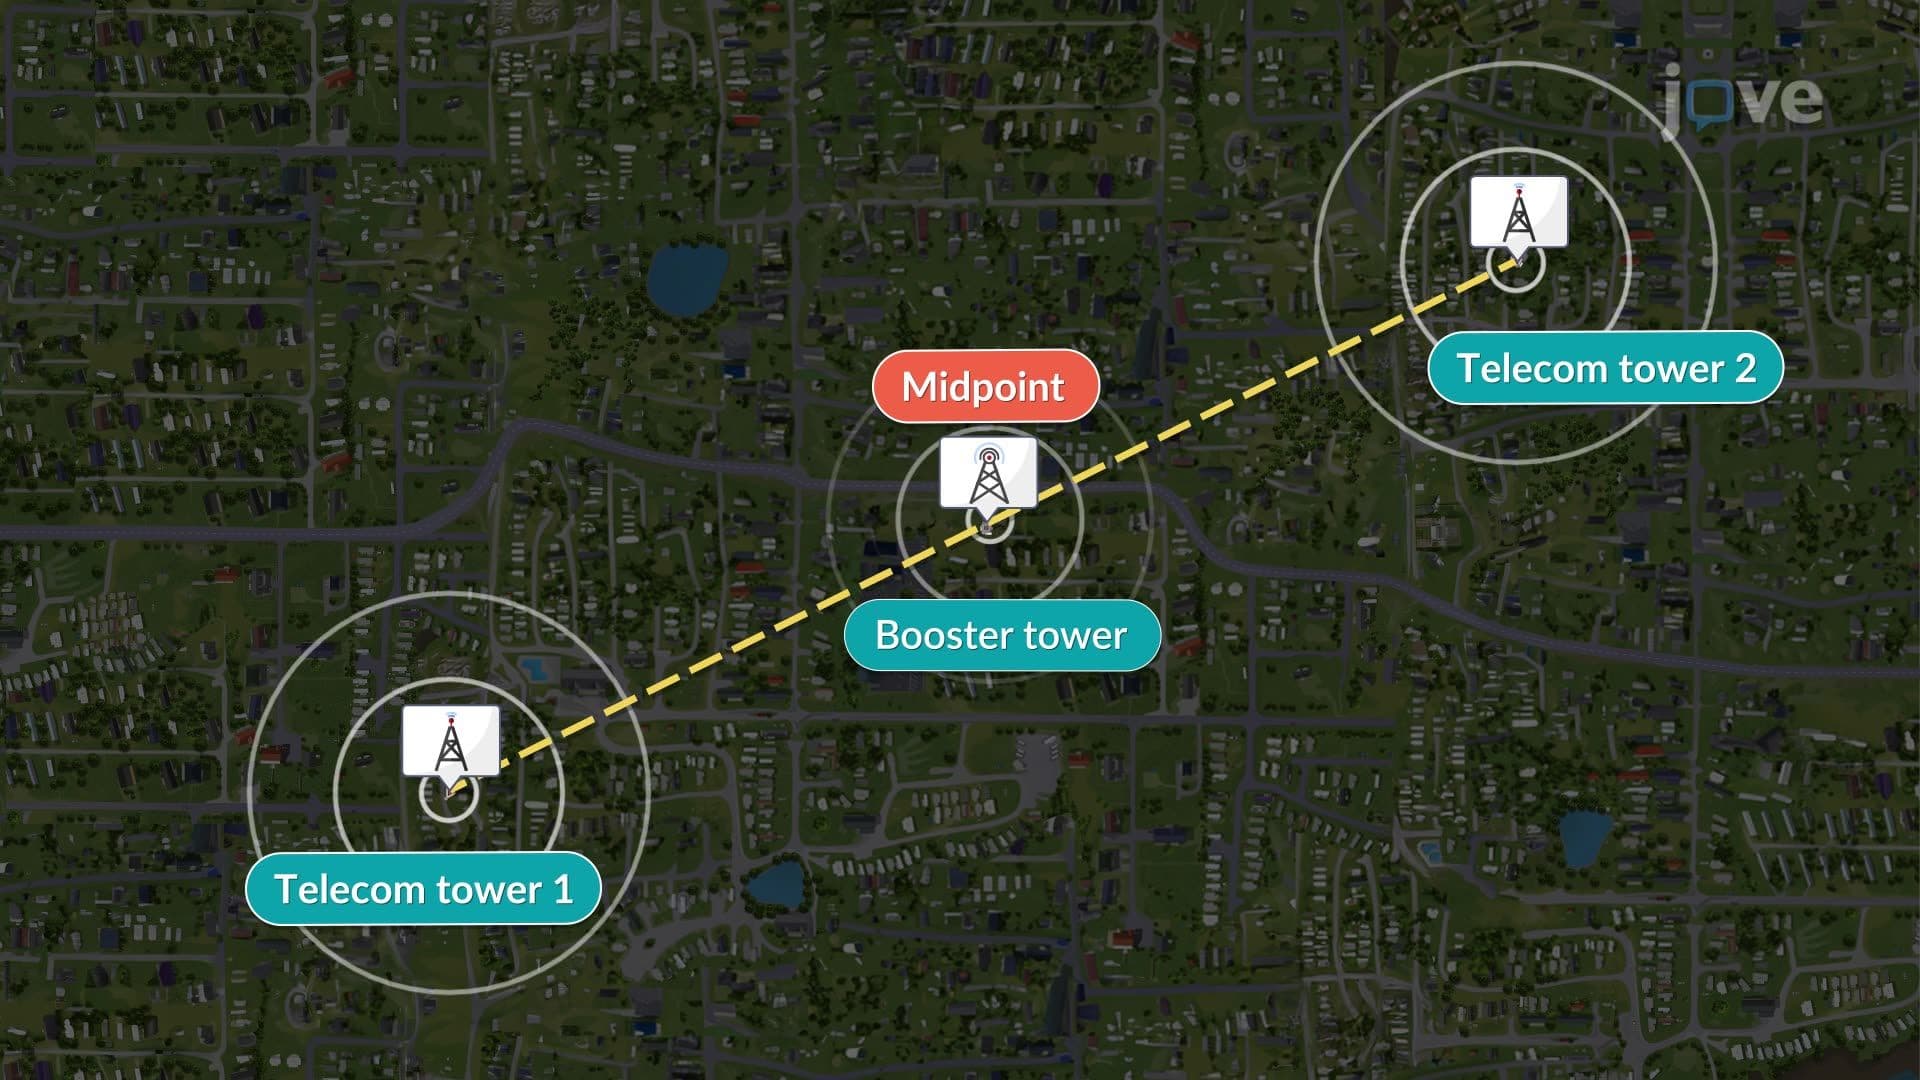 01:24
The Midpoint Formula