Cerebellar learning of accurate predictive control for fast-reaching movements
Related Experiment Video
Updated: Oct 16, 2026
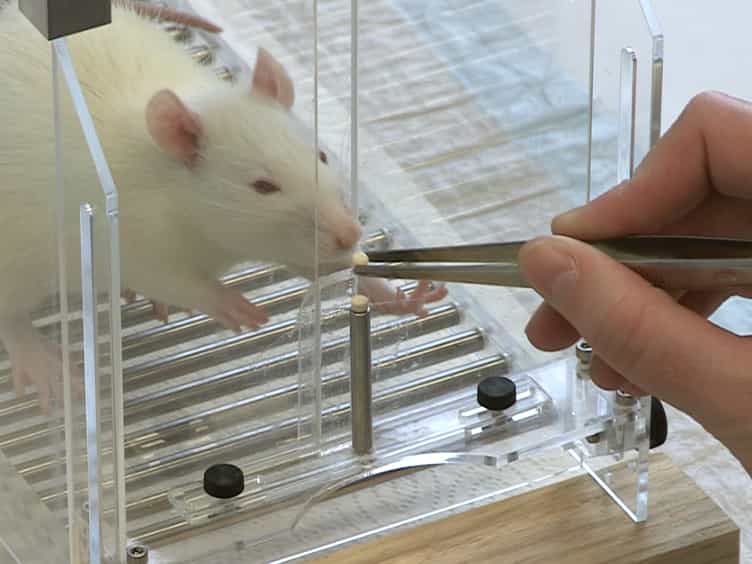
Acquisition of a High-precision Skilled Forelimb Reaching Task in Rats
Published on: June 22, 2015
J Spoelstra1, N Schweighofer, M A Arbib
1Department of Computer Sciences, University of Southern California, Los Angeles 90089-2520, USA.

Abstract:
Long conduction delays in the nervous system prevent the accurate control of movements by feedback control alone. We present a new, biologically plausible cerebellar model to study how fast arm movements can be executed in spite of these delays. To provide a realistic test-bed of the cerebellar neural model, we embed the cerebellar network in a simulated biological motor system comprising a spinal cord model and a six-muscle two-dimensional arm model. We argue that if the trajectory errors are detected at the spinal cord level, memory traces in the cerebellum can solve the temporal mismatch problem between efferent motor commands and delayed error signals. Moreover, learning is made stable by the inclusion of the cerebello-nucleo-olivary loop in the model. It is shown that the cerebellar network implements a nonlinear predictive regulator by learning part of the inverse dynamics of the plant and spinal circuit. After learning, fast accurate reaching movements can be generated.
Related Concept Videos
 01:31
Hand Control During Infancy and Toddlerhood
 01:18
Hierarchy of Motor Control
 01:14
Role of Cerebellum and Prefrontal Cortex in Memory
 01:28
Major Somatic Sensory Pathways
 01:22
Indirect Motor Pathways
The vestibulospinal tract originates in the vestibular nuclei of the brainstem. The vestibular system detects changes in...
 01:30
Motor Skills Development During Early Childhood