Simplified dynamics model of planar two-joint arm movements
Related Experiment Video
Updated: Oct 16, 2026
Subject-specific Musculoskeletal Model for Studying Bone Strain During Dynamic Motion
Published on: April 11, 2018
M Suzuki1, Y Yamazaki, K Matsunami
1Human Movement Laboratory, Kinjo Gakuin University, Moriyama, Nagoya, Japan. msuzuki@kinjo-u.qc.jp

Abstract:
A theoretical framework is presented that describes a way in which the inverse dynamics equations of motion of planar two-joint arm movements (EX-model) are reformulated in a simple form. A single point was assumed to define both the wrist and elbow joint centers, and thus the motion of two points in extrinsic space was represented by second-order differential equations to provide the variables in the reformulation (RE-) model. Through an analytical processes, it was shown that the RE-model for reproducing the shoulder joint torque consists of the linearly scaled moment per unit mass responsible for accelerating the wrist and elbow points about the shoulder joint, while that for reproducing the elbow joint torque consists of the linearly scaled moment per unit mass responsible for accelerating the wrist point about the elbow. The scaling factors for variables in the RE-model were based solely on the values for segment lengths, while in the EX-model the inertial parameter data for the segments are involved in its representation. The inertial parameter data of six-arm specimens from the cadaver experiment of Chandler et al. (1975, AMRL Technical Report, Wright-Patterson Air Force Base, OH) were used to develop and verify the numeric solutions of the RE-model. The adequacy of the model varied somewhat among subjects, but minor changes of the physical parameters of the arm segments enabled perfect reformulation, regardless of the specimens. The potential abilities of the RE-model to deal with the complexities in motor control with more simple control schemes are discussed.

Related Concept Videos
 01:23
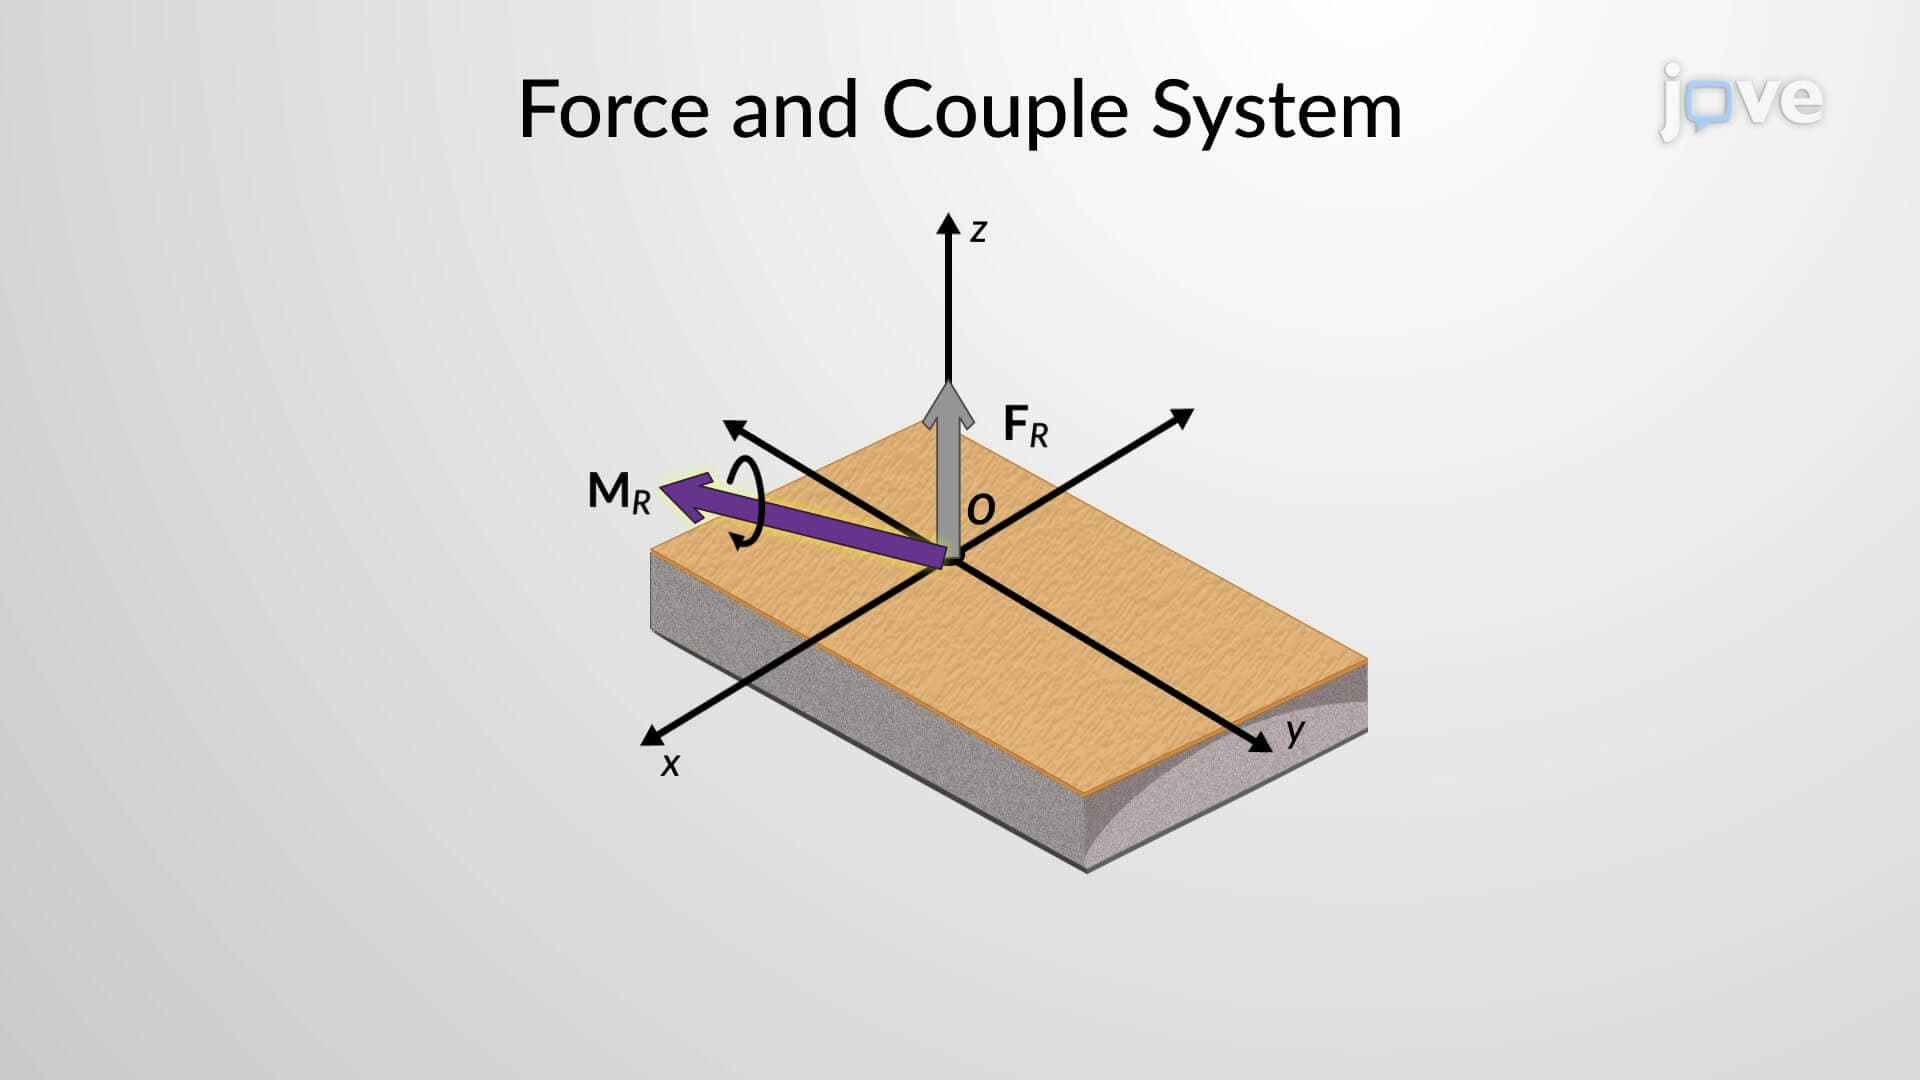
Simplification of a Force and Couple System: II
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
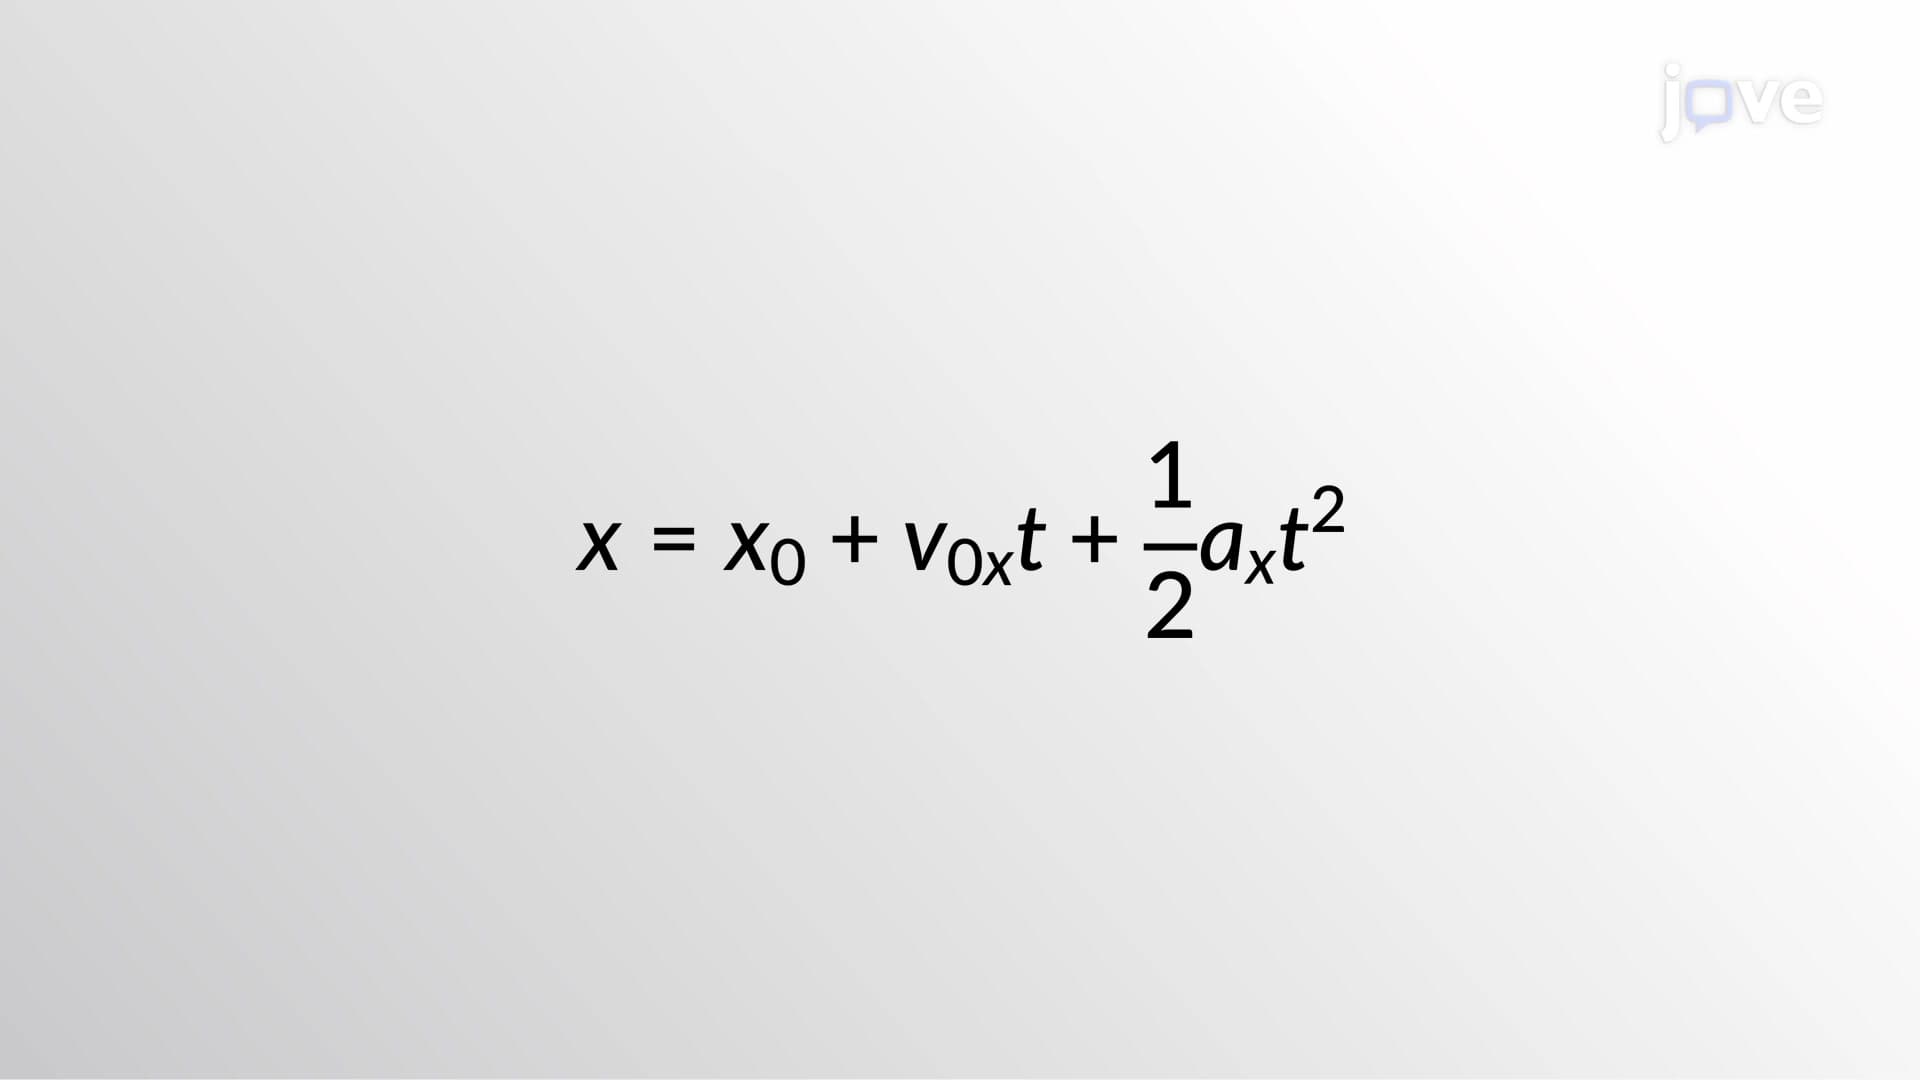 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:18
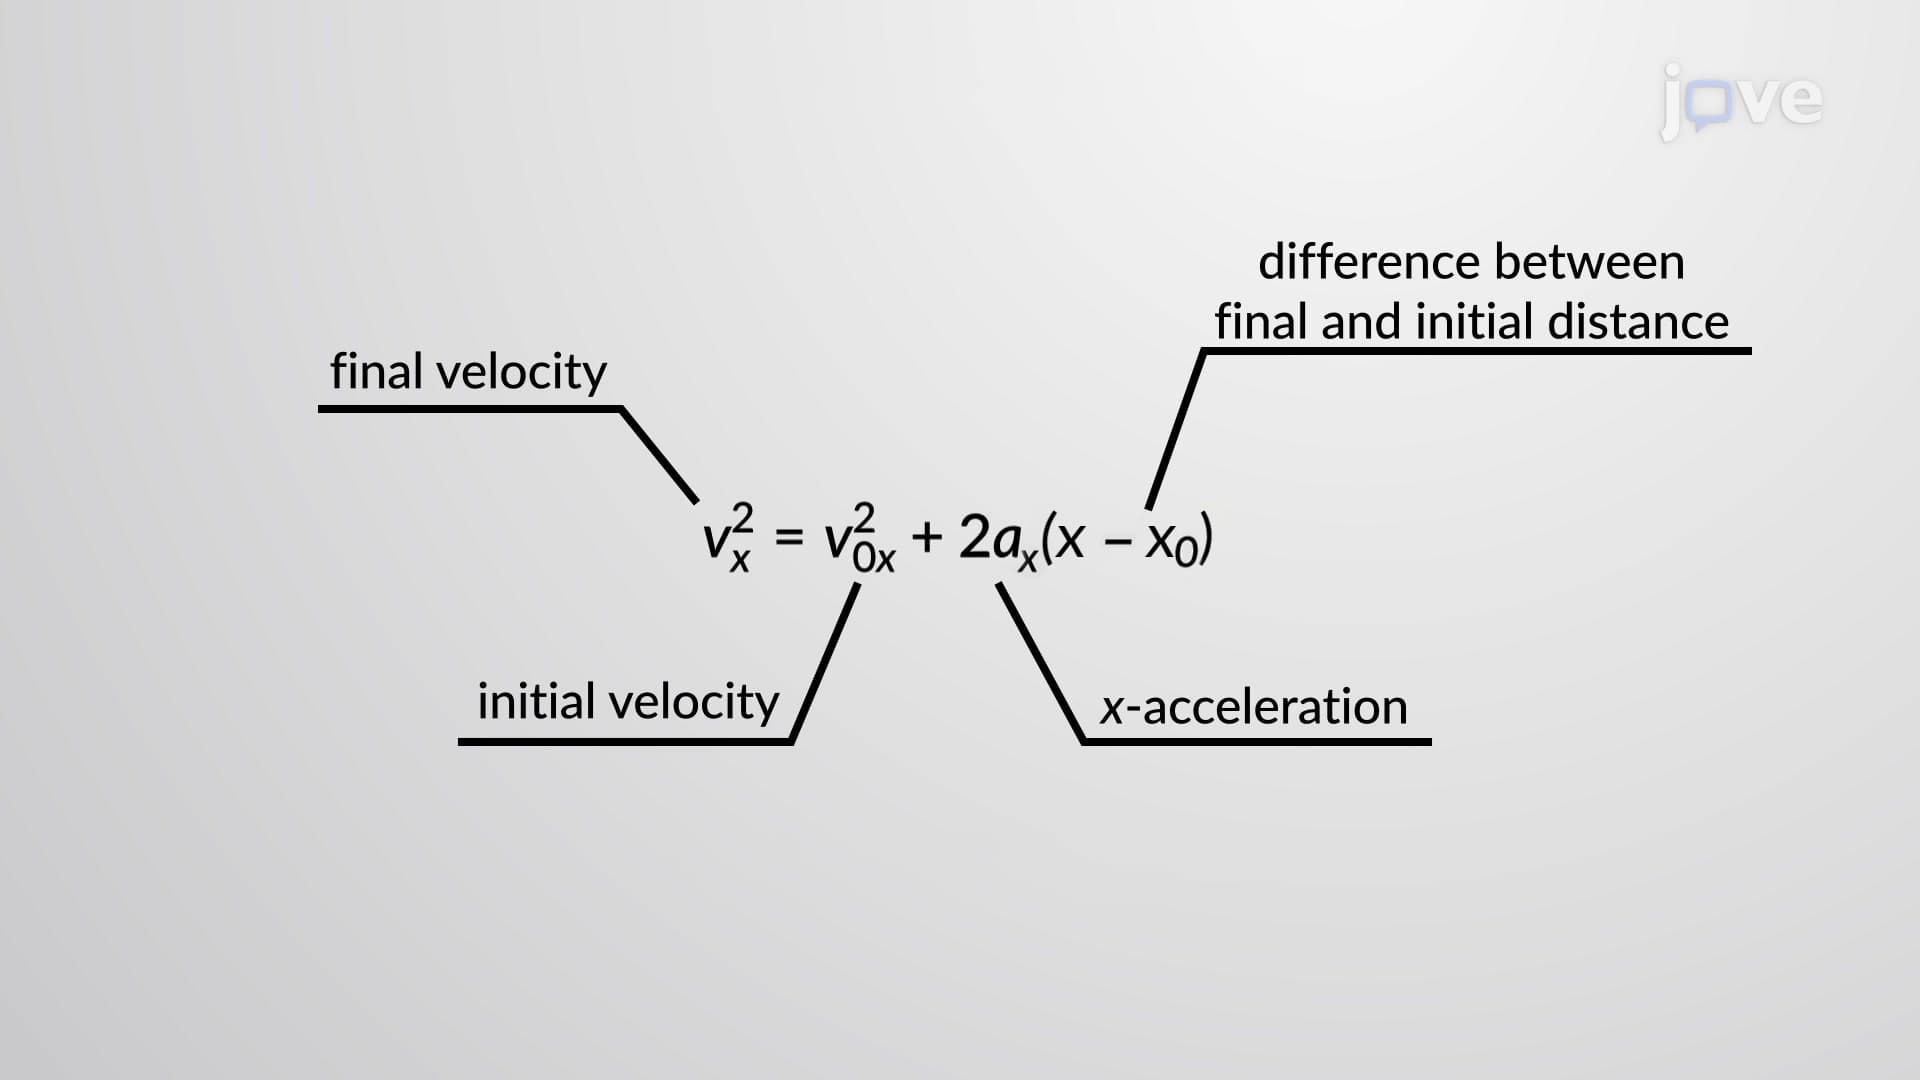
Kinematic Equations - III
Using the kinematic equations,...
 01:12
Equation of Motion for a Rigid Body
The combined moments generated about the center of mass of the object are equal to the rate of change of the angular momentum of the body. An external force, when applied at a different point...