Kinematics of human arm reconstructed from spatial tracking system recordings
Related Experiment Video
Updated: Oct 16, 2026
An Objective and Child-friendly Assessment of Arm Function by Using a 3-D Sensor
Published on: February 12, 2018
E V Biryukova1, A Roby-Brami, A A Frolov
1Institute of Higher Nervous Activity and Neurophysiology of Russian Academy of Sciences, Moscow, Russia. birds@orc.ru

Abstract:
The kinematics of the human arm in terms of angles of rotations in the joints is reconstructed from the spatial tracking system (Fastrack() Polhemus) recordings. The human arm is modeled by three rigid bodies (the upper arm, the forearm and the hand) with seven degrees of freedom (three in the shoulder, two in the elbow and two in the wrist). Joint geometry parameters (orientations of the axes relative to the arm segments, the angles and the distances between the axes) have been calculated on the basis of passive rotations in the joints. The calculated parameters have been used to solve the direct kinematics problem for the reaching movements in different directions. The difference between calculated and recorded positions and accelerations of the hand has been used to assess the accuracy of the proposed method of kinematics reconstruction. The error analysis showed that spatial tracking system recordings and human arm kinematics reconstruction could reliably be used to accurately analyze multijoint movement in humans.

Related Concept Videos
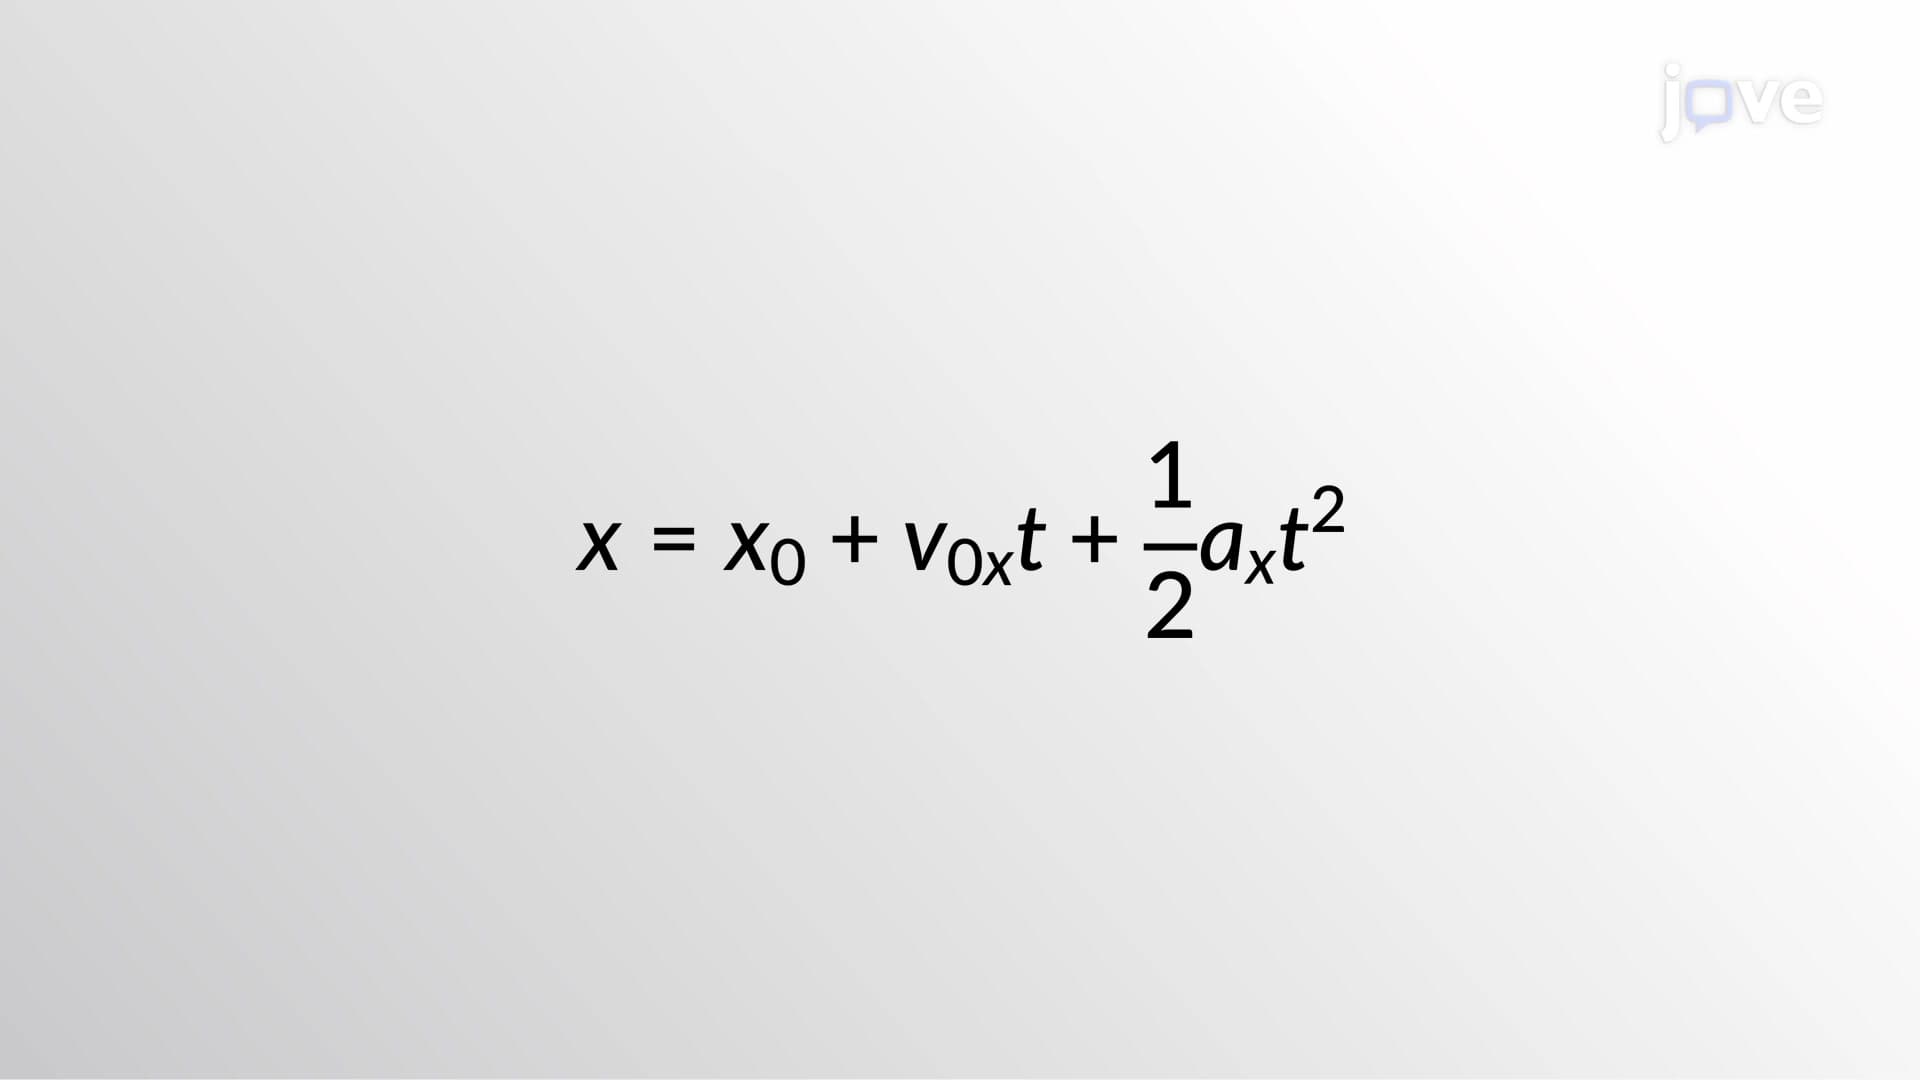 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
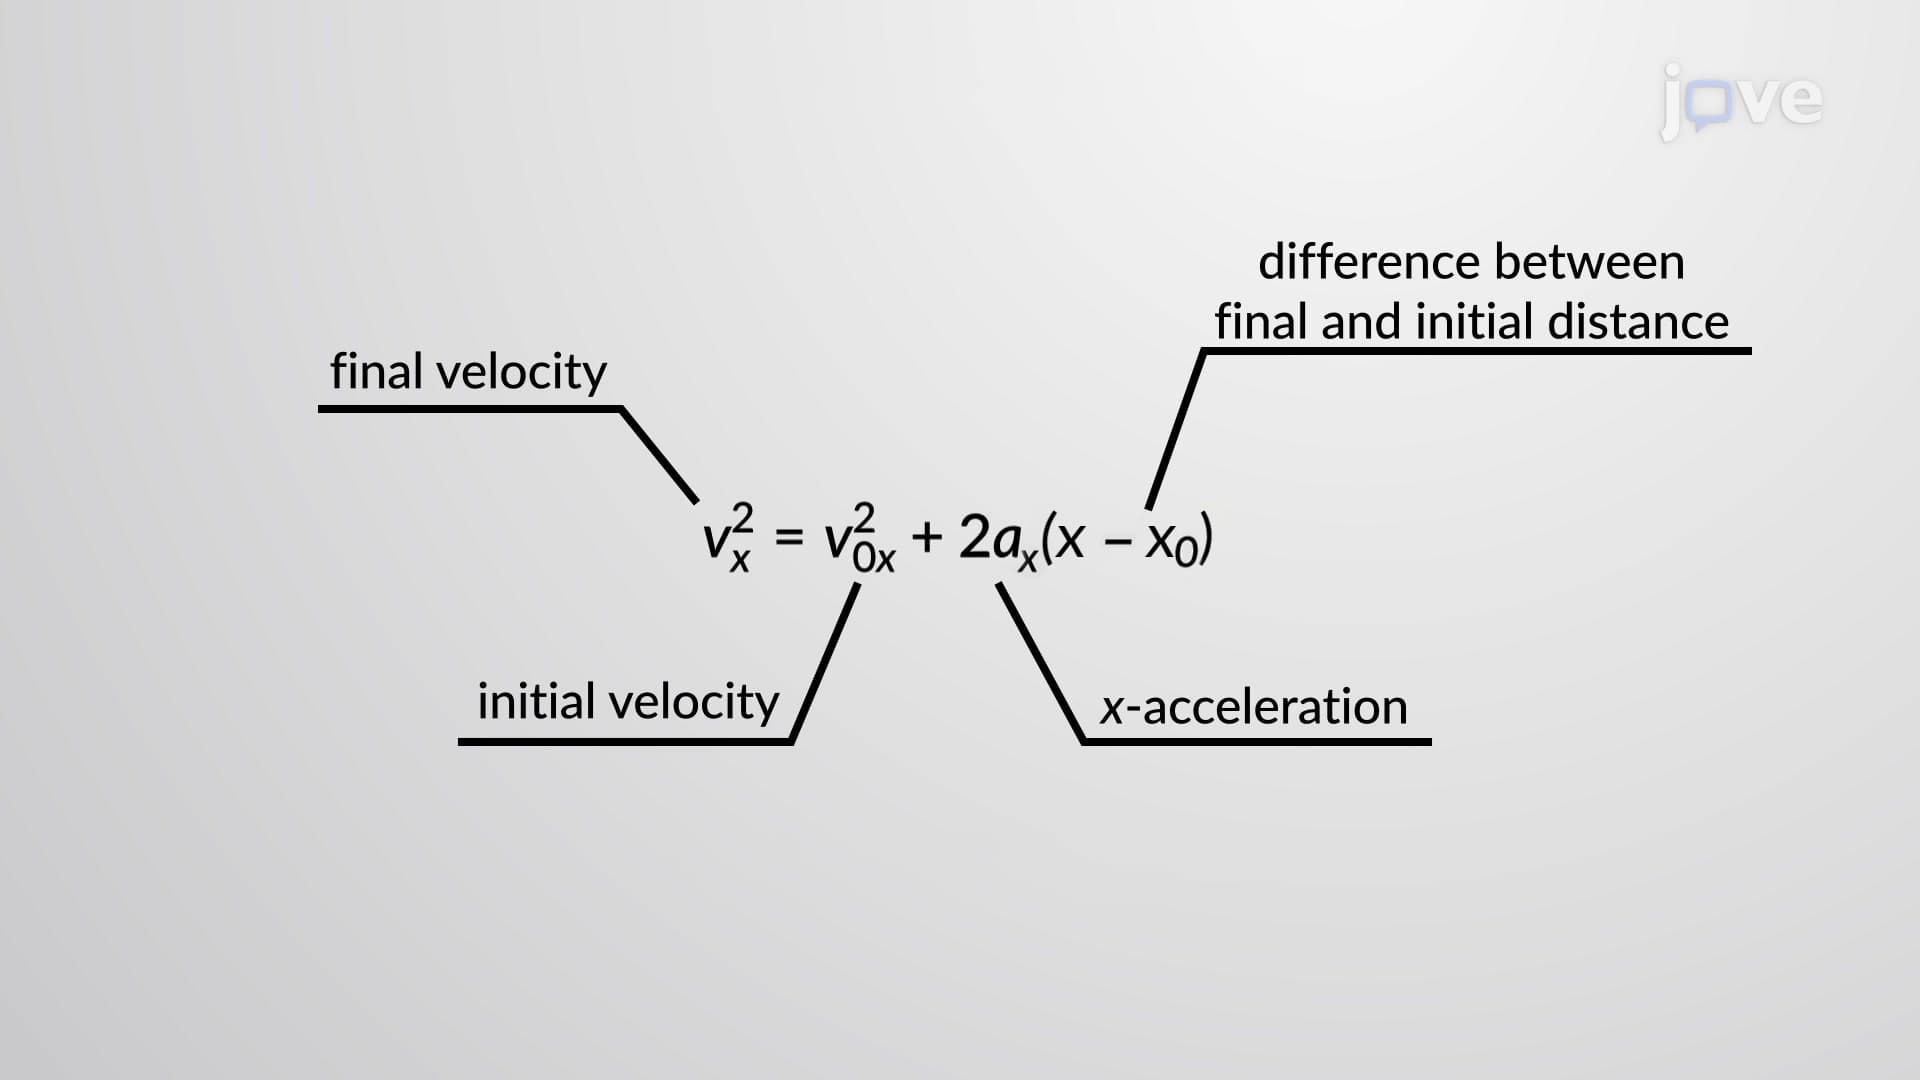
Kinematic Equations - III
Using the kinematic equations,...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
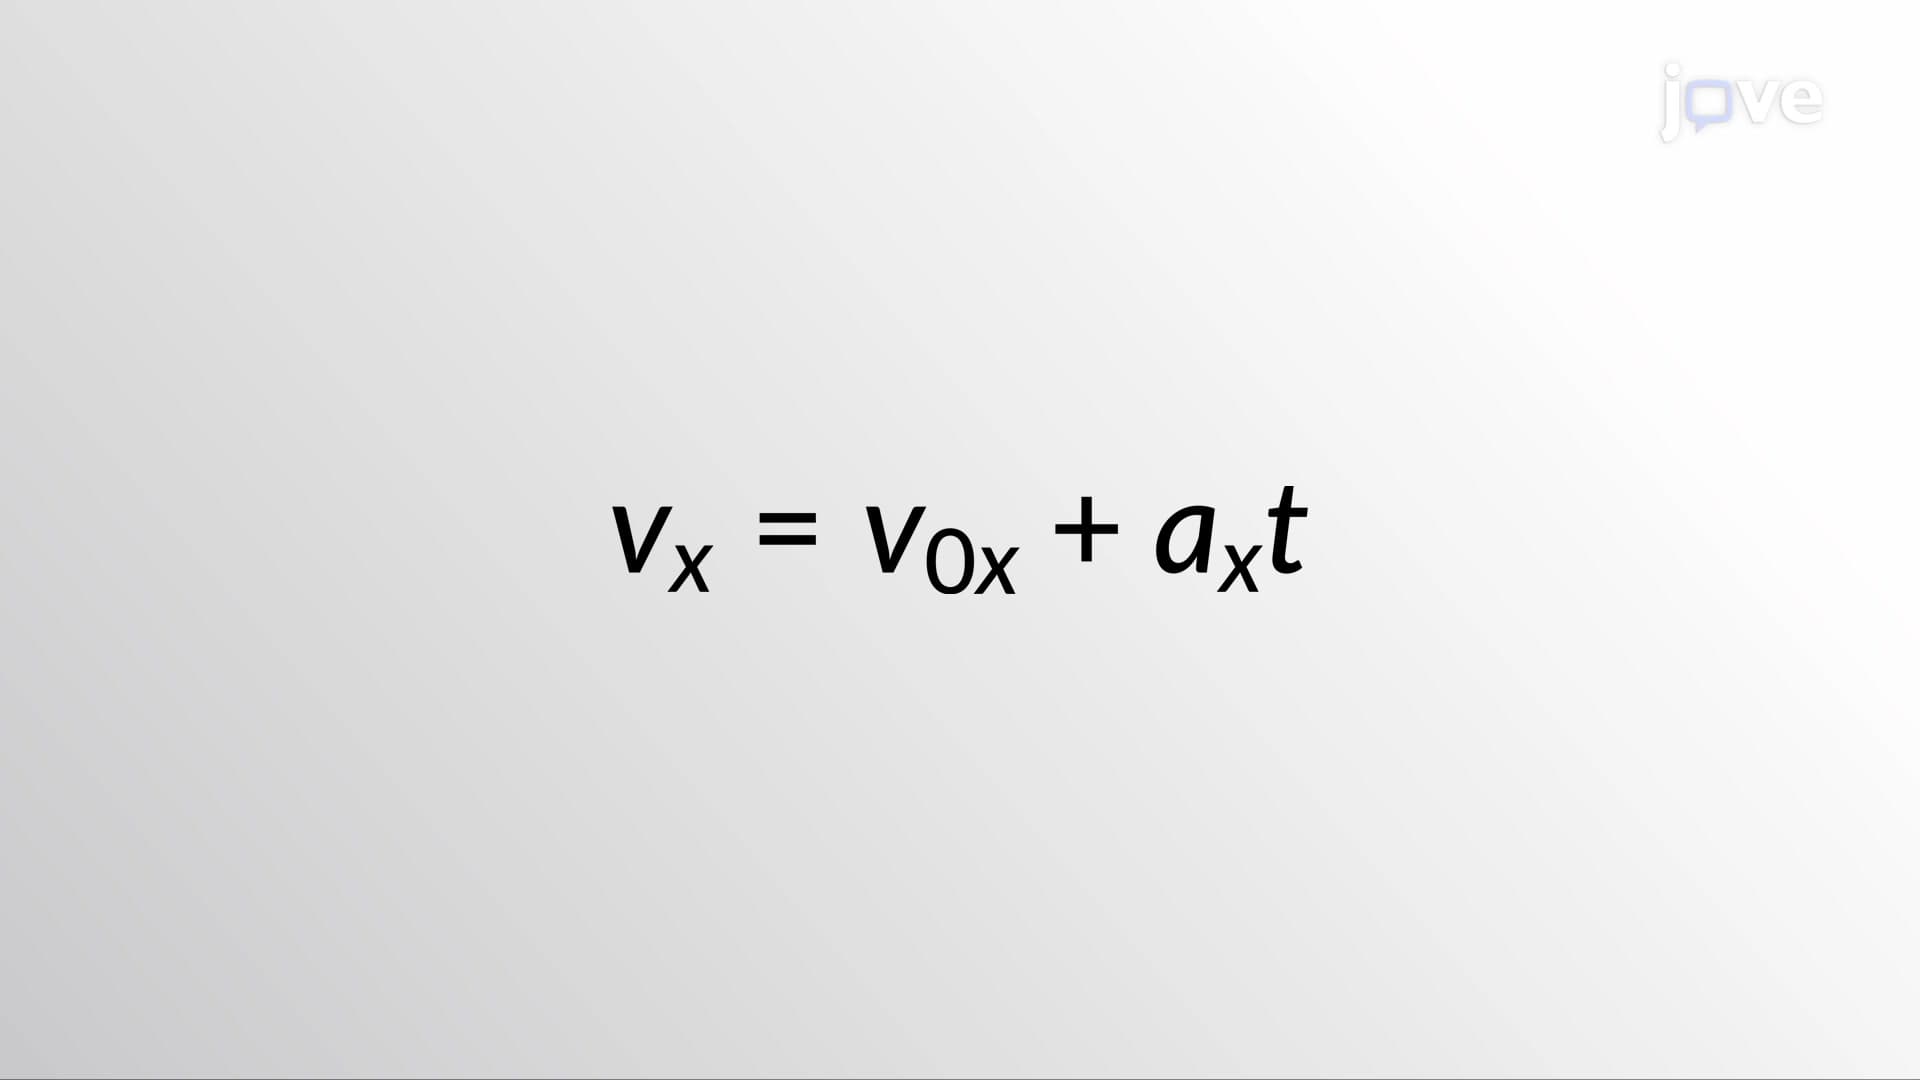 01:26
Kinematic Equations - I
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:31
Muscles that Move the Arm
The pectoralis major has two origins. Its clavicular head originates on the medial half of the clavicle. In contrast, the sternocostal head originates on the costal cartilages of ribs 1-6, the sternum, and the aponeurosis of the external oblique of the...