Related Experiment Video
Updated: Aug 18, 2026
Measurement of Coherence Decay in GaMnAs Using Femtosecond Four-wave Mixing
Published on: December 3, 2013
Time-domain modeling of nonlinear distortion of pulsed finite amplitude sound beams
J P Remenieras1, O Bou Matar, V Labat
1GIP ULTRASONS/LUSSI EA 2102, Tours, France. remenier@med.univ-tours.fr

Abstract:
This work aims to validate a time domain numerical model for the nonlinear propagation of a short pulse of finite amplitude sound beam propagation in a tissue-mimicking liquid. The complete evolution equation is simply derived by a superposition of elementary operators corresponding to the 'one effect equation'. Diffraction LD, absorption and dispersion LAD, and nonlinear distortion LNL effects are treated independently using a first order operator-splitting algorithm. Using the method of fractional steps, the normal particle velocity and the acoustical pressure are calculated plane by plane, at each point of a two-dimensional spatial grid, from the surface of the plane circular transducer to a specified distance. The LA operator is a time convolution between the particle velocity and the causal attenuation filter built after the Kramers-Kroning relations. The LNL operator is a time-based transformation obtained by following an implicit Poisson analytic solution. The LD operator is the usual Rayleigh integral. We present a comparison between theoretical and experimental temporal pressure waveform and axial pressure curves for fundamental (2.25 MHz), second, third and fourth harmonics, obtained after spectral analysis.
Related Concept Videos
 00:53
Sound Waves: Interference
 01:09
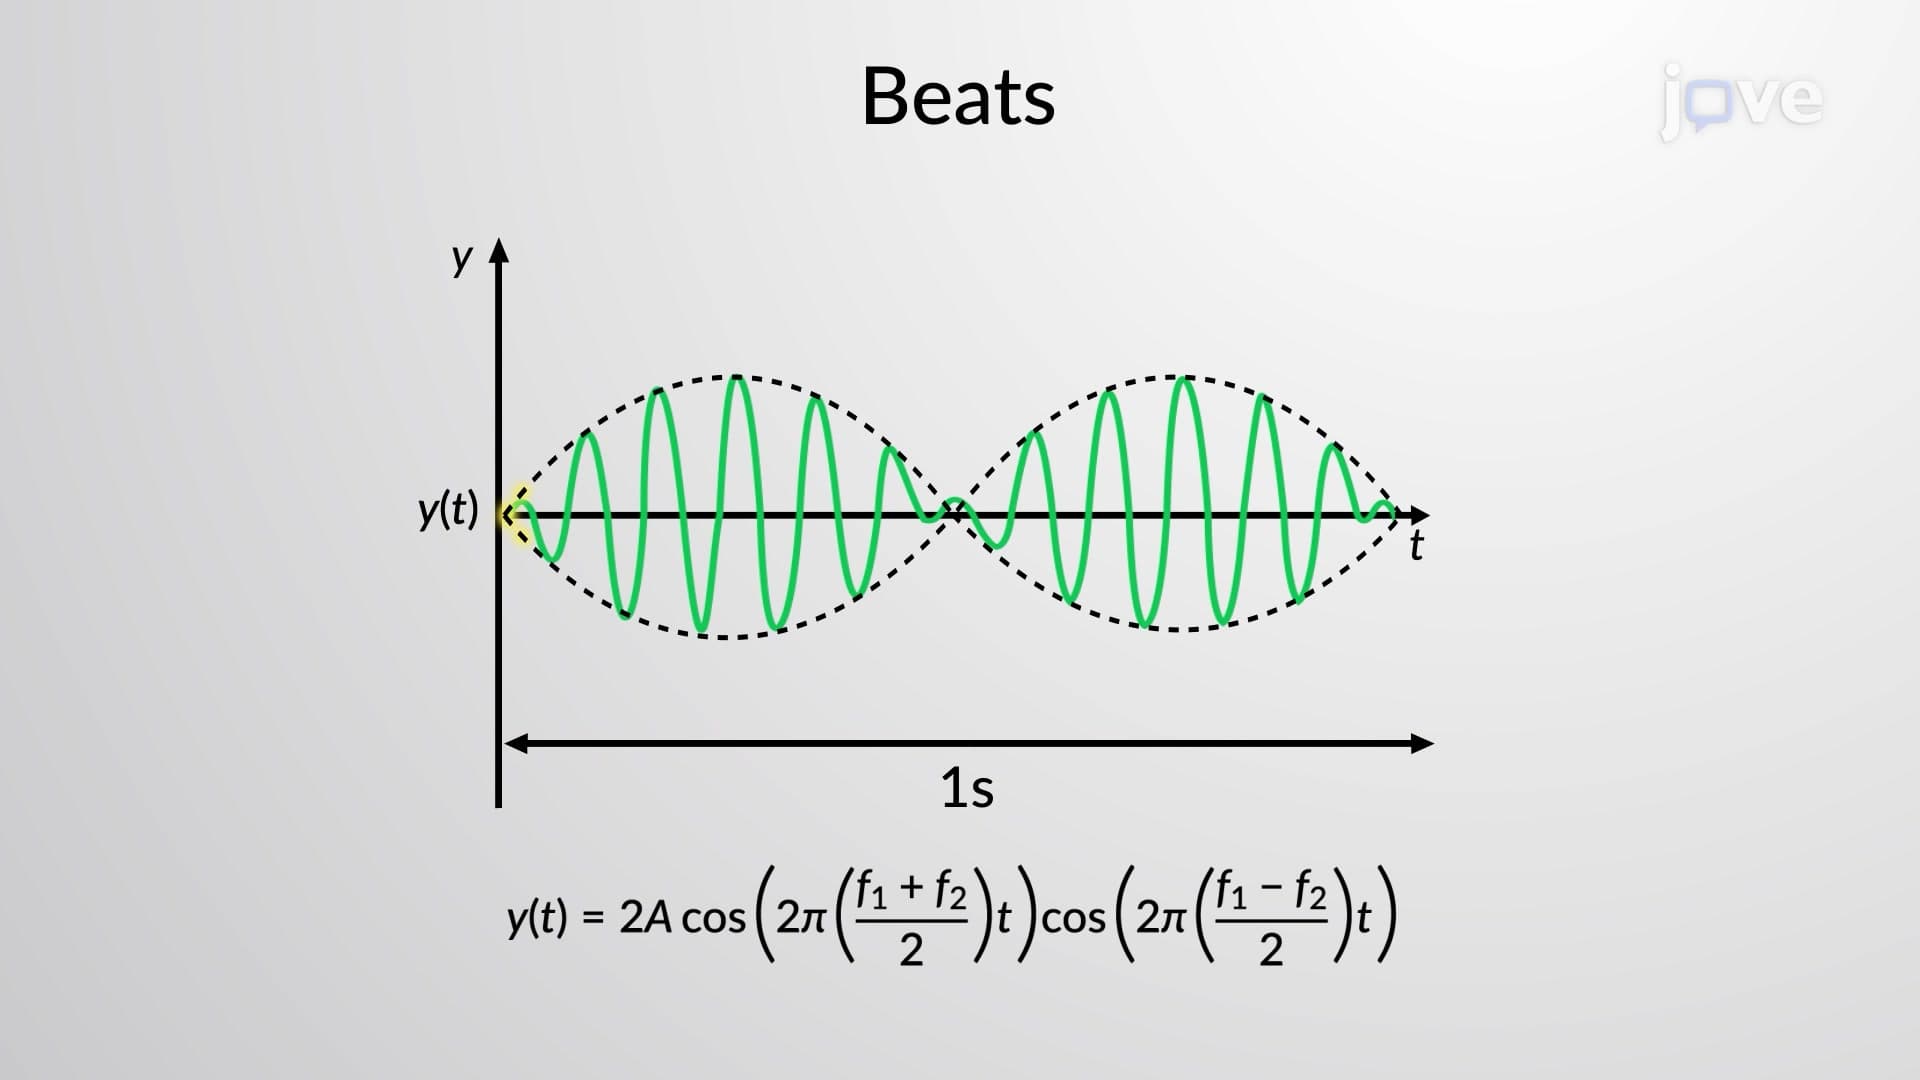
Beats
 01:18
Aliasing
If the sampling frequency is below the Nyquist rate, these replicas overlap, preventing the original signal...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any finite,...