Changes in movement variables associated with transient overshoot of the final position

S Milanovic1, S Blesic, S Jaric

  • 1Institute for Medical Research, Belgrade, Yugoslavia.

Journal of Motor Behavior
|September 27, 2000
PubMed

Related Concept Videos

Time-Domain Interpretation of PD Control01:07

Time-Domain Interpretation of PD Control

Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...

Kinematic Equations - II01:17

Kinematic Equations - II

The second kinematic equation expresses the final position of an object in terms of its initial position, the distance traveled with the initial constant velocity, and the distance traveled due to a change in velocity. Similar to the first kinematic equation, this equation is also only valid when the acceleration is constant throughout the motion of an object.
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
Instantaneous Velocity - II01:10

Instantaneous Velocity - II

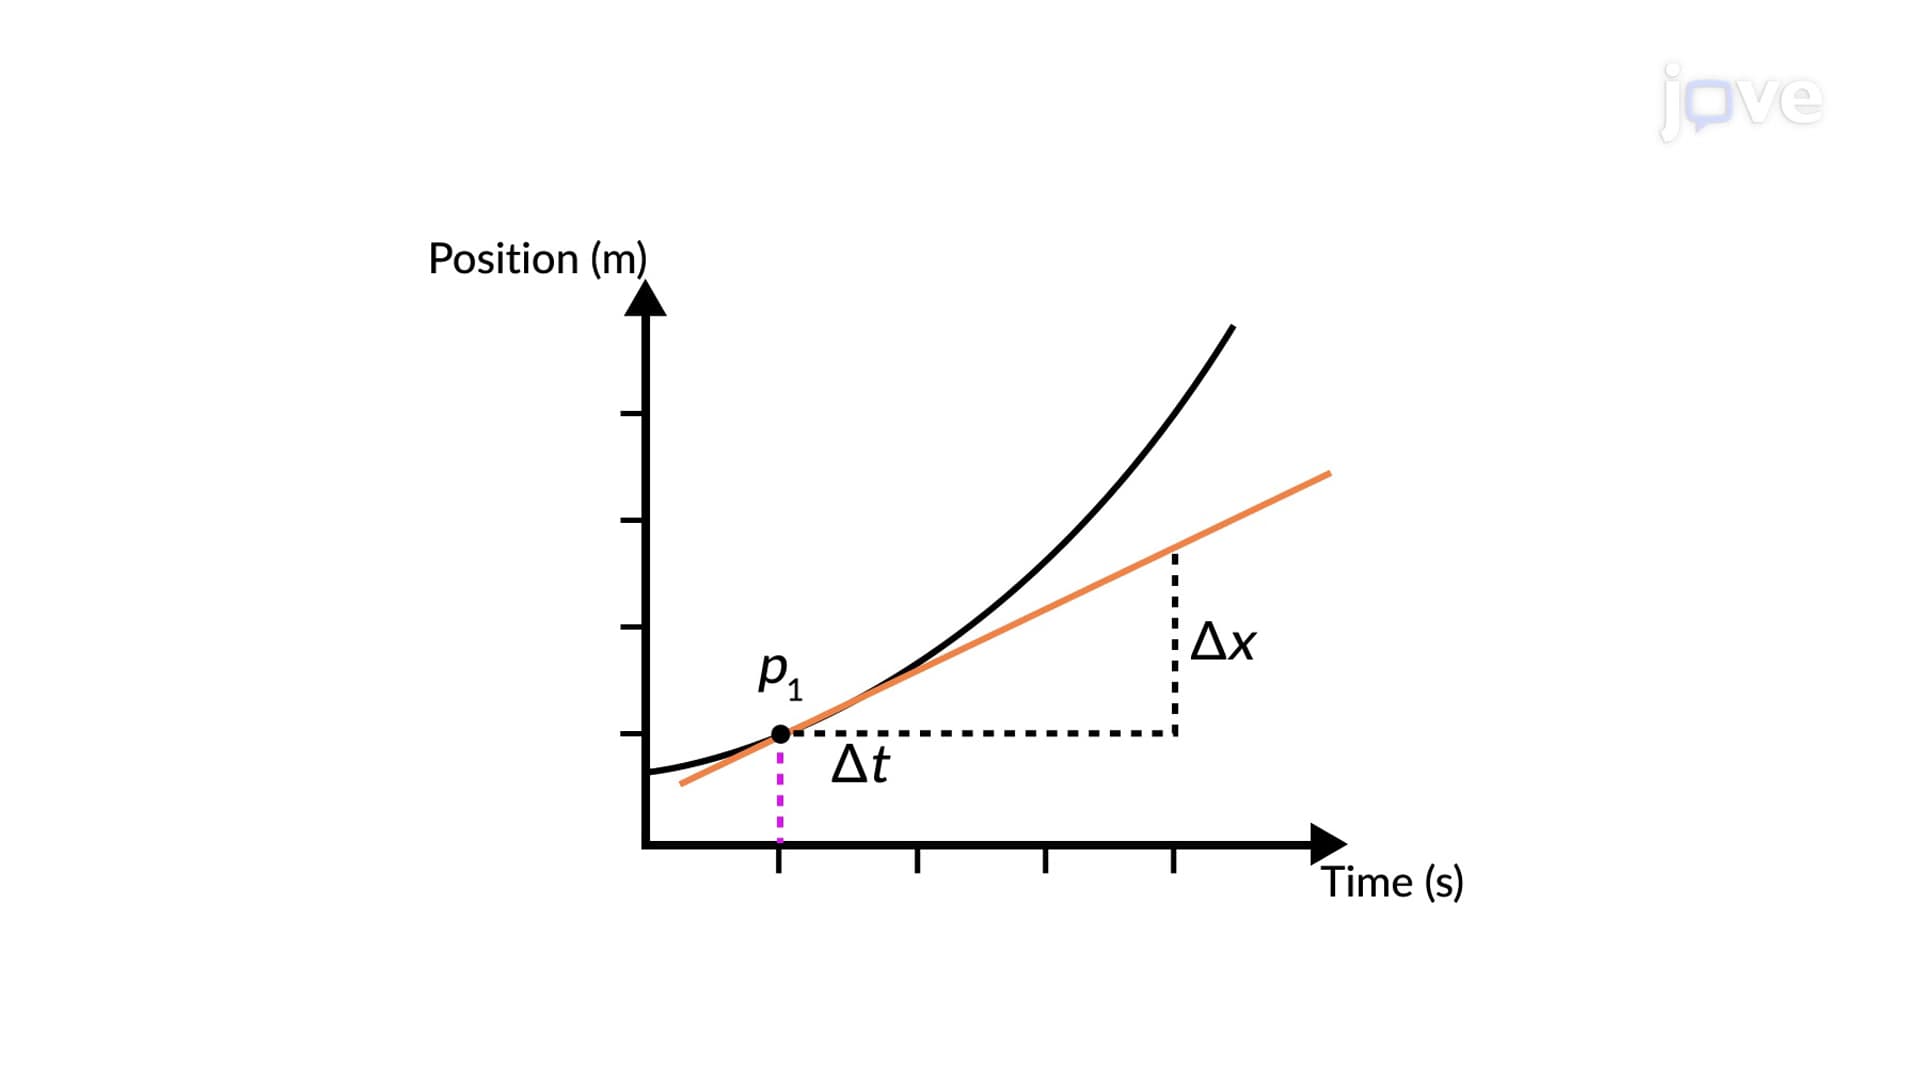
Instantaneous velocity is the quantity that measures how fast an object is moving along its path. In other words, the instantaneous velocity of an object is the limit of the average velocity as the elapsed time approaches zero, or the derivative of displacement with respect to time. Like average velocity, the instantaneous velocity is a vector with the dimensions of length per unit time. Instantaneous velocity can have both positive and negative values. The instantaneous velocity can be...
Derivatives of Inverse Trigonometric Functions01:30

Derivatives of Inverse Trigonometric Functions

A ship tracking an approaching aircraft relies on geometric measurements to find out the aircraft’s position relative to the observer. By measuring the slant distance to the aircraft and the angle of elevation, the horizontal and vertical components of the distance can be obtained using trigonometric relationships. This geometric approach provides a basis for analyzing how the observed angle changes as the aircraft moves closer to the ship.To examine the mathematical behavior of the angle of...
Velocity and Position by Graphical Method01:34

Velocity and Position by Graphical Method

Velocity and position can be calculated from the known function of acceleration as a function of time. The total area under the acceleration-time graph and the velocity-time graph gives the change in velocity and position, respectively. In the case of an airplane, its acceleration is tracked using the inertial navigation system. The pilot provides the input of the airplane's initial position and velocity before takeoff. The inertial navigation system then uses the acceleration data to calculate...
Vector Functions and Motion: Problem Solving01:30

Vector Functions and Motion: Problem Solving

Accurate position tracking is fundamental to the safe and effective operation of unmanned aerial vehicles (UAVs), particularly during precision maneuvers near complex structures. In this scenario, a drone is programmed to perform a high-precision inspection of a vertical structure, starting at position ((x, y, z) = (3, 0, 0)), with an initial velocity oriented in the positive z-direction. The trajectory of the drone is governed by a time-dependent acceleration function a(t), which is predefined...