Related Experiment Video
Updated: Oct 11, 2026
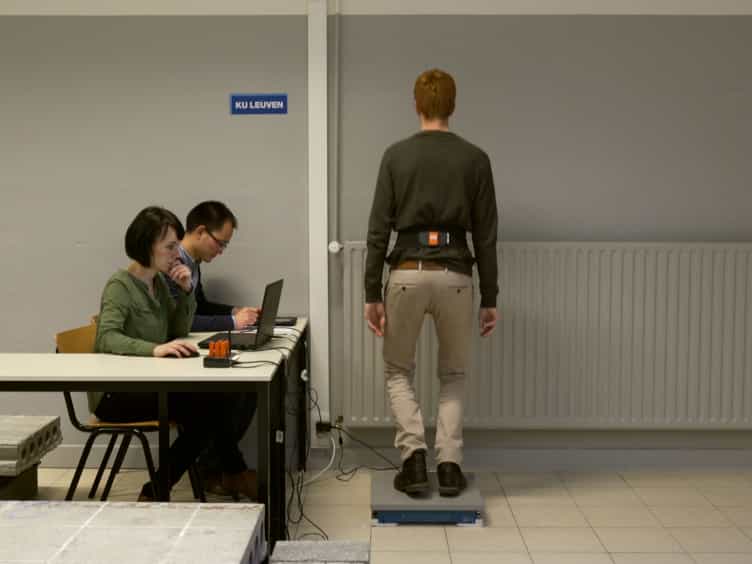
Simulation of Human-induced Vibrations Based on the Characterized In-field Pedestrian Behavior
Published on: April 13, 2016
A robotic manipulator for the characterization of two-dimensional dynamic stiffness using stochastic displacement
A M Acosta1, R F Kirsch, E J Perreault
1Department of Biomedical Engineering, Case Western Reserve University, Cleveland, Ohio 44106, USA.

Abstract:
Experimental techniques for estimating the two-dimensional dynamic stiffness of the human arm over a wide range of conditions have been developed. A robotic manipulator has been developed to create loads against which subjects perform various tasks and also to impose perturbations onto the endpoint of the arm to allow estimation of its mechanical properties. The manipulator can produce static endpoint forces exceeding 220 N in any direction in its plane of motion, and this plane can be vertically translated and tilted over wide ranges to study arm dynamic stiffness in many functionally relevant planes. It can impose stochastic position and force perturbations whose bandwidth exceeds that of the arm. These random perturbations avoid undesirable volitional reactions and allow the efficient estimation of stiffness dynamics using experimental trials of short duration. The ability of this manipulator to characterize inertial-viscoelastic systems was tested using several two-dimensional physical systems whose properties were independently characterized. The endpoint dynamic stiffness properties of a human arm were estimated as an example of the use of the manipulator in studying upper limb mechanical properties. The system properties characterized by these methods will be useful in probing normal neural arm control strategies and in developing rehabilitation interventions to improve arm movements in disabled individuals.

Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:20
Two-Dimensional Force System
 01:14
Stability of structures
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...