Related Experiment Video
Updated: Oct 11, 2026
A Real-Time Interactive System for Studying Confrontational Pursuit Behavior in Rodents
Published on: May 16, 2025
Distribution of escape times for a deterministically driven bistable system
1Area de Fisica Teorica, Universidad de Sevilla, Apartado Correos 1065, 41080 Sevilla, Spain.

Abstract:
In this paper, we analyze the sequence of escape times for a particle in a symmetric double-well potential coupled to a chain of monodimensional oscillators and we find that, in some range of energies, the probability of escape exhibits the multimodal form that is characteristic of bistable systems driven by a periodic signal embedded in noise. We identify two different modes contributing to the overall hopping dynamics of the particle, each one having a definite dependence on the energy of the chain. Those findings suggest a model for internal fluctuations that could be useful in the study of some problems of interest in physics and biology.
Related Concept Videos
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system.
 01:31
Classification of Systems-II
 01:18
Second Order systems II
If ζ...
 01:28
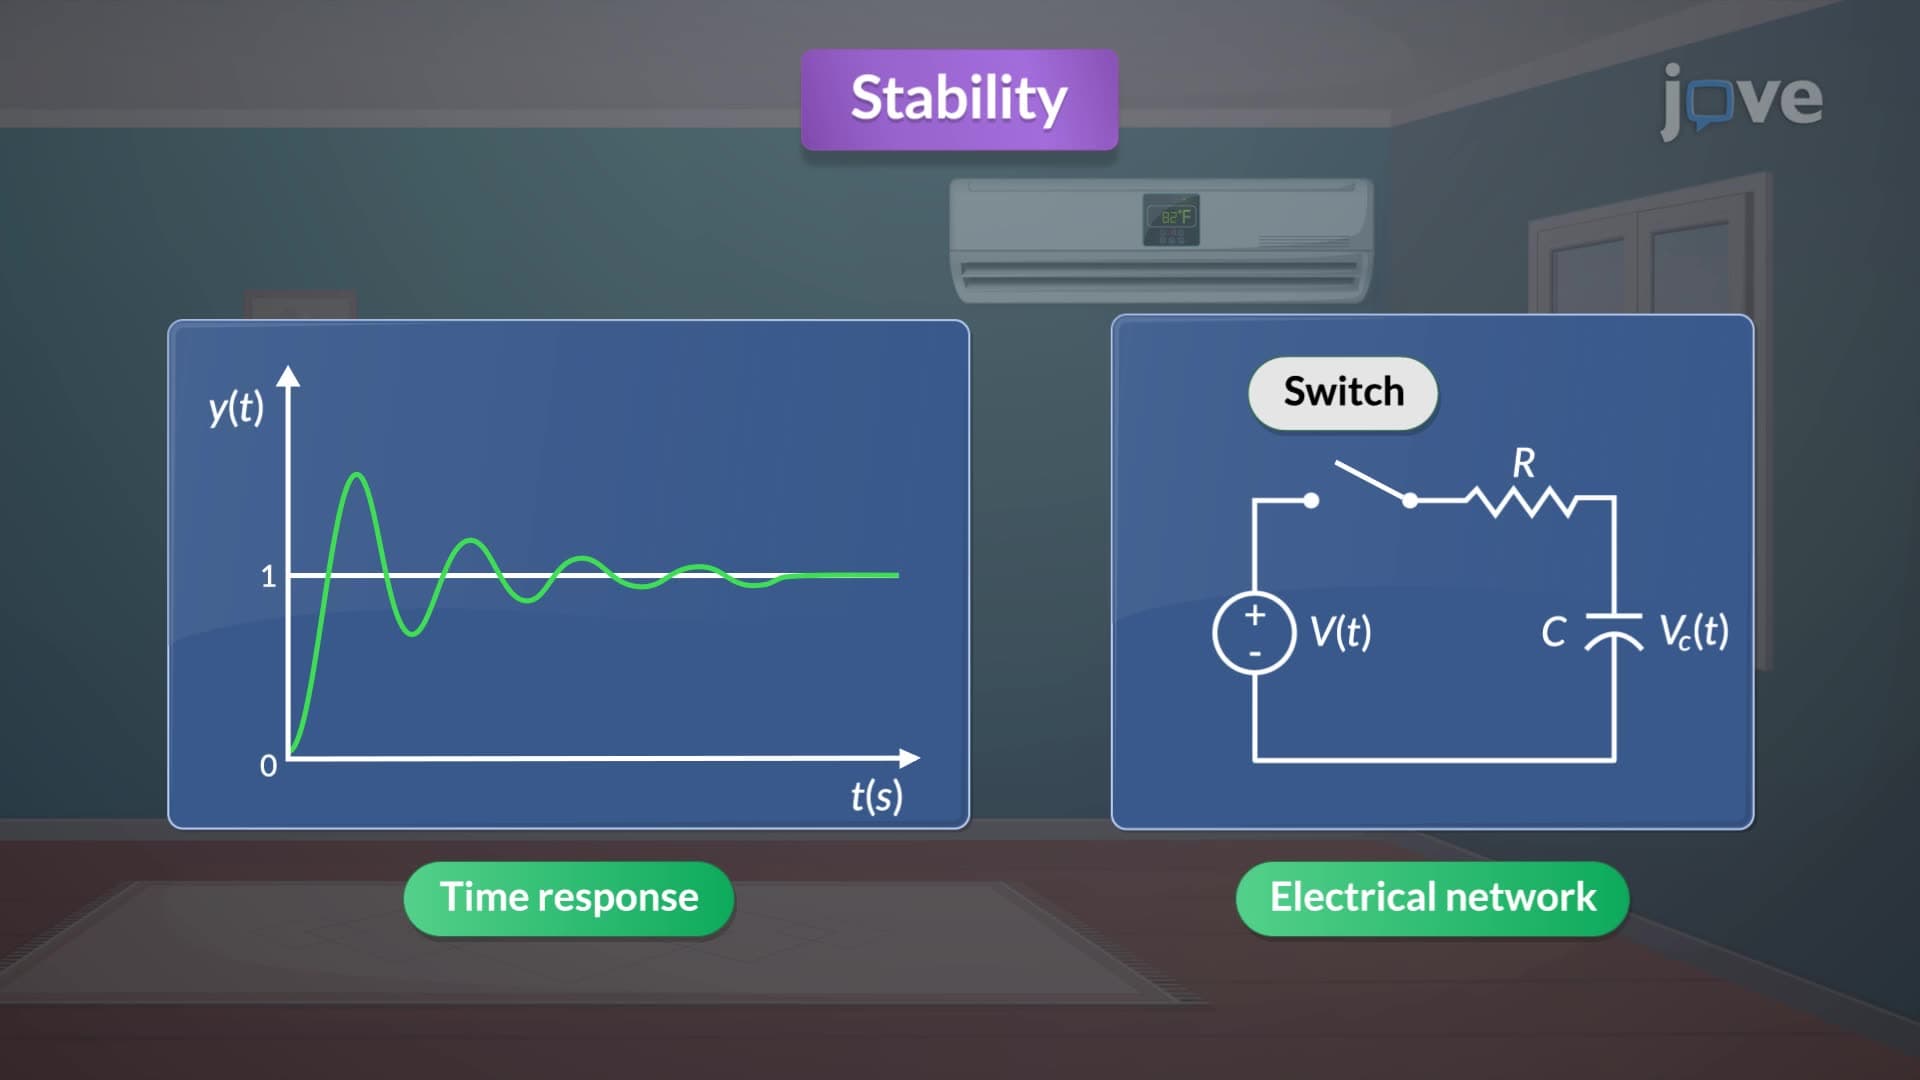
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:21
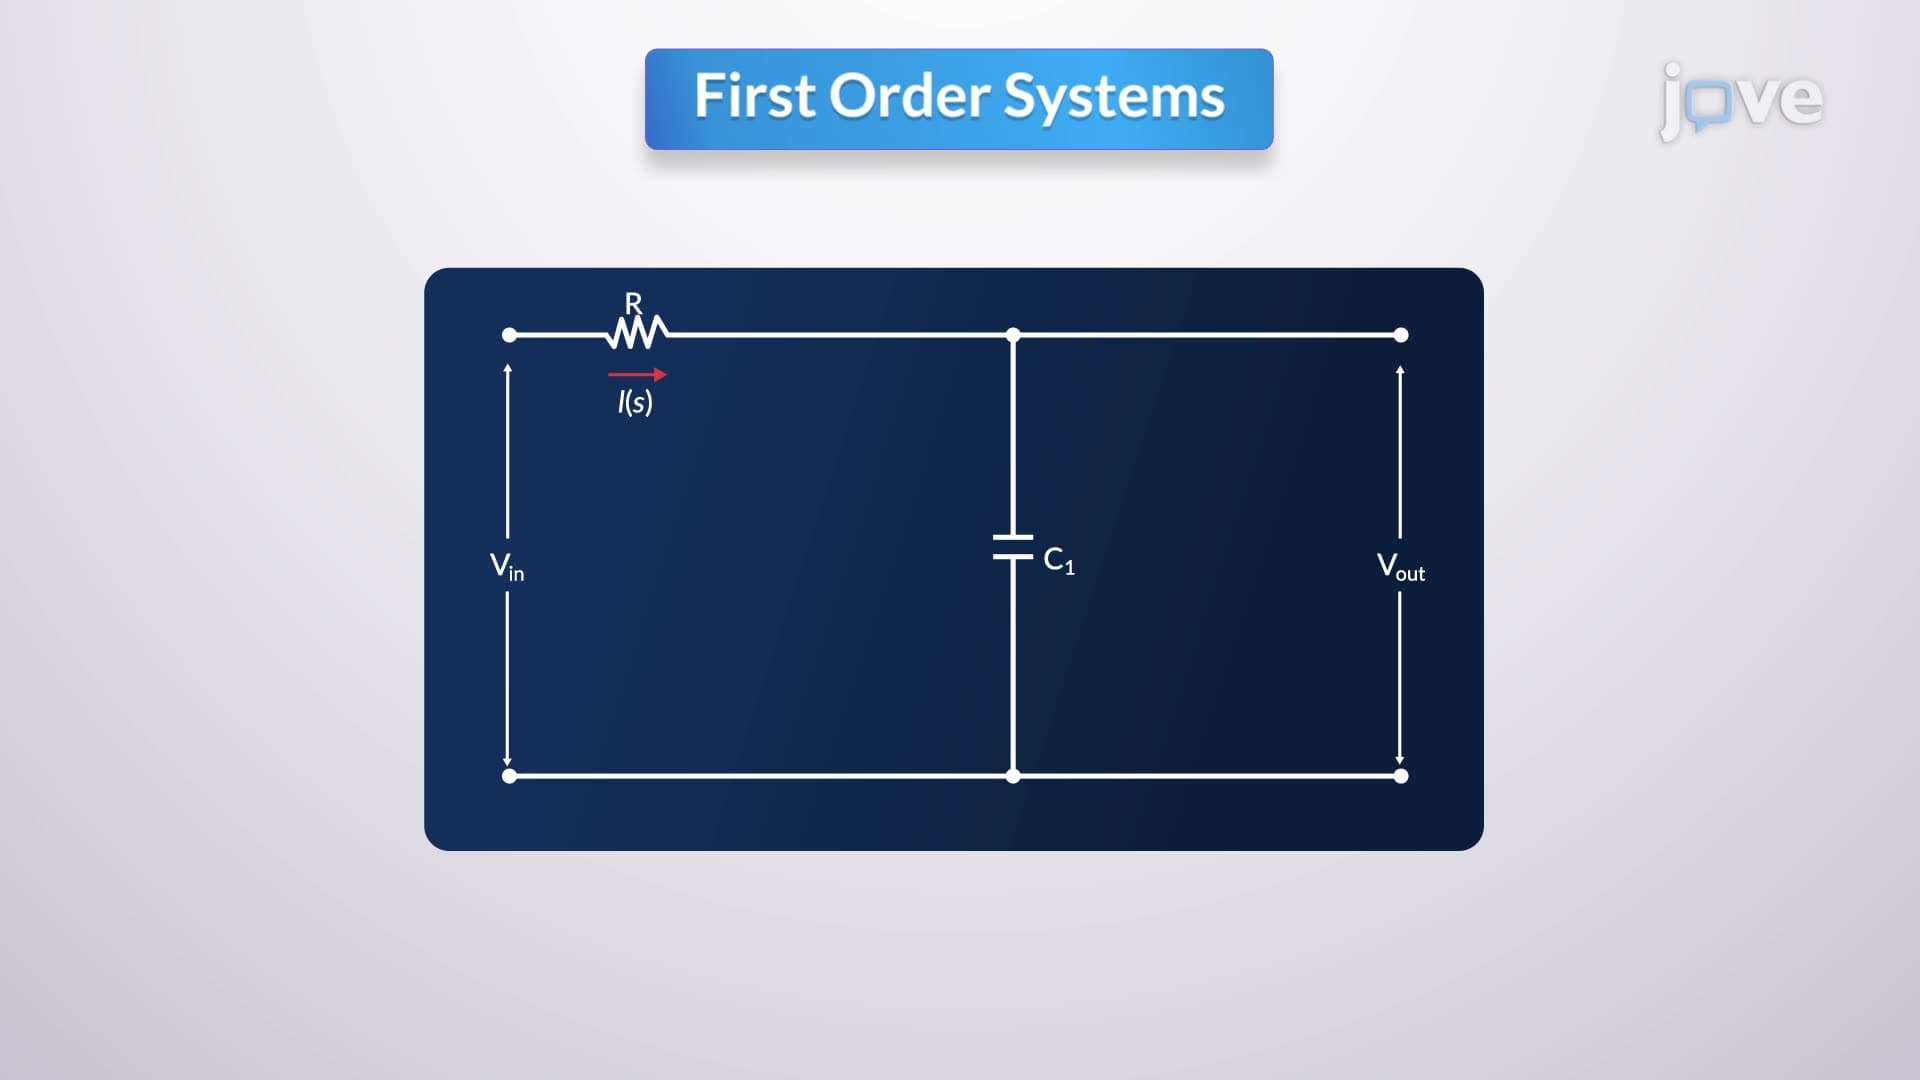
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:14
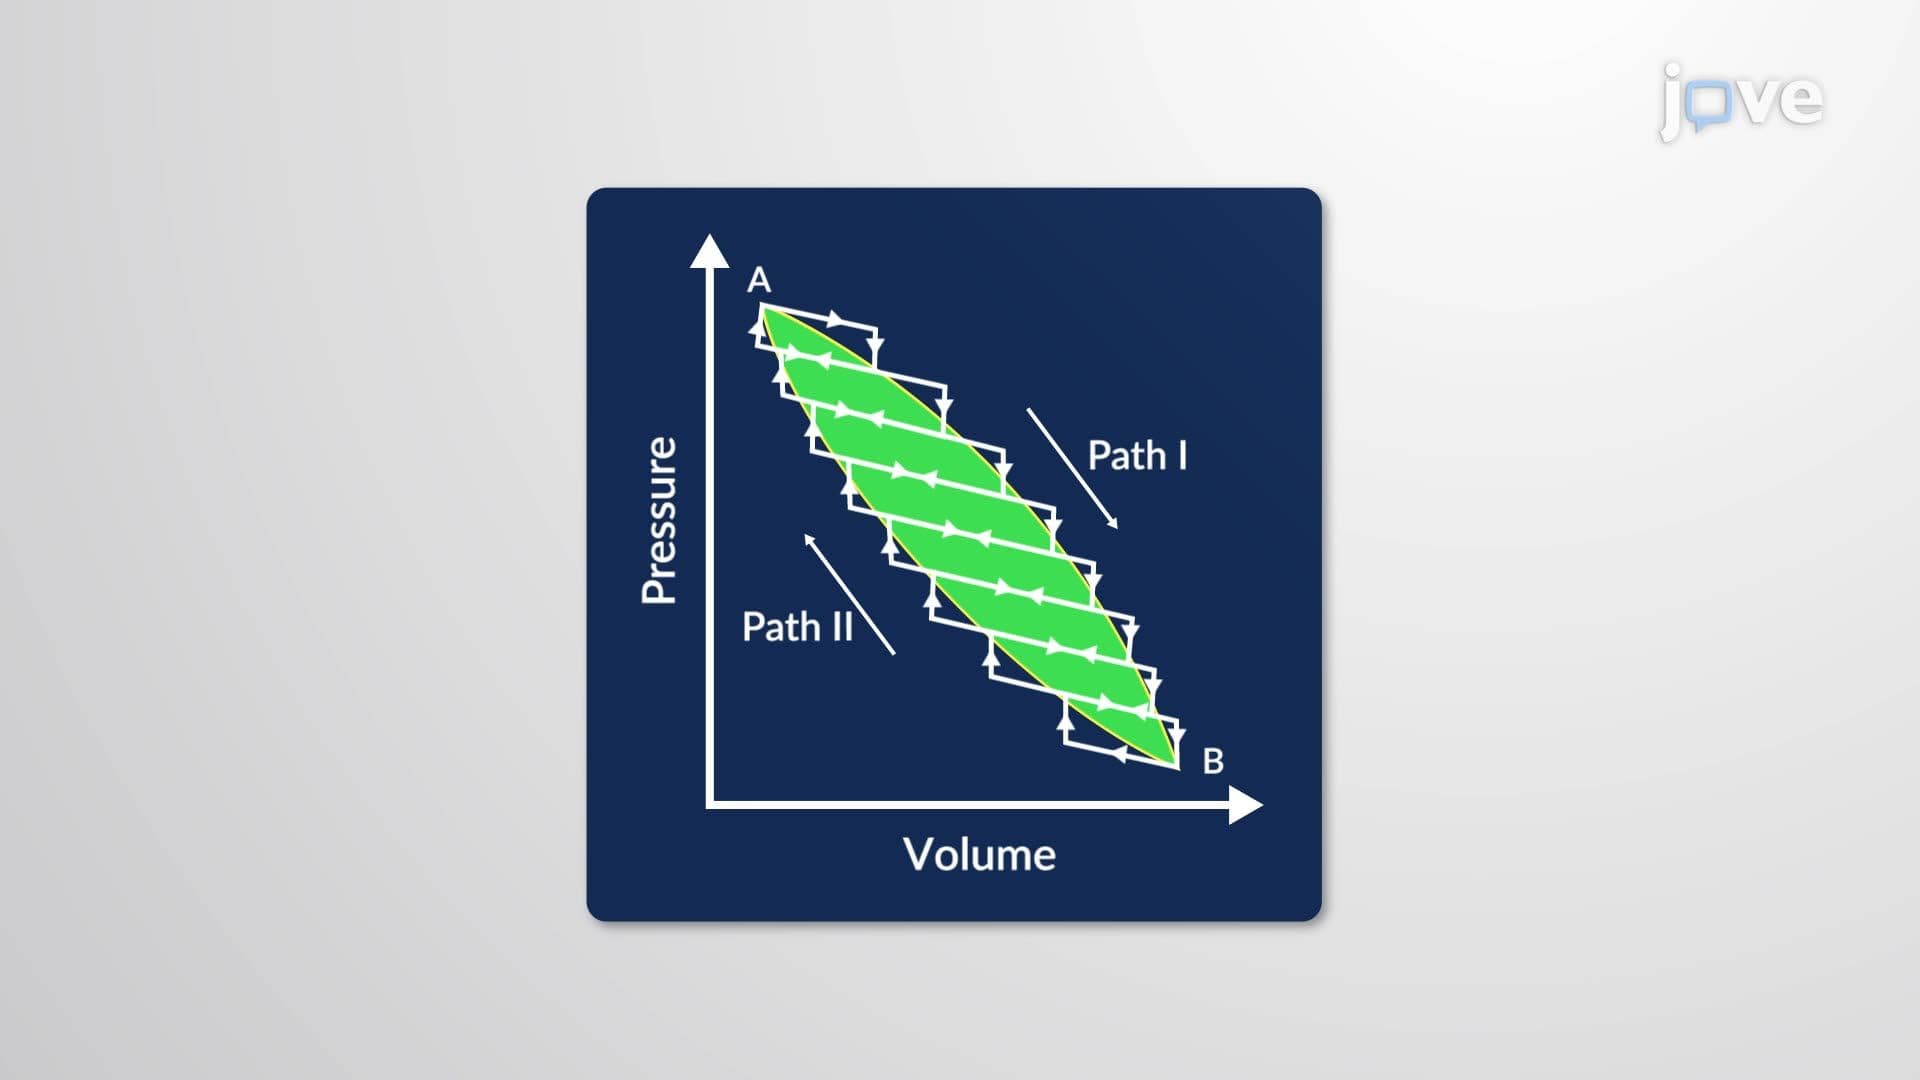
The Entropy as a State Function