Scaling of lyapunov exponents of coupled chaotic systems

Zillmer1, Ahlers, Pikovsky

  • 1Department of Physics, University of Potsdam, Postfach 601553, D-14415 Potsdam, Germany.

Related Concept Videos

Scaling01:26

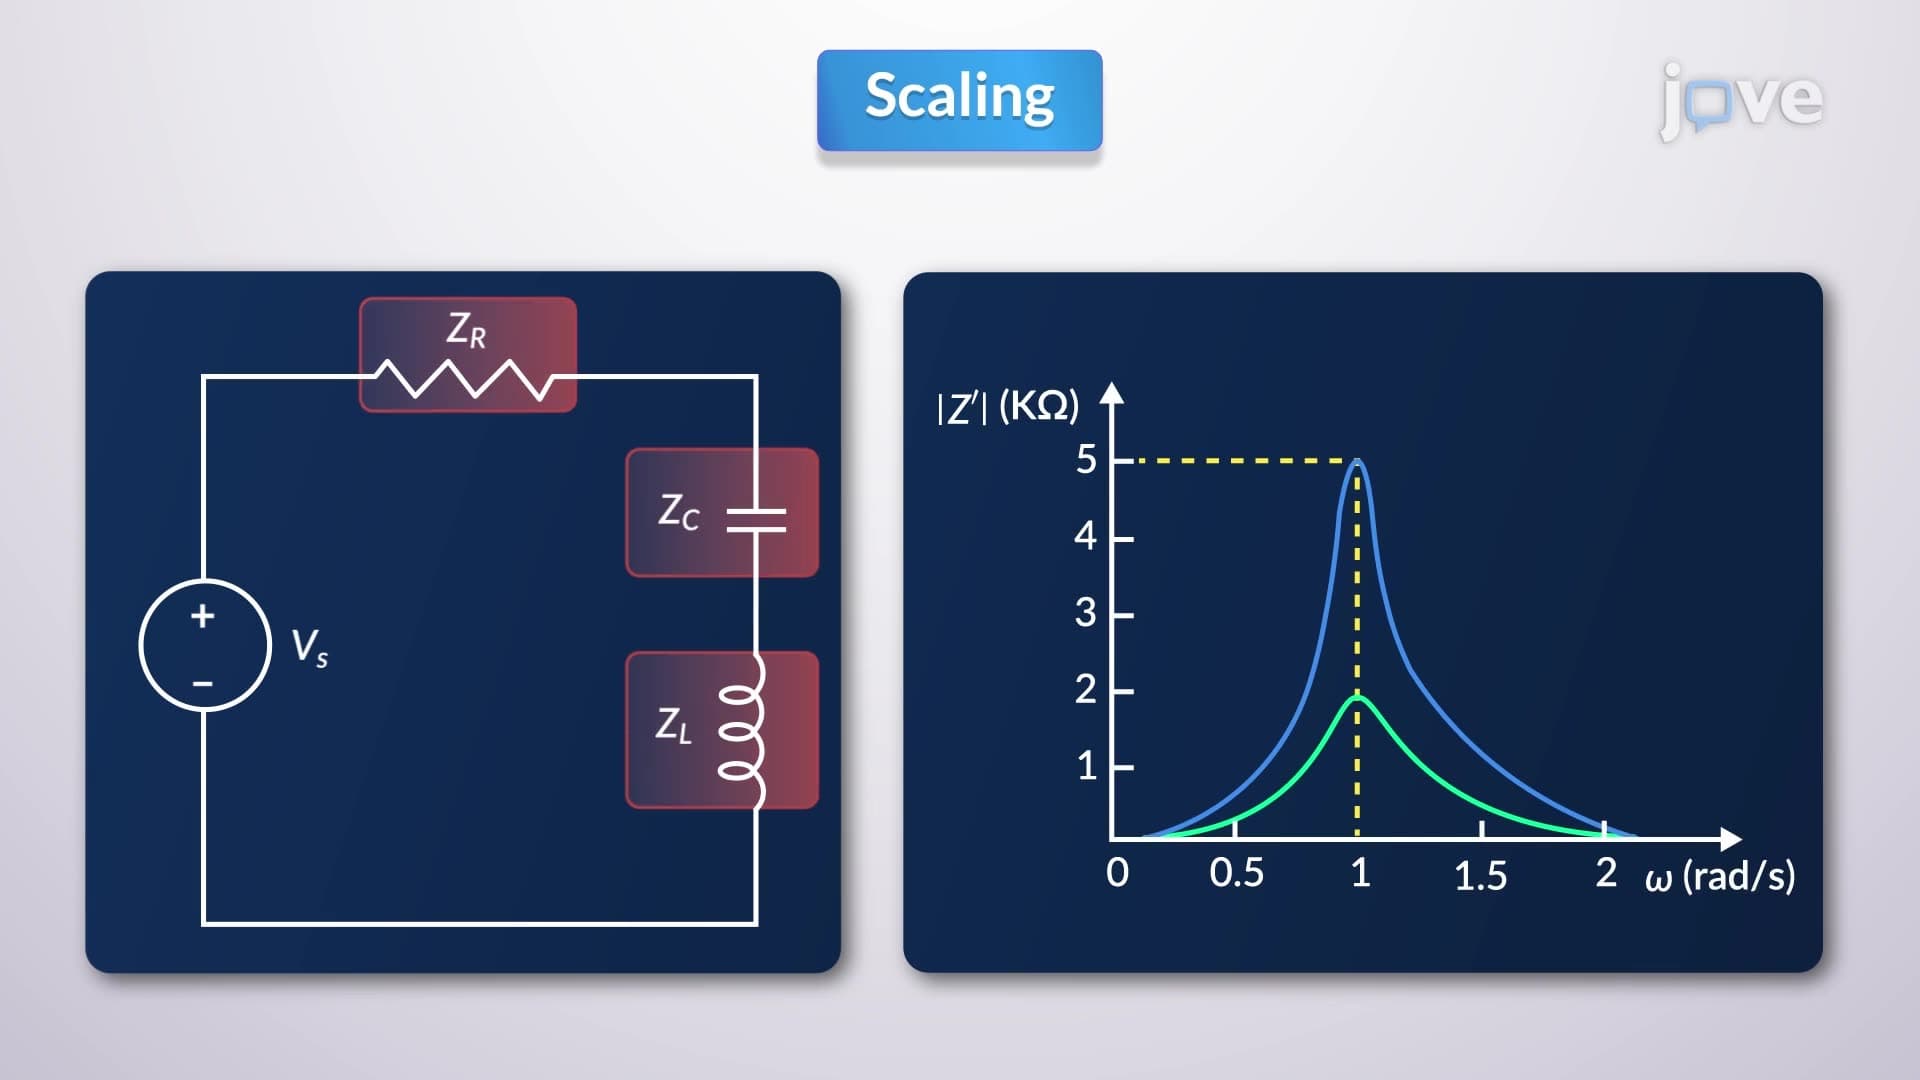
Scaling

In designing and analyzing filters, resonant circuits, or circuit analysis at large, working with standard element values like 1 ohm, 1 henry, or 1 farad can be convenient before scaling these values to more realistic figures. This approach is widely utilized by not employing realistic element values in numerous examples and problems; it simplifies mastering circuit analysis through convenient component values. The complexity of calculations is thereby reduced, with the understanding that...
Linear Approximation in Frequency Domain01:26

Linear Approximation in Frequency Domain

Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
Linear Approximation in Time Domain01:21

Linear Approximation in Time Domain

Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...

Second Order systems I01:20

Second Order systems I

A servo system exemplifies a second-order system, featuring a proportional controller and load elements that ensure the output position aligns with the input position. The relationship between these components is described by a second-order differential equation. Applying the Laplace transform under zero initial conditions yields the transfer function, showing how inputs are converted to outputs in the system.
By reinterpreting the system, one can derive the closed-loop transfer function, which...
Second Order systems II01:18

Second Order systems II

In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
If  ζ...
Plotting and Calibrating the Root Locus01:19

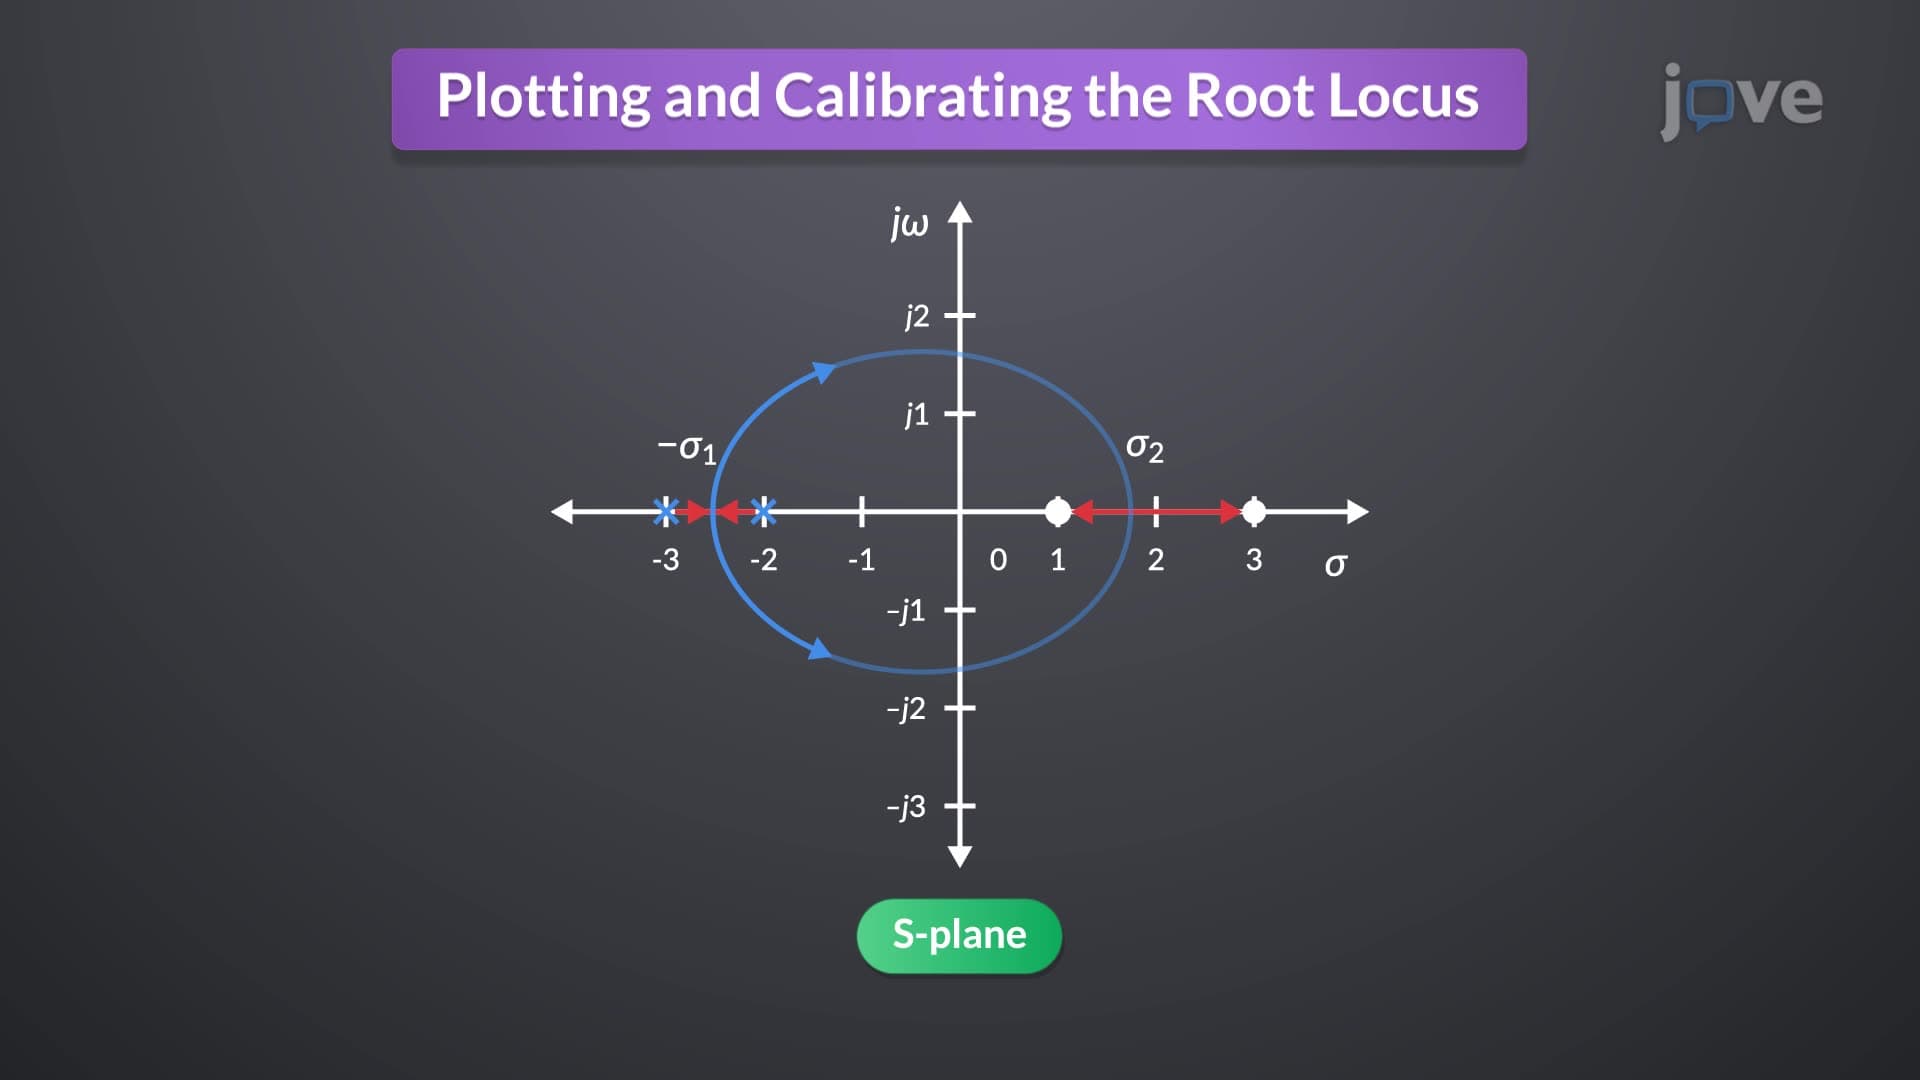
Plotting and Calibrating the Root Locus

Root loci often diverge as system poles shift from the real axis to the complex plane. Key points in this transition are the breakaway and break-in points, indicating where the root locus leaves and reenters the real axis. The branches of the root locus form an angle of 180/n degrees with the real axis, where n is the number of branches at a breakaway or break-in point.
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is observed...