Related Experiment Video
Updated: Oct 10, 2026
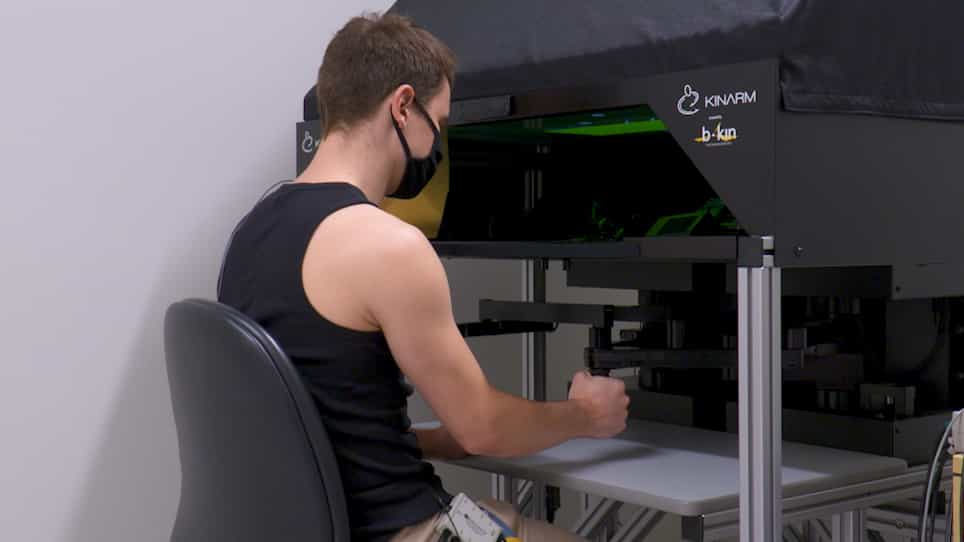
An Emerging Target Paradigm to Evoke Fast Visuomotor Responses on Human Upper Limb Muscles
Published on: August 25, 2020
Forward modeling allows feedback control for fast reaching movements

Abstract:
Delays in sensorimotor loops have led to the proposal that reaching movements are primarily under pre-programmed control and that sensory feedback loops exert an influence only at the very end of a trajectory. The present review challenges this view. Although behavioral data suggest that a motor plan is assembled prior to the onset of movement, more recent studies have indicated that this initial plan does not unfold unaltered, but is updated continuously by internal feedback loops. These loops rely on a forward model that integrates the sensory inflow and motor outflow to evaluate the consequence of the motor commands sent to a limb, such as the arm. In such a model, the probable position and velocity of an effector can be estimated with negligible delays and even predicted in advance, thus making feedback strategies possible for fast reaching movements. The parietal lobe and cerebellum appear to play a crucial role in this process. The ability of the motor system to estimate the future state of the limb might be an evolutionary substrate for mental operations that require an estimate of sequelae in the immediate future.

Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:18
Hierarchy of Motor Control
 01:15
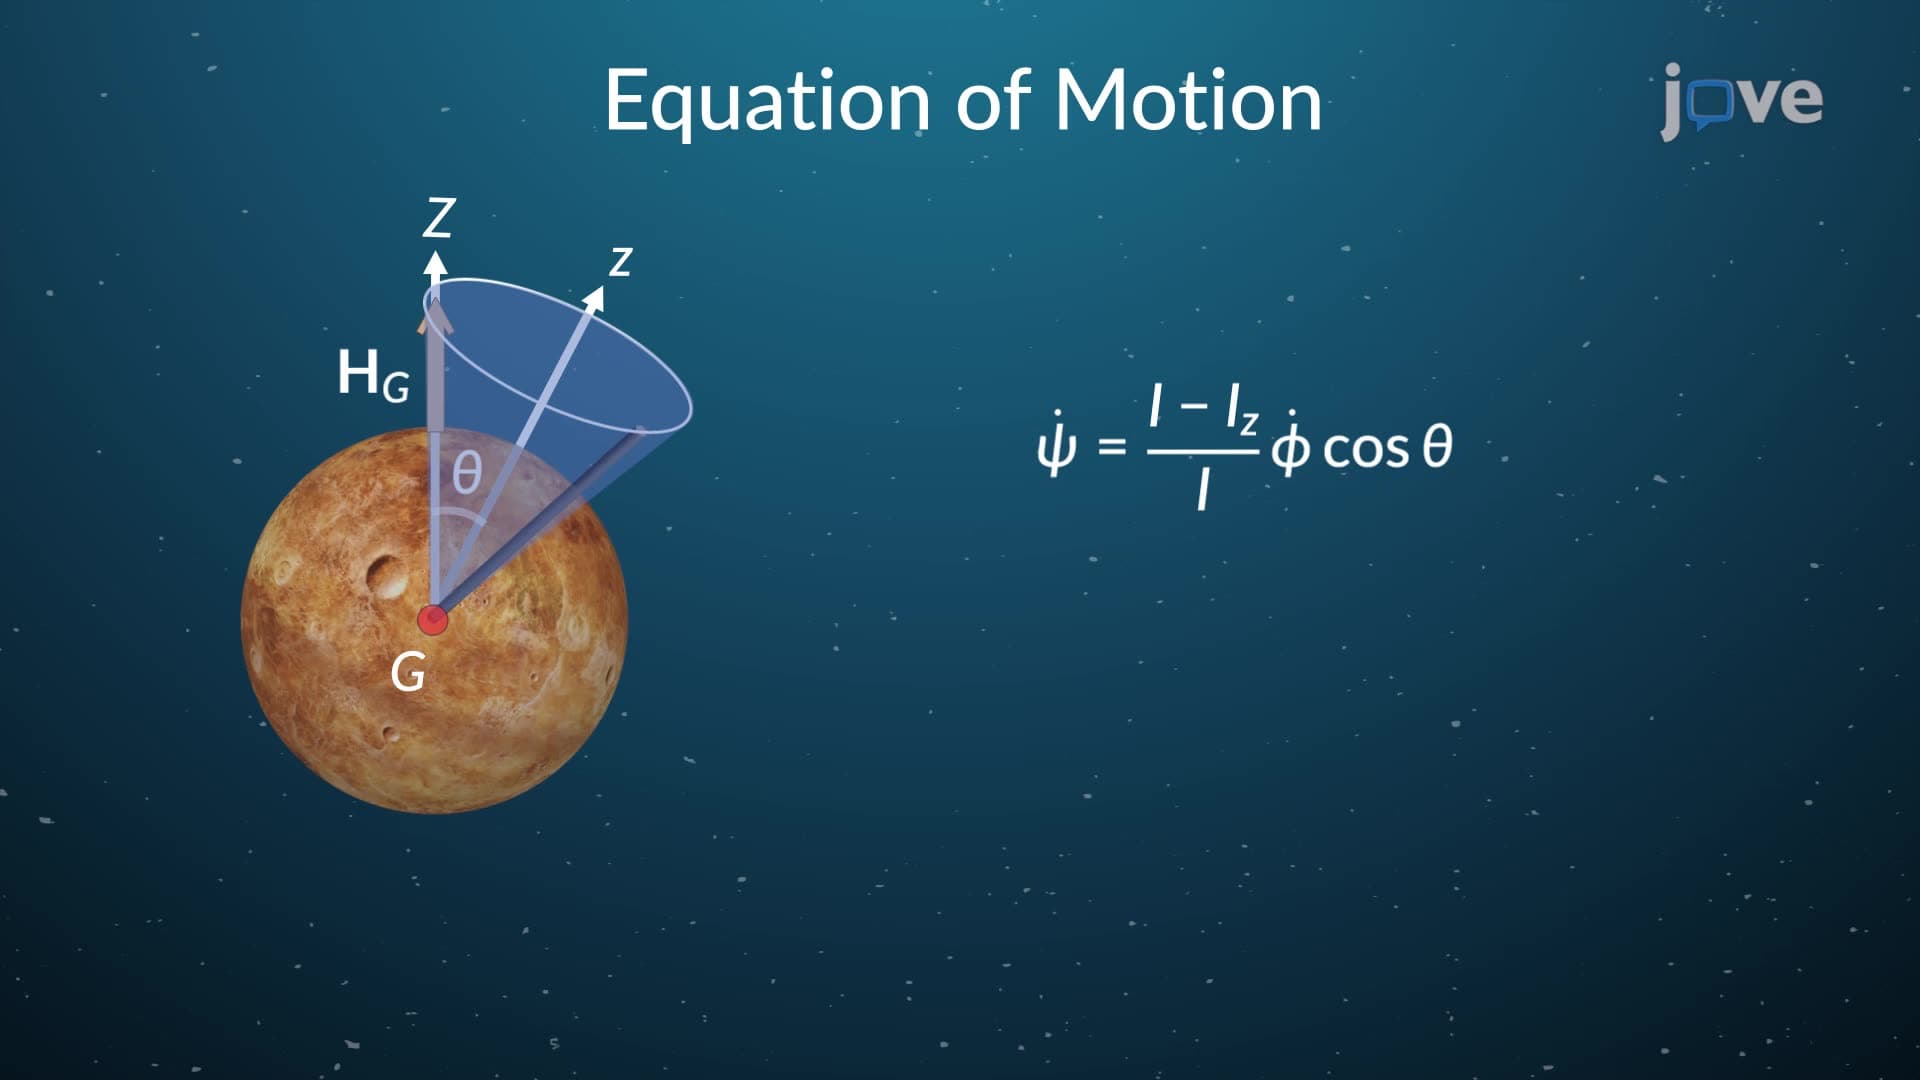
Torque Free Motion
 01:31
Hand Control During Infancy and Toddlerhood
 01:30
Motor Skills Development During Early Childhood
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...