Related Experiment Video
Updated: Jul 26, 2026
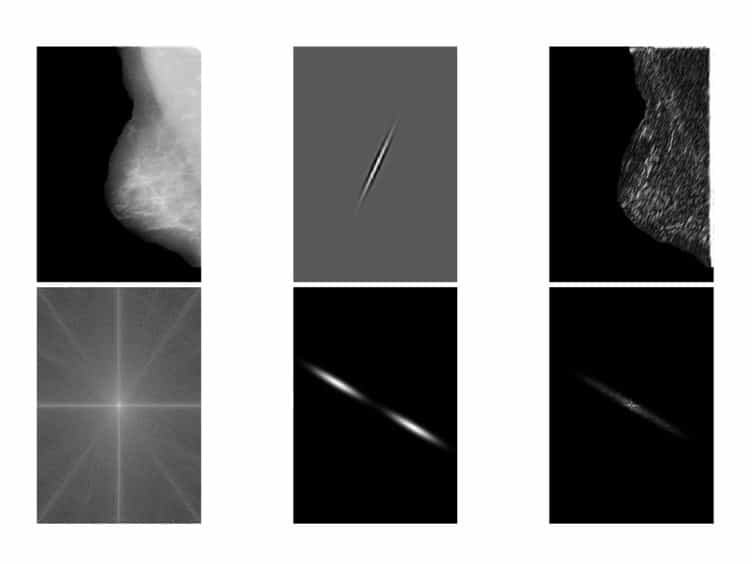

Detection of Architectural Distortion in Prior Mammograms via Analysis of Oriented Patterns
Published on: August 30, 2013
Theory and applications of the systematic detection of unstable periodic orbits in dynamical systems
1Theoretical Chemistry, Institute for Physical Chemistry, INF 229, University of Heidelberg, 69120 Heidelberg, Germany.

Abstract:
A topological approach and understanding to the detection of unstable periodic orbits based on a recently proposed method [Phys. Rev. Lett. 78, 4733 (1997)] is developed. This approach provides a classification of the set of transformations necessary for finding the orbits. Applications to the Ikeda and Henon map are performed, allowing a study of the distributions of Lyapunov exponents for high periods. In particular, the properties of the least unstable orbits up to period 36 are investigated and discussed.

Related Concept Videos
 01:04
Oscillations about an Equilibrium Position
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system.
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's response.
 01:28
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:19
Root-Locus Method
This system can be represented by a block diagram,...