Related Experiment Video
Updated: Oct 10, 2026
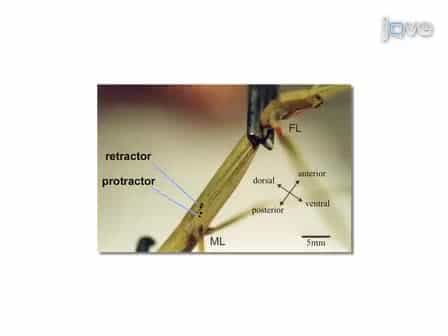
Studying the Neural Basis of Adaptive Locomotor Behavior in Insects
Published on: April 13, 2011
Mechanical models for insect locomotion: dynamics and stability in the horizontal plane I. Theory
1Department of Mechanical and Aerospace Engineering, Princeton University, Princeton, NJ 08544, USA.

Abstract:
We study the dynamics and stability of legged locomotion in the horizontal plane. Motivated by experimental studies of insects, we develop two- and three-degree-of freedom rigid body models with pairs of 'virtual' elastic legs in intermittent contact with the ground. We focus on conservative compliant-legged models, but we also consider prescribed forces, prescribed leg displacements, and combined strategies. The resulting mechanical systems exhibit periodic gaits whose stability characteristics are due to intermittent foot contact, and are largely determined by geometrical criteria. Most strikingly, we show that mechanics alone can confer asymptotic stability in heading and body orientation. In a companion paper, we apply our results to rapidly running cockroaches.


Related Concept Videos
 01:14
Stability of structures
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:22
Mechanical Systems
 01:07
Static Equilibrium - II
 01:22
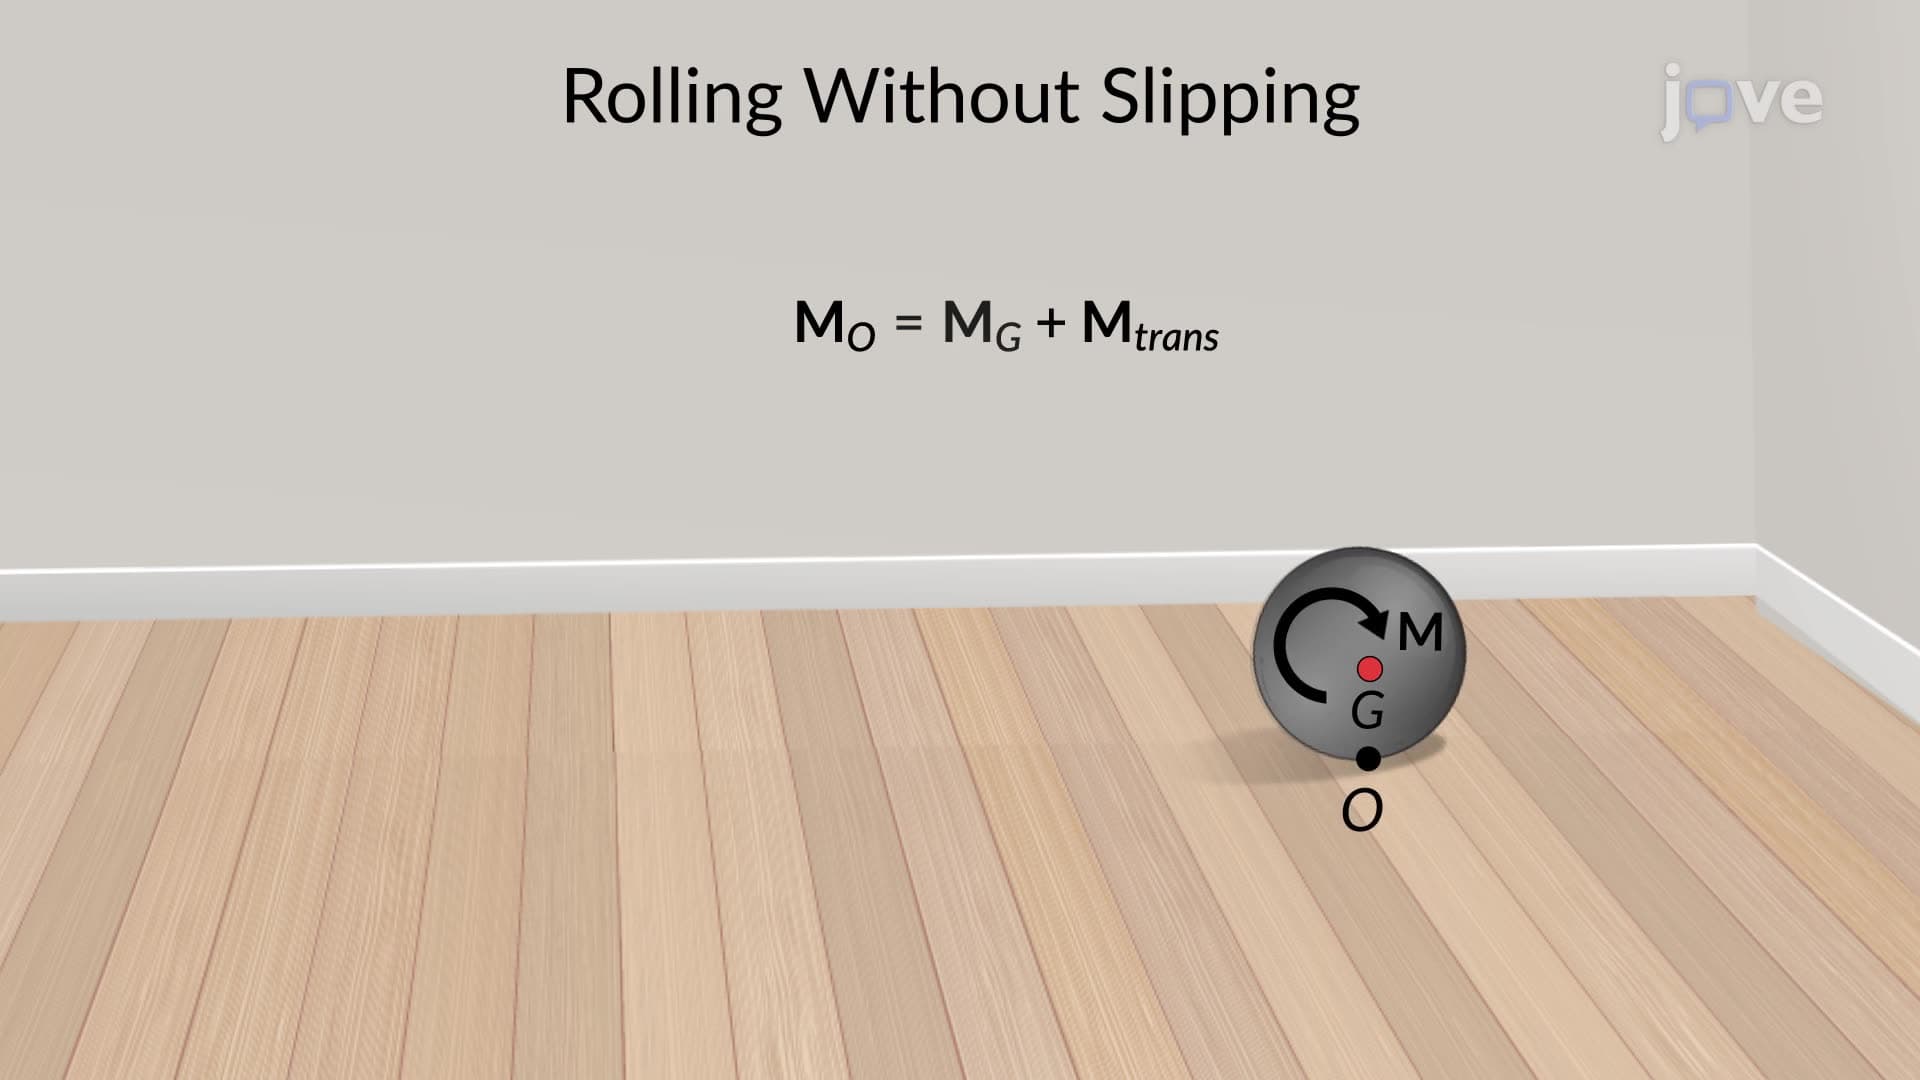
Equation of Motion: General Plane motion
Moreover, the body's center of mass experiences a rotational effect as a result of these couple moments. This rotation can be articulated as the product of the...
 01:27
Types of Friction Problems
The first type of dry friction problem involves situations where there is no apparent impending motion.