Related Experiment Video
Updated: Aug 19, 2026

A Vibrotactile Feedback Device for Seated Balance Assessment and Training
Published on: January 20, 2019
Re-evaluation of a tilt-back seat as a means of increasing acceleration tolerance

Abstract:
Relaxed tolerance was determined on seven subjects exposed to rapid onset (RO; 1 G/s) and gradual onset (GO; 1 G/10 s) acceleration at seat back angles of 13 degrees, 30 degrees, 45 degrees, 55 degrees, 65 degrees, and 75 degrees from the vertical. There was no significant difference between relaxed tolerance at the control angle of 13 degrees and tolerance at 30 degrees. However, at 45 degrees there was a significant 0.5 G increase in tolerance compared to control. Thereafter, tolerance continued to increase in an exponential manner to 8 G at 75 degrees, an increase over control of 100%. As relaxed tolerance increased with increasing back angle, peak heart rate during acceleration significantly decreased. In addition, four subjects were instrumented with an esophageal balloon for the measurement of intrathoracic pressure, which was equated as work during the M-1 straining maneuver. The amount of thoracic pressure necessary to maintain a preselected visual field declined as the back angle was increased from 13 degrees to 45 degrees to 65 degrees at the same acceleration level. The increase in relaxed tolerance along with the decrease in heart rate and the decrease in esophageal pressure at the greater back angles all demonstrate the acceleration protection provided by the tilt-back seat.
More Related Videos
 06:30
Assessment of Static Graviceptive Perception in the Roll-Plane using the Subjective Visual Vertical Paradigm
Published on: April 28, 2020
 06:28
Biomechanical Changes Related to Low Back Pain: An Innovative Tool for Movement Pattern Assessment and Treatment Evaluation in Rehabilitation
Published on: December 13, 2024
Related Concept Videos
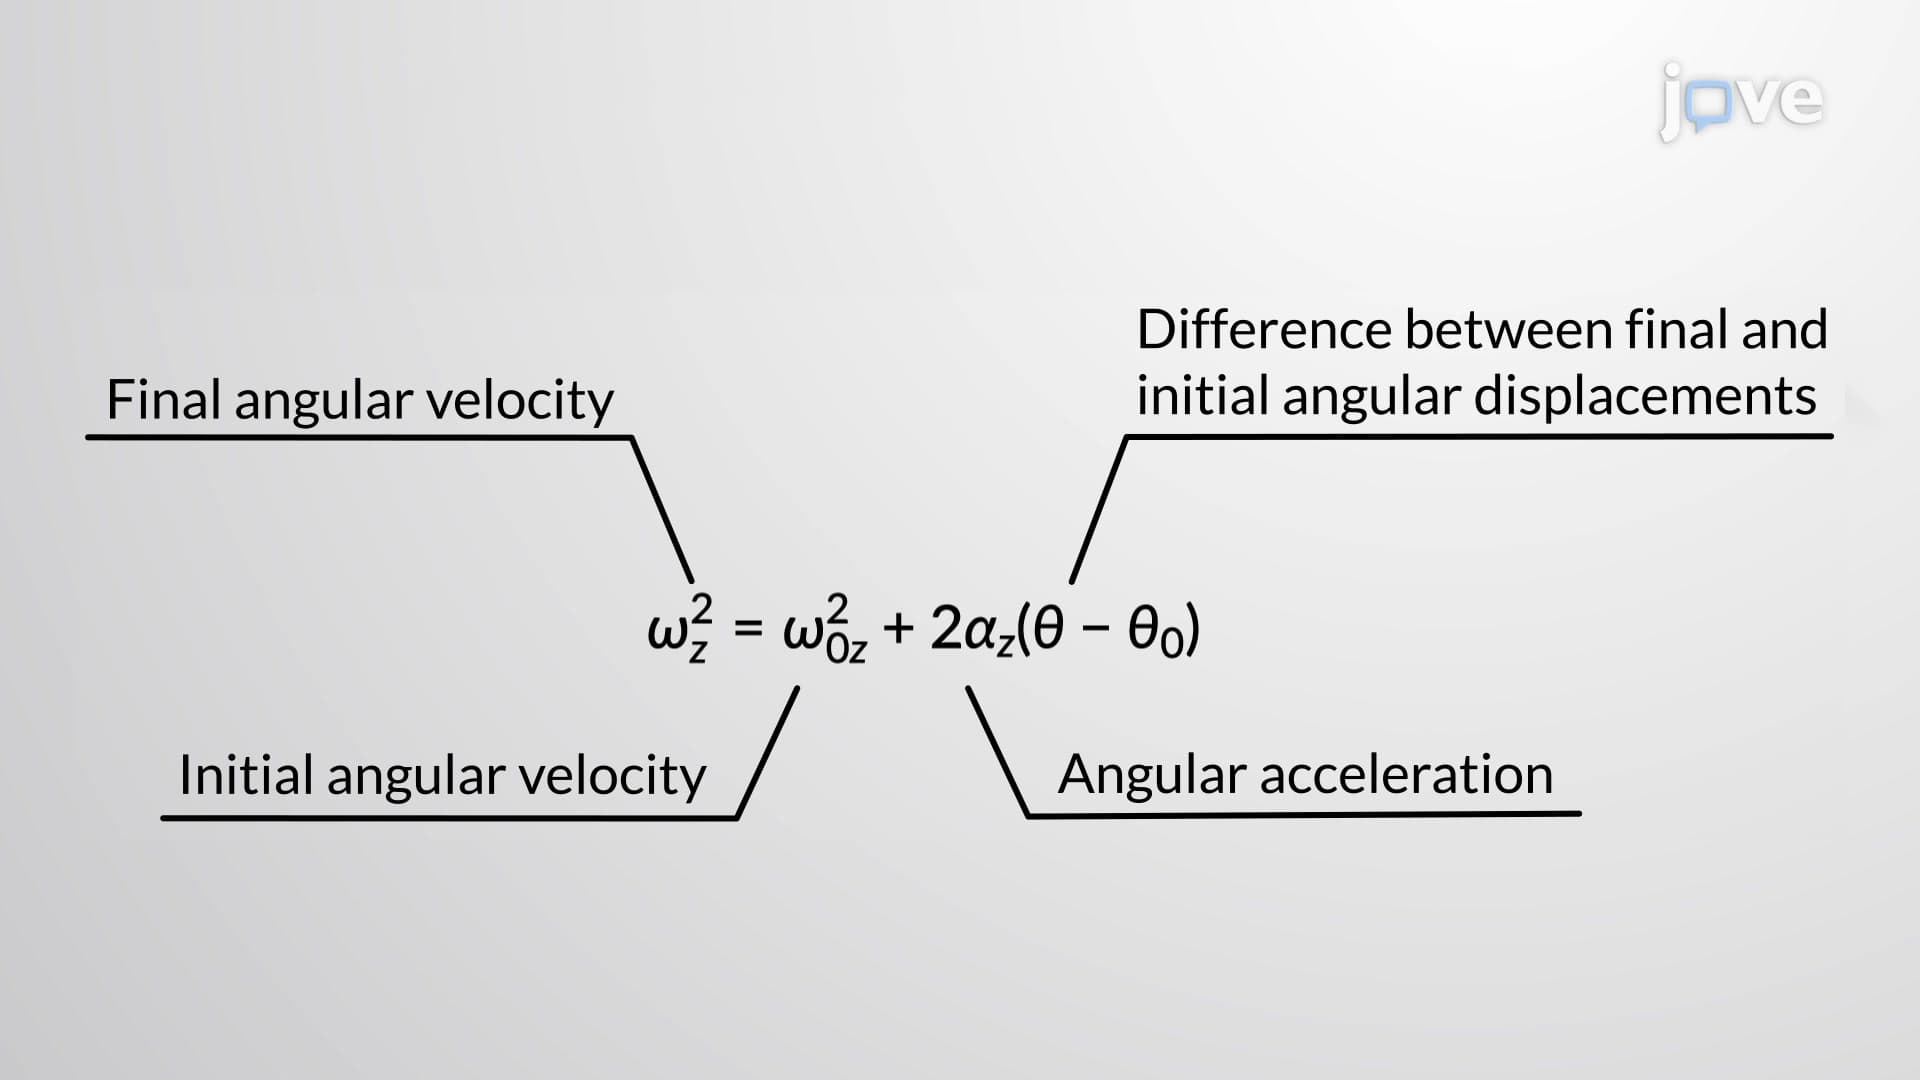 01:16
Rotation with Constant Angular Acceleration - II
The first...
 01:24
Normal and Tangetial Components: Problem Solving
 01:10
Relative Motion Analysis - Acceleration
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...