Related Experiment Video
Updated: Oct 9, 2026
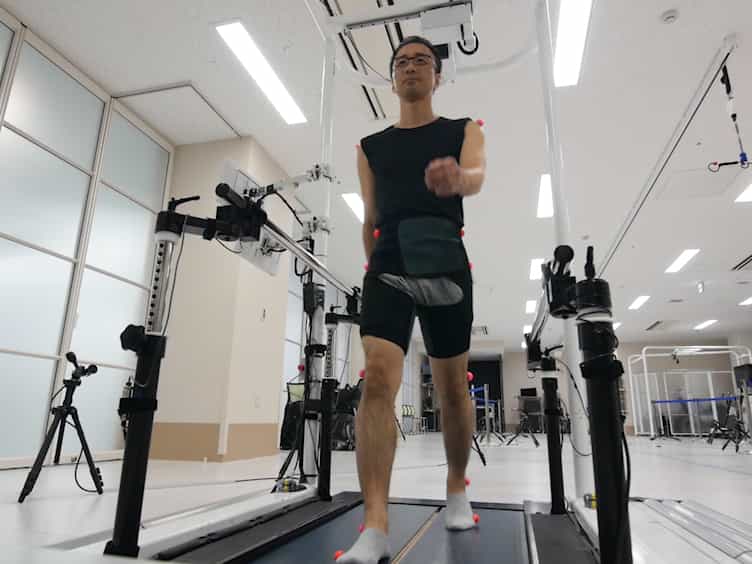

Clinical-oriented Three-dimensional Gait Analysis Method for Evaluating Gait Disorder
Published on: March 4, 2018
Static and dynamic optimization solutions for gait are practically equivalent
1Department of Mechanical Engineering, The University of Texas at Austin, Austin, Texas, USA. fca@stanford.edu

Abstract:
The proposition that dynamic optimization provides better estimates of muscle forces during gait than static optimization is examined by comparing a dynamic solution with two static solutions. A 23-degree-of-freedom musculoskeletal model actuated by 54 Hill-type musculotendon units was used to simulate one cycle of normal gait. The dynamic problem was to find the muscle excitations which minimized metabolic energy per unit distance traveled, and which produced a repeatable gait cycle. In the dynamic problem, activation dynamics was described by a first-order differential equation. The joint moments predicted by the dynamic solution were used as input to the static problems. In each static problem, the problem was to find the muscle activations which minimized the sum of muscle activations squared, and which generated the joint moments input from the dynamic solution. In the first static problem, muscles were treated as ideal force generators; in the second, they were constrained by their force-length-velocity properties; and in both, activation dynamics was neglected. In terms of predicted muscle forces and joint contact forces, the dynamic and static solutions were remarkably similar. Also, activation dynamics and the force-length-velocity properties of muscle had little influence on the static solutions. Thus, for normal gait, if one can accurately solve the inverse dynamics problem and if one seeks only to estimate muscle forces, the use of dynamic optimization rather than static optimization is currently not justified. Scenarios in which the use of dynamic optimization is justified are suggested.
More Related Videos
 08:24
Sit-to-stand-and-walk from 120% Knee Height: A Novel Approach to Assess Dynamic Postural Control Independent of Lead-limb
Published on: August 30, 2016
 06:52
Deep-Learning Based Multi-Joint Synchronous Tracking for Objective Quantification of Hindlimb Locomotor Kinematics in Rats
Published on: April 3, 2026
Related Concept Videos
 01:07
Static Equilibrium - II
 01:05
Static Equilibrium - I
 01:15
Kinematic Equations: Problem Solving
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
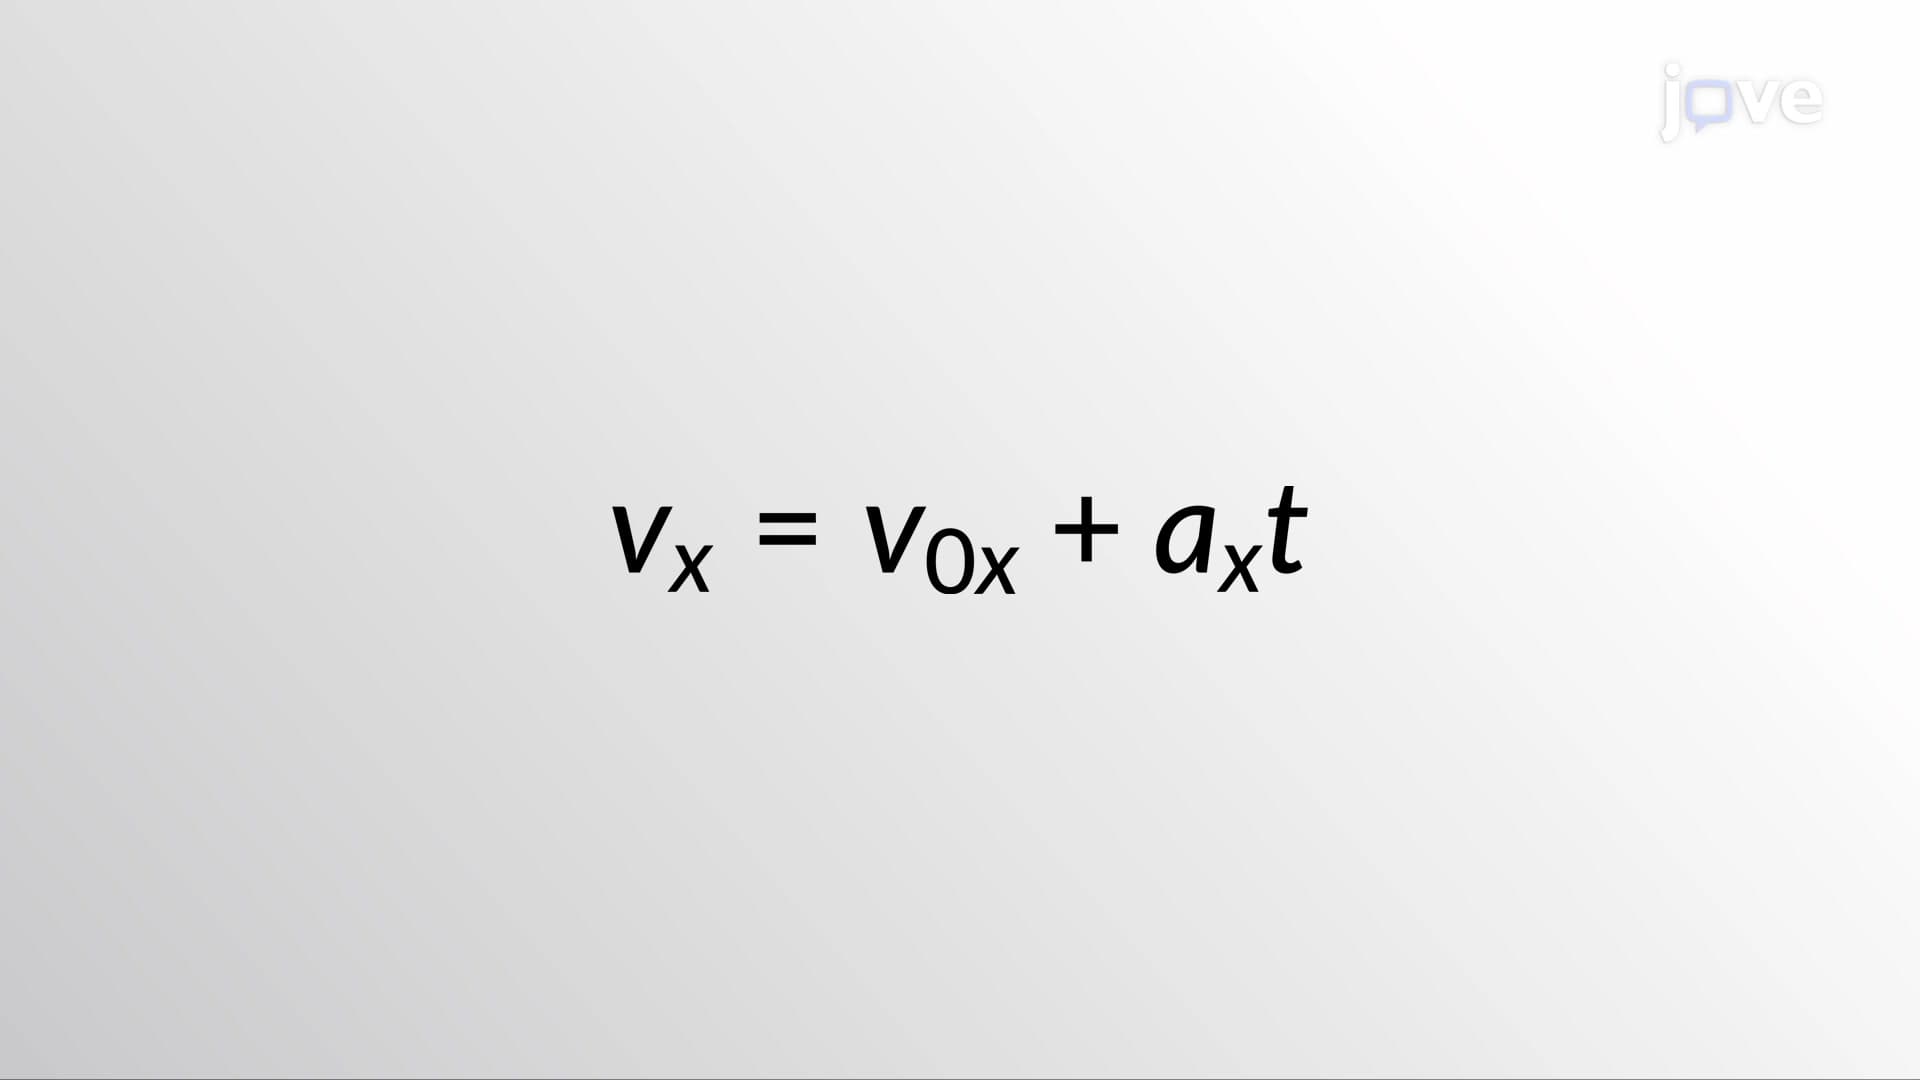 01:26
Kinematic Equations - I
 01:18
Kinematic Equations - III
Using the kinematic equations,...