Related Experiment Video
Updated: Oct 9, 2026
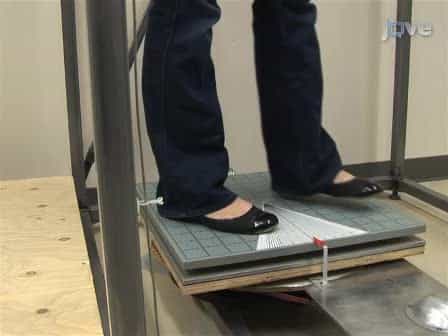
Method to Measure Tone of Axial and Proximal Muscle
Published on: December 14, 2011
Low-dimensional control: tonus (1963)
O G Meijer1, Y M Kots, V R Edgerton
1Faculty of Human Movement Sciences, Vrije Universiteit, Van der Boechorstraat 9, 1081 BT Amsterdam, The Netherlands. ojmeijer@euronet.nl

Abstract:
In 1963, an article on "Tonus" (tone), written by Nikolai A. Bernstein and Yakov M. Kots, appeared in the second edition of the Bols'aja Medicinskaja Enciclopedija [Grand Medical Encyclopedia]. The paper is now published for the first time in the English language, with Mark L. Latash as translator. In accordance with then contemporary neurophysiology and neuropsychology, the paper presented "tone" as a graded phenomenon (as opposed to all-or-none), serving to prepare the segmental level for phasic contractions. Influenced by Granit and Matthews, the authors proposed that the suprasegmental level controls the threshold and the slope of the stretch reflex. In their introduction to the present edition, the editors understand this proposal in the context of low-dimensional control, that is, control in terms of one or a few variables (as opposed to central commands specifying all the details). Selected episodes from the history of low dimensional control and its logical counterpart, spinal intelligence, are used to illustrate how difficult these ideas were to accept. As so often in new scientific developments, confusion was the rule, and in this respect the paper on "Tonus" is no exception. In the epilogue, Kots gives his personal memories of the context in which the paper was written. At the time, he was working on "equitonometry" (equi-tono-metry), measuring tonic balance with gravity eliminated. Results of equitonometric research quite naturally led to the idea that suprasegmental centers control the threshold and the slope of the tonic stretch reflex. As Kots remembers, that was "no big deal".
Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:10
Control Systems
At the heart...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:28
Load-frequency control