Related Experiment Video
Updated: Oct 9, 2026


Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Stability and Control of Human Trunk Movement During Walking
Q. Wu1, N. Sepehri, A. B. Thornton-Trump
1Department of Mechanical and Industrial Engineering.

Abstract:
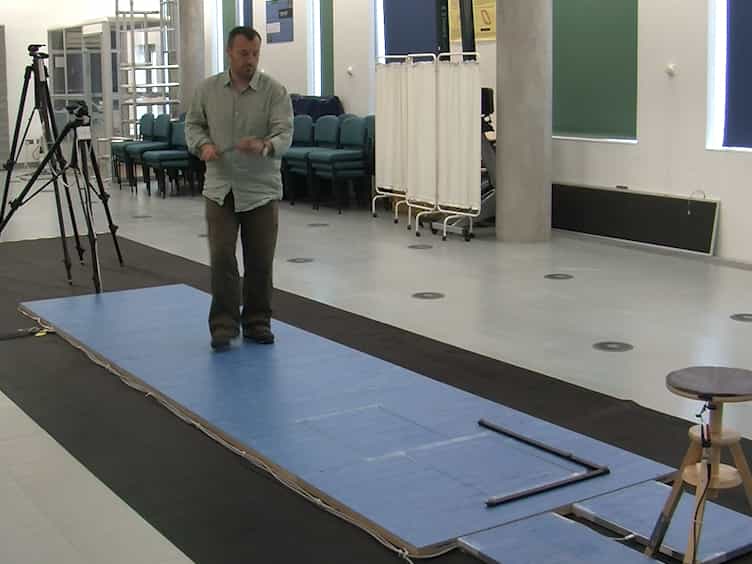
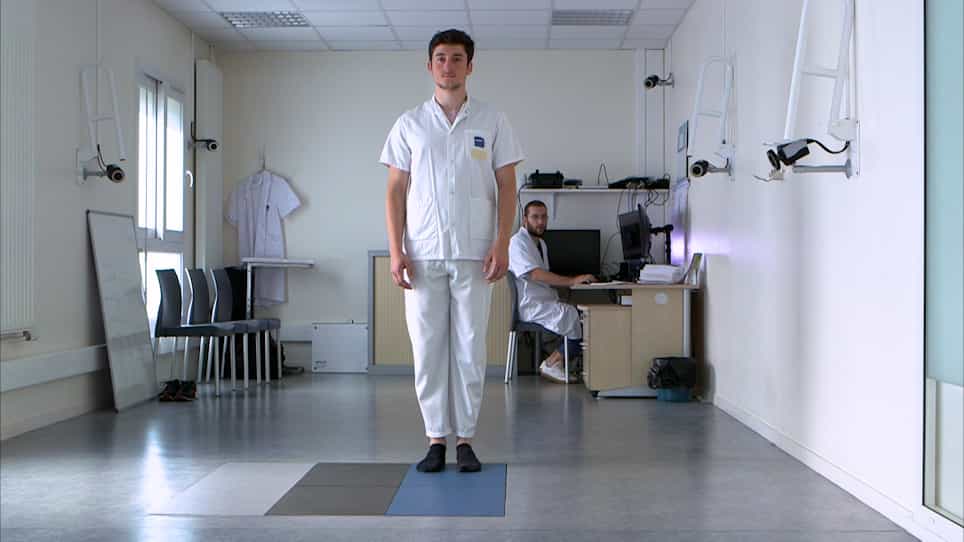
A mathematical model has been developed to study the control mechanisms of human trunk movement during walking. The trunk is modeled as a base-excited inverted pendulum with two-degrees of rotational freedom. The base point, corresponding to the bony landmark of the sacrum, can move in three-dimensional space in a general way. Since the stability of upright posture is essential for human walking, a controller has been designed such that the stability of the pendulum about the upright position is guaranteed. The control laws are developed based on Lyapunov's stability theory and include feedforward and linear feedback components. It is found that the feedforward component plays a critical role in keeping postural stability, and the linear feedback component, (resulting from viscoelastic function of the musculoskeletal system) can effectively duplicate the pattern of trunk movement. The mathematical model is validated by comparing the simulation results with those based on gait measurements performed in the Biomechanics Laboratory at the University of Manitoba.
More Related Videos
Related Concept Videos
 01:05
Development of Head Control During Infancy
 01:22
Indirect Motor Pathways
The vestibulospinal tract originates in the vestibular nuclei of the brainstem. The vestibular system detects changes in...
 01:18
Hierarchy of Motor Control
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's response.