Fourth-Order Rotational Corrections to the Effective Dipole Moments of Nonrigid Asymmetric Rotors

V. I. Starikov1

  • 1The Institute of Atmospheric Optics, SB RAN, Tomsk, 634055, Russia

Related Concept Videos

Rotation of Asymmetric Top01:11

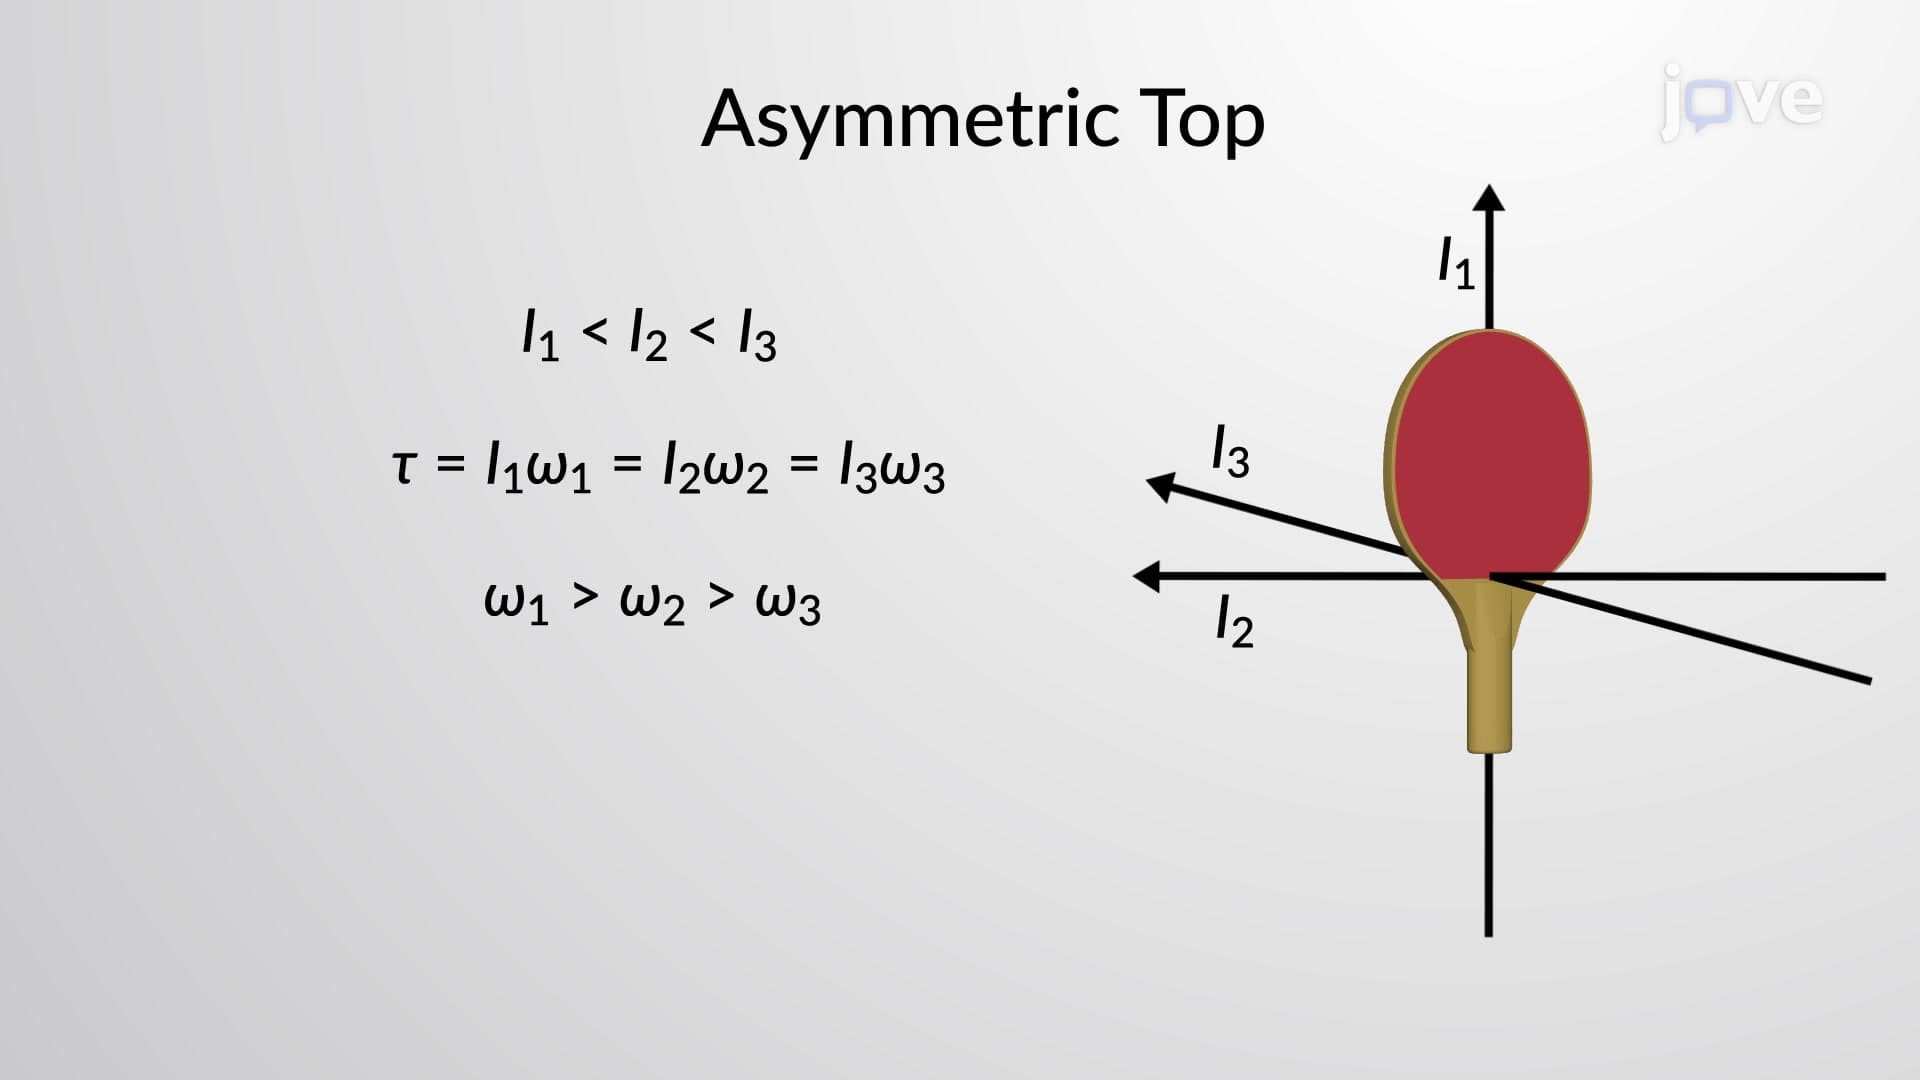
Rotation of Asymmetric Top

By definition, a spherically symmetric body has the same moment of inertia about any axis passing through its center of mass. This situation changes if there is no spherical symmetry. Since most rigid bodies are not spherically symmetric, these require special treatment.
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
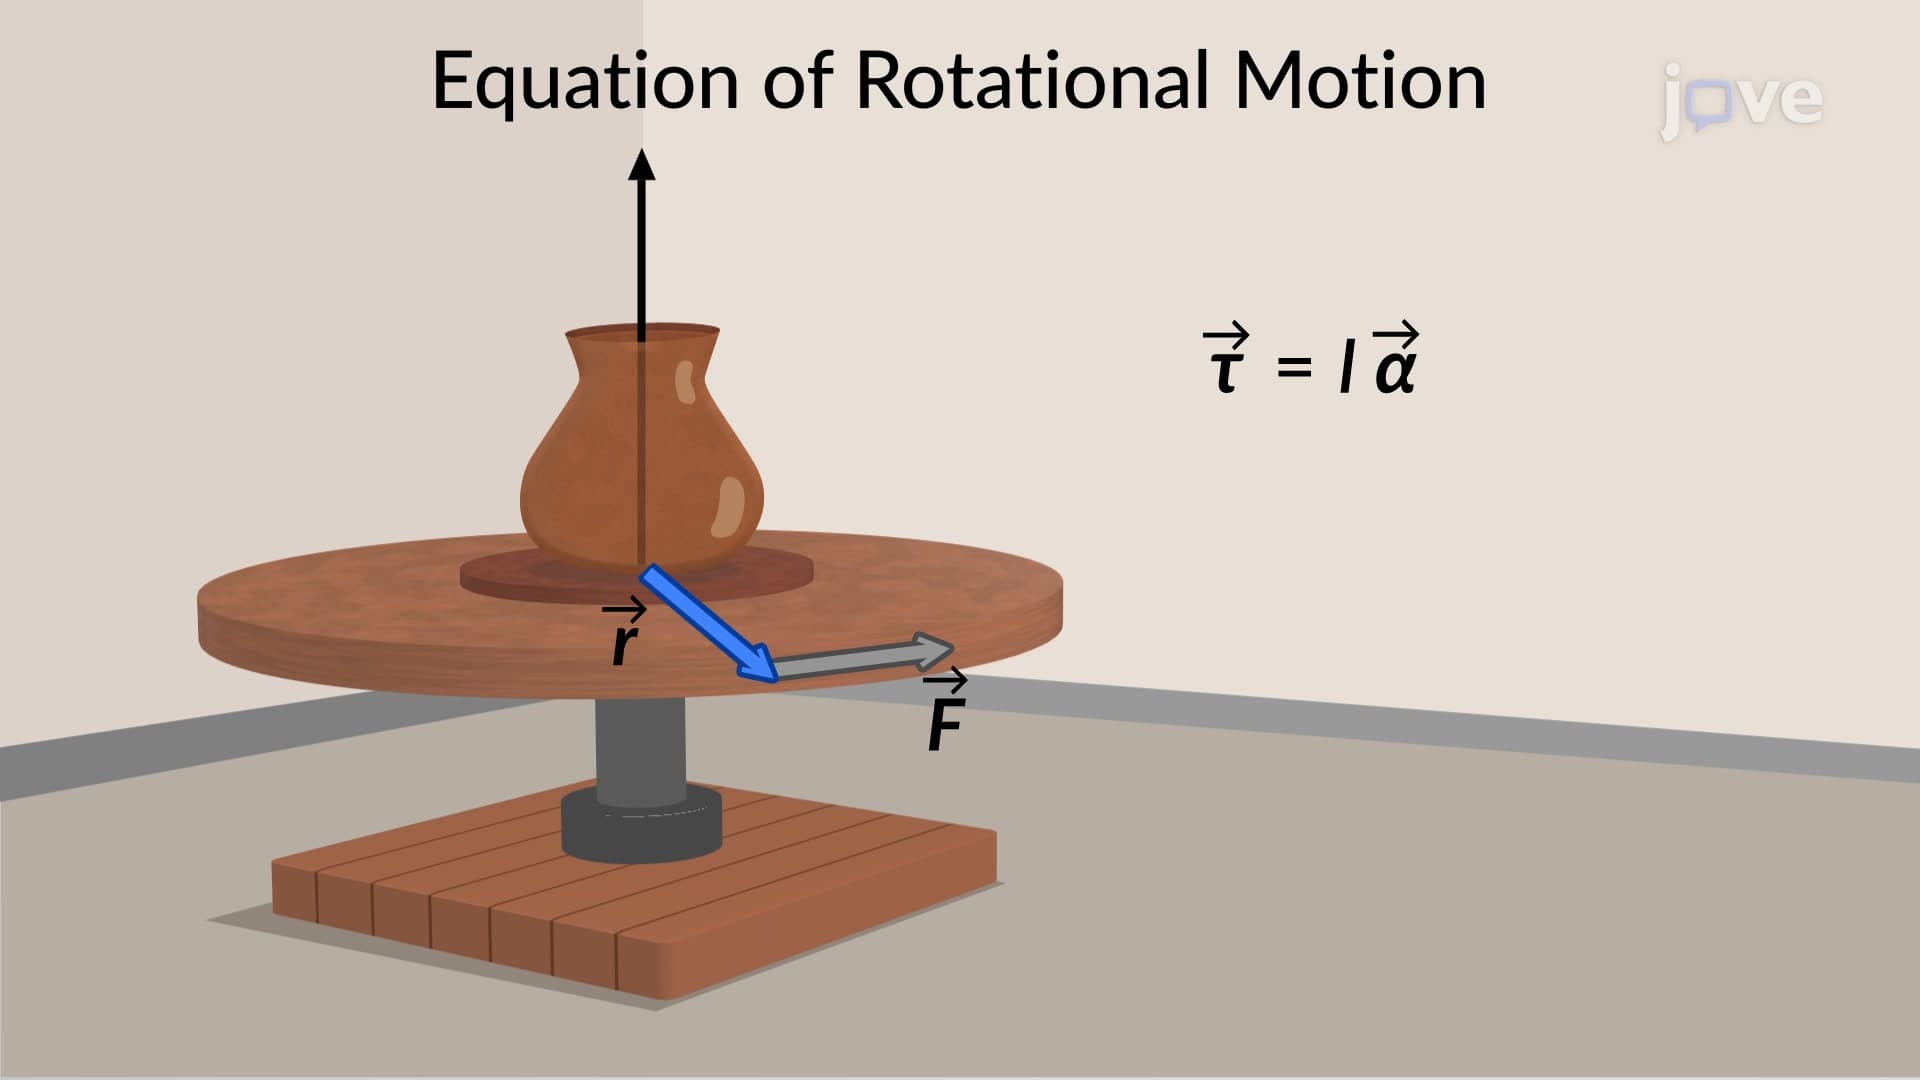
Equation of Rotational Dynamics01:08

Equation of Rotational Dynamics

Angular variables are introduced in rotational dynamics. Comparing the definitions of angular variables with the definitions of linear kinematic variables, it is seen that there is a mapping of the linear variables to the rotational ones. Linear displacement, velocity, and acceleration have their equivalents in rotational motion, which are angular displacement, angular velocity, and angular acceleration. Similar to the rotational variables, a mapping exists from Newton's second law of motion...
Woodward–Hoffmann Selection Rules and Microscopic Reversibility01:34

Woodward–Hoffmann Selection Rules and Microscopic Reversibility
Electrocyclic reactions, cycloadditions, and sigmatropic rearrangements are concerted pericyclic reactions that proceed via a cyclic transition state. These reactions are stereospecific and regioselective. The stereochemistry of the products depends on the symmetry characteristics of the interacting orbitals and the reaction conditions. Accordingly, pericyclic reactions are classified as either symmetry-allowed or symmetry-forbidden. Woodward and Hoffmann presented the selection criteria for...
Euler Equations of Motion01:19

Euler Equations of Motion

Imagine a rigid body that is rotating at an angular velocity of ω within an inertial frame of reference. Along with this, picture a second rotating frame that is attached to the body itself. This frame moves along with the body and possesses an angular velocity of Ω. The total moment about the center of mass is calculated by adding the rate of change of angular momentum about the center of mass in relation to the rotating frame and the cross-product of the body's angular velocity and its...
Angle of Twist: Problem Solving01:13

Angle of Twist: Problem Solving

An electric motor applies a torque of 700 N·m to an aluminum shaft, triggering a stable rotation. Two pulleys, B and C, are subjected to torques of 300 N·m and 400 N·m, respectively. The modulus of rigidity is provided as 25 GPa. With the knowledge of the length and diameter of each segment, the twist angle between the two pulleys can be computed. First, a section cut is made between pulleys B and C, and the cut cross-section is analyzed using a free-body diagram. Given that the torque exerted...
Rotation with Constant Angular Acceleration - II01:16

Rotation with Constant Angular Acceleration - II

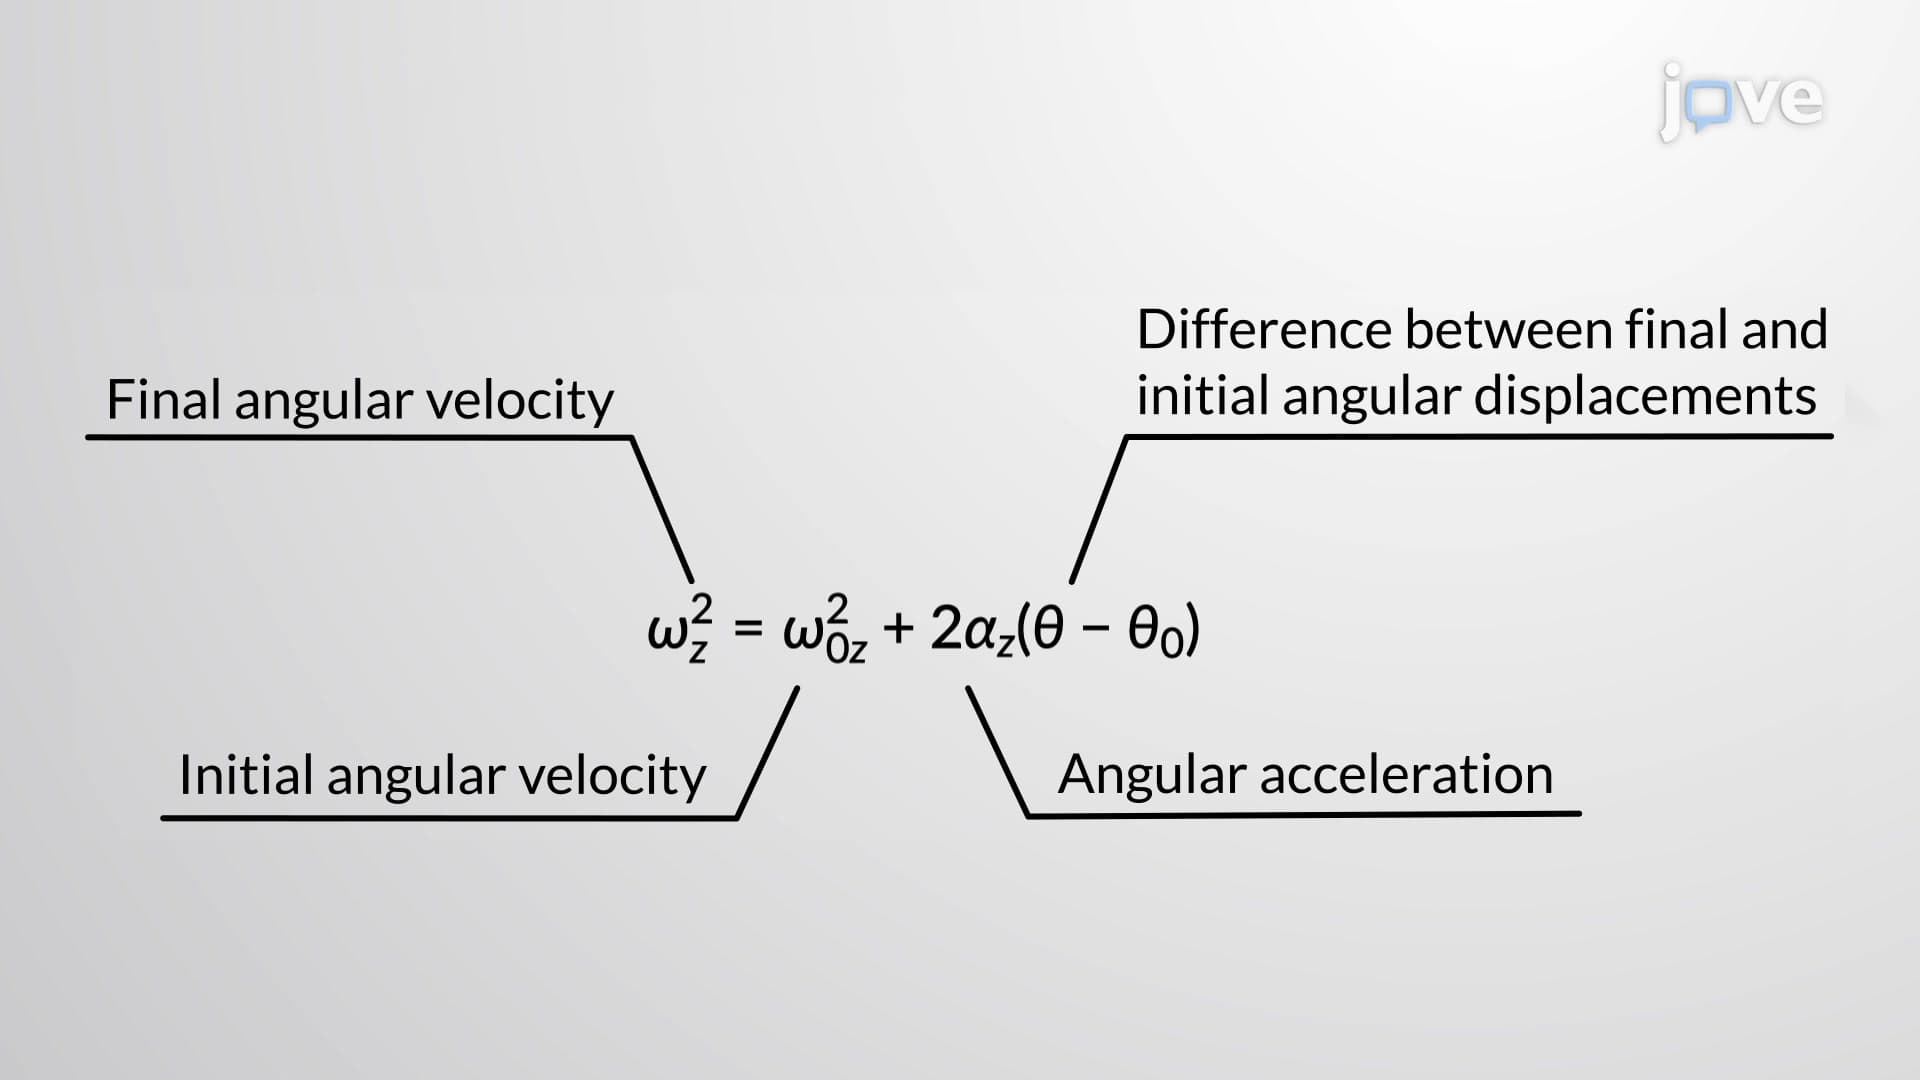
Kinematics is the description of motion. The kinematics of rotational motion discusses the relationships between rotation angle, angular velocity, angular acceleration, and time. One can describe many things with great precision using kinematics, but kinematics does not consider causes. For example, a large angular acceleration describes a very rapid change in angular velocity without any consideration of its cause. Thus, rotational kinematics does not represent the laws of nature.
The first...