Delayed stochastic differential model for quiet standing

W Yao1, P Yu, C Essex

  • 1Applied Mathematics Department, University of Western Ontario, London, Ontario, Canada N6A 5B7.

Related Concept Videos

Types of Damping01:20

Types of Damping

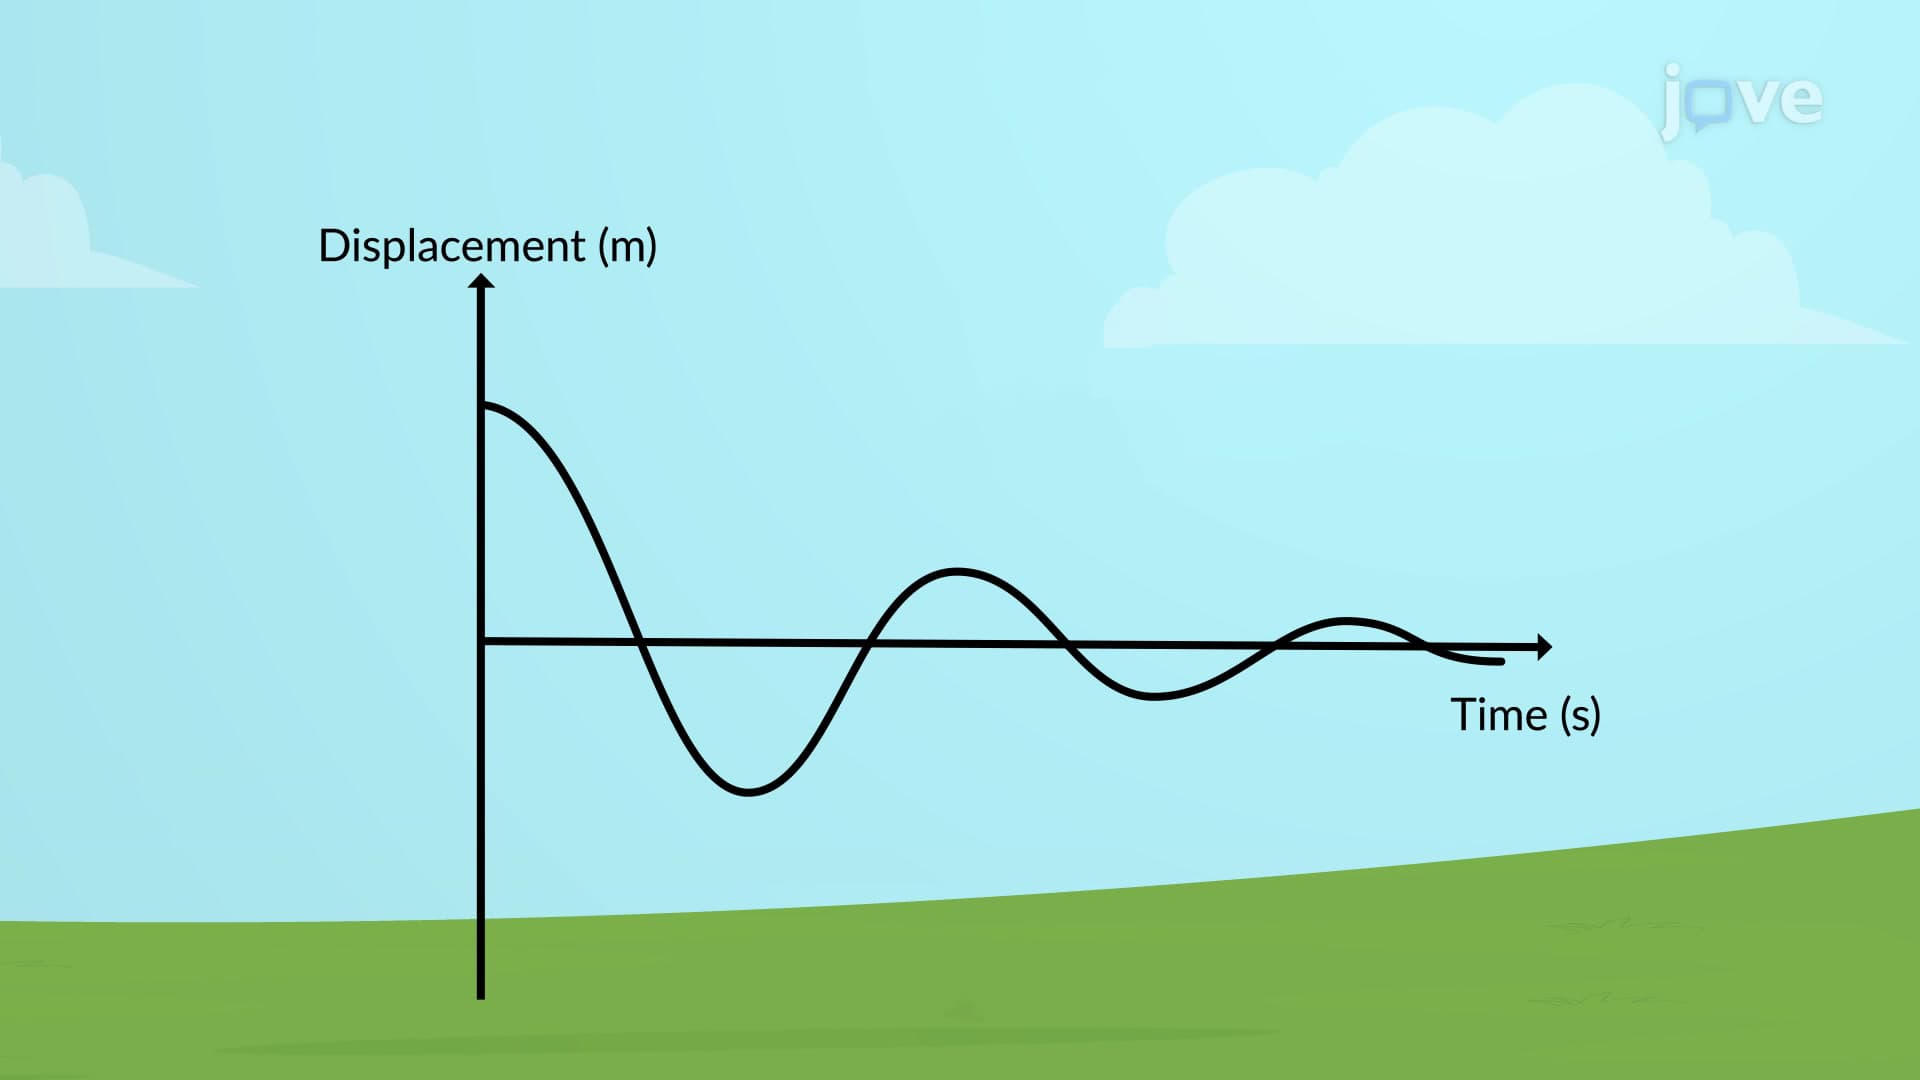
If the amount of damping in a system is gradually increased, the period and frequency start to become affected because damping opposes, and hence slows, the back and forth motion (the net force is smaller in both directions). If there is a very large amount of damping, the system does not even oscillate; instead, it slowly moves toward equilibrium. In brief, an overdamped system moves slowly towards equilibrium, whereas an underdamped system moves quickly to equilibrium but will oscillate about...
Linear Approximation in Time Domain01:21

Linear Approximation in Time Domain

Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
Second Order systems II01:18

Second Order systems II

In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
If  ζ...
Mechanistic Models: Compartment Models in Individual and Population Analysis01:23

Mechanistic Models: Compartment Models in Individual and Population Analysis
Mechanistic models are utilized in individual analysis using single-source data, but imperfections arise due to data collection errors, preventing perfect prediction of observed data. The mathematical equation involves known values (Xi), observed concentrations (Ci), measurement errors (εi), model parameters (ϕj), and the related function (ƒi) for i number of values. Different least-squares metrics quantify differences between predicted and observed values. The ordinary least squares (OLS)...
Pharmacodynamic Models: Link Model and Systems Pharmacodynamic Model01:14

Pharmacodynamic Models: Link Model and Systems Pharmacodynamic Model

The link model is a fundamental pharmacokinetic-pharmacodynamic (PK–PD) approach to account for delayed drug responses when the observed effect does not immediately correlate with the drug's plasma concentration peak. This delay is mathematically addressed by introducing an effect compartment concentration, Ce, which is kinetically linked to the plasma concentration, Cp, via a first-order rate constant, ke0. The linkage allows for a more accurate prediction of drug effects over time. A higher...
Modeling with Differential Equations01:25

Modeling with Differential Equations

Population dynamics can be described mathematically by considering the population size P(t) as a function of time. The rate of change of the population is then represented by the derivative of P(t). A simple assumption is that the rate of growth is proportional to the size of the population itself. This leads to an exponential growth model, where the population increases rapidly without bound. While this is a useful first approximation, it does not reflect realistic long-term...