Scaling behavior for finite O(n) systems with long-range interaction

H Chamati1, N S Tonchev

  • 1Institute of Solid State Physics, 72 Tzarigradsko Chaussée, 1784 Sofia, Bulgaria. chamati@issp.bas.bg

Related Concept Videos

Scaling01:26

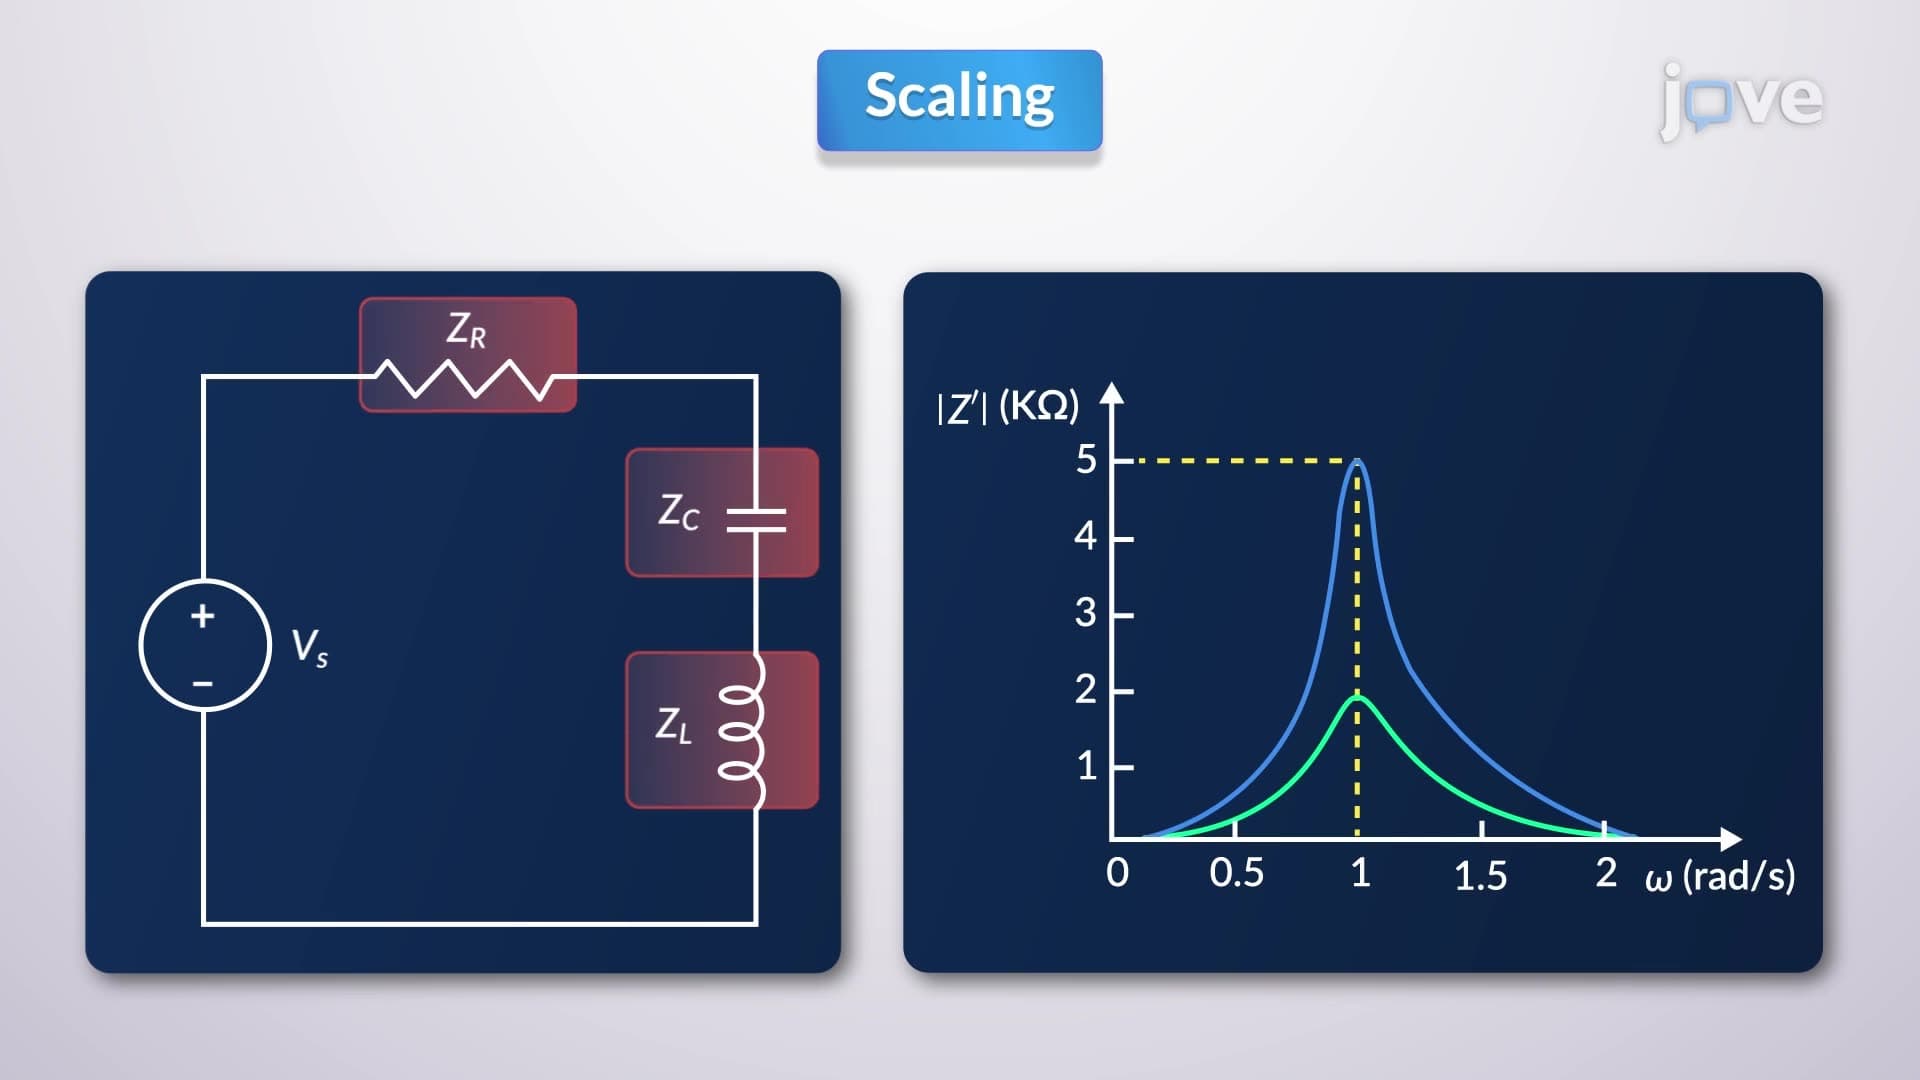
Scaling

In designing and analyzing filters, resonant circuits, or circuit analysis at large, working with standard element values like 1 ohm, 1 henry, or 1 farad can be convenient before scaling these values to more realistic figures. This approach is widely utilized by not employing realistic element values in numerous examples and problems; it simplifies mastering circuit analysis through convenient component values. The complexity of calculations is thereby reduced, with the understanding that...
Linear Approximation in Time Domain01:21

Linear Approximation in Time Domain

Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
Modeling with Differential Equations01:25

Modeling with Differential Equations
Population dynamics can be described mathematically by considering the population size P(t) as a function of time. The rate of change of the population is then represented by the derivative of P(t). A simple assumption is that the rate of growth is proportional to the size of the population itself. This leads to an exponential growth model, where the population increases rapidly without bound. While this is a useful first approximation, it does not reflect realistic long-term...
First Law: Particles in One-dimensional Equilibrium01:10

First Law: Particles in One-dimensional Equilibrium

Newton's first law of motion states that a body at rest remains at rest, or if in motion, remains in motion at constant velocity, unless acted on by a net external force. It also states that there must be a cause for any change in velocity (a change in either magnitude or direction) to occur. This cause is a net external force. For example, consider what happens to an object sliding along a rough horizontal surface. The object quickly grinds to a halt, due to the net force of friction. If we...
Second Order systems II01:18

Second Order systems II

In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
If  ζ...
Stability of Equilibrium Configuration01:23

Stability of Equilibrium Configuration

Understanding the stability of equilibrium configurations is a fundamental part of mechanical engineering. In any system, there are three distinct types of equilibrium: stable, neutral, and unstable.
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...