Related Experiment Video
Updated: Oct 7, 2026
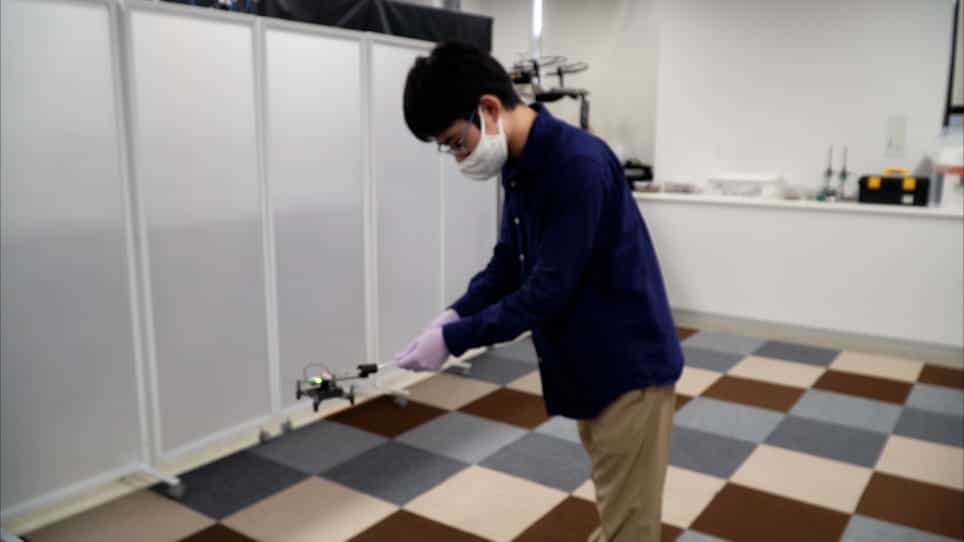

Electroantennography-based Bio-hybrid Odor-detecting Drone using Silkmoth Antennae for Odor Source Localization
Published on: August 27, 2021
Landing strategies in honeybees, and possible applications to autonomous airborne vehicles
M V Srinivasan1, S Zhang, J S Chahl
1Centre for Visual Science, Research School of Biological Sciences, Australian National University, Canberra, ACT. M.Srinivasan@anu.edu.au

Abstract:
Insects, being perhaps more reliant on image motion cues than mammals or higher vertebrates, are proving to be an excellent organism in which to investigate how information on optic flow is exploited to guide locomotion and navigation. This paper describes one example, illustrating how bees perform grazing landings on a flat surface. A smooth landing is achieved by a surprisingly simple and elegant strategy: image velocity is held constant as the surface is approached, thus automatically ensuring that flight speed is close to zero at touchdown. No explicit knowledge of flight speed or height above the ground is necessary. The feasibility of this landing strategy is tested by implementation in a robotic gantry, and its applicability to autonomous airborne vehicles is discussed.

Related Concept Videos
 01:30
Vector Functions and Motion: Problem Solving
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...