Related Experiment Video
Updated: Oct 7, 2026
Asymmetric Walkway: A Novel Behavioral Assay for Studying Asymmetric Locomotion
Published on: January 15, 2016
Models of central pattern generators for quadruped locomotion. II. Secondary gaits
1University of Warwick, Coventry CV4 7AL, UK. buono@crm.umontreal.ca

Abstract:
We continue the analysis of the network of symmetrically coupled cells modeling central pattern generators (CPG) for quadruped locomotion proposed by Golubitsky, Stewart, Buono and Collins by studying secondary gaits. Secondary gaits are modeled by output signals from the CPG where each cell emits one of two different output signals along with exact phase shifts. Examples of secondary gaits are transverse gallop, rotary gallop, and canter. We classify secondary gaits that bifurcate when the Poincaré map of a primary gait has a real eigenvalue crossing the unit circle. In particular, we show that periodic solutions modeling transverse gallop and rotary gallop bifurcate from primary gaits. Moreover, we find gaits from period-doubling bifurcations and analyze plausible footfall patterns. Numerical simulations are performed using the Morris-Lecar equations as cell dynamics.
Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:22
Indirect Motor Pathways
The vestibulospinal tract originates in the vestibular nuclei of the brainstem. The vestibular system detects changes in...
 01:11
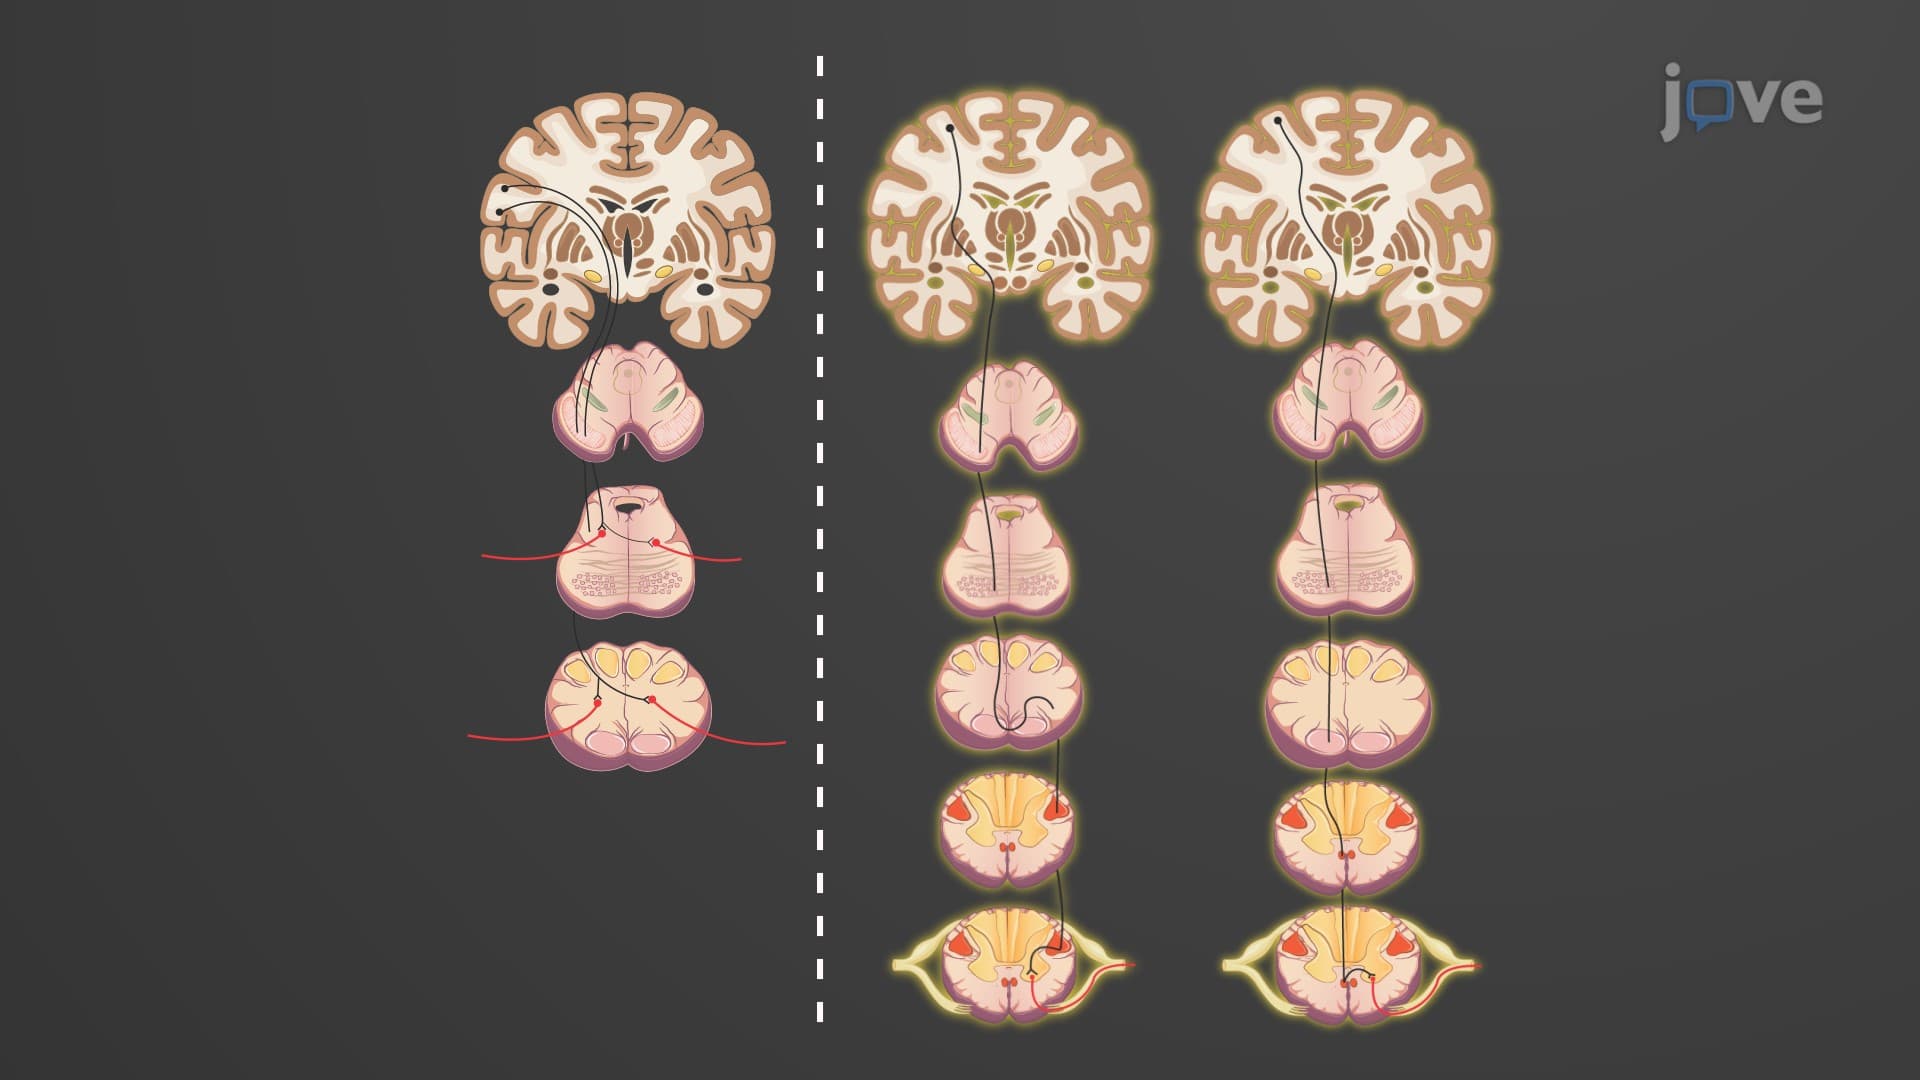
Direct Motor Pathways
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and the...