Stability analysis of four-point walking
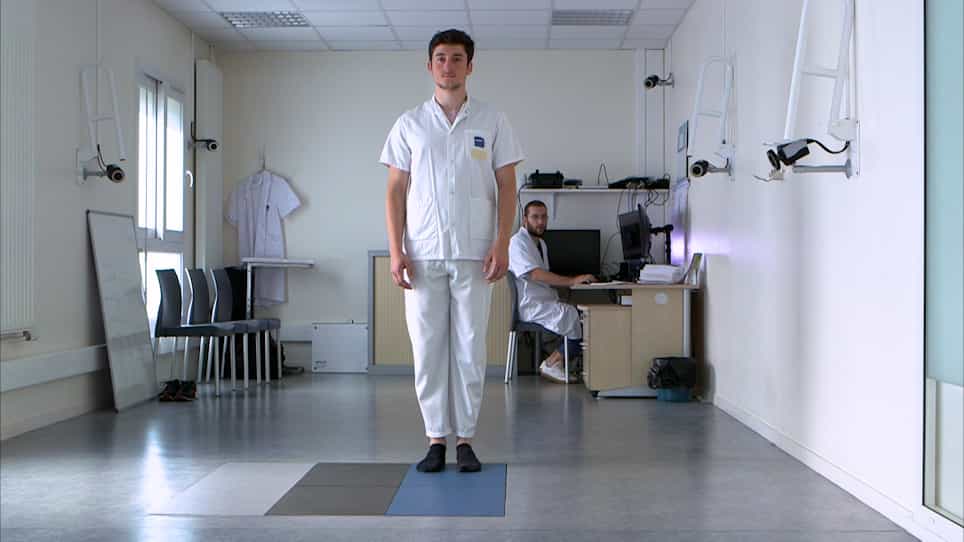
Related Experiment Video
Updated: Oct 7, 2026

Sit-to-stand-and-walk from 120% Knee Height: A Novel Approach to Assess Dynamic Postural Control Independent of Lead-limb
Published on: August 30, 2016
1Faculty of Electrical Engineering, University of Ljubljana, Ljubljana, Slovenia. jan.babic@ijs.si

Abstract:
The aim of the experiment reported here was to determine the static and dynamic stability of two-point stance phases when walking on hands and knees at different speeds. In addition, we defined the methods and predicted the consequences of including two-point stance phases into crutch assisted functional electrical stimulation (FES) walking. Crawling on hands and knees was performed at three speeds by five healthy male persons. With twelve joint-position markers placed on the subject, we determined two stability indices for every instant of gait. We analysed the peak values of these two indices during the two-point stance phases. The results indicate that we have to ensure the proper position of the centre of gravity to increase the speed of walking. To reach speeds, lower than 0.6 m/s, it is not necessary to include statically unstable phases. The shift of the centre of gravity towards and across the leading stability edge can result in getting into the dynamically unstable state. Considering the results we can effectively introduce two-point stance phases into crutch assisted FES walking and therefore increase the speed and energy effectiveness of walking

Related Concept Videos
 01:28
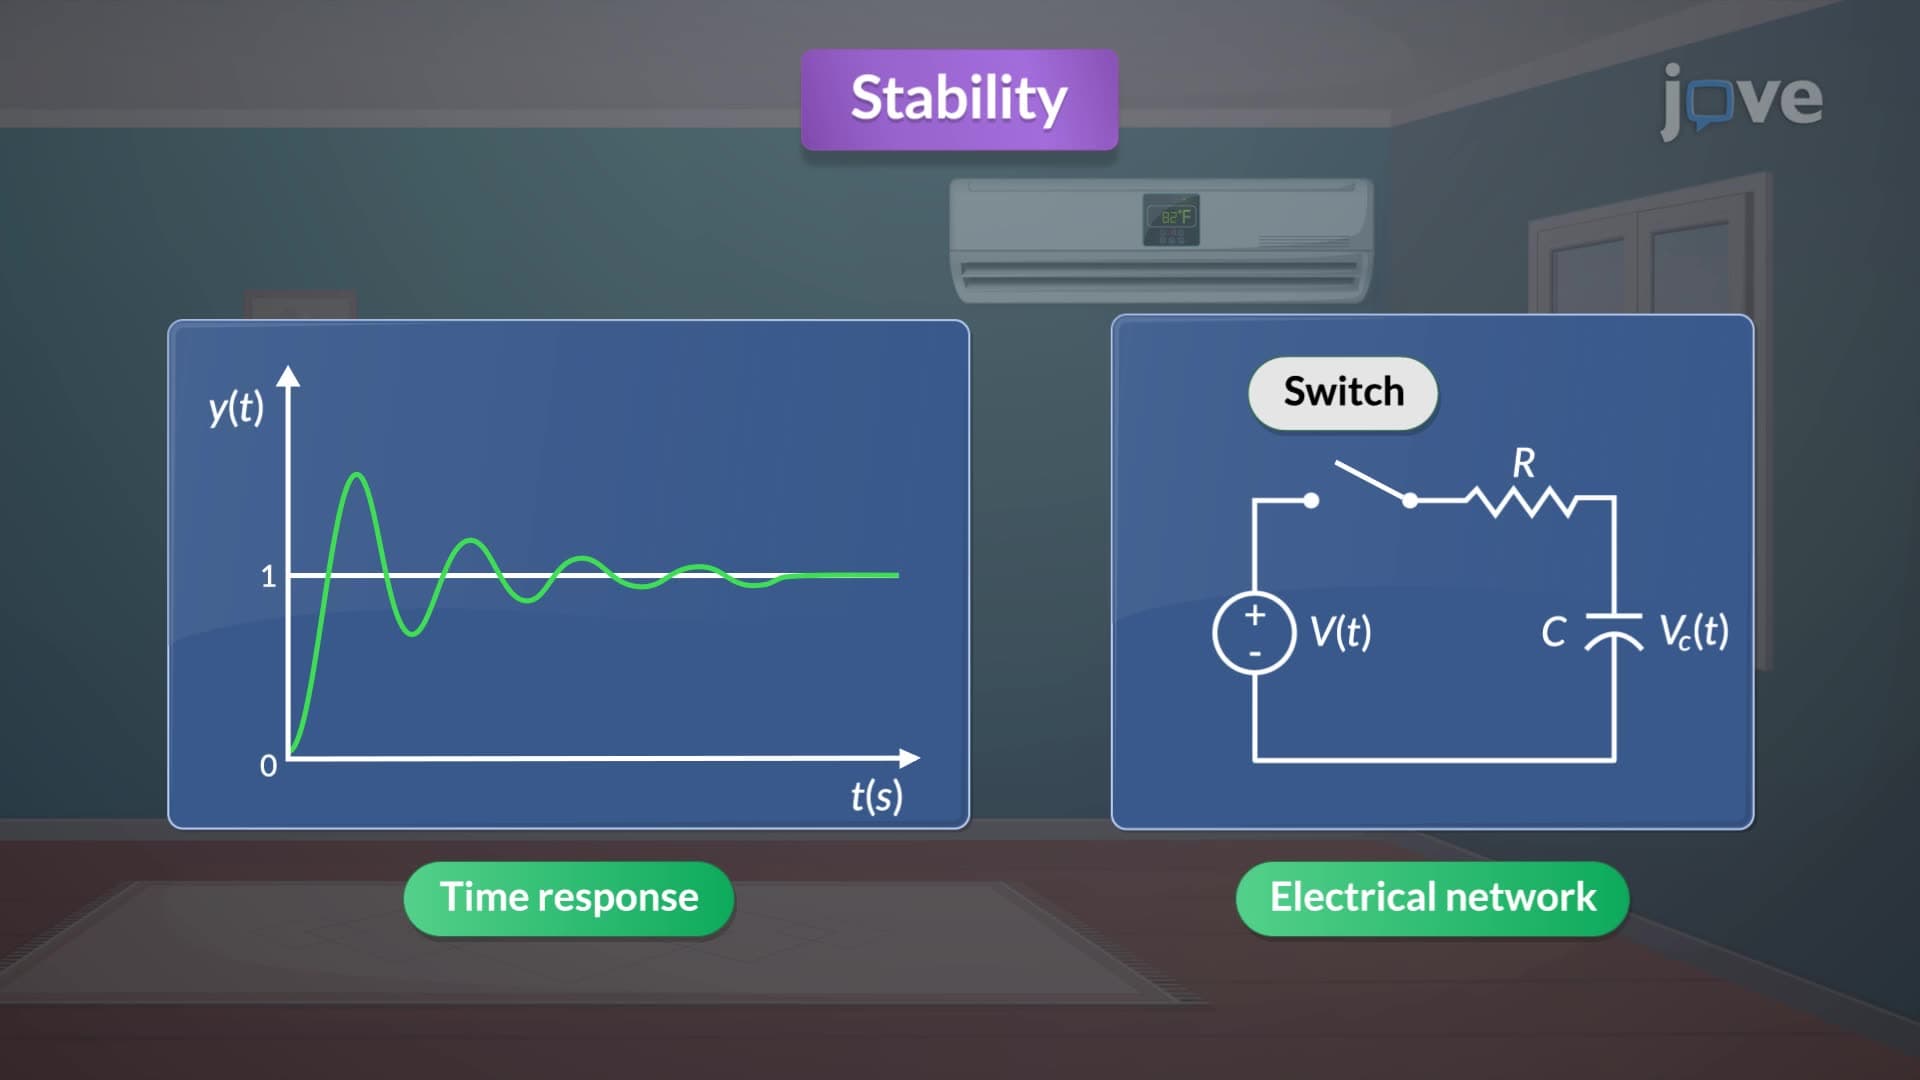
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:14
Stability of structures
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's response.
 01:13
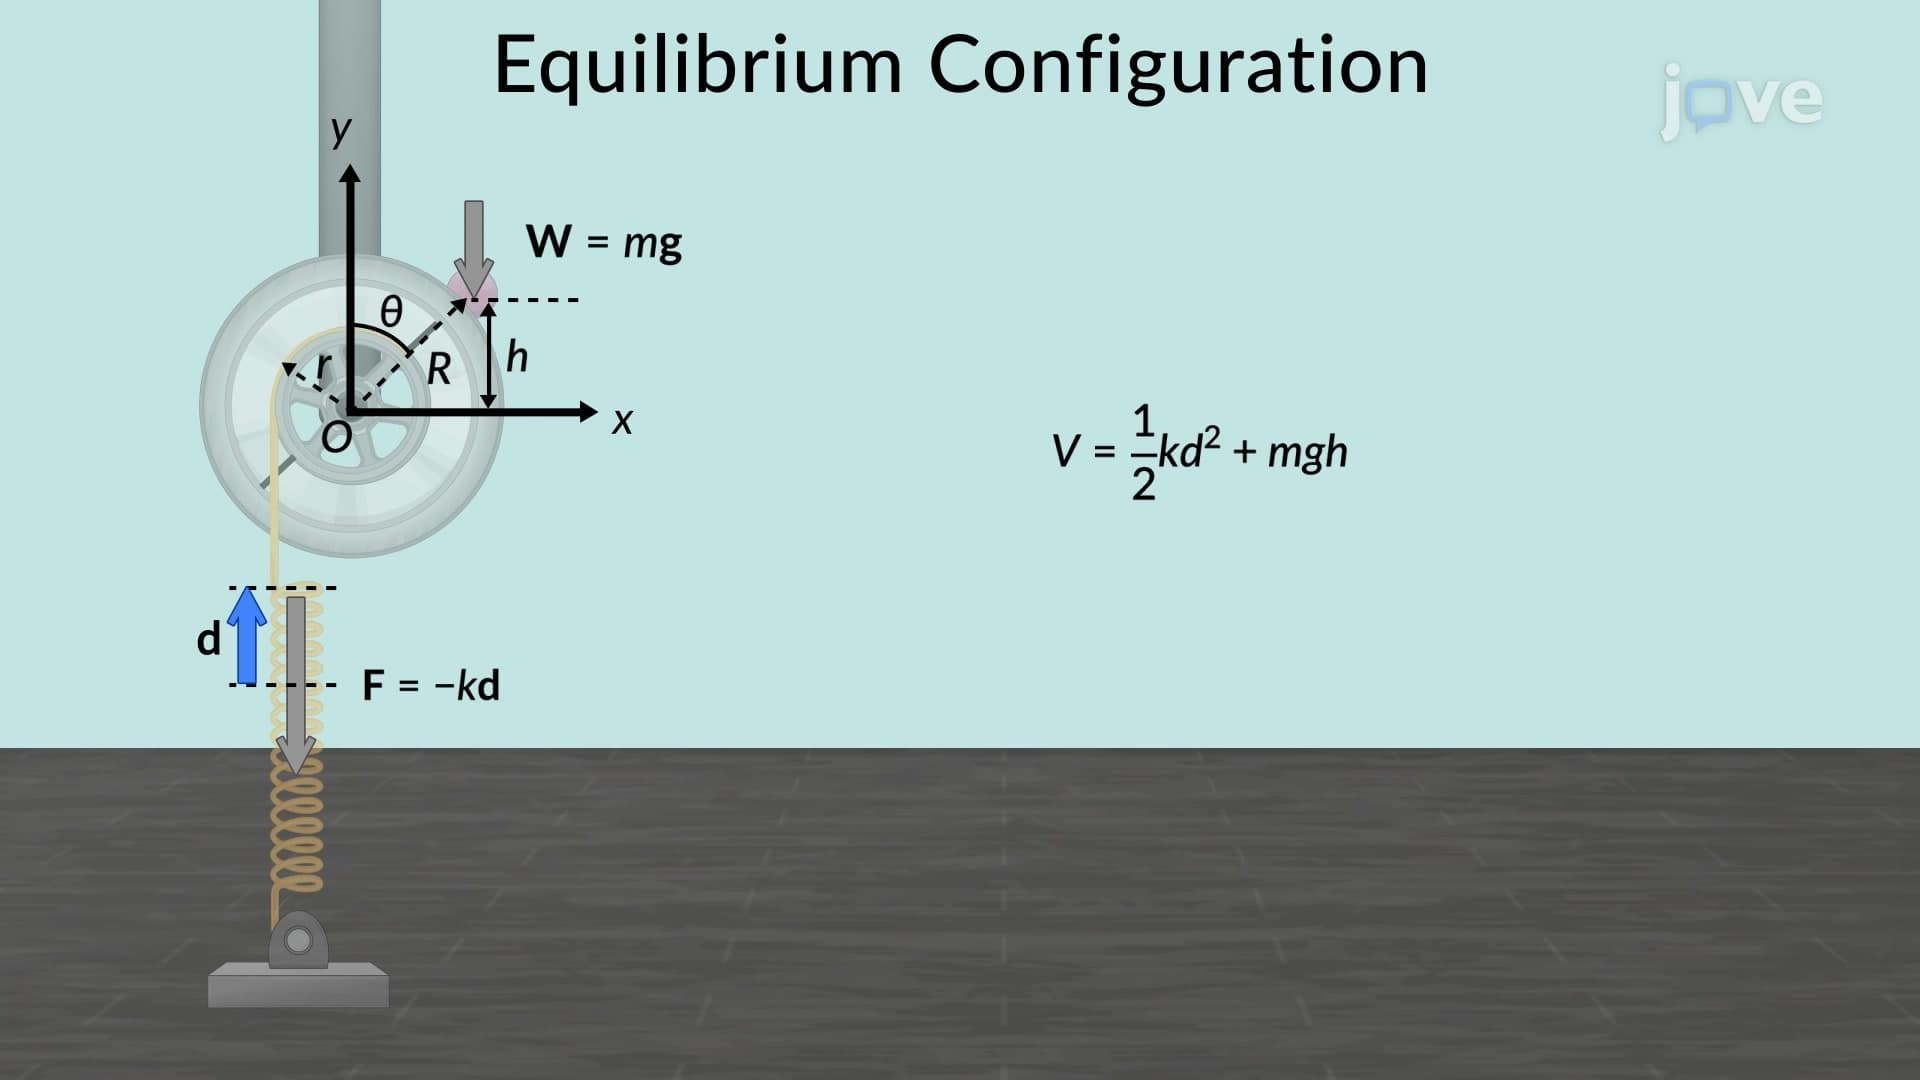
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:04
Oscillations about an Equilibrium Position
 01:21
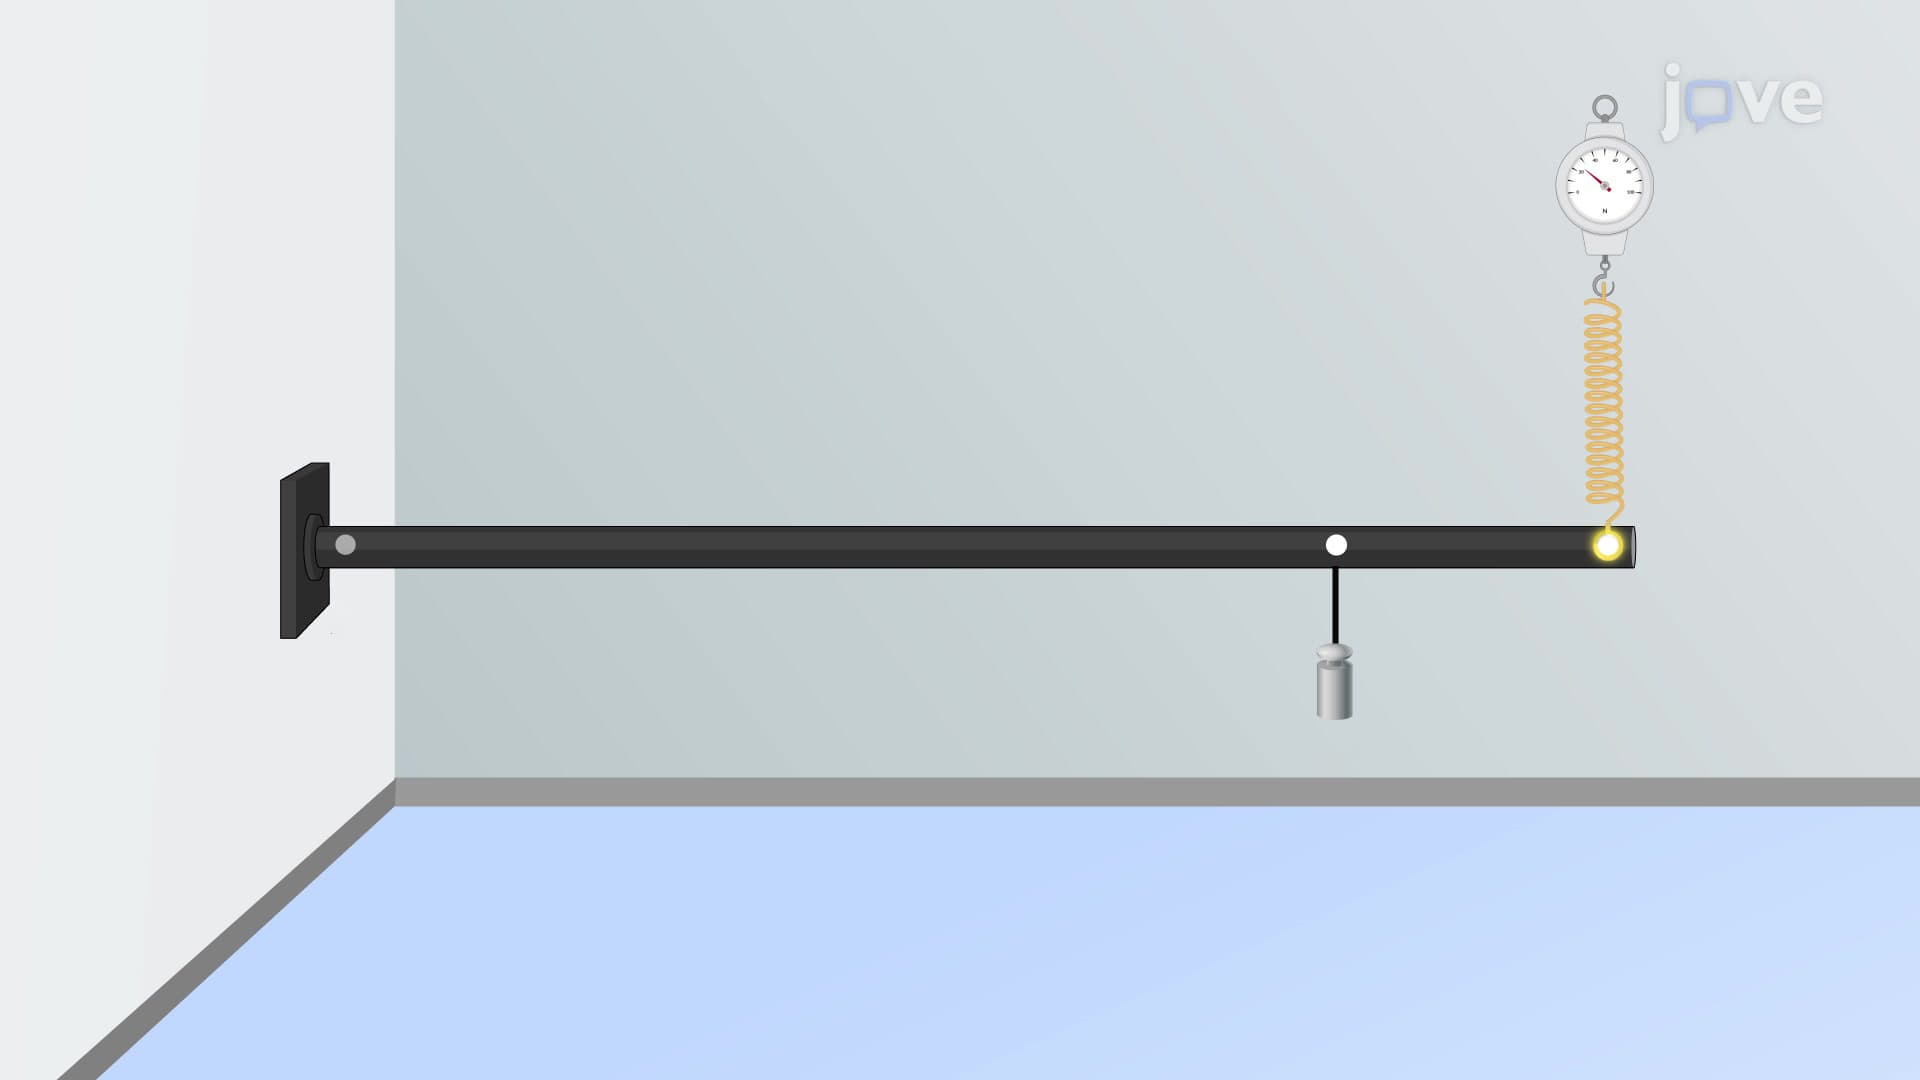
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?