Related Experiment Video
Updated: Feb 10, 2026

Vascularized Composite Hand Allograft Procurement and Preparation for Distal and Proximal Forearm Allotransplantation: A Stepwise Approach
Published on: May 23, 2025
Elbow load during pushup at various forearm rotations
1Institute of Biomedical Engineering, National Cheng Kung University, Tainan, Taiwan, ROC.

Objective:
Elbow joint loading was evaluated during pushup exercises at various forearm rotations.
Design:
Subjects were asked to perform pushup in various forearm rotations: neutral, 90 degrees internal rotation, and 90 degrees external rotation.
Background:
Training with pushup exercise is good for the muscles and joints of the upper extremities. However, excessive shear forces on the elbow might lead to injuries to either normal trainees or to handicapped people, especially for those who rely on elbow prosthesis.
Methods:
The kinematics and kinetics of the elbow joint were investigated under various forearm rotations.
Results:
The loading biomechanics of the elbow joint differed with various forearm rotations. It was noted that greater posterior and varus forces of the elbow are encountered with internal rotation of the hand position and, consequently, full forearm pronation.
Conclusions:
Pushup with hands in internally rotated position should be prevented so as to avoid excessive shear forces or moments.
Relevance:
Knowledge of elbow kinematics and kinetics may be helpful in preventing injuries by reducing the elbow shear force with changes of forearm rotation.
Related Concept Videos
 01:16
Muscles of the Forearm that Move the Hand and Fingers
Anterior Compartment
The anterior compartment muscles originate from the humerus. They primarily function as flexors and are also known as flexor muscles. They typically insert on the carpals, metacarpals, and phalanges. The superficial layer includes the flexor carpi...
 01:16
Muscles that Move the Forearm
Forearm Flexors
The biceps brachii, brachialis, and brachioradialis are forearm flexors. The biceps brachii is made up of two heads. Its long head originates at the supraglenoid tubercle of the scapula, whereas that of the short head is...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:11
Rotation of Asymmetric Top
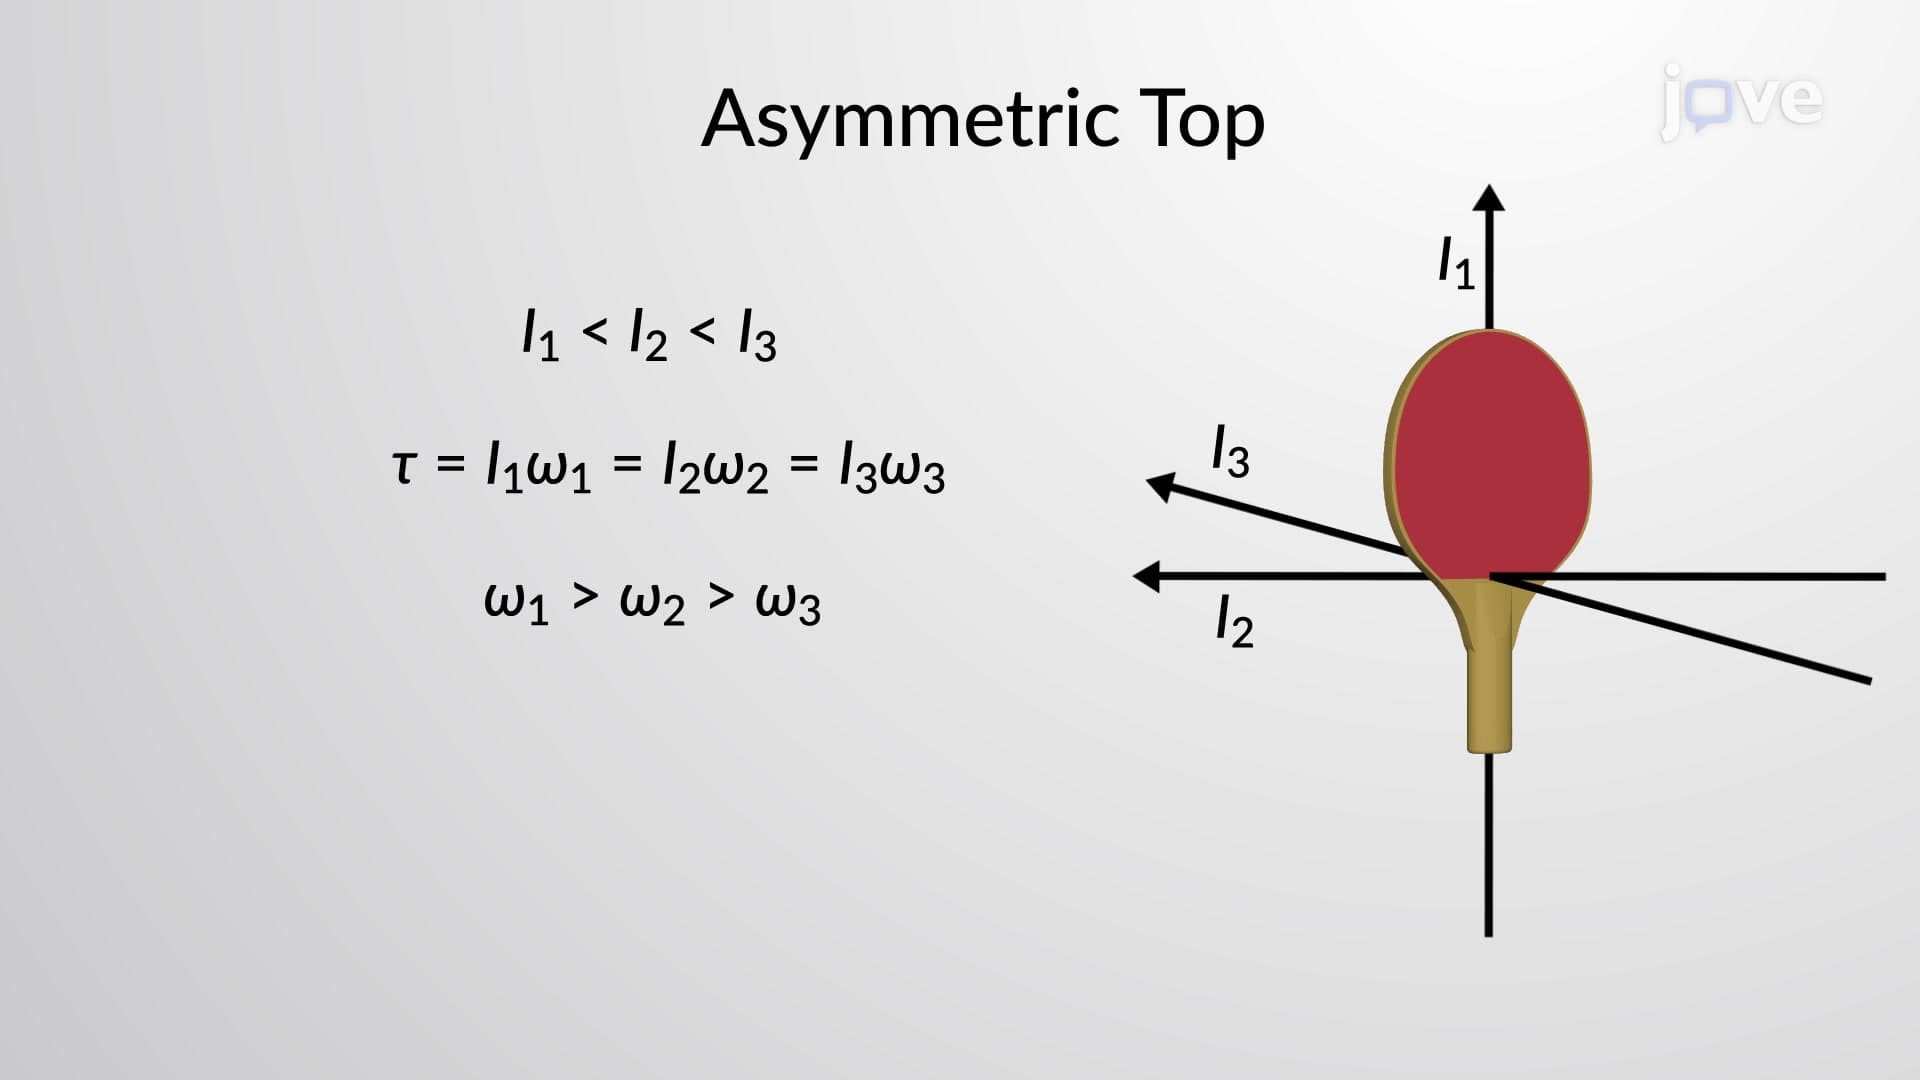
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
 01:19
Impact Loading
In cases of elastic deformation,...
 01:37
Rotation with Constant Angular Acceleration - I
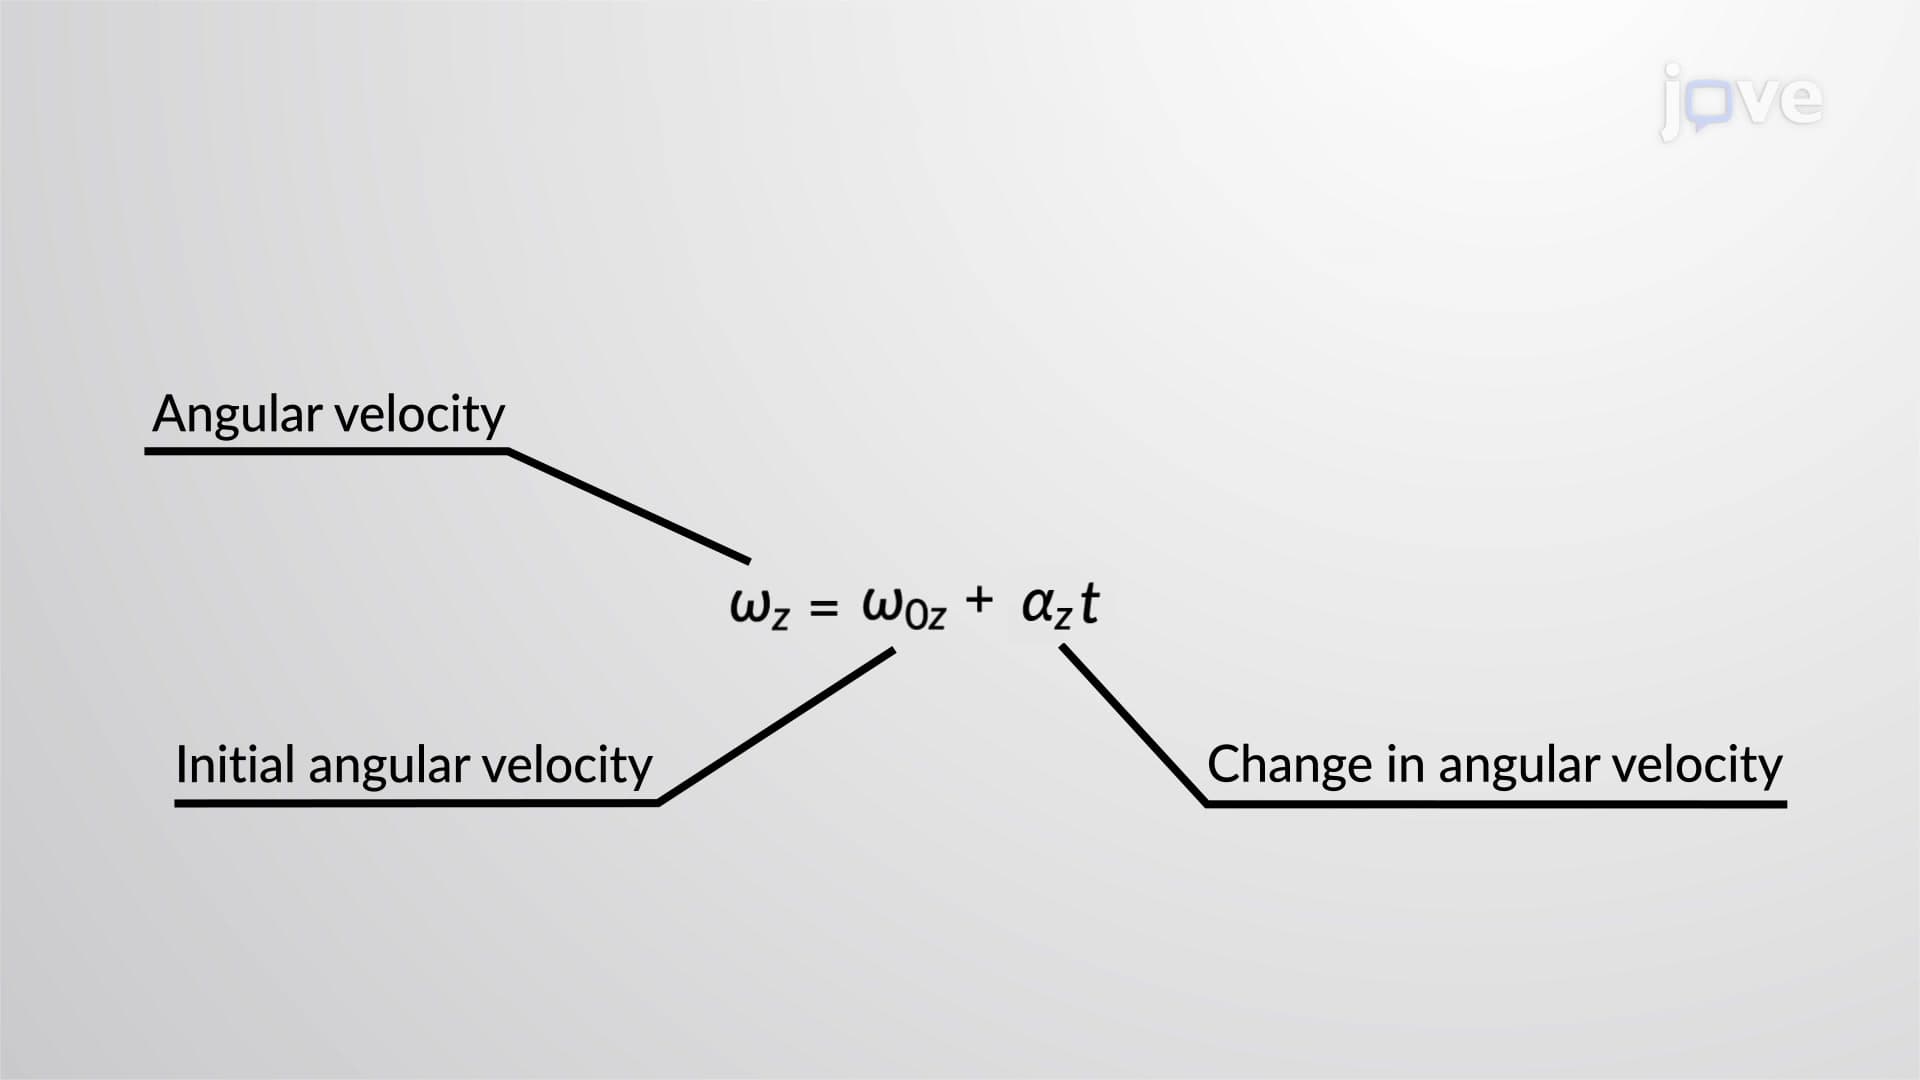
Using our intuition, we can begin to see how rotational quantities such as angular displacement, angular velocity, angular acceleration, and time are related to one another. For example, if a flywheel...