Stability in force-production tasks
Related Experiment Video
Updated: Oct 2, 2026
Force and Position Control in Humans - The Role of Augmented Feedback
Published on: June 19, 2016
1Department of Mechanical Engineering, Laval University, Sainte-Foy, Québec, Canada. boloria@gmc.ulaval.ca

Abstract:
Exerting a force on a mechanical system can induce mechanical instability. To overcome that instability, humans may take advantage of their upper limb mechanical impedance (e.g., hand stiffness). The authors investigated what stiffness is required to maintain static stability and how humans can achieve that stiffness in the context of the task of pushing on a pivoting stick. Results showed that the stiffness required is in the range of measured human upper limb stiffness. To avoid an ill-posed problem, one can better express the requirements for stability as a simple geometrical criterion related to the curvature of the potential energy field at the hand. A planar model of the upper limb revealed that individuals can use both hand rotational and translational stiffness to stabilize a stick. Although hand rotational stiffness does not participate in producing the axial force on the stick, it can significantly contribute to achieving a limb stiffness appropriate for maintaining static stability. Hand rotational stiffness can be important for the design of hand tools, because humans can increase it only by augmenting grip force, a biomechanical factor associated with cumulative trauma injuries of the upper extremities.
Related Concept Videos
 01:23
Stability of Equilibrium Configuration
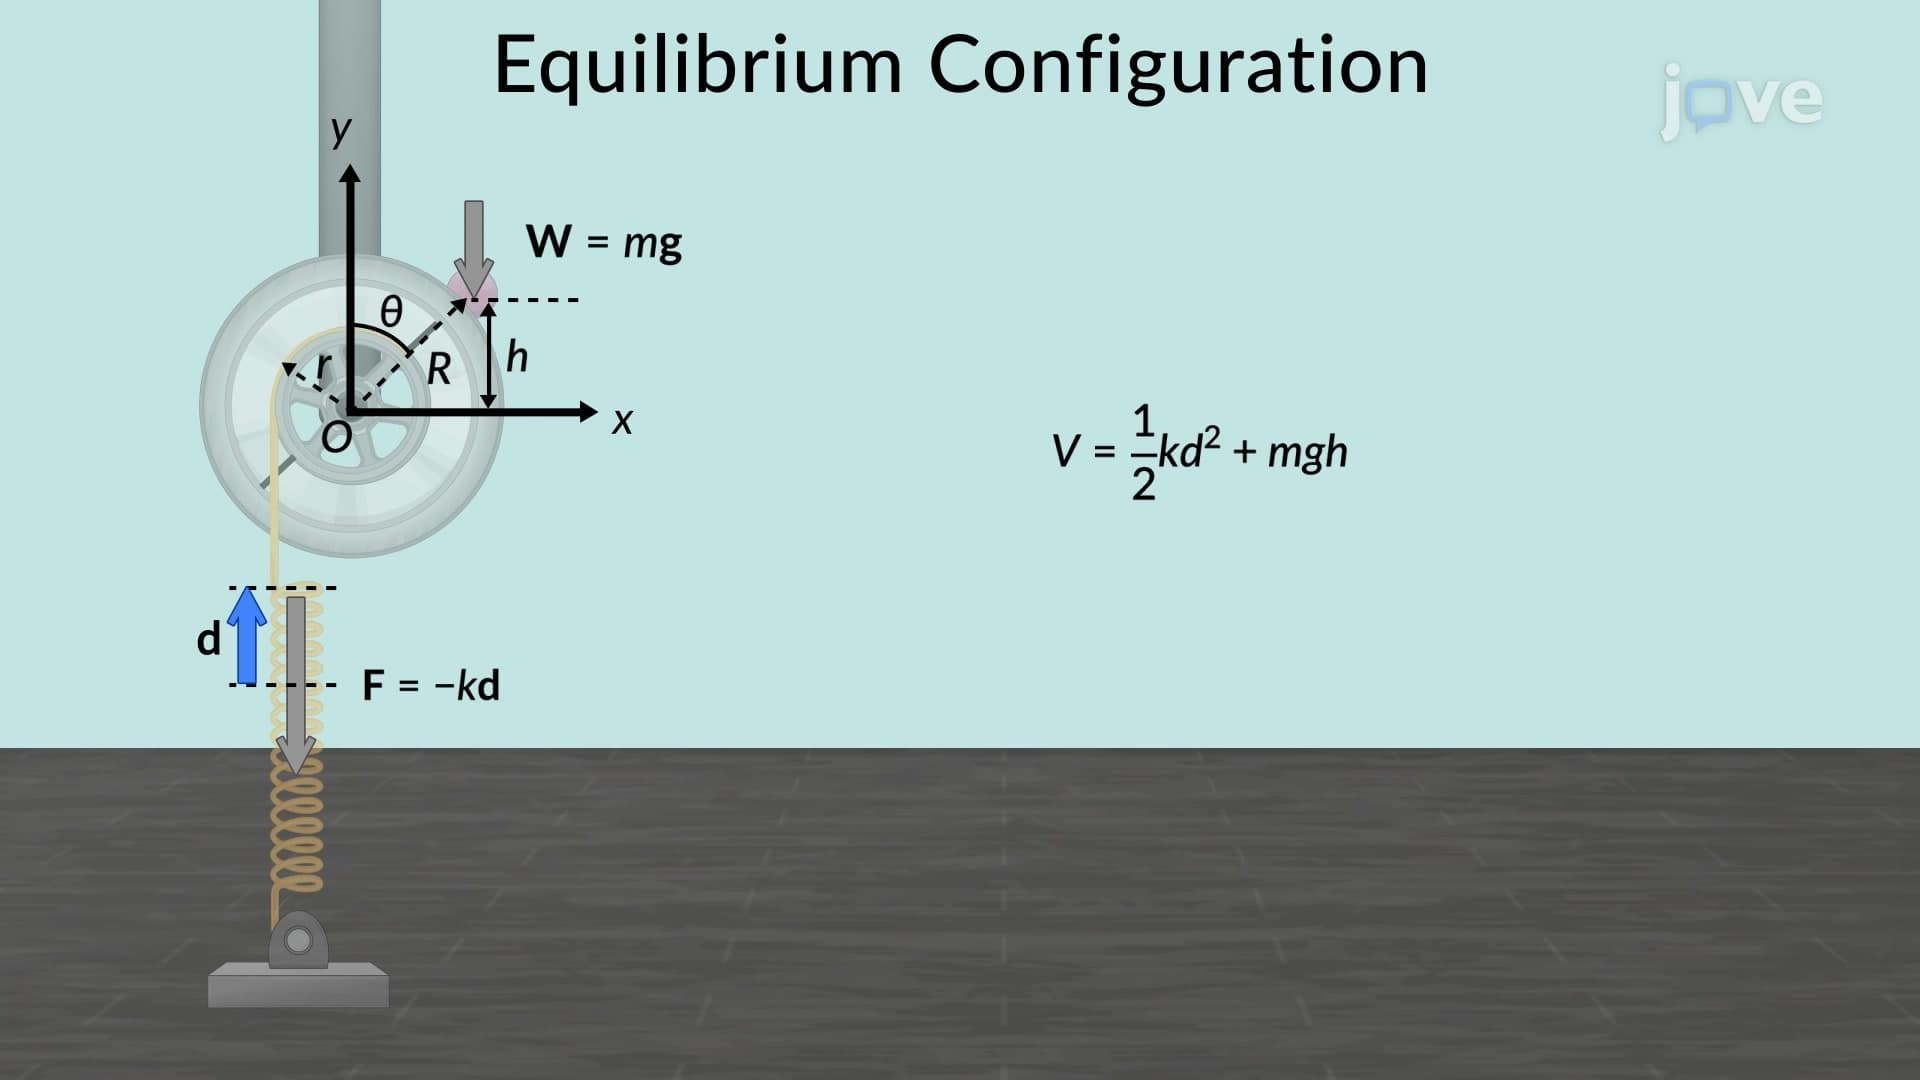
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
 01:13
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:14
Stability of structures
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's response.
 01:28
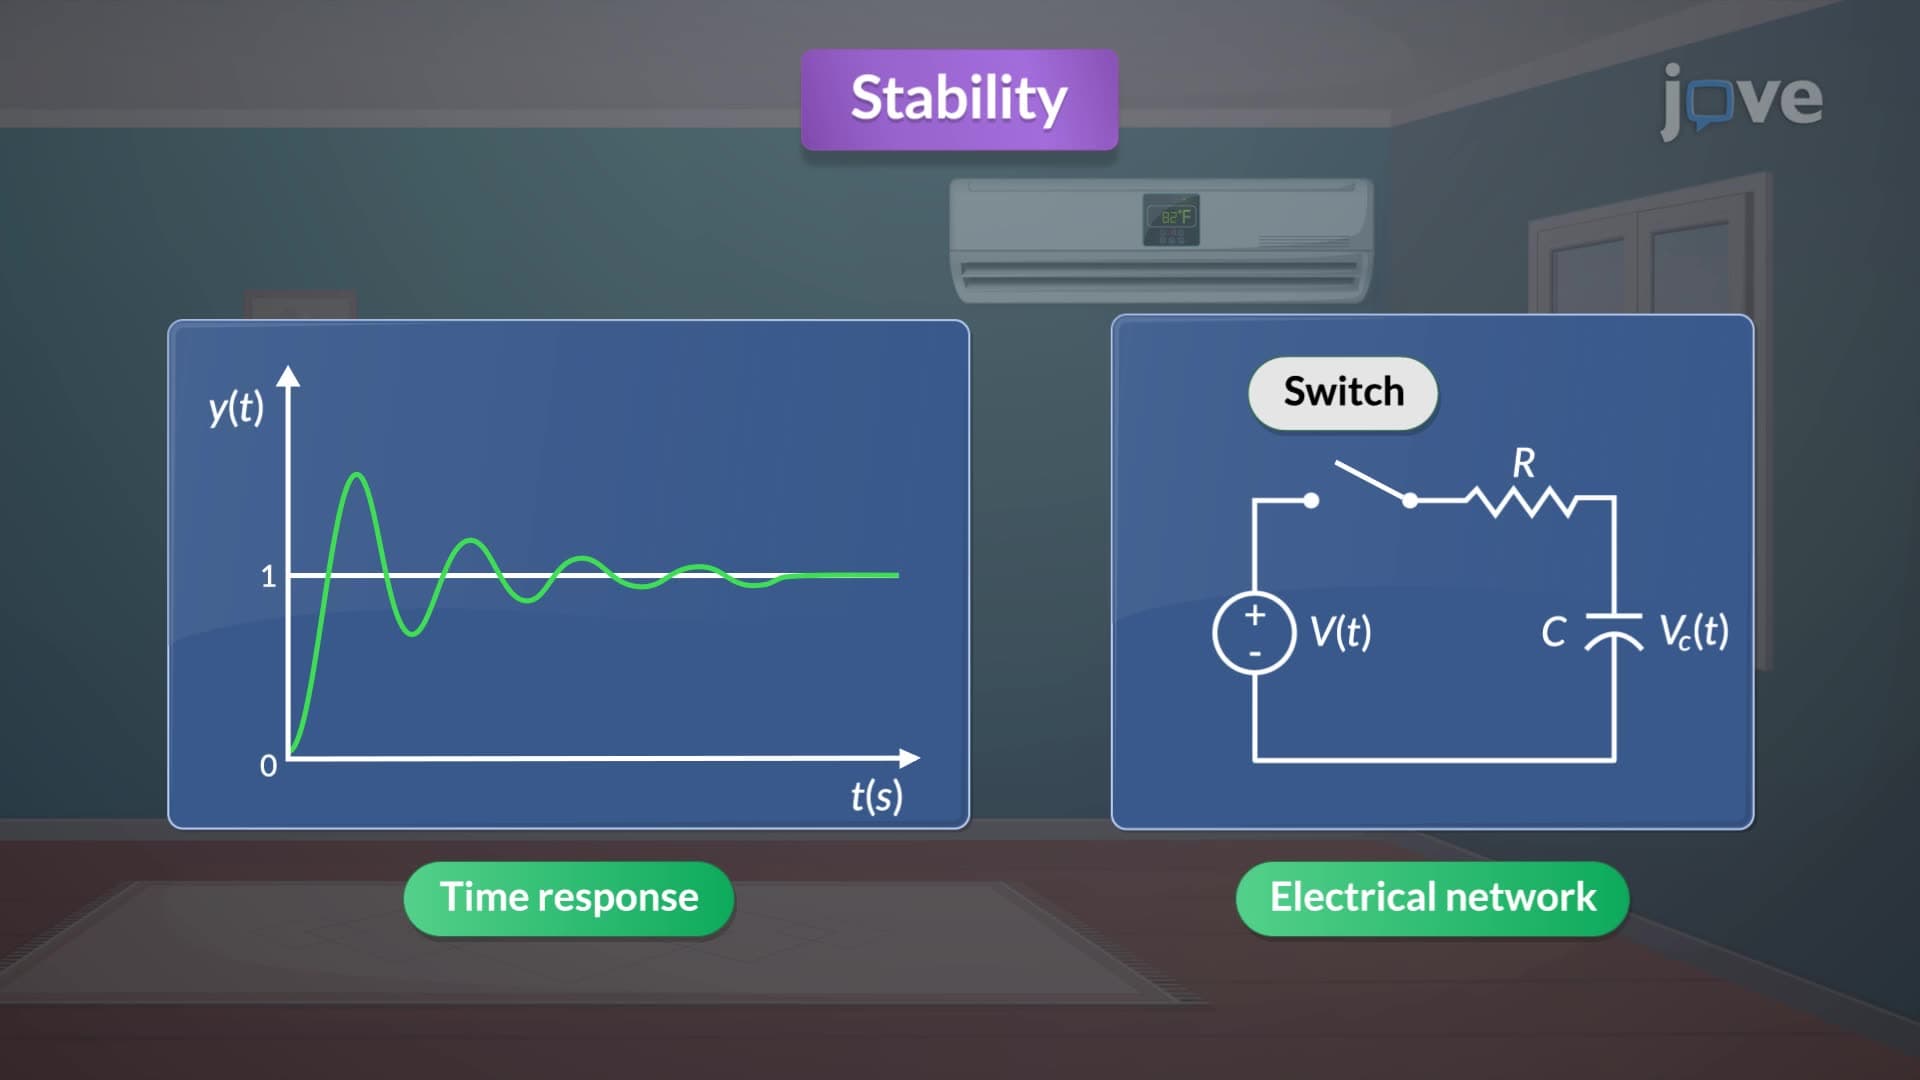
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:25
Multimachine Stability
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by: