Related Experiment Video
Updated: Aug 9, 2026
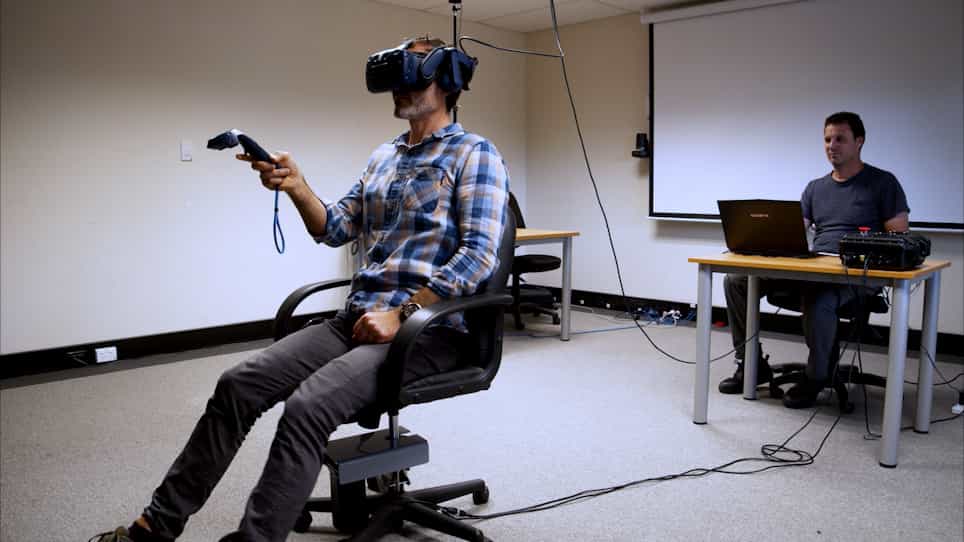

Controlled Rotation of Human Observers in a Virtual Reality Environment
Published on: April 21, 2022
Estimation of the finite center of rotation in planar movements
1Biomechanics Laboratory, The Pennsylvania State University, 39 Recreation Building, 16802-3408, University Park, PA, USA. jhc10@psu.edu

Abstract:
The finite center of rotation (FCR) is often used to assess joint function. It was the purpose of this study to compare the accuracy of the procedure of Crisco et al. [4] for estimating the FCR with a procedure which uses least-squares principles. The procedures were evaluated using noisy data rotated about a known FCR. Both procedures demonstrated increasing accuracy of FCR estimation with increasing rotation angle. As the centroid of a pair of markers was moved further from the FCR, accuracy of its location decreased. Noise levels had a strong influence on FCR estimation accuracy, with the least-squares procedure being better able to cope with noise. Increasing the number of landmarks increased FCR estimation accuracy. The accuracy of the procedure of Crisco et al. [4] increased when multiple estimates of the FCR were averaged. On all of the evaluations performed, the least-squares procedure gave small improvements in the accuracy of estimating the FCR, but was not able to circumvent the inaccuracies which arise when landmarks are not appropriately positioned, numerous, or if the rotation angle is small.

Related Concept Videos
 01:26
Rotational Motion about a Fixed Axis
 01:18
Equation of Motion: Rotation About a Fixed Axis
The tangential component is dependent on the direction of the angular acceleration of the flywheel. The tangential component of the acceleration propels the flywheel along its path. On the other hand,...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:20
Instantaneous Center of Zero Velocity
To analyze this, consider two points on the wheel: point A and point B. The absolute velocity of point B can be expressed as the vector sum of the absolute velocity of point A and the relative velocity of point B with respect to point A. To simplify this analysis,...
 01:12
Equation of Motion for a Rigid Body
The combined moments generated about the center of mass of the object are equal to the rate of change of the angular momentum of the body. An external force, when applied at a different point...
 01:30
Applications of Integration to Find Centers of Mass