Regularization in a neural model of motion perception
Related Experiment Video
Updated: Oct 5, 2026
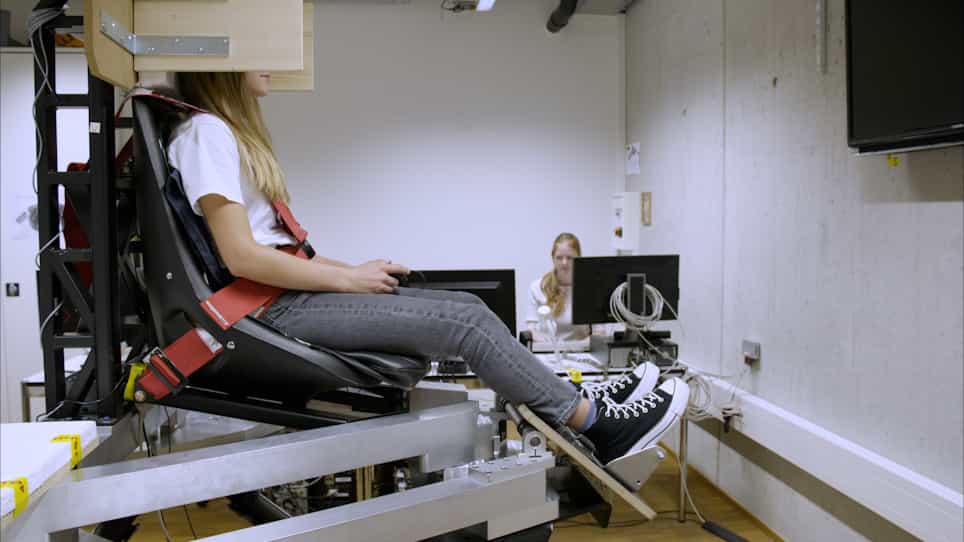
Estimating Vestibular Perceptual Thresholds Using a Six-Degree-Of-Freedom Motion Platform
Published on: August 4, 2022
1Department of Psychology, University College London, London WC1E 6BT, UK. kl@psychol.ucl.ac.uk

Abstract:
Neurons in sensory systems encode and transmit information about attributes of the environment. Much of the information transmitted by spiking neurons appears to be encoded in the rate at which they fire. This rate necessarily has a positive value. In this paper, the implication of this constraint for models of motion detection is examined. The detection of image motion is represented mathematically as a quadratic programming problem in which variables used to represent image speed are restricted to positive values. This novel representation requires that additional constraints are introduced to stabilize motion computations because quadratic programming problems require a surplus of unknowns to code for image speed. Two further constraints are introduced into the model to take into account possible cases of image degeneracy. They are based upon (i) an a priori preference for small image speeds, and (ii) the assumption that image motion parallel to contours of constant intensity for a one-dimensional signal is zero. The latter assumption is shown to account for perceived biases in speed reported for type I plaid patterns [Castet, E. & Morgan, M. (1996). Apparent speed of type-I symmetrical plaids. Vision Research 36, 223-32]. The model suggests that the visual system uses separate constraints to stabilize motion computations. One set of constraints arises from the nature of the motion detection process itself, while another two constraints take into account possible cases of degeneracy where image contrast is low or near zero and where the image function is one-dimensional and the aperture problem prevails.

Related Concept Videos
 01:47
Neural Regulation
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:27
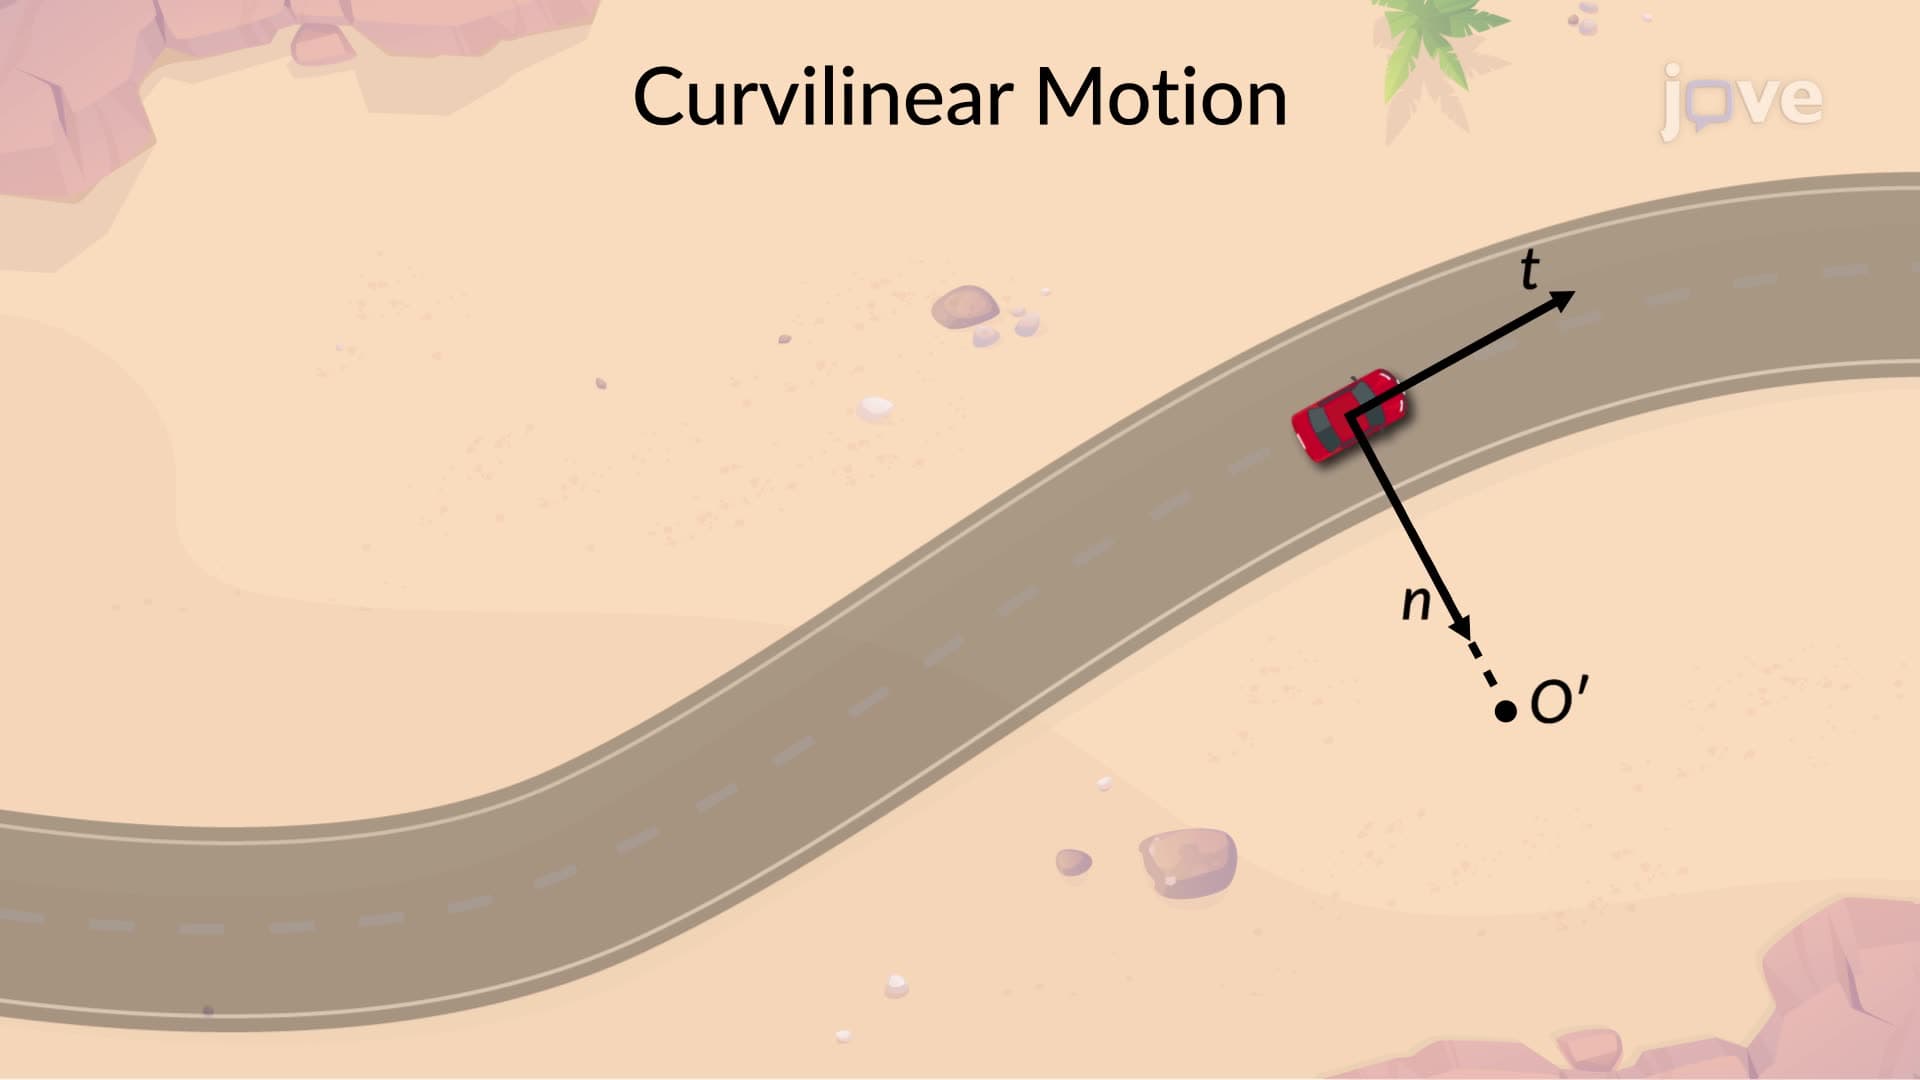
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:27
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position with respect to time...
 01:23
Propagation of Action Potentials
Neurons (nerve cells) have a resting membrane potential, with a slightly negative charge inside compared to outside. This is maintained by ion channels, such as sodium (Na+) and potassium (K+) channels, which control the flow of ions. When a stimulus, like a touch or a signal from another neuron, triggers the neuron, sodium channels open, allowing sodium ions to...
 01:26
Linearization and Approximation