Related Experiment Video
Updated: Jun 24, 2026


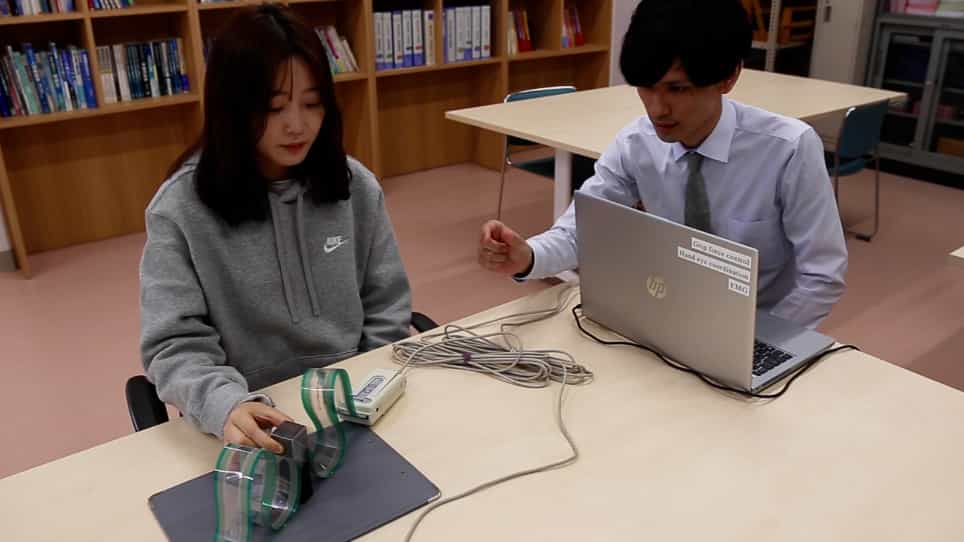
A Human-machine-interface Integrating Low-cost Sensors with a Neuromuscular Electrical Stimulation System for Post-stroke Balance Rehabilitation
Published on: April 12, 2016
Force can overcome object geometry in the perception of shape through active touch
G Robles-De-La-Torre1, V Hayward
1McGill University, Center for Intelligent Machines, Montréal,Canada H3A 2A7. roblesg@cim.mcgill.ca

Abstract:
Haptic (touch) perception normally entails an active exploration of object surfaces over time. This is called active touch. When exploring the shape of an object, we experience both geometrical and force cues. For example, when sliding a finger across a surface with a rigid bump on it, the finger moves over the bump while being opposed by a force whose direction and magnitude are related to the slope of the bump. The steeper the bump, the stronger the resistance. Geometrical and force cues are correlated, but it has been commonly assumed that shape perception relies on object geometry alone. Here we show that regardless of surface geometry, subjects identified and located shape features on the basis of force cues or their correlates. Using paradoxical stimuli, for example combining the force cues of a bump with the geometry of a hole, we found that subjects perceived a bump. Conversely, when combining the force cues of a hole with the geometry of a bump, subjects typically perceived a hole.

Related Concept Videos
 01:06
Force
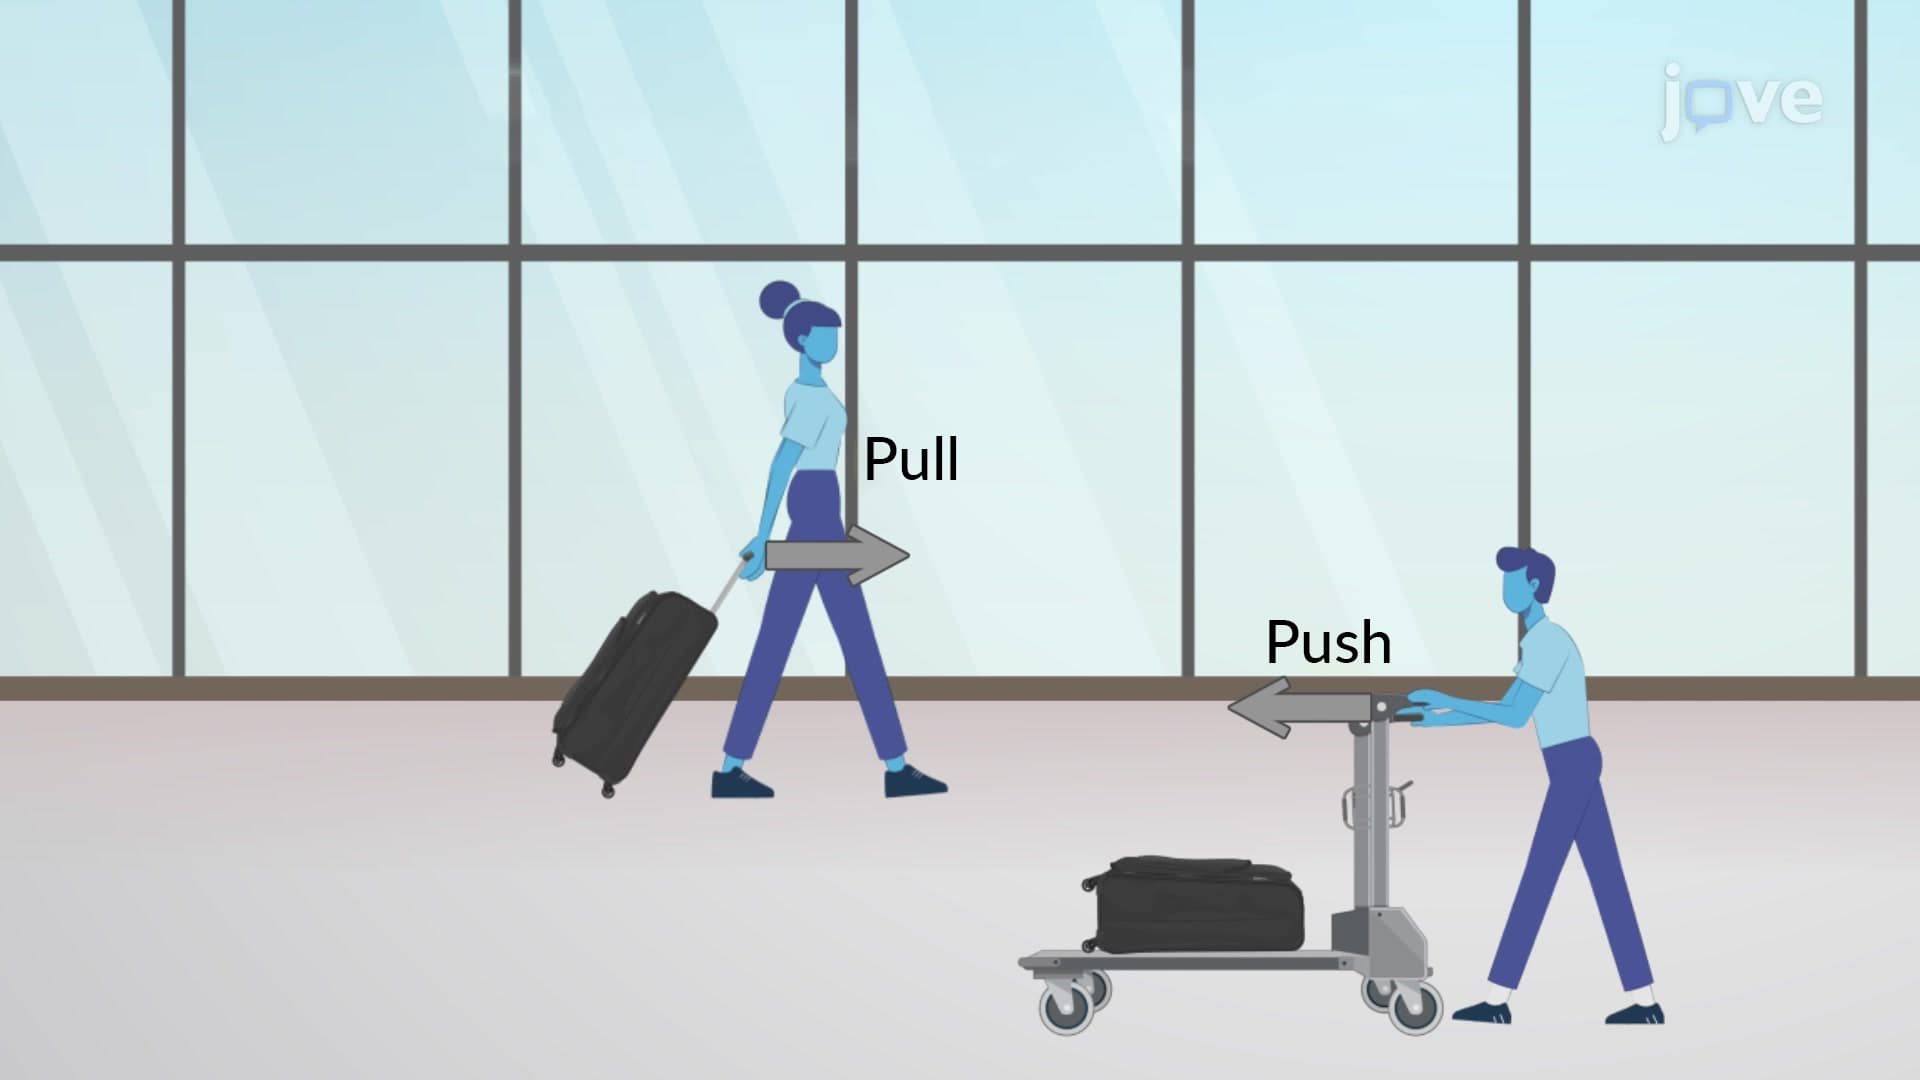
The study of motion is called kinematics, but kinematics only describes the way...
 01:13
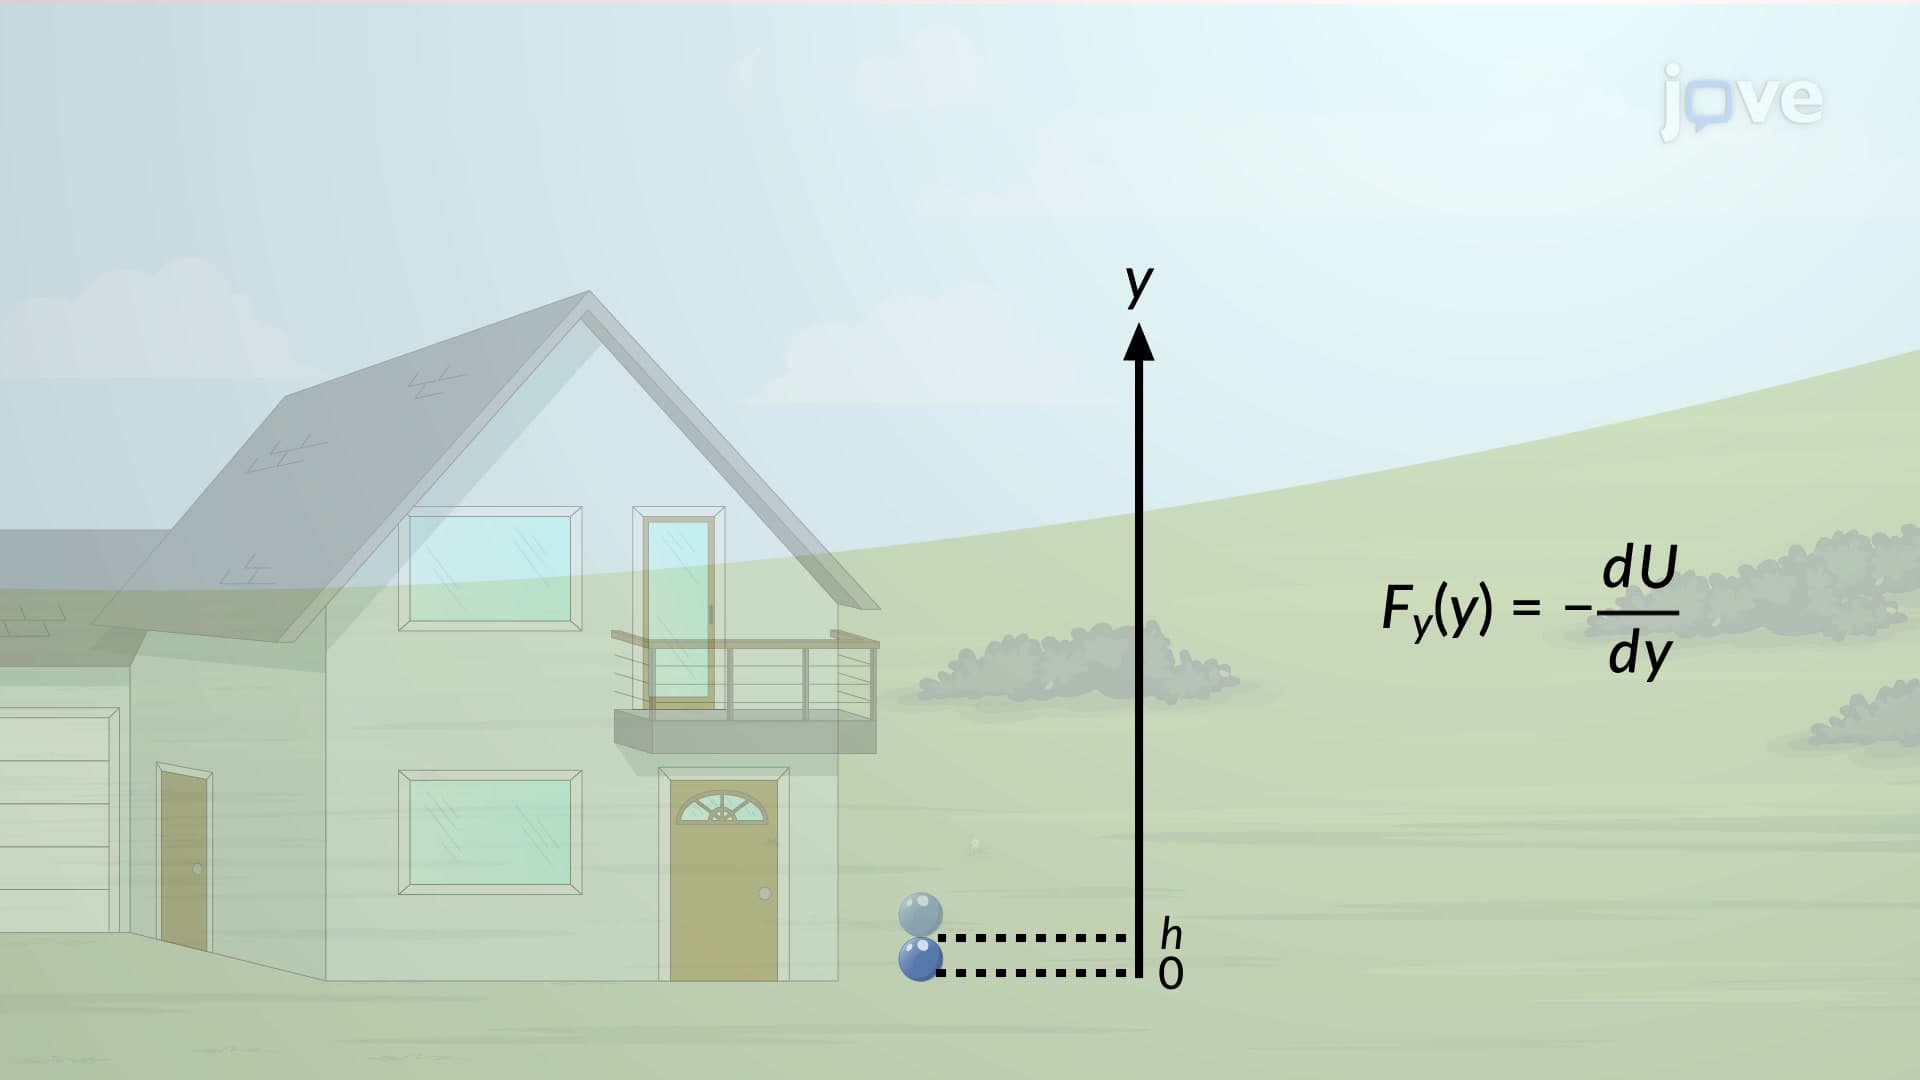
Force and Potential Energy in One Dimension
 01:04
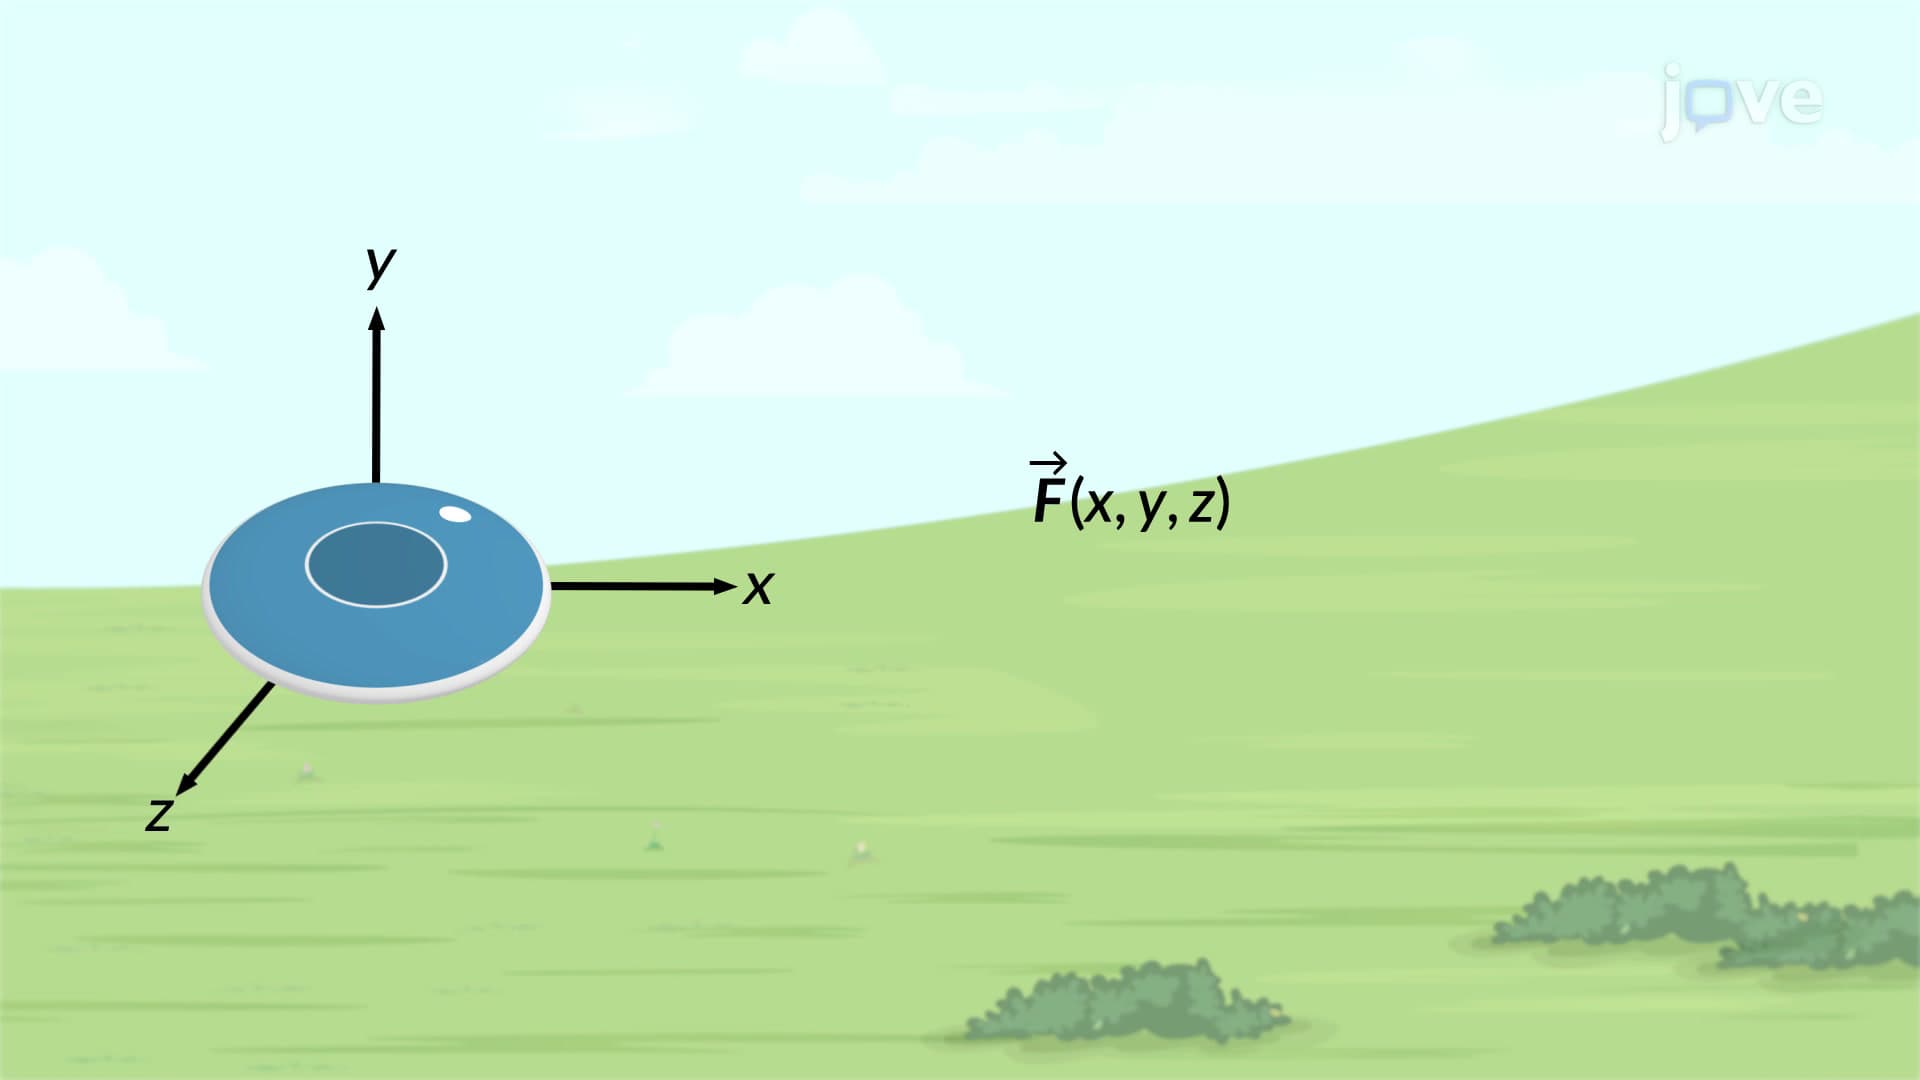
Force and Potential Energy in Three Dimensions
 01:18
Moment of a Force: Scalar Formulation
Consider a simple example of a flywheel being rotated about a point, O, by applying a force to it. In this case, the moment arm is the perpendicular distance between the point O and the line of action of the force. The...
 01:29
Moment of a Force: Problem Solving
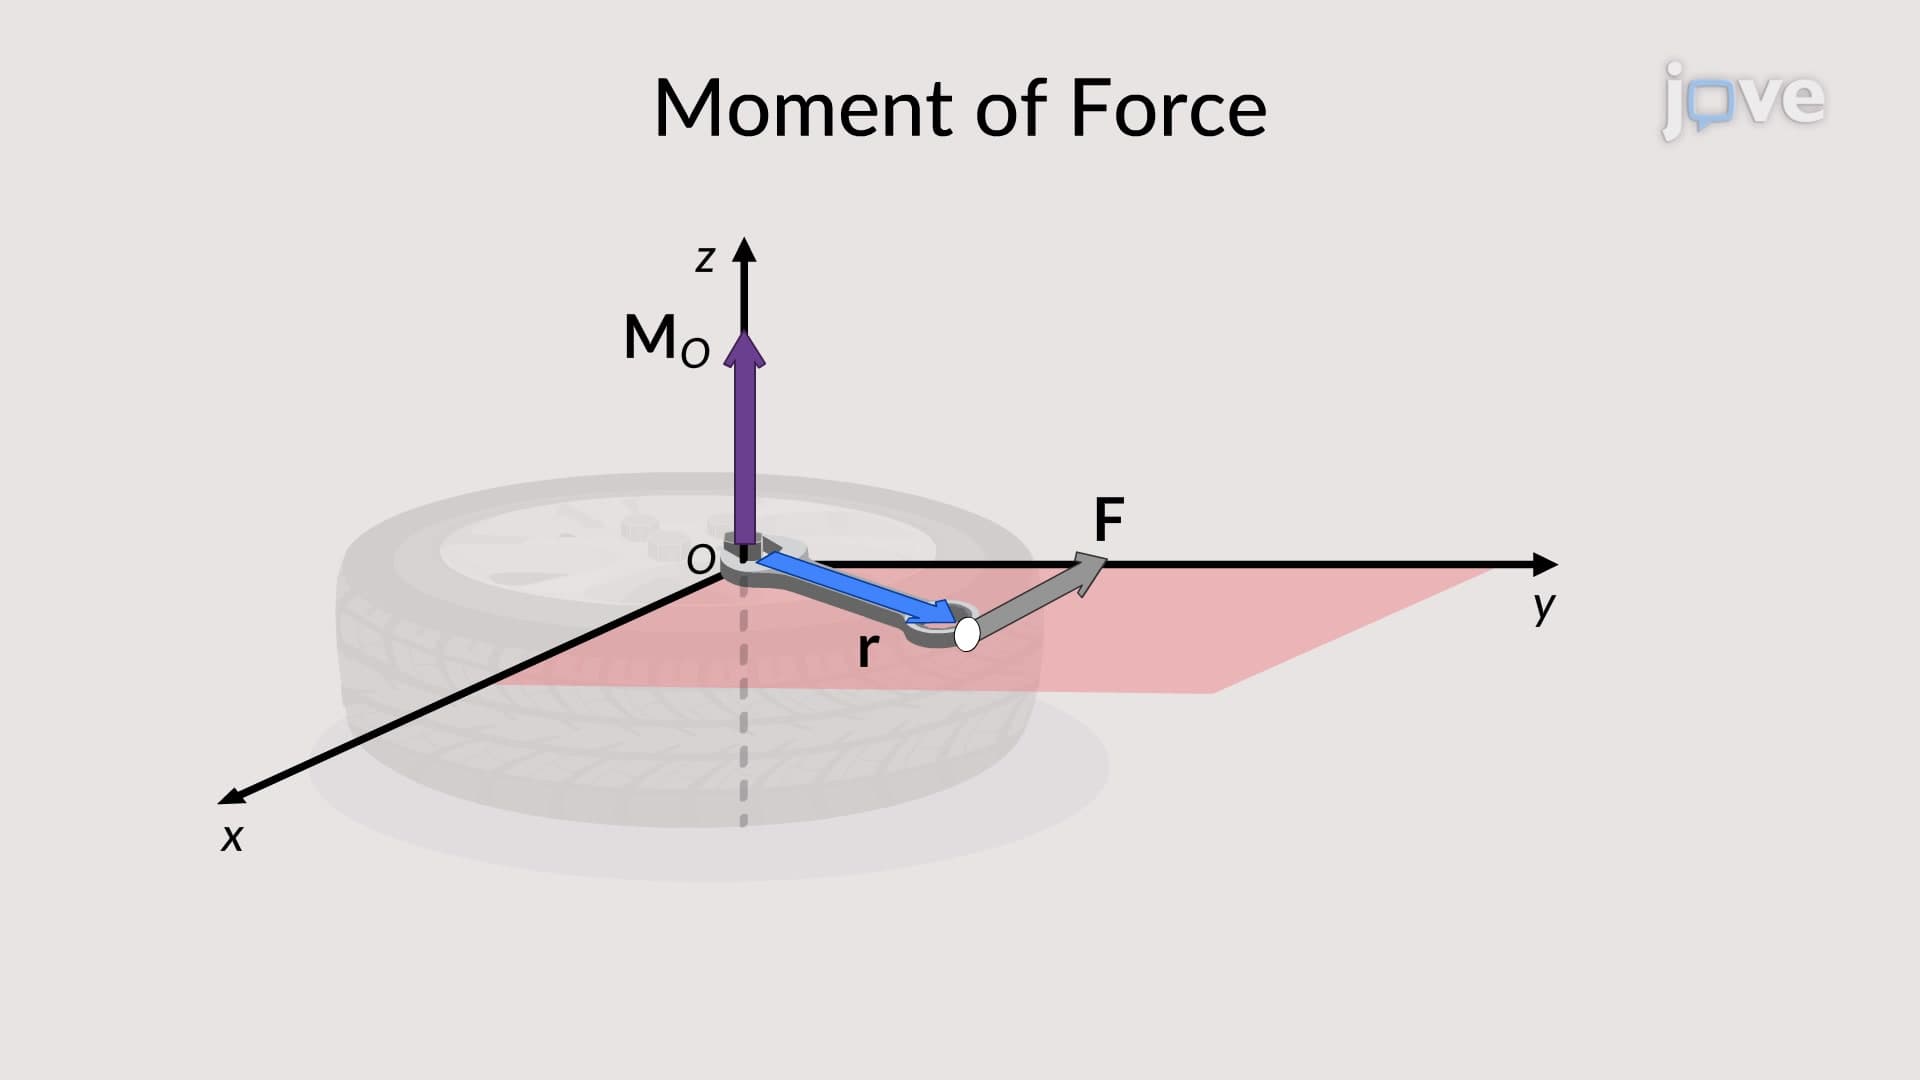 01:27
Moment of a Force: Vector Formulation
The vector formulation of the moment of force is the cross-product of the position and force vectors. The...