Identification of time-varying Hammerstein systems from ensemble data

M Lortie1, R E Kearney

  • 1Department of Biomedical Engineering, McGill University, Montréal, Québec, Canada.

Related Concept Videos

Linear Approximation in Time Domain01:21

Linear Approximation in Time Domain

Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
Classification of Systems-II01:31

Classification of Systems-II

Continuous-time systems have continuous input and output signals, with time measured continuously. These systems are generally defined by differential or algebraic equations. For instance, in an RC circuit, the relationship between input and output voltage is expressed through a differential equation derived from Ohm's law and the capacitor relation,
Linear time-invariant Systems01:23

Linear time-invariant Systems

A system is linear if it displays the characteristics of homogeneity and additivity, together termed the superposition property. This principle is fundamental in all linear systems. Linear time-invariant (LTI) systems include systems with linear elements and constant parameters.
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
Second Order systems II01:18

Second Order systems II

In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
If  ζ...
Discrete Fourier Transform01:15

Discrete Fourier Transform

The Discrete Fourier Transform (DFT) is a fundamental tool in signal processing, extending the discrete-time Fourier transform by evaluating discrete signals at uniformly spaced frequency intervals. This transformation converts a finite sequence of time-domain samples into frequency components, each representing complex sinusoids ordered by frequency. The DFT translates these sequences into the frequency domain, effectively indicating the magnitude and phase of each frequency component present...
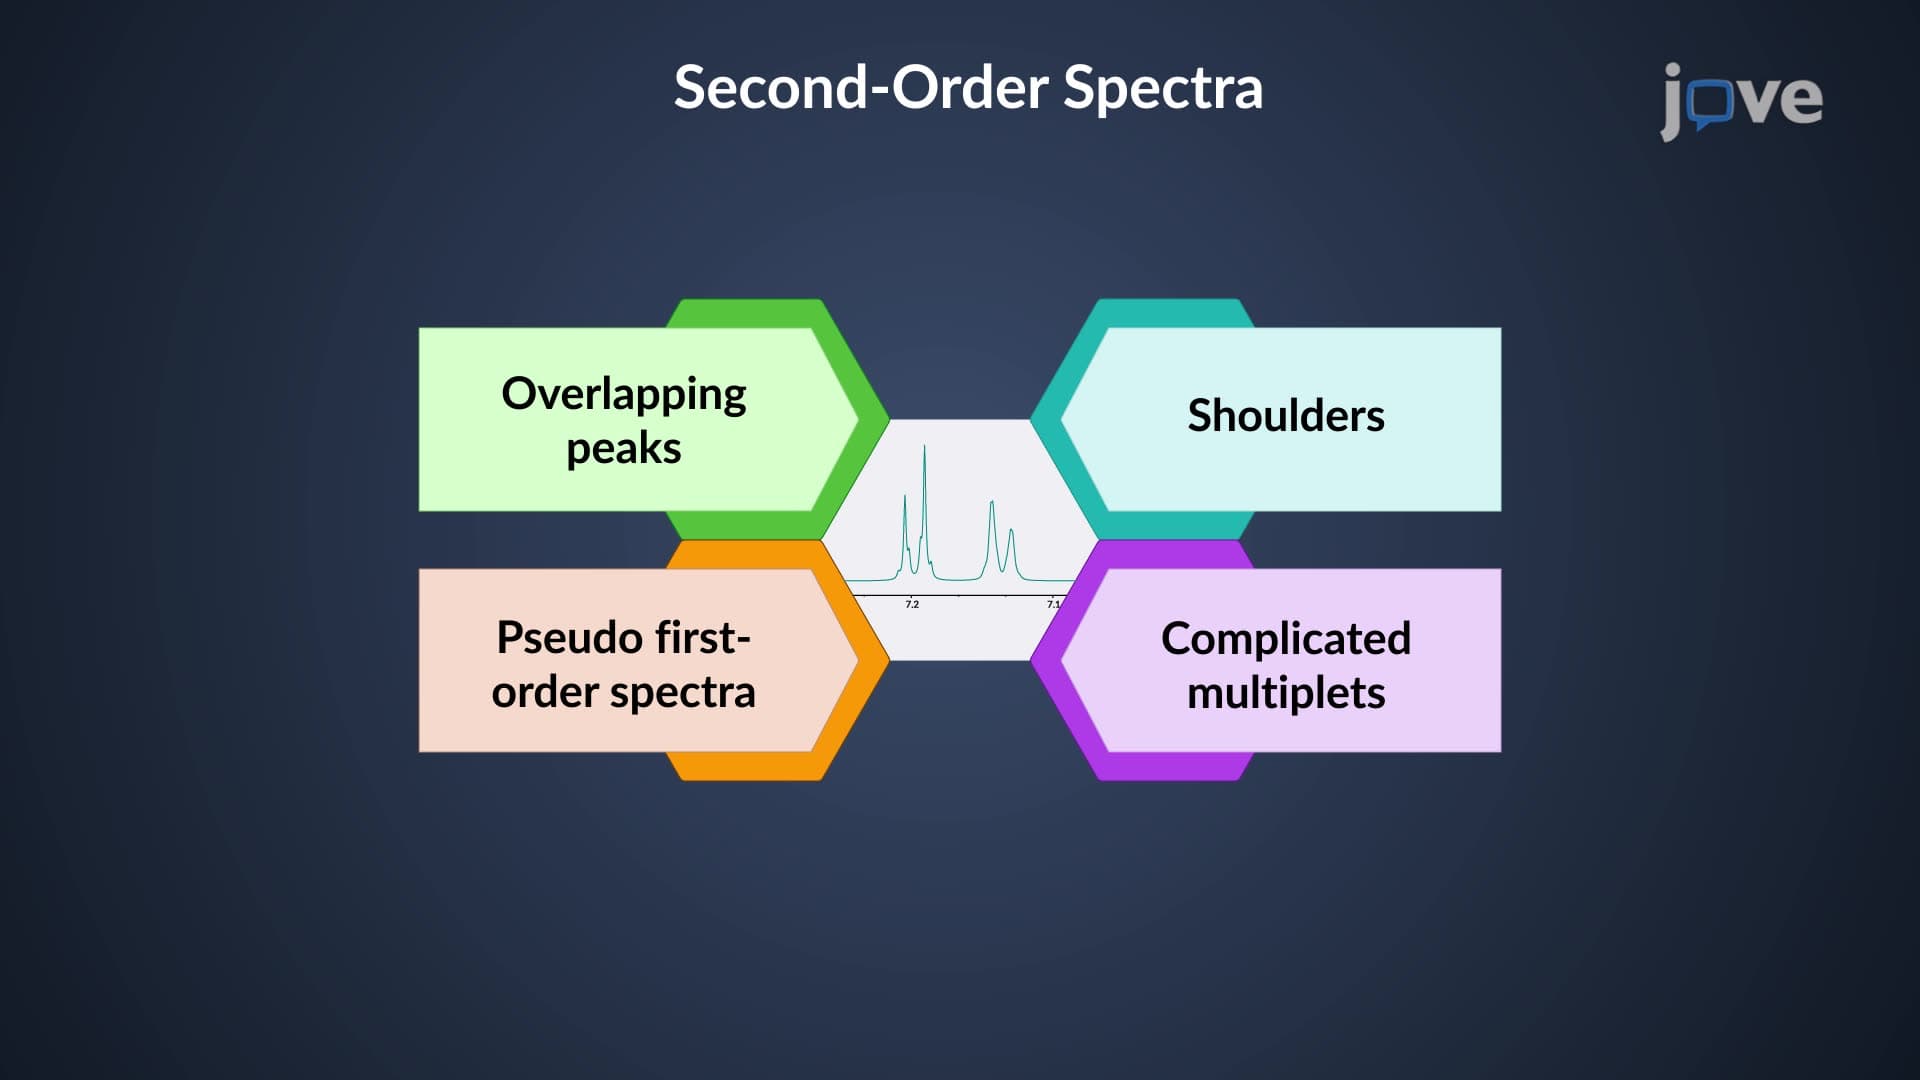
¹H NMR: Interpreting Distorted and Overlapping Signals01:02

¹H NMR: Interpreting Distorted and Overlapping Signals

Spin systems where the difference in chemical shifts of the coupled nuclei is greater than ten times J are called first-order spin systems. These nuclei are weakly coupled, and their chemical shifts and coupling constant can generally be estimated from the well-separated signals in the spectrum.
As Δν decreases and the signals move closer, the doublets appear increasingly distorted. The intensities of the inner lines increase at the cost of those of the outer lines as the signals are slanted or...