A 3-D dynamic model of human finger for studying free movements
Related Experiment Video
Updated: Oct 3, 2026

Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023
J L Sancho-Bru1, A Pérez-González, M Vergara-Monedero
1Departament de Tecnologia, Universitat Jaume I, Campus de Riu Sec, 12071 Castellò, Spain. sancho@tec.uji.es

Abstract:
The purpose of this work is to develop a 3D inverse dynamic model of the human finger for estimating the muscular forces involved during free finger movements. A review of the existing 3D models of the fingers is presented, and an alternative one is proposed. The validity of the model has been proved by means of two simulations: free flexion-extension motion of all joints, and free metacarpophalangeal (MCP) adduction motion. The simulation shows the need for a dynamic model including inertial effects when studying fast movements and the relevance of modelling passive forces generated by the structures studying free movements, such as the force exerted by the muscles when they are stretched and the passive action of the ligaments over the MCP joint in order to reproduce the muscular force pattern during the simulation of the free MCP abduction-adduction movements.
More Related Videos
Related Concept Videos
 01:30
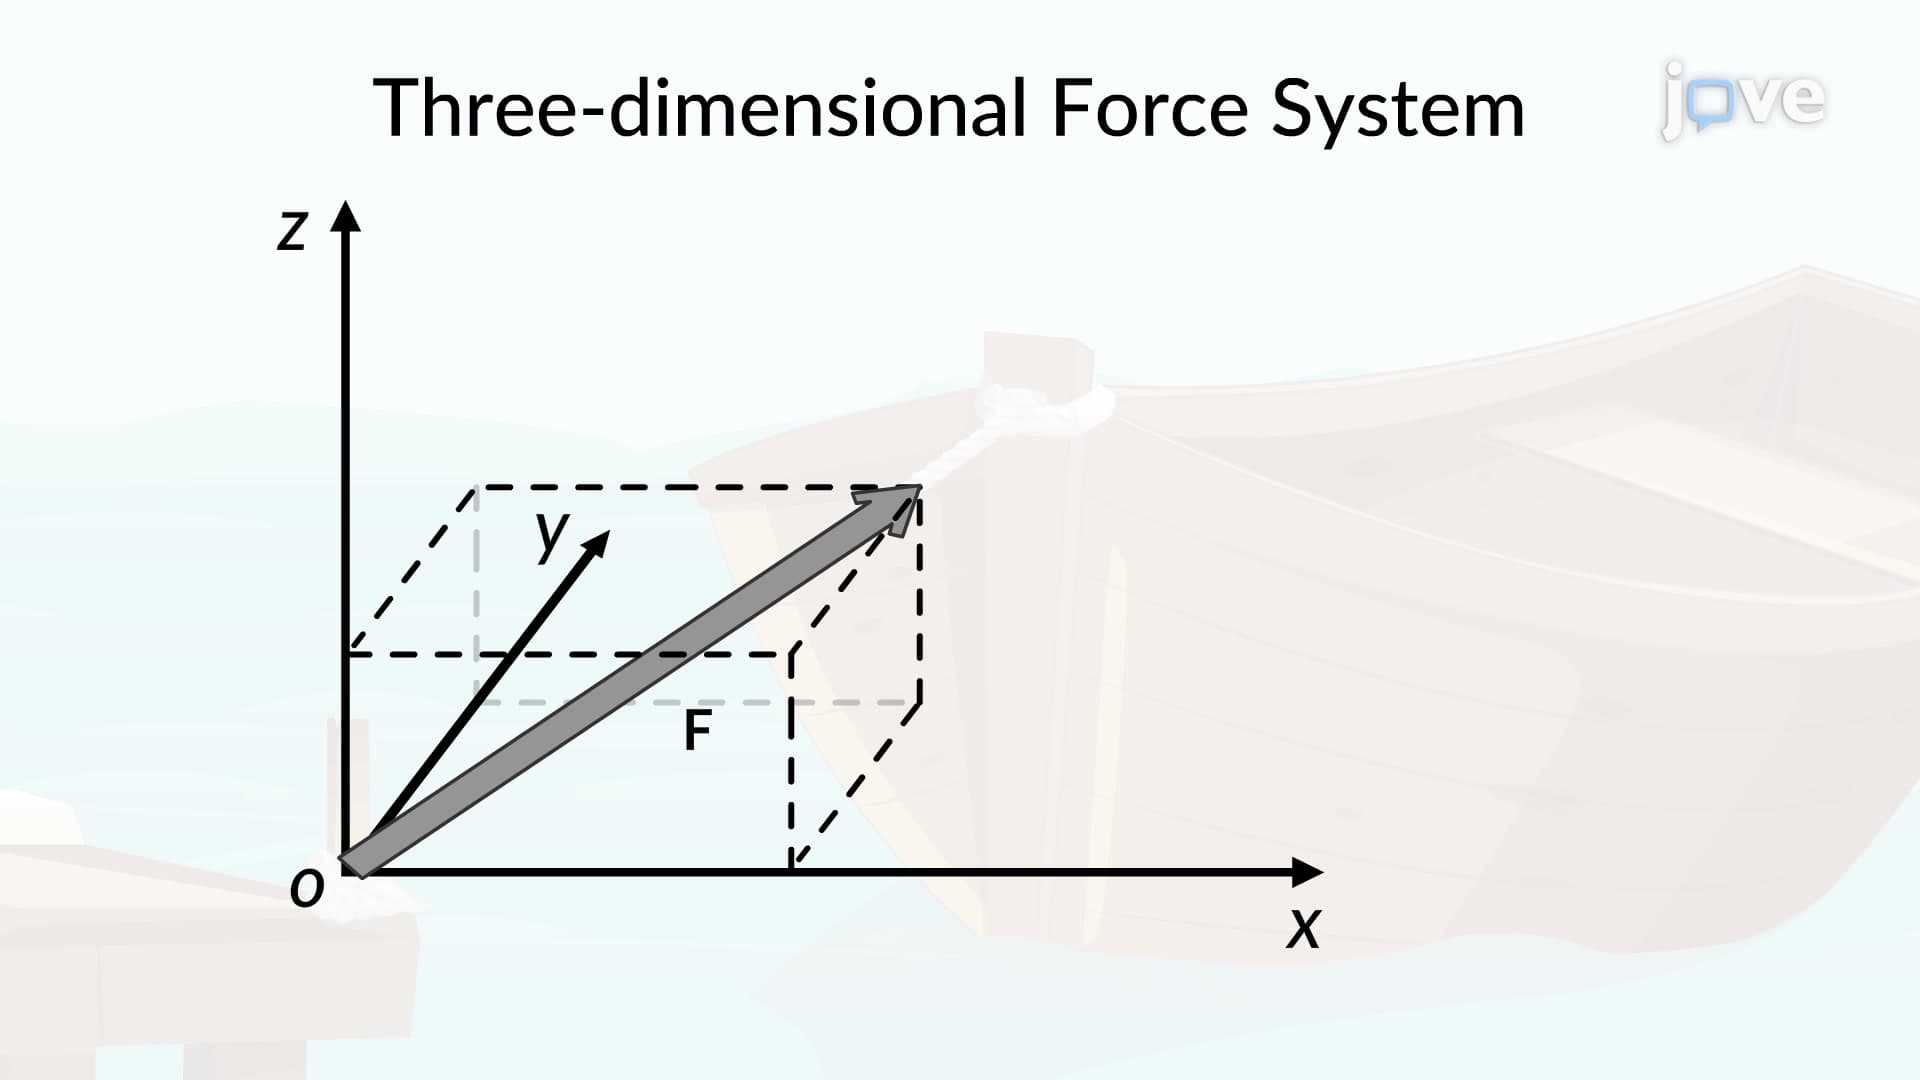
Three-Dimensional Force System
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...