Related Experiment Video
Updated: Oct 3, 2026

Age-dependent Dynamics of Locomotion in Caenorhabditis elegans: A Lyapunov Exponent Analysis
Published on: September 23, 2025
Global geometric indicator of chaos and Lyapunov exponents in Hamiltonian systems
K Ramasubramanian1, M S Sriram
1Department of Theoretical Physics, University of Madras, Guindy Campus, Chennai 600 025, India.

Abstract:
Recently a geometric description of chaos in Hamiltonian systems has been formulated using the tools of Riemannian geometry. Here, Hamiltonian chaos is explained in terms of the curvature properties of the configuration space manifold. In particular, it has been claimed that the average of an appropriately defined sectional curvature (K((2))) over a constant energy manifold is a measure of the global extent of chaoticity for systems with a small number of degrees of freedom. We investigate the relations between this quantity K((2)) and the maximal Lyapunov exponent lambda for some Hamiltonian systems of physical interest with two degrees of freedom. We find that there is a close relation between K((2)) and lambda(2). Both the quantities scale as E(1/2) for quartic potentials, where E is the energy. They are expected to scale as E((n-2)/n) for a general potential of degree n. However, we find that though K((2)) is a global indicator of chaos, it is not a sufficiently accurate measure of order-chaos transitions, in all cases.
Related Concept Videos
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's response.
 01:19
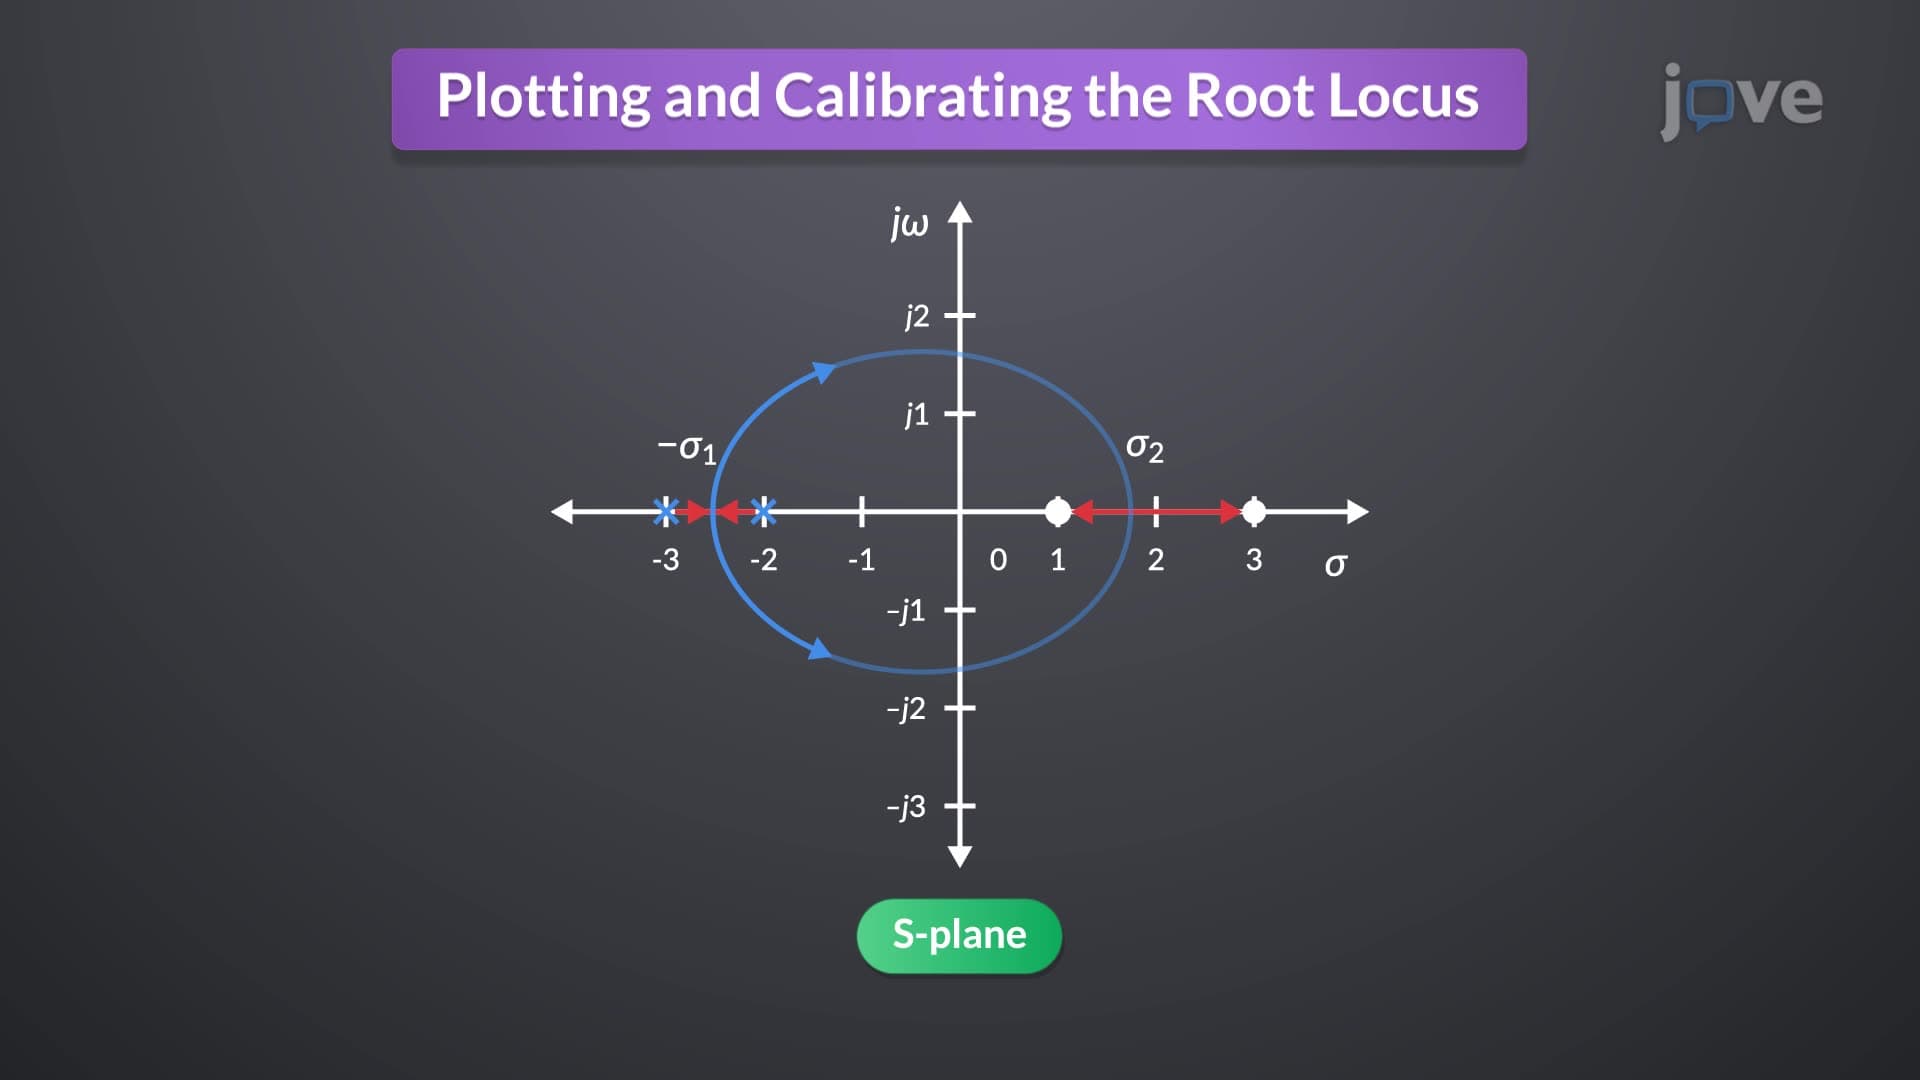
Plotting and Calibrating the Root Locus
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is observed...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
 01:23
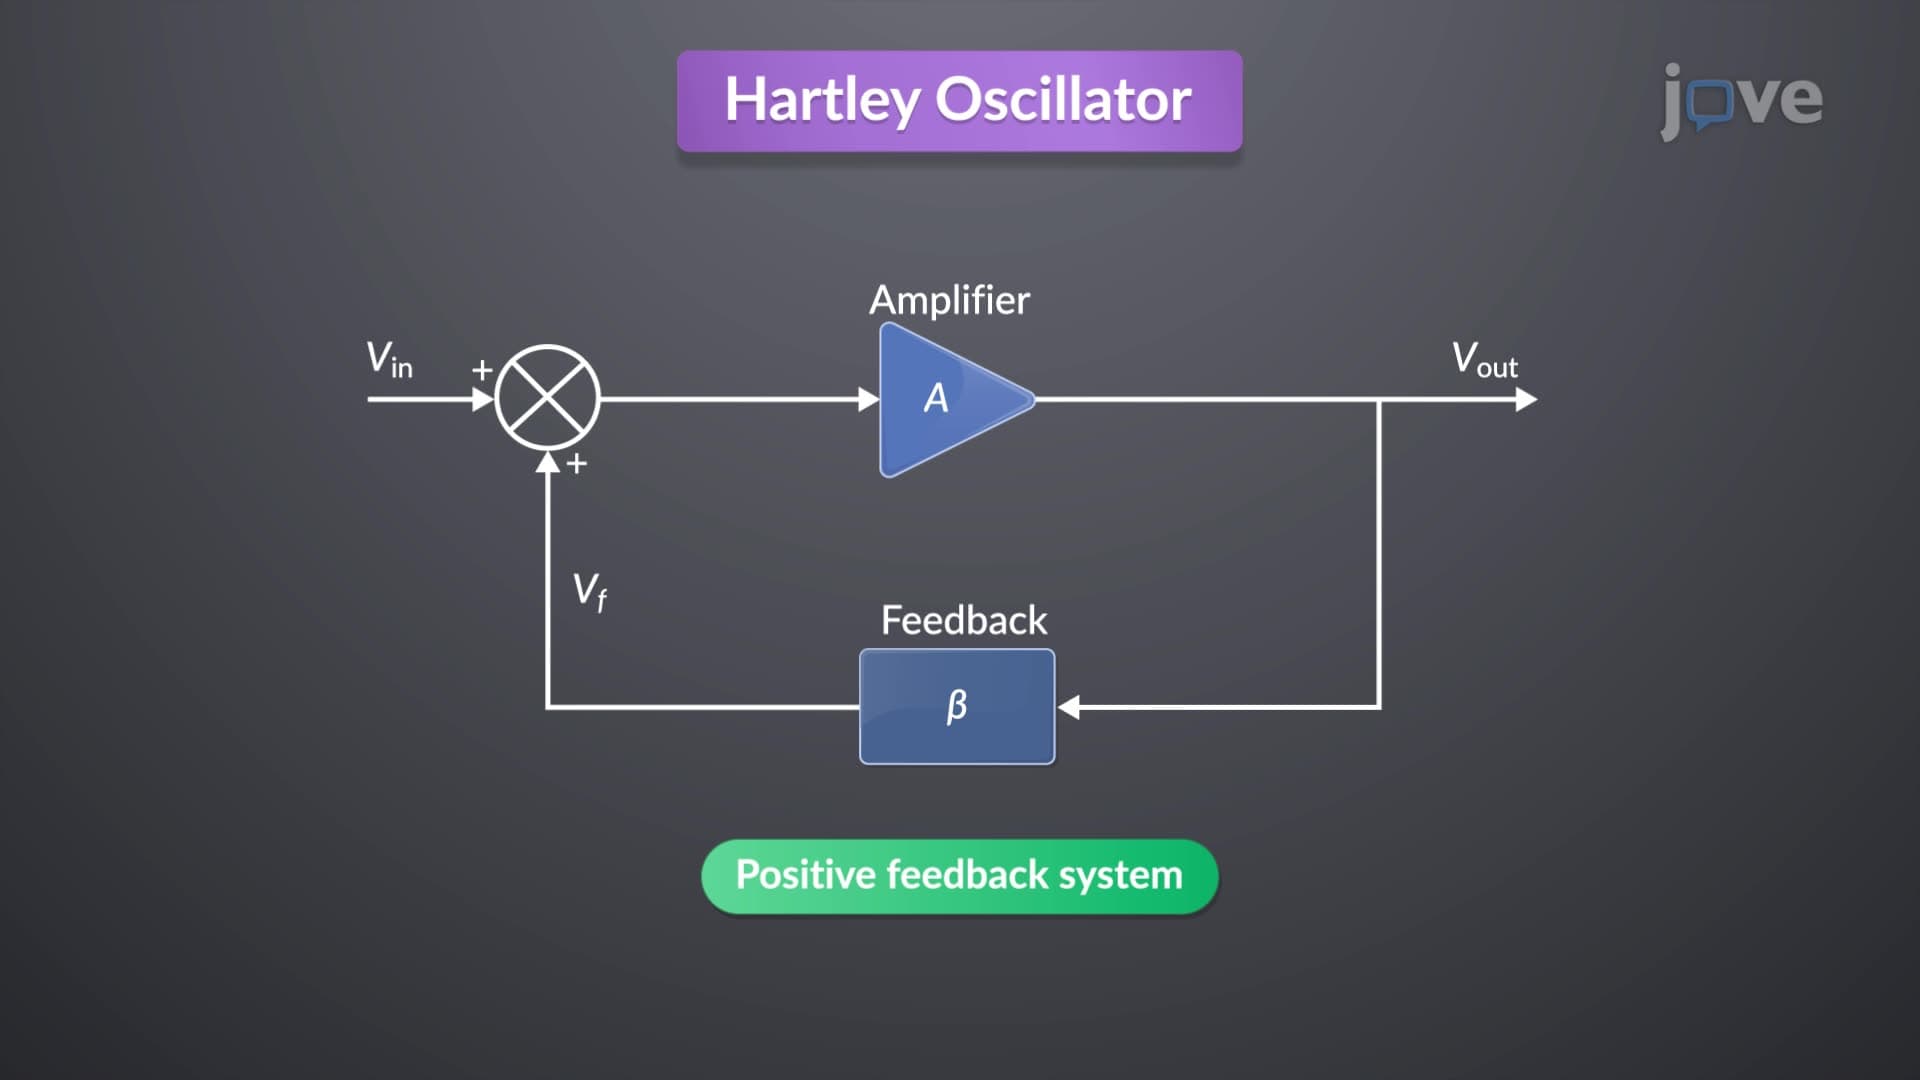
Root Loci for Positive-Feedback Systems
The construction rules for the root locus in positive feedback systems are similar to those in...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:10
Entropy Change in Reversible Processes
The statement can be further generalized to prove that entropy is a state function. Take a cyclic process between any two points on a p-V diagram.