Related Experiment Video
Updated: Jul 27, 2026

Measuring Attention and Visual Processing Speed by Model-based Analysis of Temporal-order Judgments
Published on: January 23, 2017
A model of the formation of illusory conjunctions in the time domain
J Botella1, M Suero, M I Barriopedro
1Facultad de Psicología, Universidad Autónoma de Madrid, Spain. juan.botella@uam.es

Abstract:
The authors present a model to account for the miscombination of features when stimuli are presented using the rapid serial visual presentation (RSVP) technique (illusory conjunctions in the time domain). It explains the distributions of responses through a mixture of trial outcomes. In some trials, attention is successfully focused on the target, whereas in others, the responses are based on partial information. Two experiments are presented that manipulated the mean processing time of the target-defining dimension and of the to-be-reported dimension, respectively. As predicted, the average origin of the responses is delayed when lengthening the target-defining dimension, whereas it is earlier when lengthening the to-be-reported dimension; in the first case the number of correct responses is dramatically reduced, whereas in the second it does not change. The results, a review of other research, and simulations carried out with a formal version of the model are all in close accordance with the predictions.
Related Concept Videos
 01:20
Graphical and Analytic Representation of Sinusoids
The first step is measuring the peak-to-peak value, which is twice the amplitude of the sinusoid. This provides information about the maximum voltage swing of the waveform.
Secondly, the period and angular frequency are determined. The period is the time taken for one complete cycle of the waveform, while...
 01:24
Convolution: Math, Graphics, and Discrete Signals
To simplify the convolution integral, it is assumed that both the input signal and impulse response are zero for negative time values. The graphical convolution process...
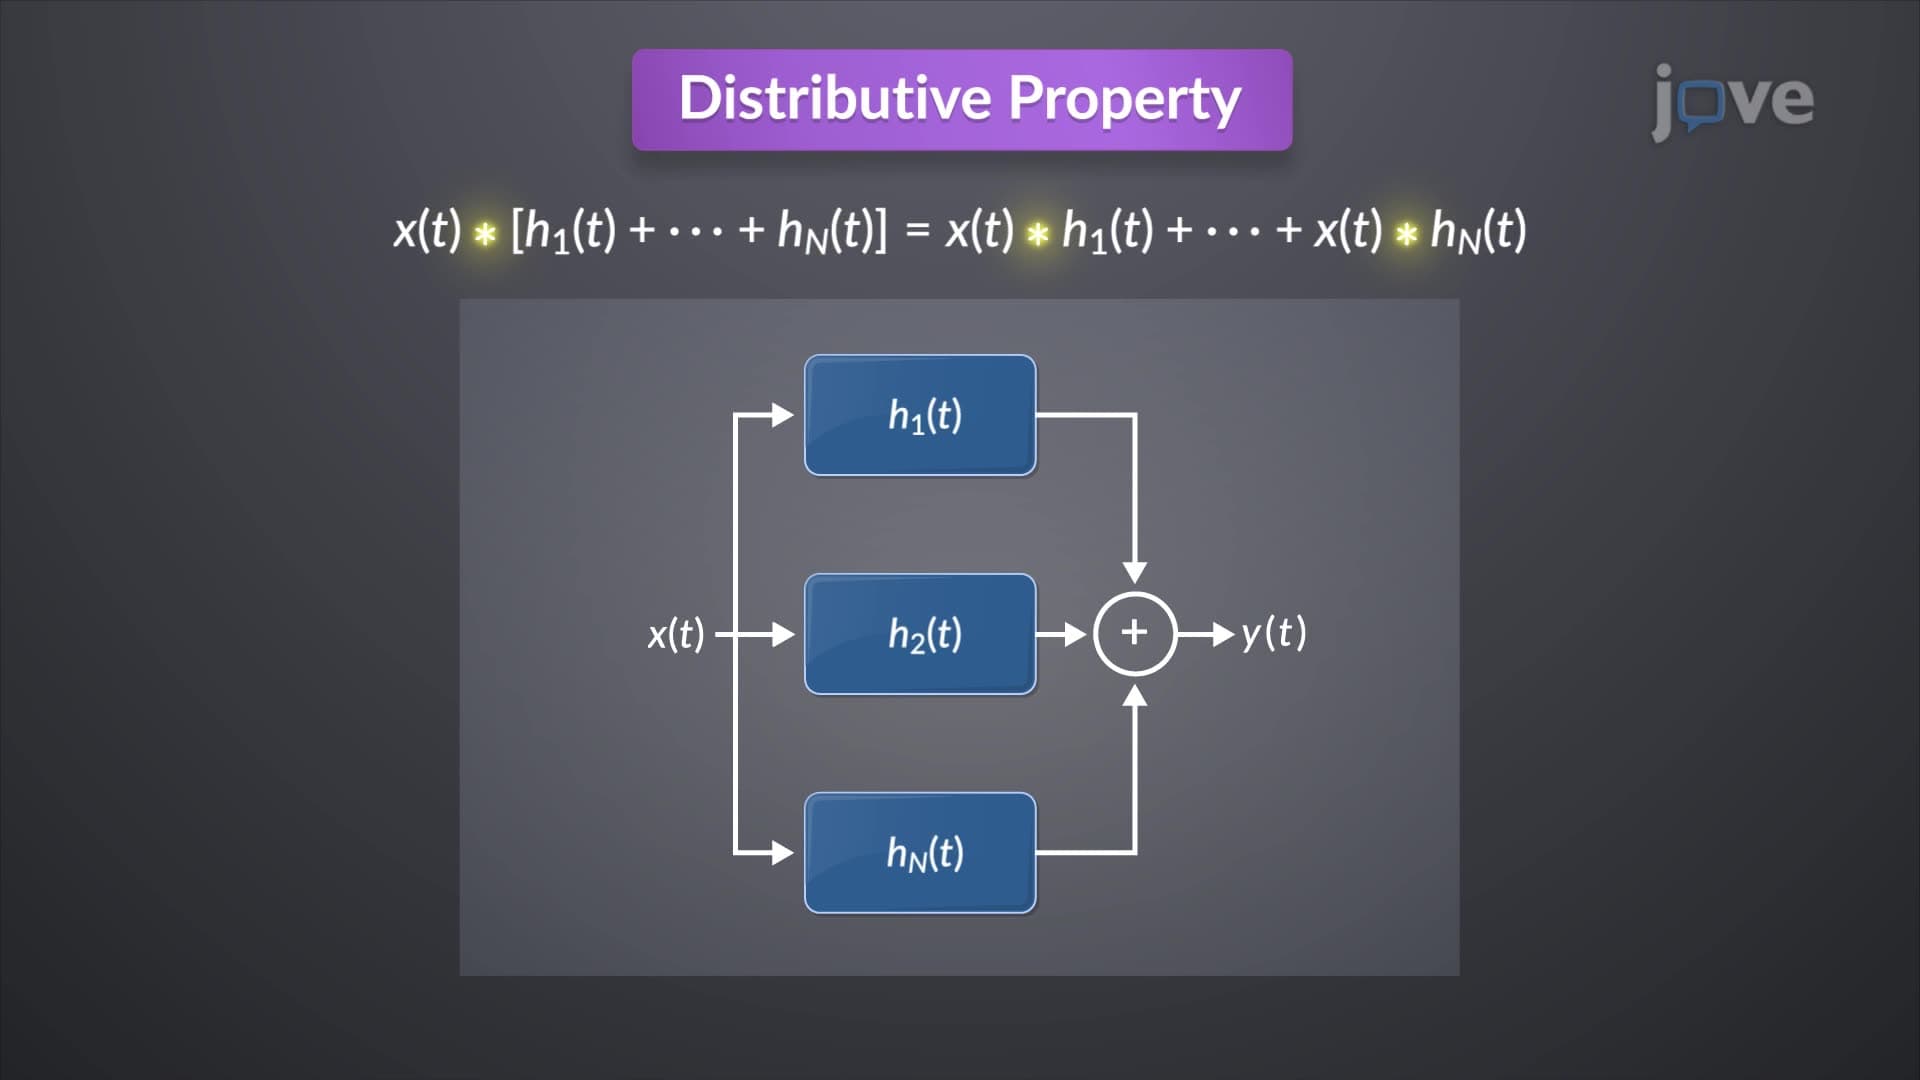 01:20
Convolution Properties I
The commutative property reveals that the input and the impulse response of an LTI (Linear Time-Invariant) system can be interchanged without affecting the output:
 01:20
Region of Convergence of Laplace Tarnsform
Consider a decaying exponential signal that begins at a specific time. When deriving its Laplace transform, the time-domain variable is replaced with a complex variable. This substitution...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any finite,...