Related Experiment Video
Updated: Sep 20, 2026
The Crossmodal Congruency Task as a Means to Obtain an Objective Behavioral Measure in the Rubber Hand Illusion Paradigm
Published on: July 26, 2013
Modeling rhythmic interlimb coordination: beyond the Haken-Kelso-Bunz model
P J Beek1, C E Peper, A Daffertshofer
1Faculty of Human Movement Sciences, Vrije Universiteit Amsterdam, Van der Boechorststraat 9, Amsterdam, 1081 BT, The Netherlands. p_j_beek@fbw.vu.nl

Abstract:
Although the Haken-Kelso-Bunz (HKB) model was originally formulated to account for phase transitions in bimanual movements, it evolved, through experimentation and conceptual elaboration, into a fundamental formal construct for the experimental study of rhythmically coordinated movements in general. The model consists of two levels of formalization: a potential defining the stability properties of relative phase and a system of coupled limit cycle oscillators defining the individual limb movements and their interactions. Whereas the empirical validity of the potential is well established, the validity of the formalization in terms of coupled oscillators is questionable, both with regard to the assumption that individual limb movements are limit cycle oscillators with (only) two active degrees of freedom and with regard to the postulated coupling. To remedy these limitations a more elaborate system of coupled oscillators is outlined, comprising two coupled limit cycle oscillators at the neural level, each of which is coupled to a linearly damped oscillator, representing the end-effectors.

Related Concept Videos
 01:15
Kinematic Equations: Problem Solving
 00:49
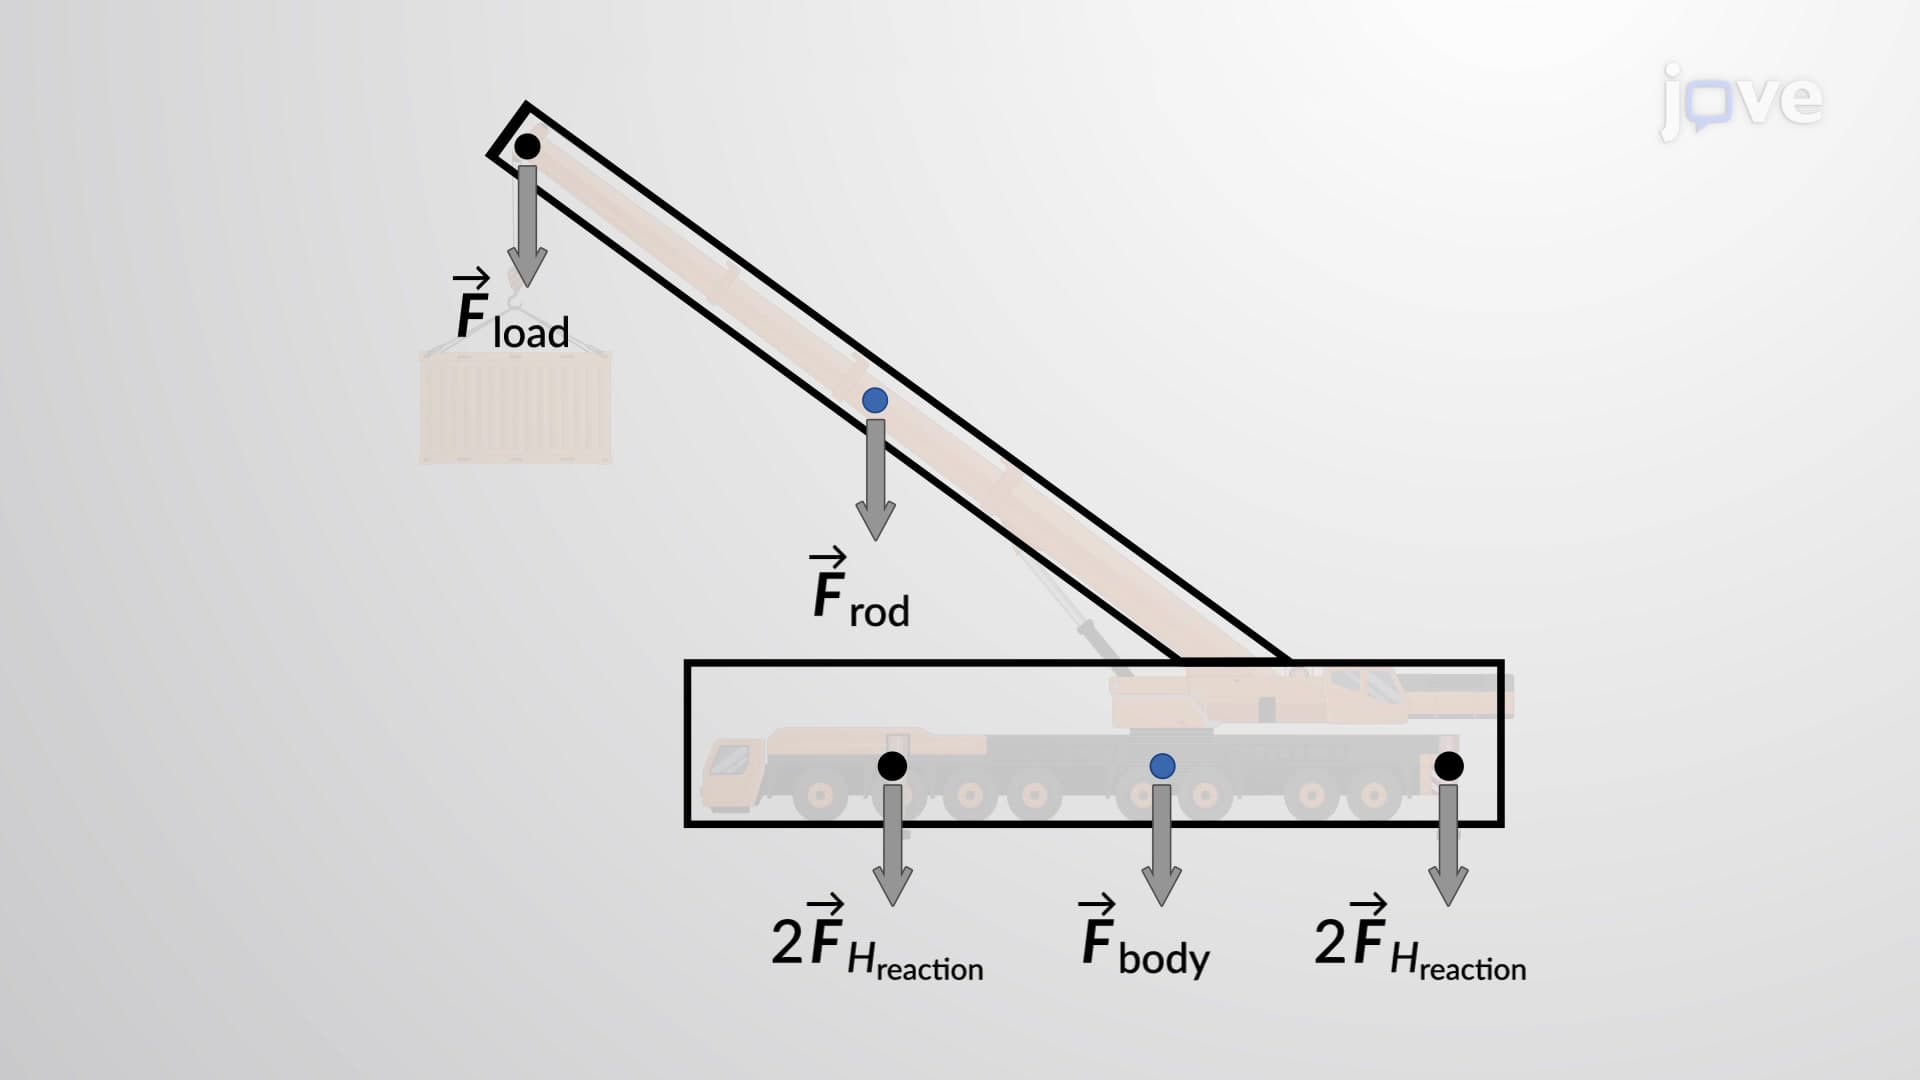
Rigid Body Equilibrium Problems - I
 01:21
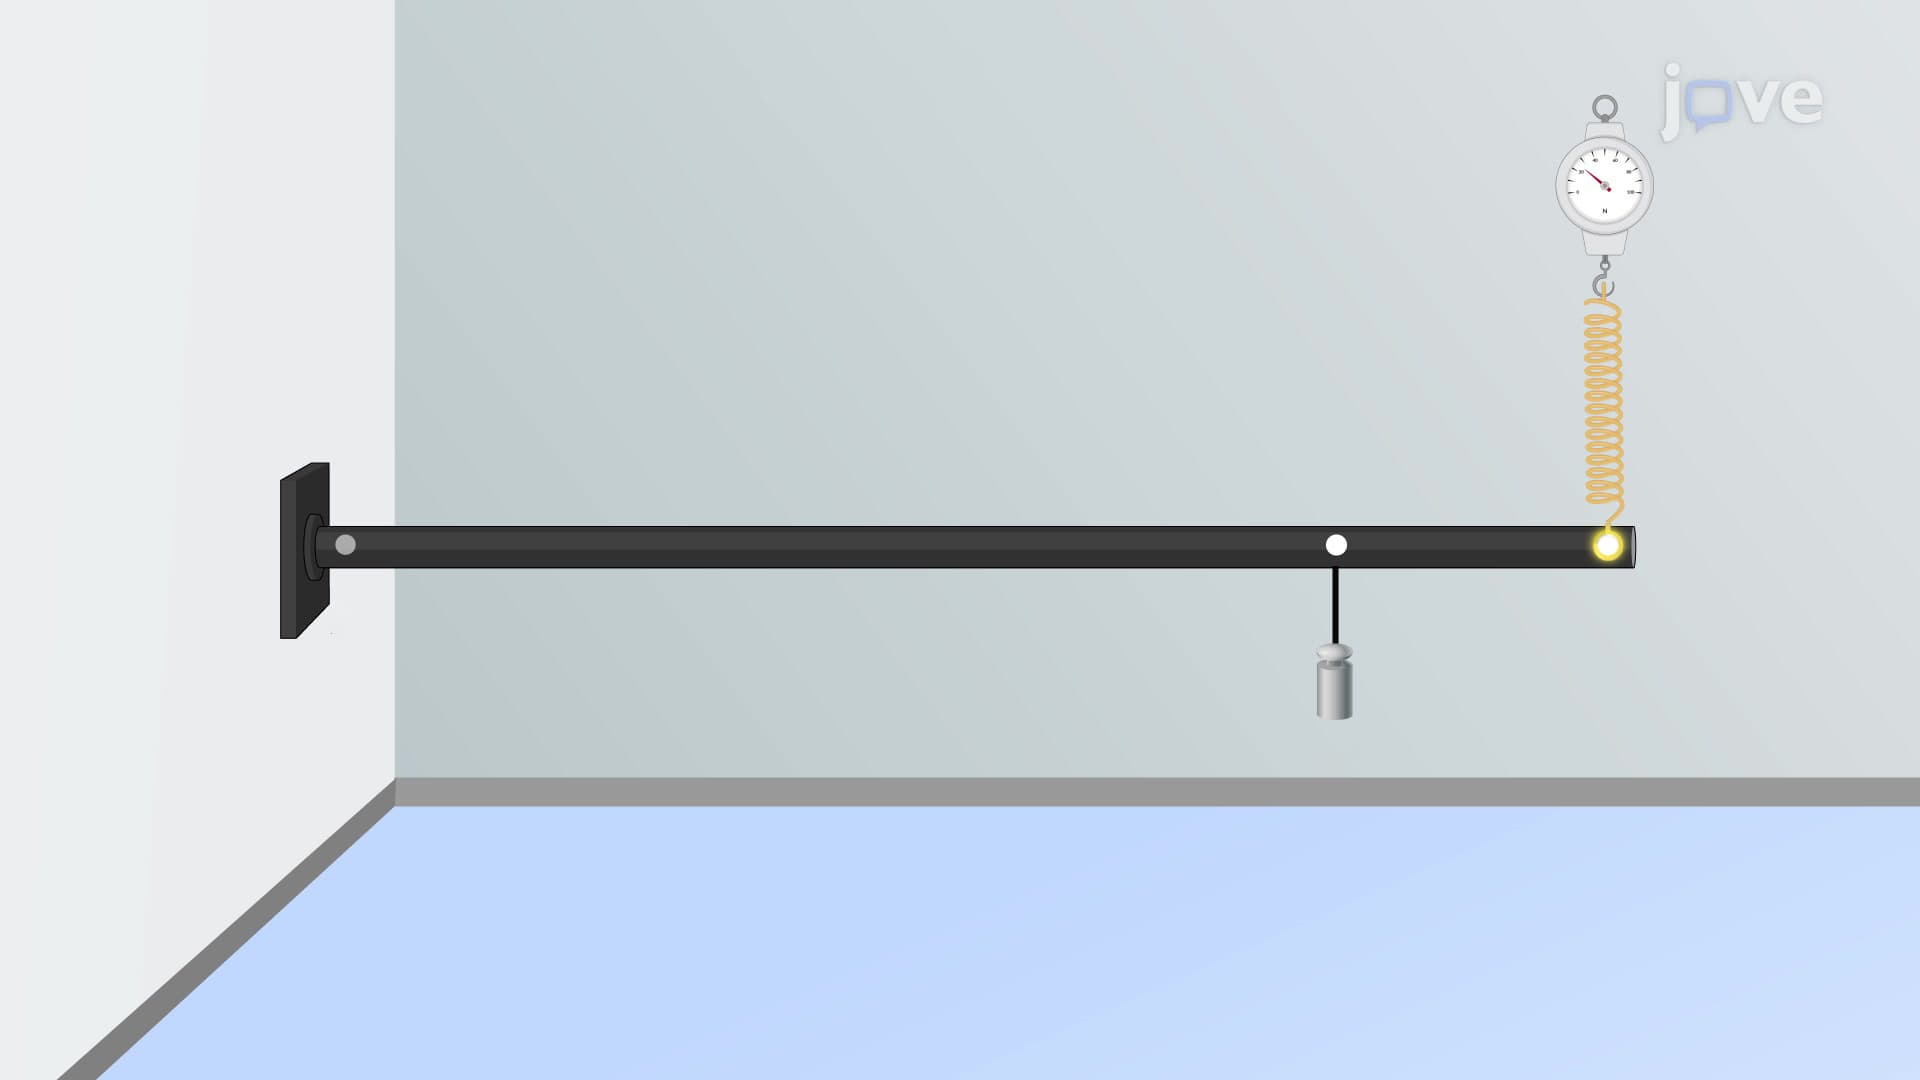
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:07
Development of the Limb Synovial Joints
The mesenchymal stem cells differentiate into chondrocytes that form the hyaline cartilage, and later the cartilaginous model of the bone. This model further transforms into a bone. This process is known as endochondral ossification.
During development, the limbs...
 01:24
Muscle Coordination and Action
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement.
 01:12
Modeling and Similitude