Manual and virtual rotation of a three-dimensional object
Related Experiment Video
Updated: Oct 2, 2026

Three-Dimensional Mapping of the Rotation of Interactive Virtual Objects with Eye-Tracking Data
Published on: October 18, 2024
1School of Psychology, Cardiff University. royr@comp.leeds.ac.uk

Abstract:
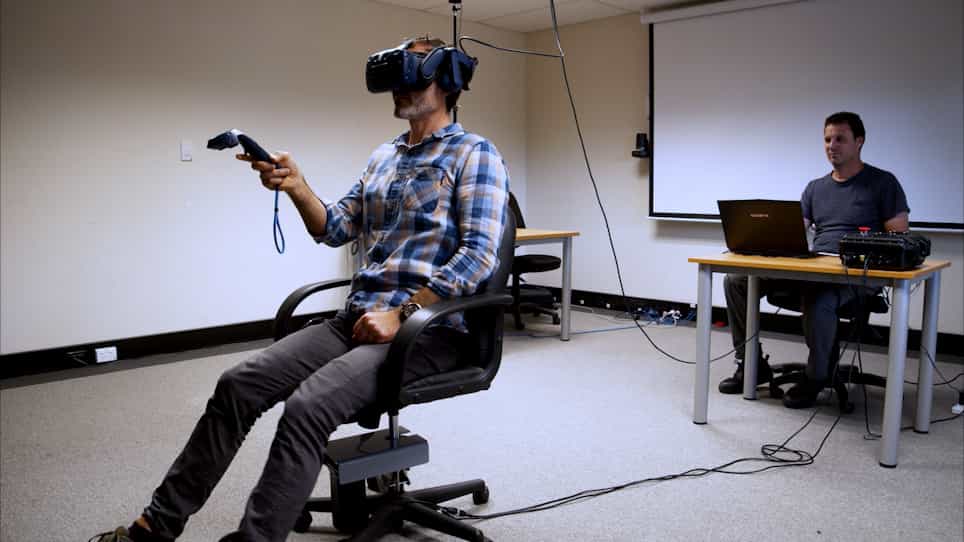
An orientation-matching task, based on a mental rotation paradigm, was used to investigate how participants manually rotated a Shepard-Metzler object in the real world and in an immersive virtual environment (VE). Participants performed manual rotation more quickly and efficiently than virtual rotation, but the general pattern of results was similar for both. The rate of rotation increased with the starting angle between the stimuli meaning that, in common with many motor tasks, an amplitude-based relationship such as P. M. Fitts' (1954) law is applicable. When rotation was inefficient (i.e., not by the shortest path), it was often because participants incorrectly perceived the orientation of one of the objects, and this happened more in the VE than in the real world. Thus, VEs allow objects to be manipulated naturally to a limited extent, indicating the need for timing-scale factors to be used for applications such as method-time-motion studies of manufacturing operations.
Related Concept Videos
 01:26
Rotational Motion about a Fixed Axis
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:11
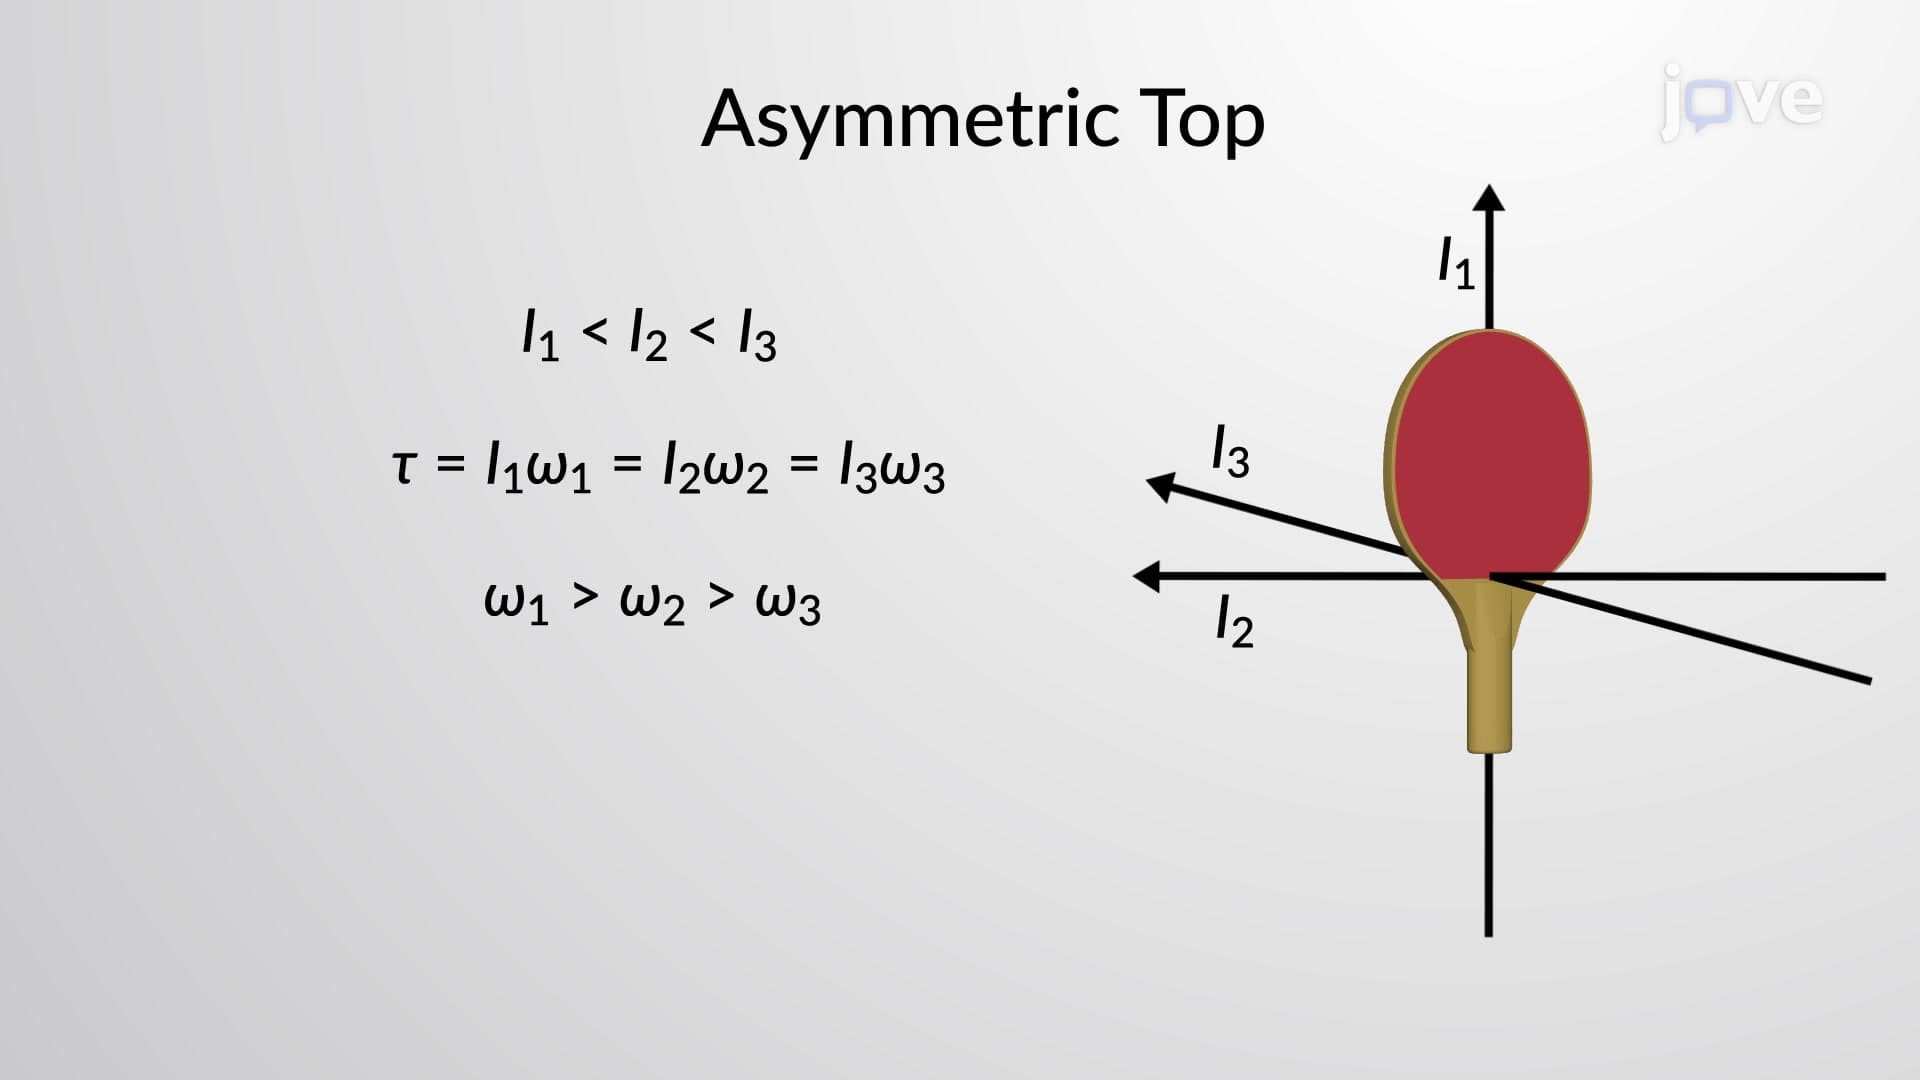
Rotation of Asymmetric Top
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
 01:16
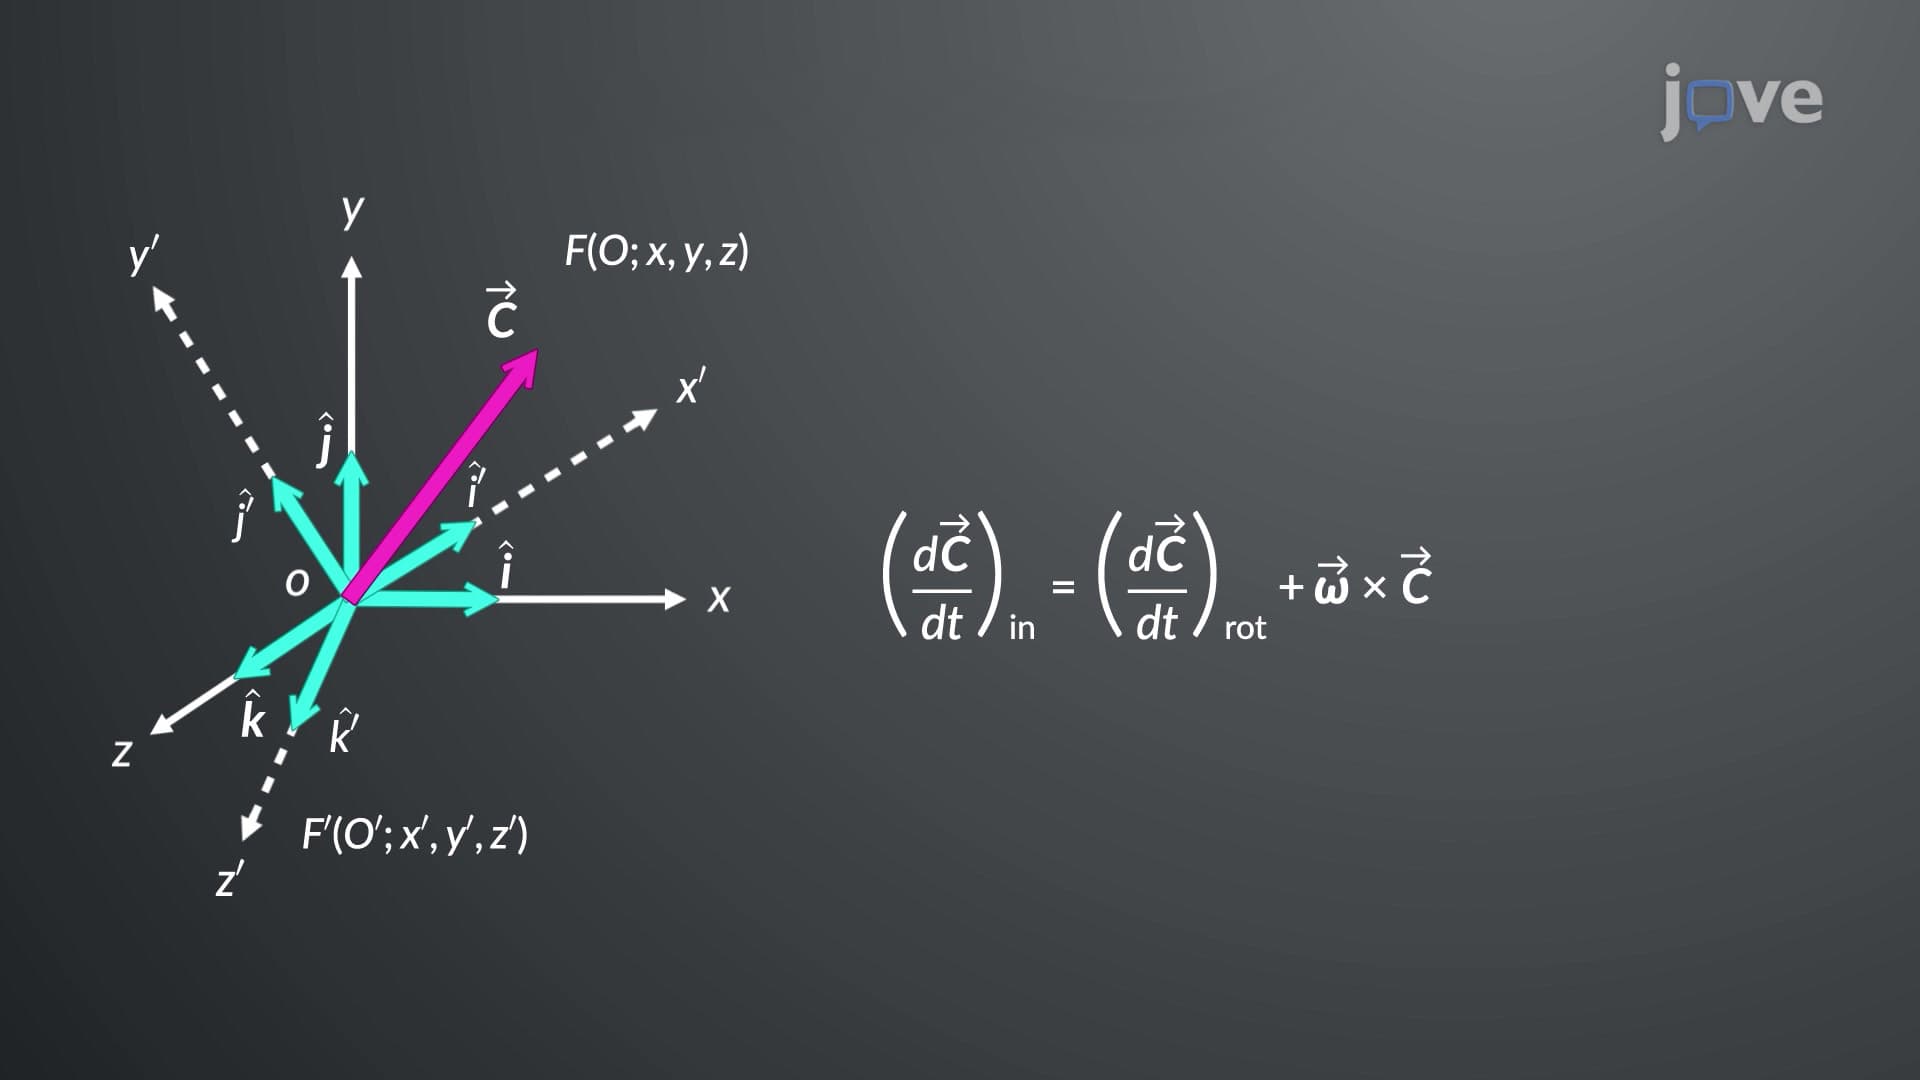
Vector Transformation in Rotating Coordinate Systems
 01:28
Cylinders in Three-Dimensional Space