Related Experiment Video
Updated: Aug 8, 2026
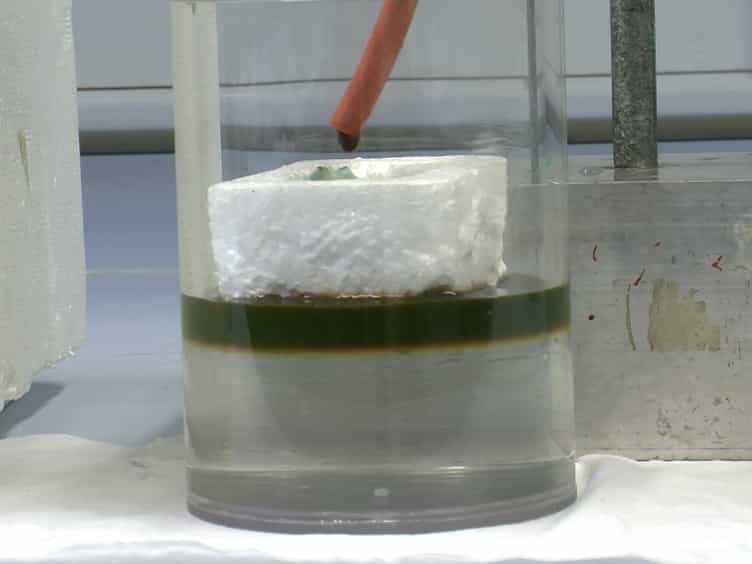

Magnetically Induced Rotating Rayleigh-Taylor Instability
Published on: March 3, 2017
Simple approach to the creation of a strange nonchaotic attractor in any chaotic system
1Department of Biomedical Engineering, Case Western Reserve University, Cleveland, Ohio 44106, USA. jxs131@po.cwru.edu

Abstract:
A simple approach to the creation of a strange nonchaotic attractor in any chaotic system is described. The main idea is to control the parameter of the system in such a manner that the system dynamics is expanding at some times, but converging at others. With this approach, a strange nonchaotic attractor can be found in a large region in the parameter space near the boundaries between chaotic and regular phases or within the chaotic region far from the regular one. The maximum nontrivial Lyapunov exponent of the system can pass through zero nonsmoothly and cannot be fitted by a linear function.
Related Concept Videos
 01:14
The Second Law of Thermodynamics
 01:04
Oscillations about an Equilibrium Position
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:21
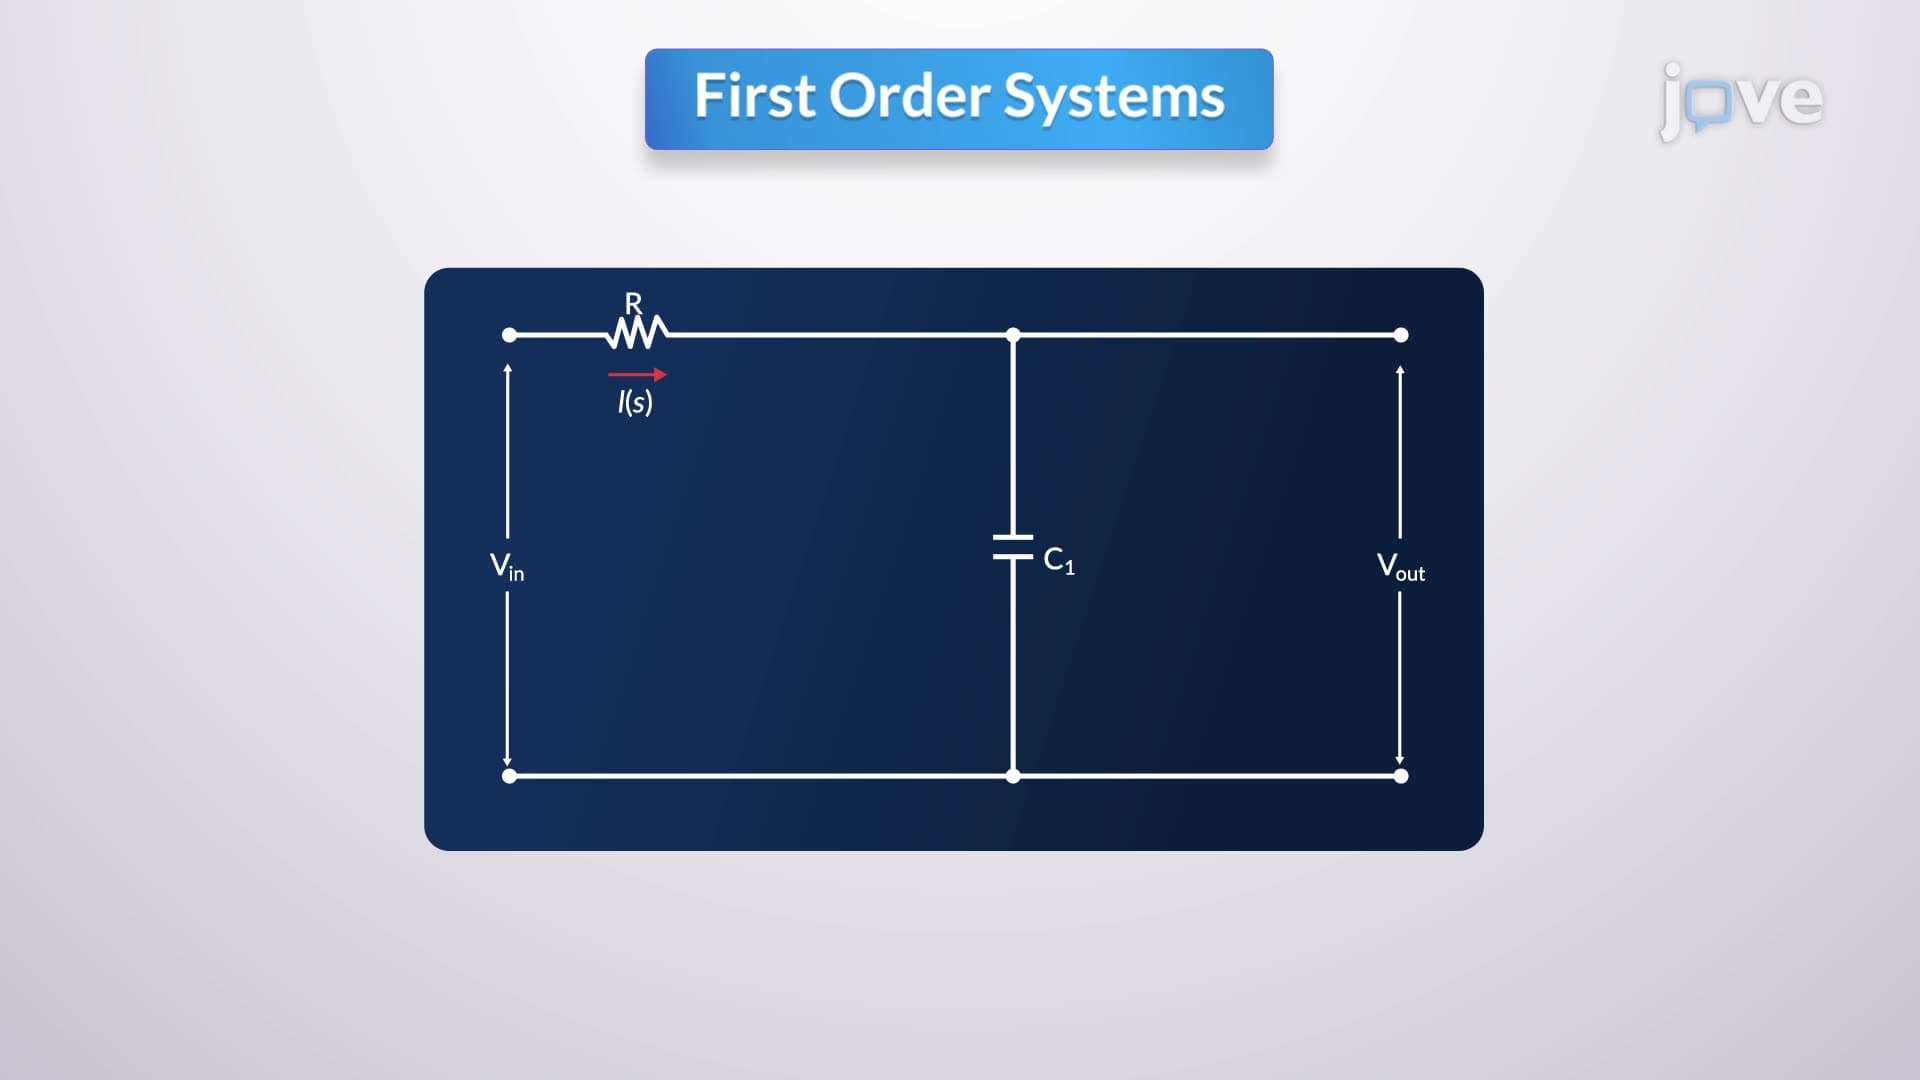
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:28
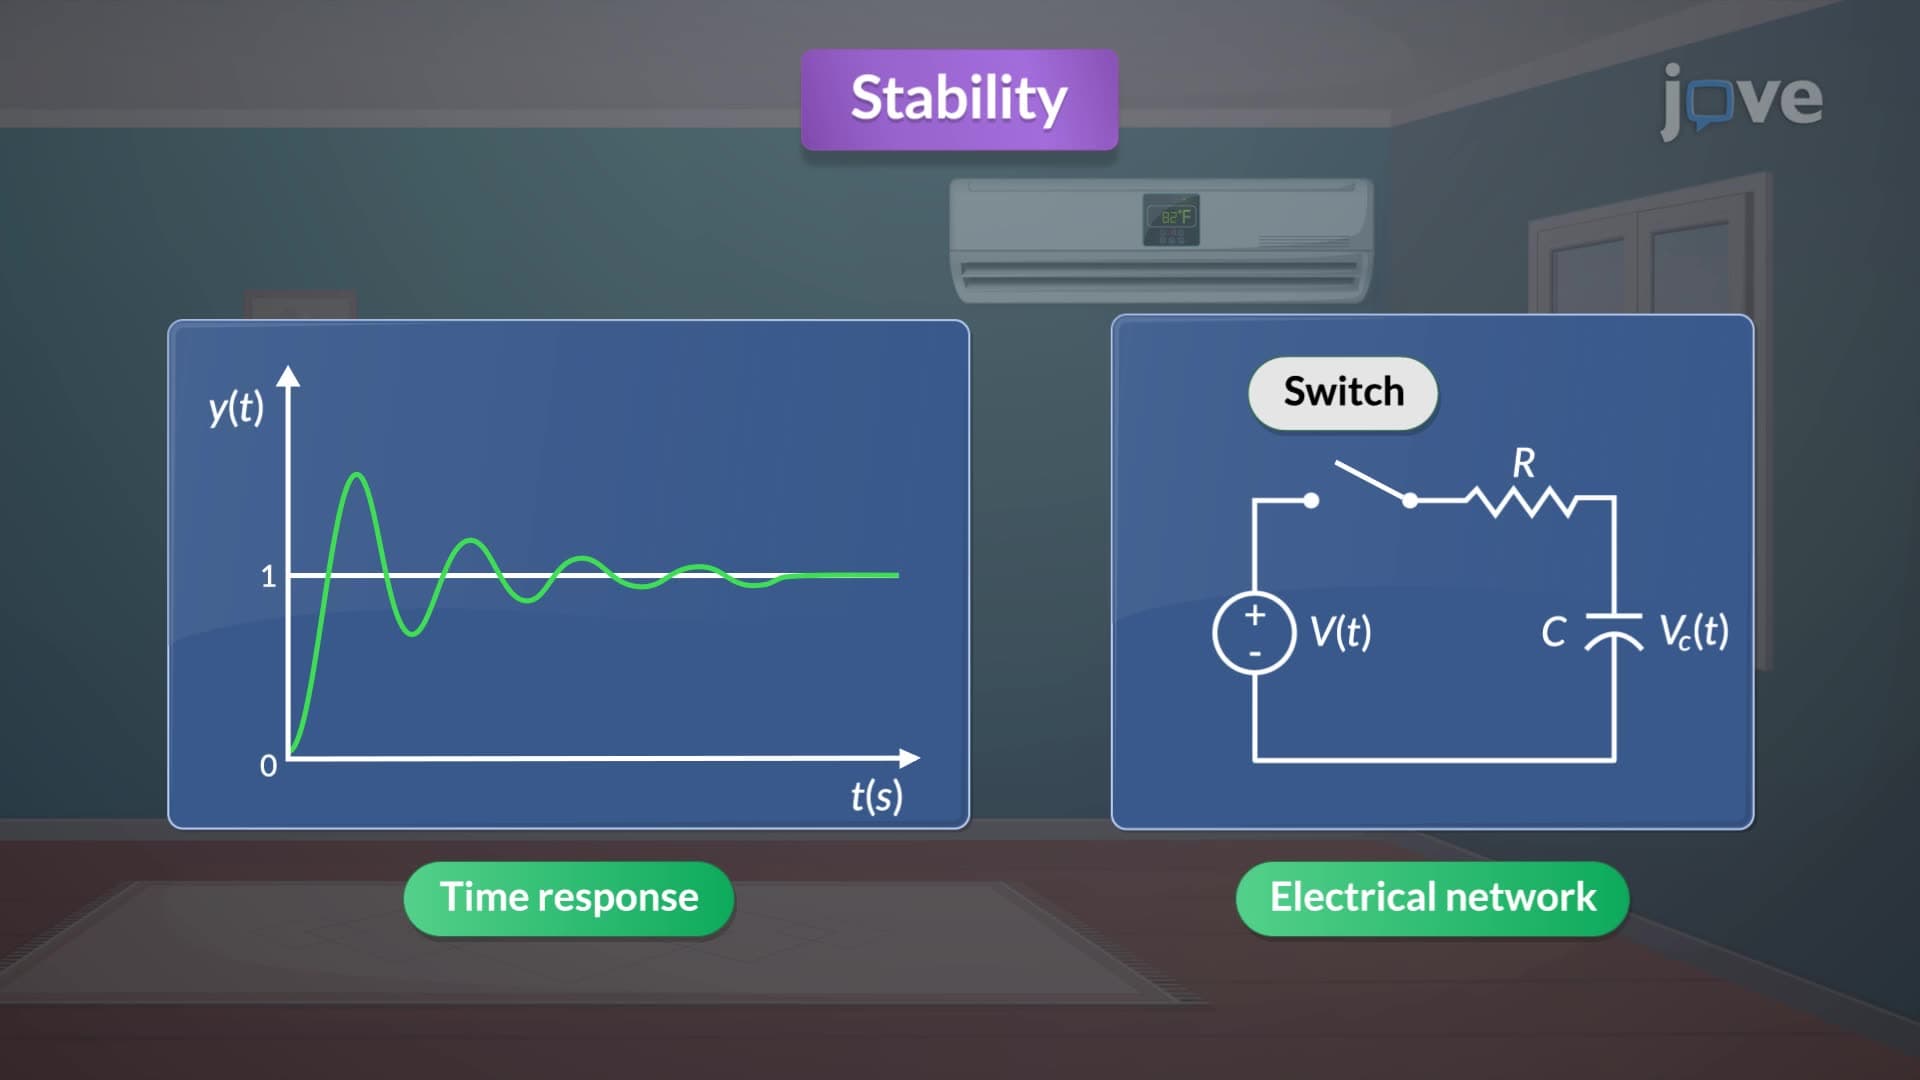
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...