Related Experiment Video
Updated: Aug 12, 2026

Video-rate Scanning Confocal Microscopy and Microendoscopy
Published on: October 20, 2011
Convergence rates for iterative vector space projection methods for control of two deformable mirrors for
1Starfire Optical Range, U.S. Air Force Research Laboratory, Kirtland Air Force Base, New Mexico 87117, USA.

Abstract:
The control of two deformable mirrors for compensation of time-varying fluctuations in the complex field that results from wave propagation through a turbulent medium is considered. Iterative vector space projection methods are utilized to determine the control commands to be applied to the two deformable mirrors. Convergence of the iterative algorithm is accelerated when the algorithm is initialized, at each measurement period, with the values for the phase commands obtained from the previous measurement period. Furthermore, it is found that, if the sample frequency is sufficiently greater than the Greenwood frequency, then only a single iterative step at each measurement period is required to obtain good compensation of both amplitude and phase fluctuations.

Related Concept Videos
 01:16
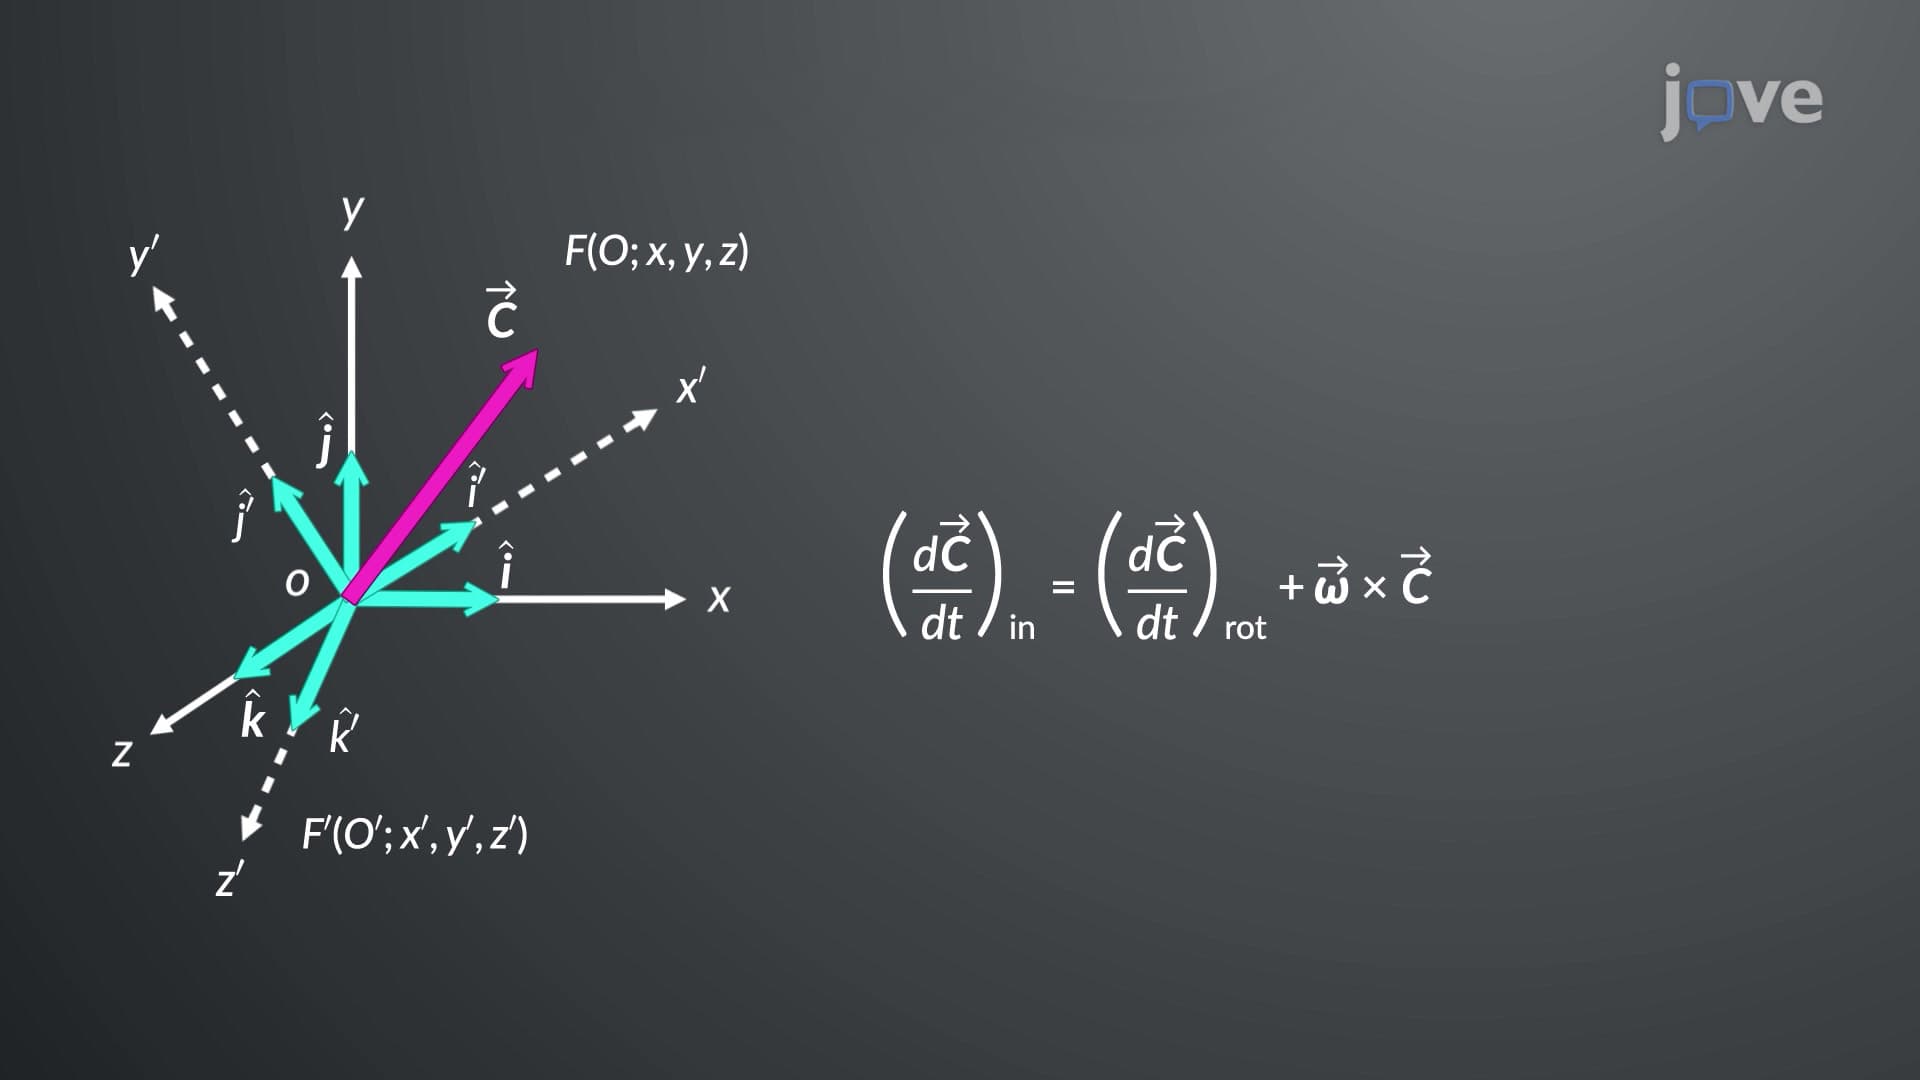
Vector Transformation in Rotating Coordinate Systems
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:29
Real-World Applications of Space Curves
 01:30
Vector Functions and Motion: Problem Solving