Related Experiment Videos
Representation and extrapolation in multilayer perceptrons
1School of Computing, Information Systems and Mathematics, London Guildhall University, London UK. abrowne@lgu.ac.uk
Neural Computation
|June 25, 2002

Abstract:
To give an adequate explanation of cognition and perform certain practical tasks, connectionist systems must be able to extrapolate. This work explores the relationship between input representation and extrapolation, using simulations of multilayer perceptrons trained to model the identity function. It has been discovered that representation has a marked effect on extrapolation.
Related Concept Videos
 01:25
Multiple Regression
Multiple regression assesses a linear relationship between one response or dependent variable and two or more independent variables. It has many practical applications.
Farmers can use multiple regression to determine the crop yield based on more than one factor, such as water availability, fertilizer, soil properties, etc. Here, the crop yield is the response or dependent variable as it depends on the other independent variables. The analysis requires the construction of a scatter plot...
Farmers can use multiple regression to determine the crop yield based on more than one factor, such as water availability, fertilizer, soil properties, etc. Here, the crop yield is the response or dependent variable as it depends on the other independent variables. The analysis requires the construction of a scatter plot...
 01:17
Convolution Properties II
The important convolution properties include width, area, differentiation, and integration properties.
The width property indicates that if the durations of input signals are T1 and T2, then the width of the output response equals the sum of both durations, irrespective of the shapes of the two functions. For instance, convolving two rectangular pulses with durations of 2 seconds and 1 second results in a function with a width of 3 seconds.
The area property asserts that the area under the...
 01:10
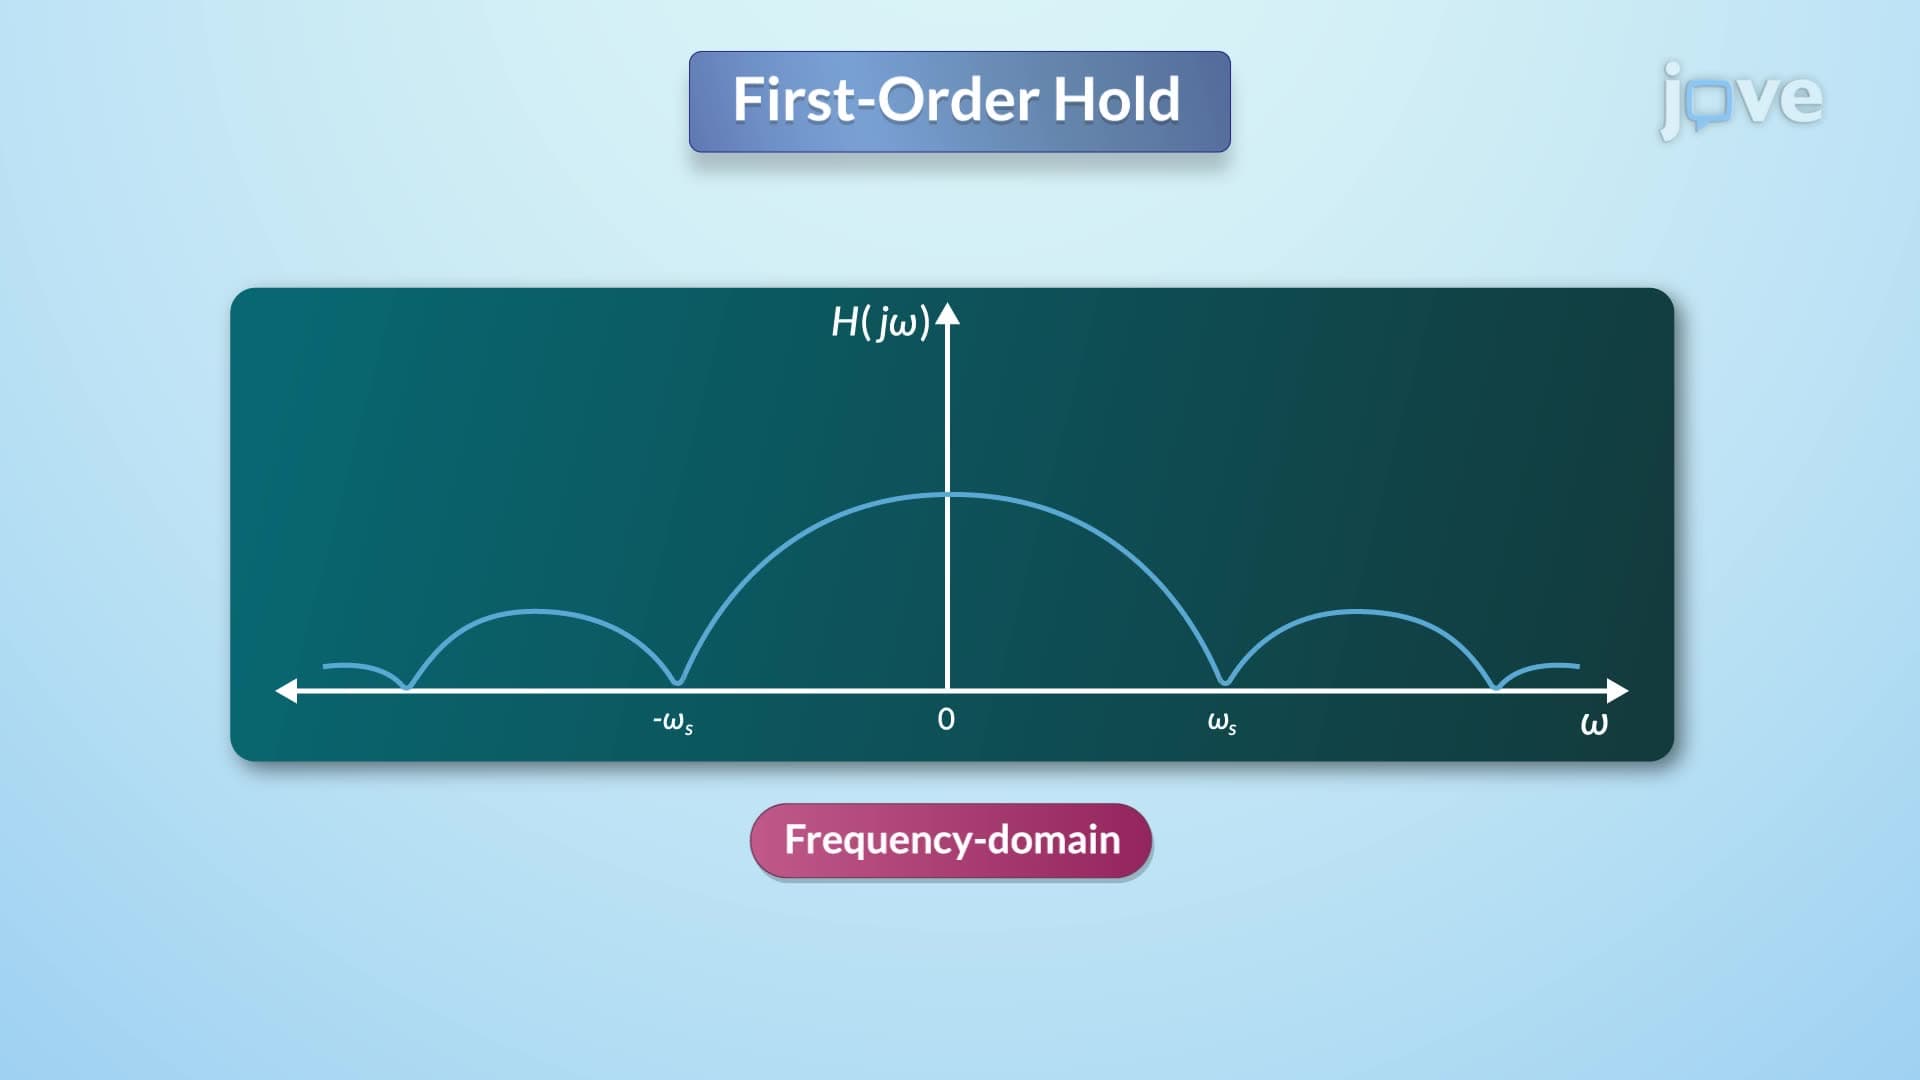
Reconstruction of Signal using Interpolation
Signal processing techniques are essential for accurately converting continuous signals to digital formats and vice versa. When a continuous signal is sampled with a period T, the resulting sampled signal exhibits replicas of the original spectrum in the frequency domain, spaced at intervals equal to the sampling frequency. To handle this sampled signal, a zero-order hold method can be applied, which creates a piecewise constant signal by retaining each sample's value until the next sampling...
 01:26
Linear Approximation in Frequency Domain
Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:22
Multi-input and Multi-variable systems
Cruise control systems in cars are designed as multi-input systems to maintain a driver's desired speed while compensating for external disturbances such as changes in terrain. The block diagram for a cruise control system typically includes two main inputs: the desired speed set by the driver and any external disturbances, such as the incline of the road. By adjusting the engine throttle, the system maintains the vehicle's speed as close to the desired value as possible.
In the absence of...
In the absence of...
 01:23
Linear Approximations
For a differentiable function of two variables, linear approximation estimates values near a known point by replacing the curved surface with its tangent plane. Consider the function\begin{equation*}f(x,y)=x^2+3y^2\end{equation*}near the point (2, 1). The exact value at this point is f(2, 1) = 22 + 3(1)2 = 4 + 3 = 7.The linear approximation of f(x, y)) near (a, b) is\begin{equation*}L(x,y)=f(a,b)+f_x(a,b)(x-a)+f_y(a,b)(y-b)\end{equation*}First, compute the partial derivatives: fx(x, y) = 2x and...