Related Experiment Video
Updated: Jul 31, 2026

A Human-machine-interface Integrating Low-cost Sensors with a Neuromuscular Electrical Stimulation System for Post-stroke Balance Rehabilitation
Published on: April 12, 2016
A mathematical model of the stability control of human thorax and pelvis movements during walking
1Department of Mechanical and Industrial Engineering, The University of Manitoba, Winnipeg, Canada.

Abstract:
A mathematical model is developed to study the human thorax and pelvis movements in the frontal plane during normal walking. The model comprises of two-link base-excited inverted pendulums with one-degree of rotational freedom for each link. Since the linear motion of the pelvis has a significant effect on the upper body stability, this effect is included in the model by having a base point moving in the frontal plane in a general way. Furthermore, because the postural stability is the primary requirement of normal human walking, the control law is developed based on Lyapunov's stability theory, which guarantees the stability of the pendulum system around the up-right position. To evaluate the model, the simulation results, including the angular displacement of each link and the torque applied on each link, are compared with those from gait measurements. It is shown that the simulation results match those from gait measurements closely. These results suggest that the proposed model can provide a useful framework for analysis of postural control mechanisms.

Related Concept Videos
 00:49
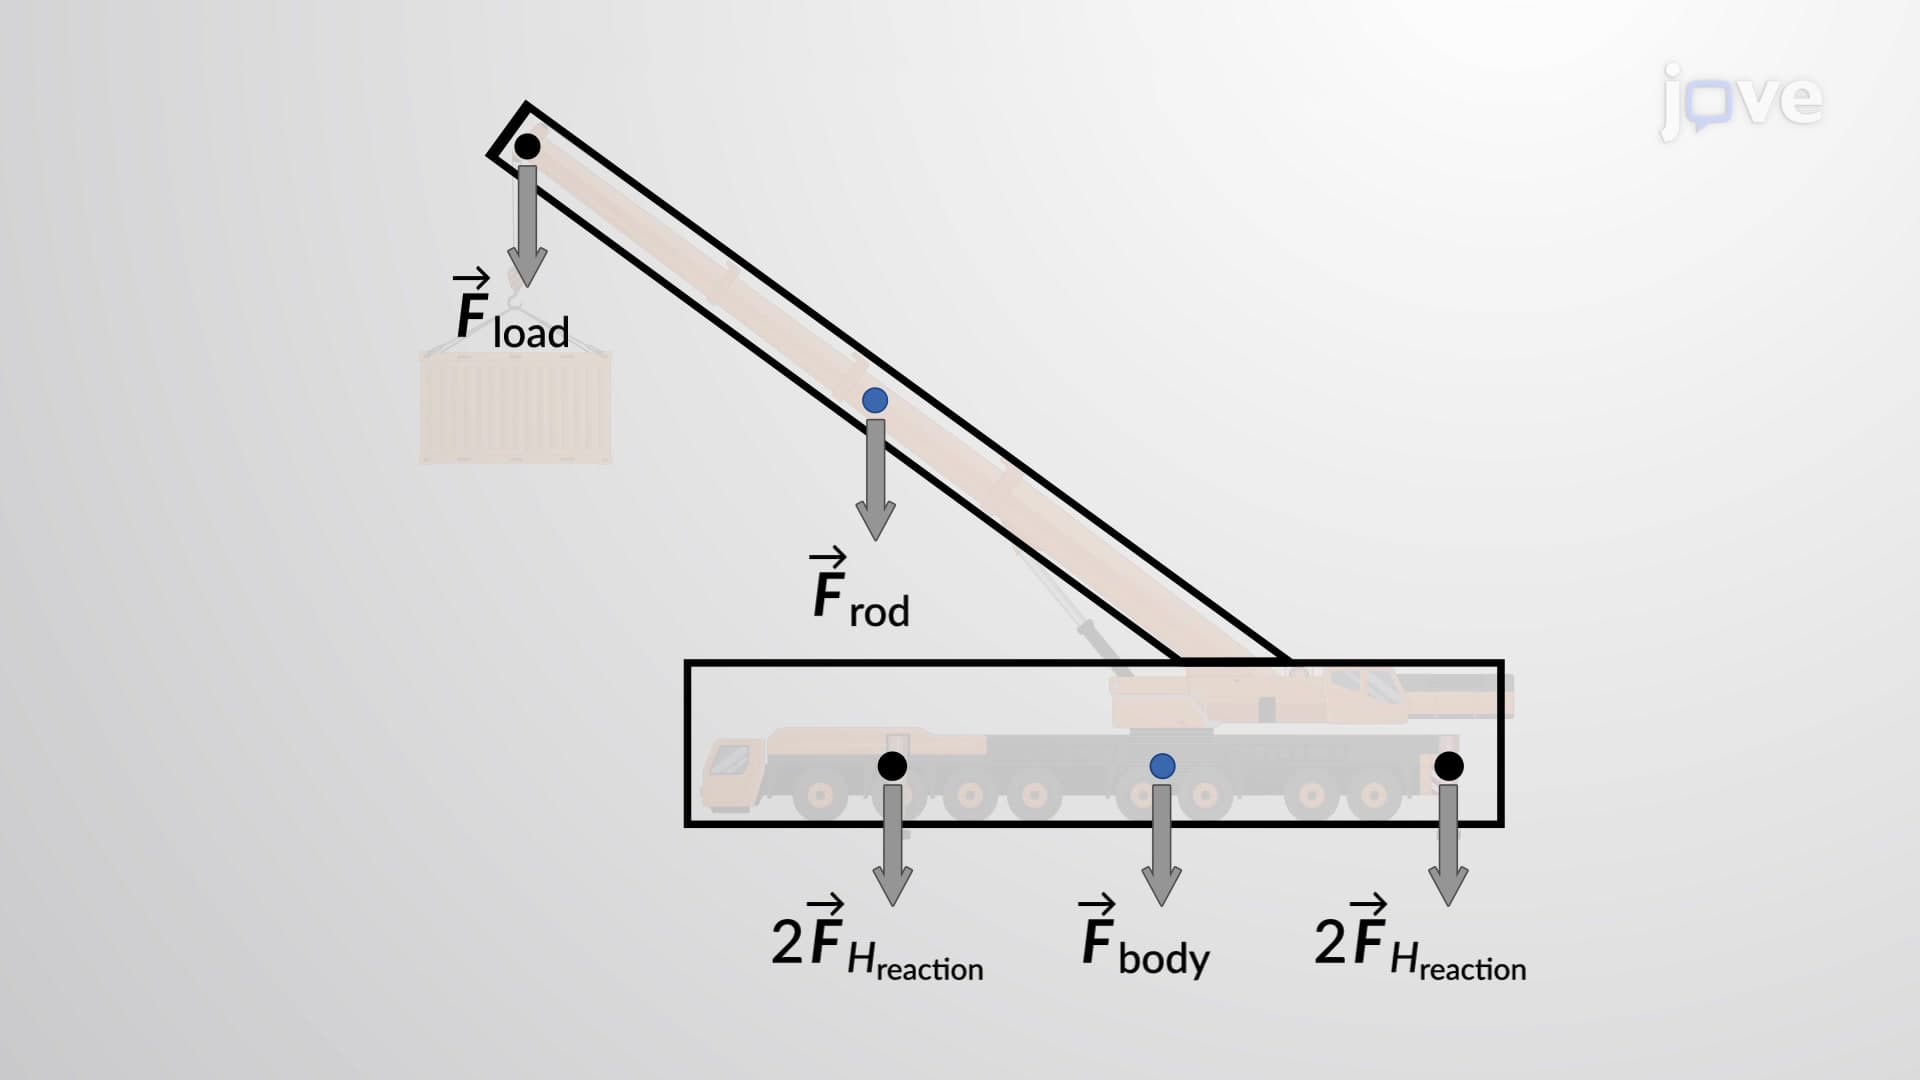
Rigid Body Equilibrium Problems - I
 01:21
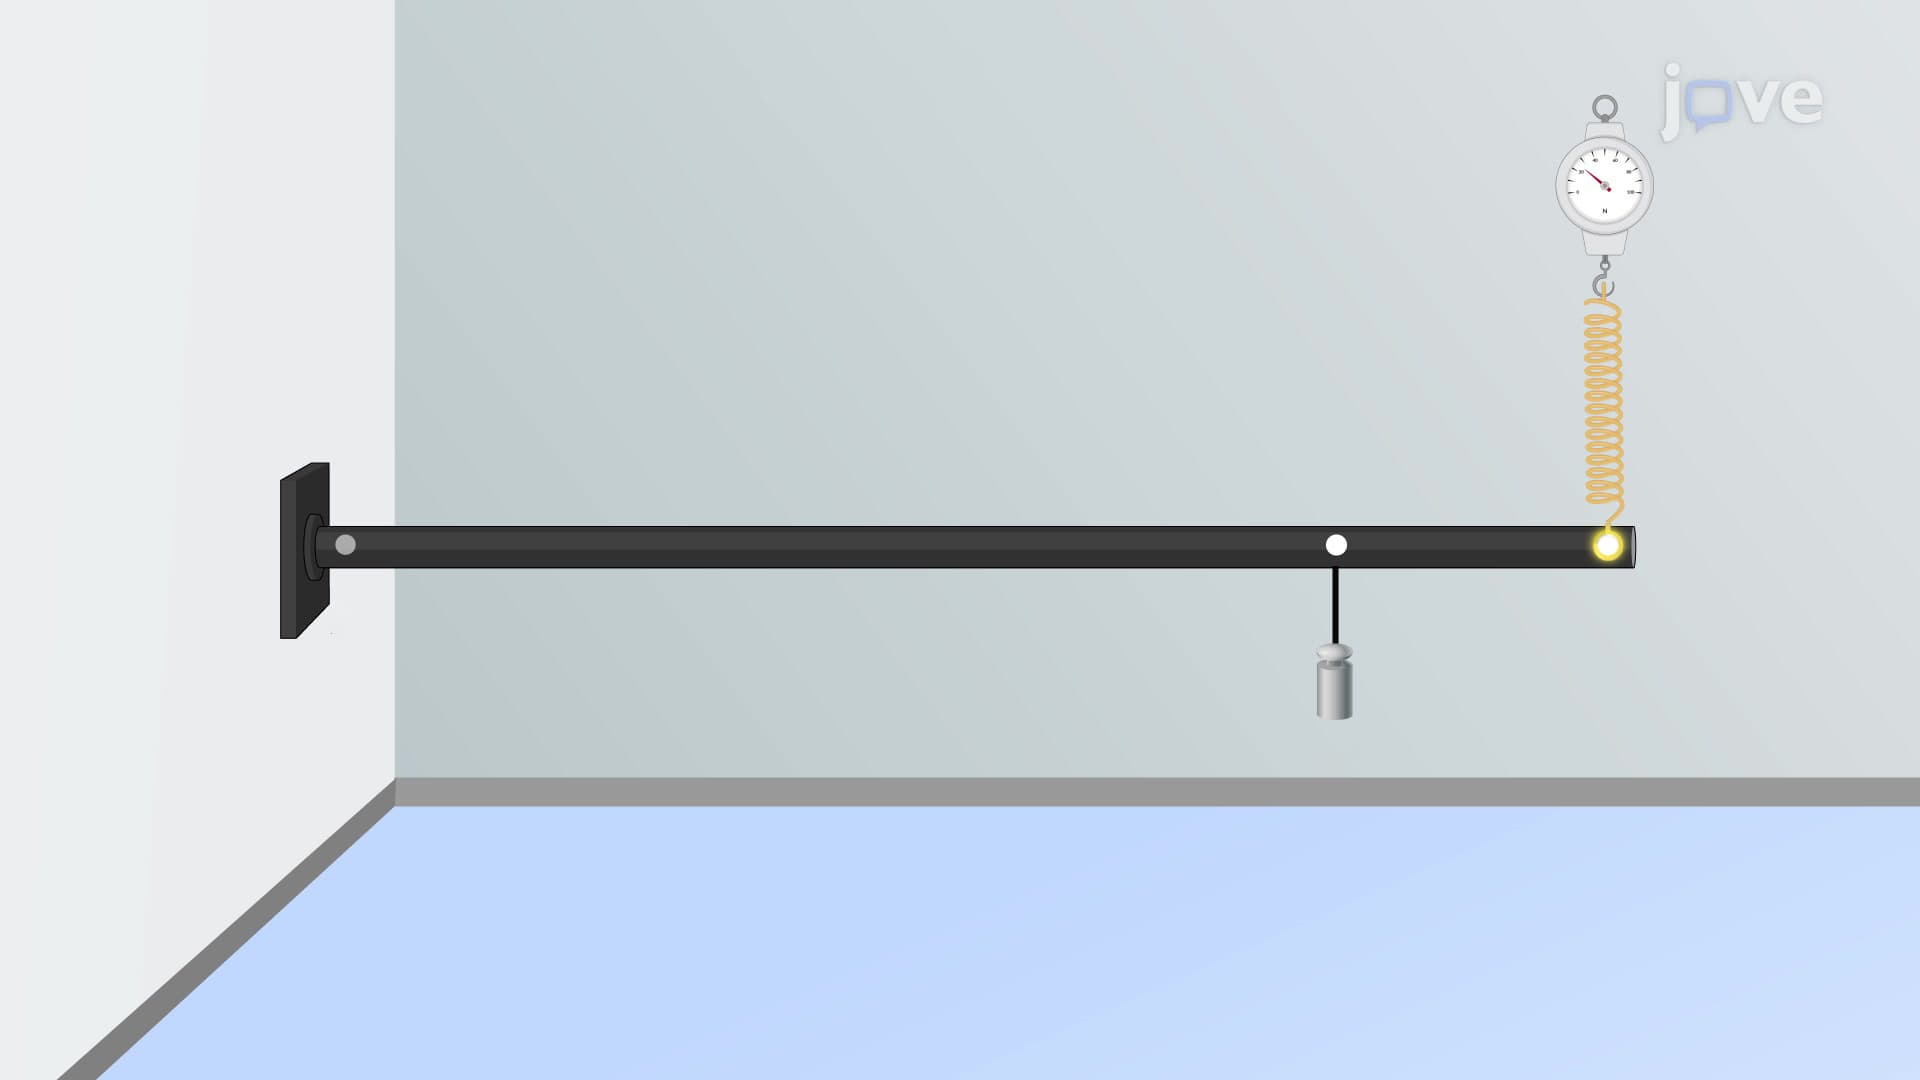
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:13
Stability of Equilibrium Configuration: Problem Solving
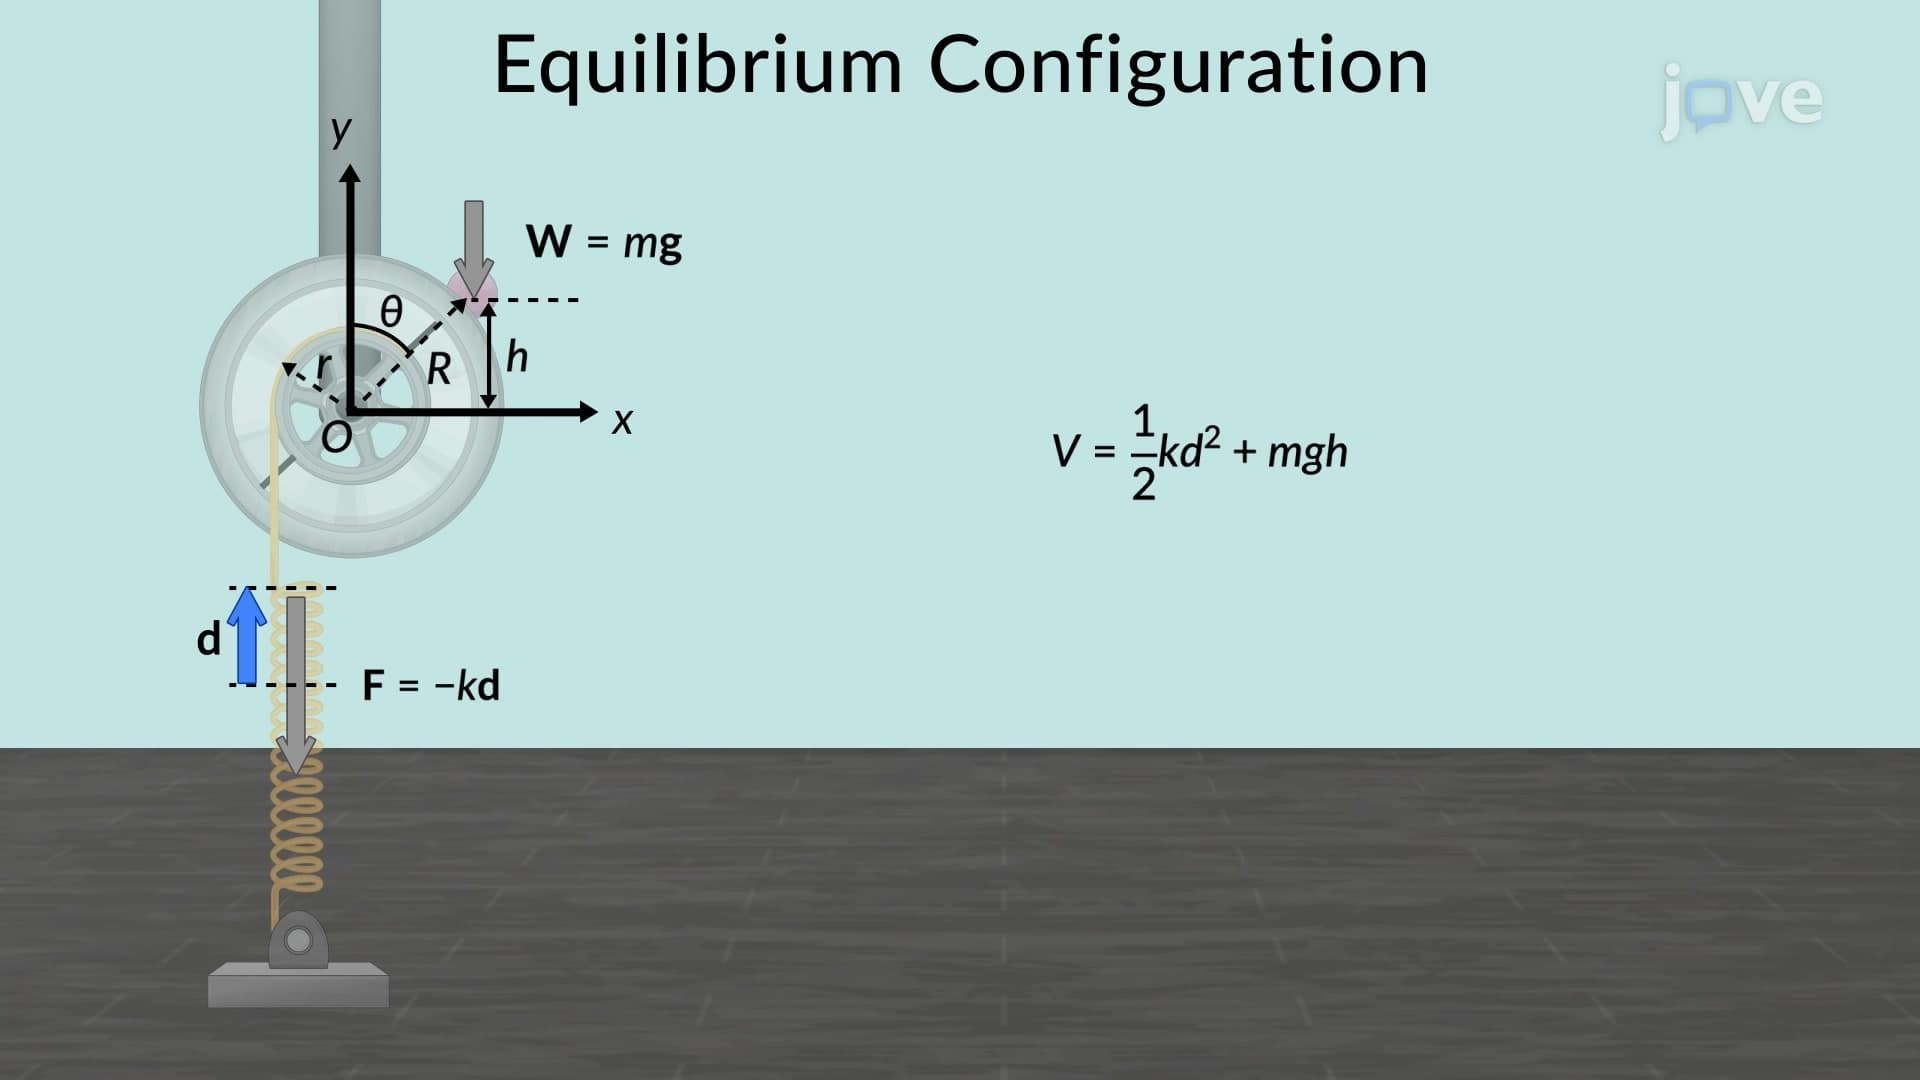
Problem-solving in the context of the stability of equilibrium configuration...
 01:14
Stability of structures
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's response.
 01:28
Stability
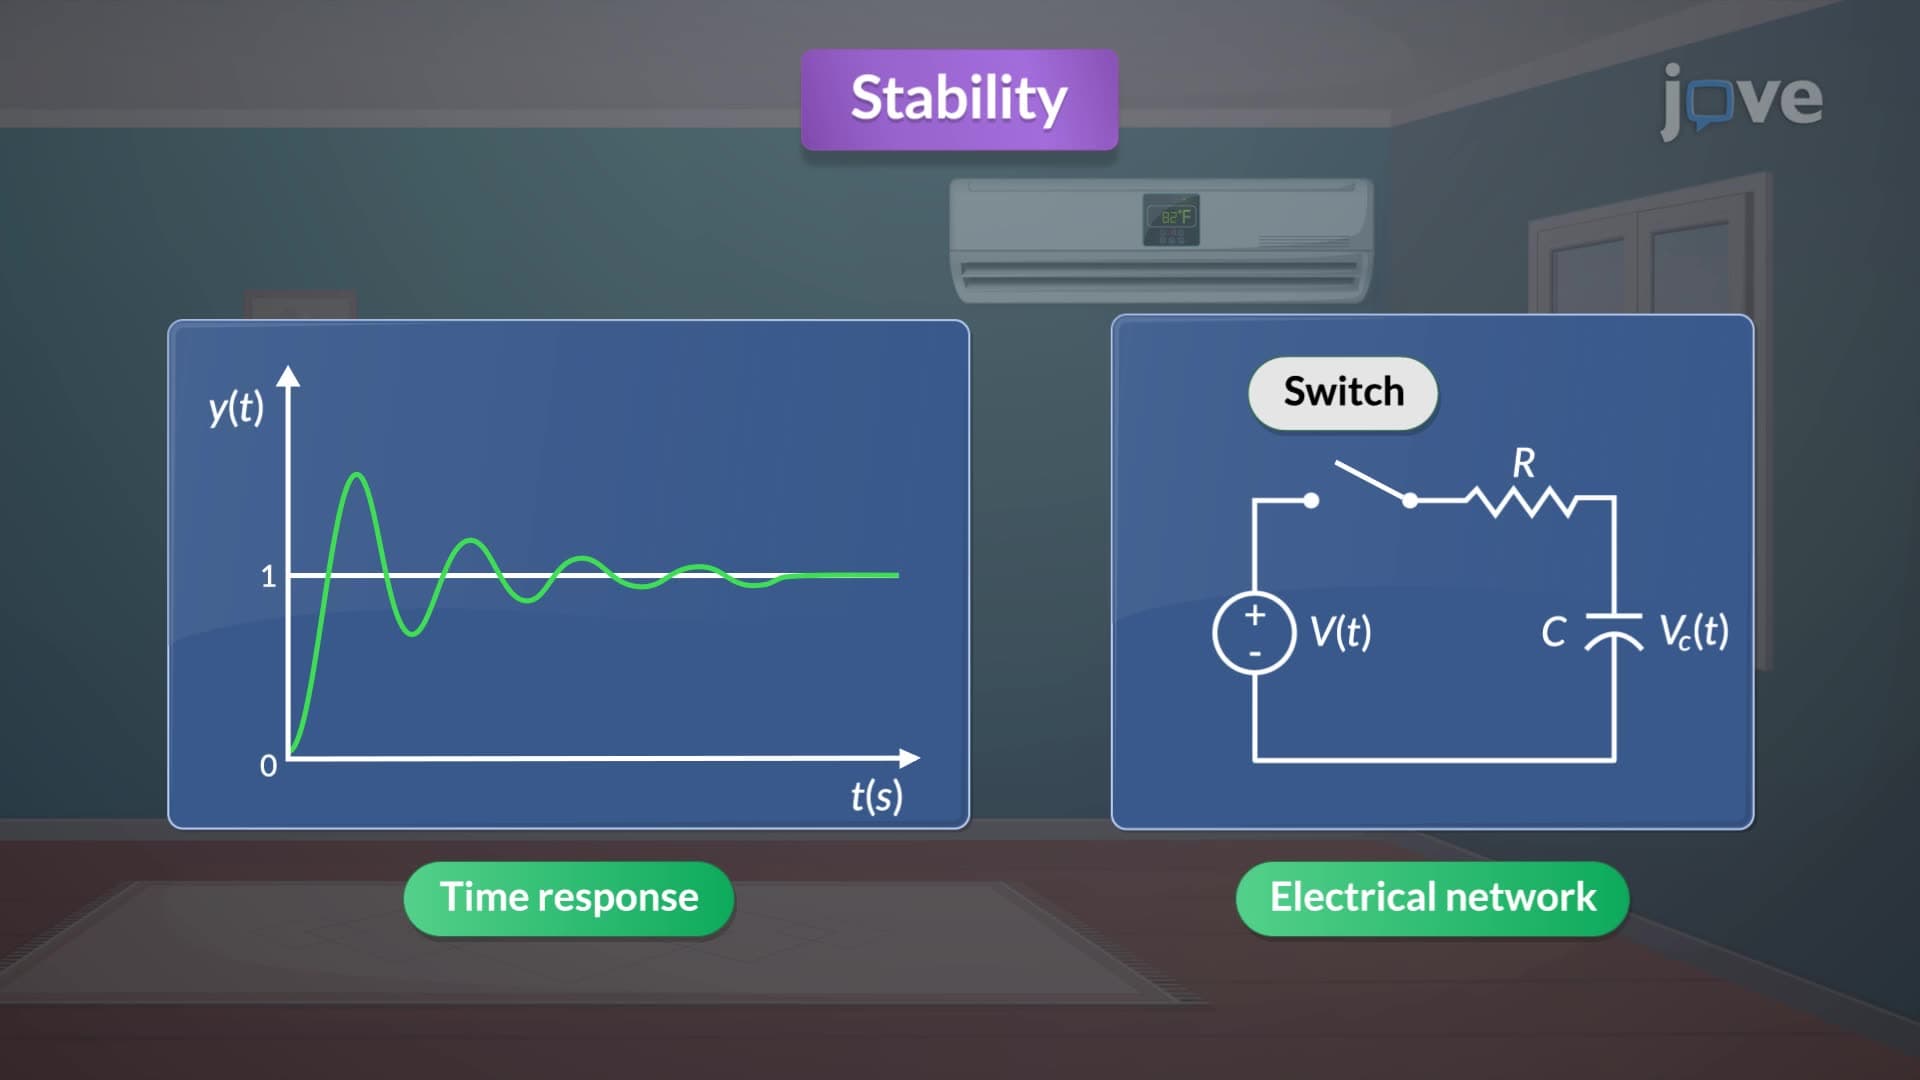
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...